Welcome to ROSMASTER M3 PRO repository
11.Medipipe gesture ID sorting machine code
Medipipe gesture ID sorting machine code
1. Content Description
This function implements the program to capture images through the camera and then recognize gestures (1-4). After analyzing the gestures, the robotic arm moves to a sorting posture. According to the gestures, it sorts the machine-coded wooden blocks on the table. If a machine-coded wooden block with the ID corresponding to the gesture exists on the table, the robotic arm lowers its gripper and places it in the designated location. If a machine-coded wooden block with the ID corresponding to the gesture does not exist on the table, the robotic arm shakes its head and finally returns to the gesture recognition posture.
This section requires entering commands in the terminal. The terminal you open depends on your motherboard type. This lesson uses the Raspberry Pi 5 as an example. For Raspberry Pi and Jetson-Nano boards, you need to open a terminal on the host computer and enter the command to enter the Docker container. Once inside the Docker container, enter the commands mentioned in this section in the terminal. For instructions on entering the Docker container from the host computer, refer to this product tutorial [Configuration and Operation Guide]--[Enter the Docker (Jetson Nano and Raspberry Pi 5 users, see here)].
Simply open the terminal on the Orin motherboard and enter the commands mentioned in this section.
The wooden blocks used in this lesson are: 30x30x30mm Machine Code Blocks.
2. Program startup
First, open the terminal and enter the following command to start the robot arm solver and camera driver,
ros2 launch M3Pro_demo camera_arm_kin.launch.py
Then, open another terminal and enter the following command to start the robotic arm gripping program:
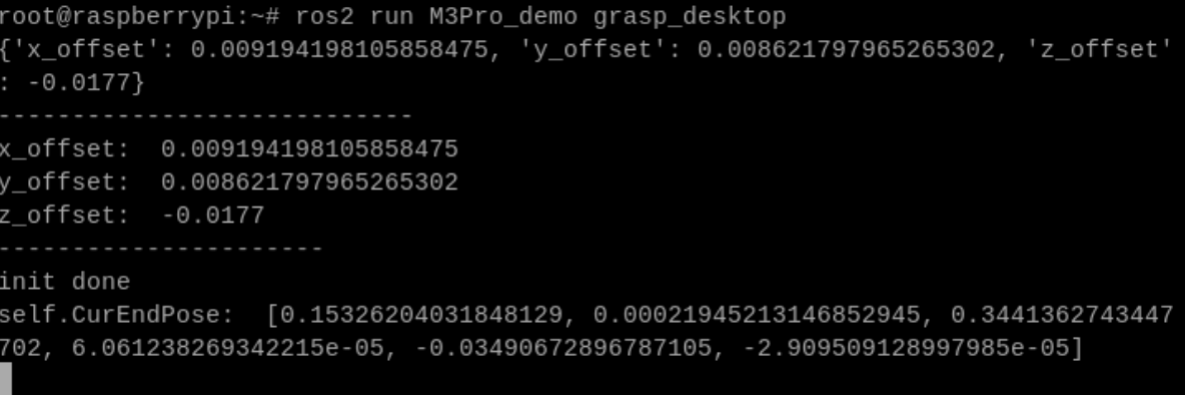
xxxxxxxxxxros2 run M3Pro_demo grasp_desktop
After running, it is shown as follows:
Then enter the following command in the third terminal to start the Mediapipe gesture ID sorting machine code program,
xxxxxxxxxxros2 run M3Pro_demo apriltagID_gesture
After starting this command, the second terminal should receive the current angle topic information sent in one frame and calculate the current posture once, as shown in the figure below.
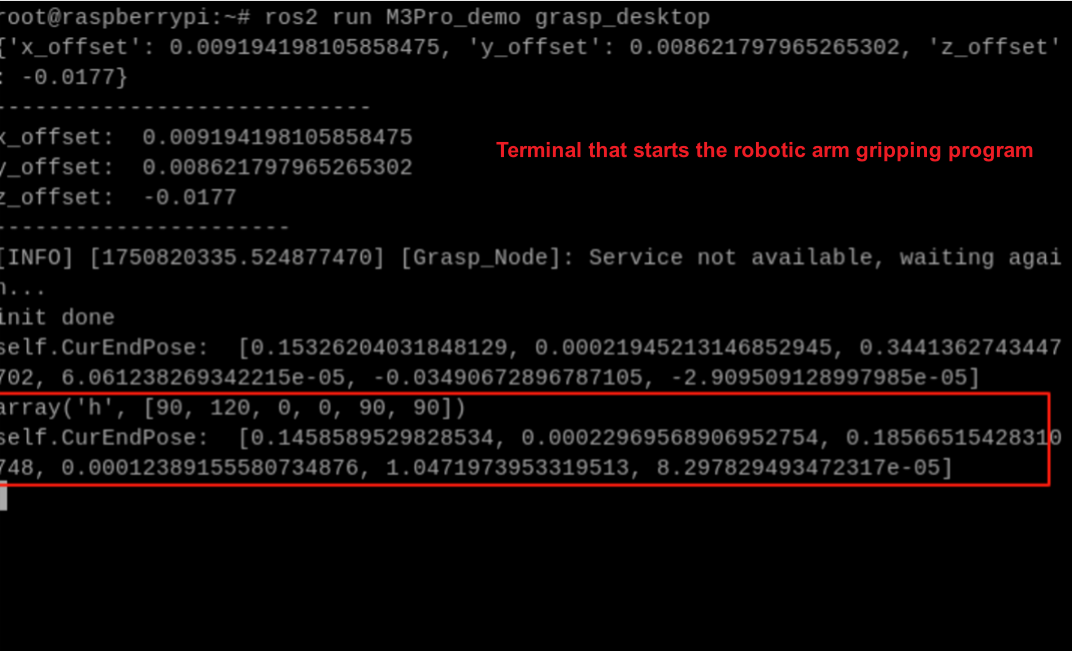
If the current angle information is not received and the current posture is not calculated, the gripping posture will be inaccurate during the coordinate system conversion. Therefore, you need to close the Mediapipe gesture ID sorting machine code program by pressing ctrl c and restart the Mediapipe gesture ID sorting machine code program until the robot arm gripping program obtains the current angle information and calculates the current end position posture.
Then enter the following command in the fourth terminal to start the Mediapipe gesture recognition program,
xxxxxxxxxxros2 run M3Pro_demo mediapipe_detect
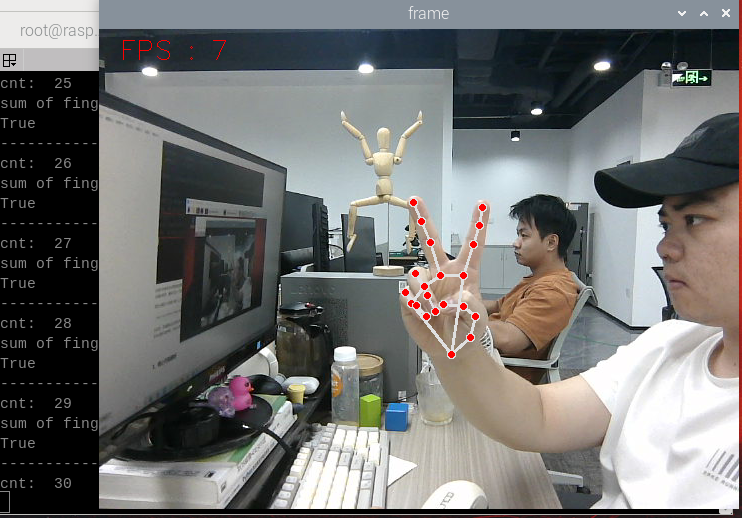
After starting, the robot arm will move to the recognition posture and begin to recognize gestures. The recognized gestures are 1-4. Gesture 1 represents one finger stretched out, gesture 2 represents two fingers stretched out, gesture 3 represents three fingers stretched out, and gesture 4 represents four fingers stretched out. Keep the gesture in mind and wait for the buzzer to sound, indicating that the gesture recognition is complete. The robot arm will move to the sorting posture. As shown in the figure below, assuming gesture 2 is given,
Once in sorting mode, it will begin recognizing the machine code (30x30x30mm) on the table, as shown in the image below.
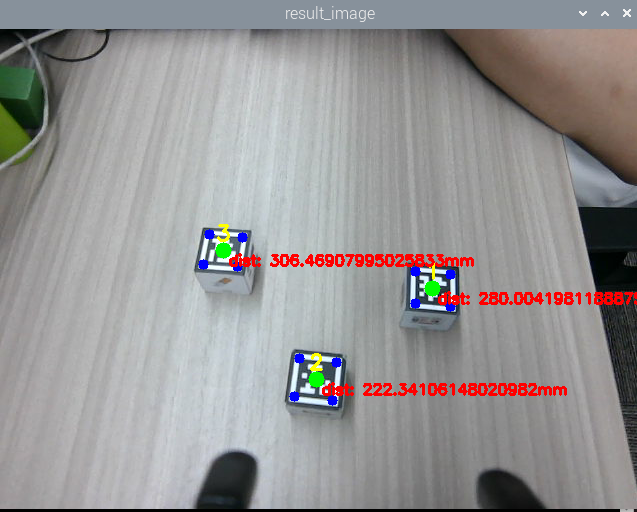
After waiting for 8 seconds, if machine code No. 2 is found, the program will determine whether the distance between the machine code block No. 2 and the trolley base_link is within the range of [210, 220]. If so, the lower claw will directly clamp the machine code block No. 2, and then place it at the set position. Finally, the robotic arm returns to the sorting posture. If not, the distance between the machine code block No. 2 and the trolley base_link is outside the range of [210, 220]. The program will control the chassis to adjust the distance, adjust the distance between the two to within the range of [210, 220], and then clamp it with the lower claw, and then place it at the set position. Finally, the robotic arm returns to the sorting posture.
If machine code No. 2 is not found or no machine code is found, the buzzer on the car will sound, then the robotic arm will shake its head and finally return to the gesture recognition posture.
3. Core code analysis
3.1、mediapipe_detect.py
Program code path:
Raspberry Pi and Jetson-Nano board
The program code is in the running docker. The path in docker is /root/yahboomcar_ws/src/M3Pro_demo/M3Pro_demo/ mediapipe_detect.py
Orin Motherboard
The program code path is /home/jetson/yahboomcar_ws/src/M3Pro_demo/M3Pro_demo/mediapipe_detect.py
Import the necessary libraries,
xxxxxxxxxximport cv2import osimport numpy as npX5Plusfrom sensor_msgs.msg import Imagefrom cv_bridge import CvBridgeimport cv2 as cvfrom arm_msgs.msg import ArmJointsfrom std_msgs.msg import Bool,Int16,UInt16from geometry_msgs.msg import Twistimport timefrom M3Pro_demo.media_library import *from rclpy.node import Nodeimport rclpyfrom message_filters import Subscriber, TimeSynchronizer,ApproximateTimeSynchronizerimport threadingThe program initializes and creates publishers and subscribers,
xxxxxxxxxxdef __init__(self, name): super().__init__(name) #Robotic arm gesture recognition self.init_joints = [90, 150, 12, 20, 90, 0] self.rgb_bridge = CvBridge() self.depth_bridge = CvBridge() #Create a gesture recognition object self.hand_detector = HandDetector() #Define the flag for publishing gestures. When the value is True, it means that the topic of gesture recognition results can be published. self.pub_gesture = True #Record the number of times the gesture recognition has the same result. If the number reaches 30, the gesture recognition is completed. self.cnt = 0 #Record the last gesture recognition result self.last_sum = 0 self.pTime = self.cTime = 0 #Create a topic for publishers to publish gesture recognition results self.pub_GesturetId = self.create_publisher(Int16,"GesturetId",1) self.TargetAngle_pub = self.create_publisher(ArmJoints, "arm6_joints", 10) self.rgb_image_sub = Subscriber(self, Image, '/camera/color/image_raw') #Create a subscriber to subscribe to the reset gesture recognition result topic self.sub_reset_gesture = self.create_subscription(Bool,"reset_gesture",self.get_resetCallBack,100) self.pub_beep = self.create_publisher(UInt16, "beep", 10) #Control the robot arm to move to the recognized gesture posture self.pubSix_Arm(self.init_joints) self.ts = ApproximateTimeSynchronizer([self.rgb_image_sub], 1, 0.5) self.ts.registerCallback(self.callback) time.sleep(2)callback image topic callback function,
xxxxxxxxxxdef callback(self,color_msg): #Get color image topic data and use CvBridge to convert message data into image data rgb_image = self.rgb_bridge.imgmsg_to_cv2(color_msg, "bgr8") #Pass the obtained image data into self.process for gesture recognition self.process(rgb_image)process function,
xxxxxxxxxxdef process(self, frame): #Call the findHands function to detect the palm. The function will return the lmList list, which stores the detection results. frame, lmList, bbox = self.hand_detector.findHands(frame) #If the detection list is not empty, it means that a palm is detected, and self.pub_gesture is True, which means that the gesture topic can be published if len(lmList) != 0 and self.pub_gesture == True: #Start the thread and execute the gesture recognition program gesture = threading.Thread(target=self.Gesture_Detect_threading, args=(lmList,bbox)) gesture.start() gesture.join() self.cTime = time.time() fps = 1 / (self.cTime - self.pTime) self.pTime = self.cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) #self.media_ros.pub_imgMsg(frame) if cv.waitKey(1) & 0xFF == ord('q'): cv.destroyAllWindows() cv.imshow('frame', frame)Gesture_Detect_threading gesture detection program,
xxxxxxxxxxdef Gesture_Detect_threading(self, lmList,bbox): #Call fingersUp function to return the number of fingers extended fingers = self.hand_detector.fingersUp(lmList) print("sum of fingers: ",sum(fingers)) print(self.pub_gesture) #If the number of fingers stretched is the same as last time, then start counting if sum(fingers) == self.last_sum: print("---------------------------") self.cnt = self.cnt + 1 print("cnt: ",self.cnt) #The cumulative count reaches 30, indicating that the gesture recognition results of 30 times are the same. The gesture recognition program ends, the buzzer sounds once, and the gesture recognition result topic is published. if self.cnt==30 and self.pub_gesture == True: self.Beep_Loop() print("sum of fingers: ",self.last_sum) self.pub_gesture = False sum_gesture = Int16() sum_gesture.data = self.last_sum self.pub_GesturetId.publish(sum_gesture) else: self.cnt = 0 #Change the gesture result of the last recognition to the current number of fingers stretched self.last_sum = sum(fingers)3.2, apriltagID_gesture.py
Program code path:
Raspberry Pi and Jetson-Nano board
The program code is in the running docker. The path in docker is /root/yahboomcar_ws/src/M3Pro_demo/M3Pro_demo/ apriltagID_gesture.py
Orin Motherboard
The program code path is /home/jetson/yahboomcar_ws/src/M3Pro_demo/M3Pro_demo/apriltagID_gesture.py
Import the necessary library files,
xxxxxxxxxximport cv2import osimport numpy as npimport message_filtersfrom M3Pro_demo.vutils import draw_tagsfrom dt_apriltags import Detectorfrom cv_bridge import CvBridgeimport cv2 as cvfrom arm_interface.srv import ArmKinemaricsfrom arm_interface.msg import AprilTagInfo,CurJointsfrom arm_msgs.msg import ArmJointsfrom arm_msgs.msg import ArmJointfrom M3Pro_demo.Robot_Move import *from M3Pro_demo.compute_joint5 import *from std_msgs.msg import Float32,Bool,UInt16,Int16import timeimport yamlimport mathfrom rclpy.node import Nodeimport rclpyfrom message_filters import Subscriber, TimeSynchronizer,ApproximateTimeSynchronizerfrom sensor_msgs.msg import Imagefrom geometry_msgs.msg import Twistimport transforms3d as tfsimport tf_transformations as tfThe program initializes and creates publishers and subscribers,
xxxxxxxxxxdef __init__(self, name): super().__init__(name). #Robot arm sorting posture self.init_joints = [90, 120, 0, 0, 90, 90] self.identify_joints = [90, 150, 12, 20, 90, 0] #Define the array to store the end posture of the robotic arm self.CurEndPos = [0.0, 0.0, 0.0, 0.0, 0.0, 0.0] self.rgb_bridge = CvBridge() self.depth_bridge = CvBridge() self.pubPos_flag = False self.at_detector = Detector(searchpath=['apriltags'], families='tag36h11', nthreads=8, quad_decimate=2.0, quad_sigma=0.0, refine_edges=1, decode_sharpening=0.25, debug=0) self.Center_x_list = [] self.Center_y_list = [] self.pos_info_pub = self.create_publisher(AprilTagInfo,"PosInfo",1) self.CmdVel_pub = self.create_publisher(Twist,"cmd_vel",1) self.sub_grasp_status = self.create_subscription(Bool,"grasp_done",self.get_graspStatusCallBack,100) self.pub_cur_joints = self.create_publisher(CurJoints,"Curjoints",1) #Define the publisher of the reset gesture result topic self.pub_reset_gesture = self.create_publisher(Bool,"reset_gesture",1) self.TargetAngle_pub = self.create_publisher(ArmJoints, "arm6_joints", 10) self.pub_SingleTargetAngle = self.create_publisher(ArmJoint, "arm_joint", 10) self.rgb_image_sub = Subscriber(self, Image, '/camera/color/image_raw') self.depth_image_sub = Subscriber(self, Image, '/camera/depth/image_raw') self.client = self.create_client(ArmKinemarics, 'get_kinemarics') self.TargetJoint5_pub = self.create_publisher(Int16, "set_joint5", 10) self.get_current_end_pos() self.pubCurrentJoints() #Define the subscriber who subscribes to the gesture recognition result topic self.sub_GesturetId = self.create_subscription(Int16,"GesturetId",self.get_GesturetIdCallBack,1) self.ts = ApproximateTimeSynchronizer([self.rgb_image_sub, self.depth_image_sub], 1, 0.5) #Define the publisher to publish the buzzer control topic self.pub_beep = self.create_publisher(UInt16, "beep", 10) self.ts.registerCallback(self.callback) self.camera_info_K = [477.57421875, 0.0, 319.3820495605469, 0.0, 477.55718994140625, 238.64108276367188, 0.0, 0.0, 1.0] self.EndToCamMat = np.array([[ 0 ,0 ,1 ,-1.00e-01], [-1 ,0 ,0 ,0], [0 ,-1 ,0 ,4.82000000e-02], [ 0.00000000e+00 , 0.00000000e+00 , 0.00000000e+00 , 1.00000000e+00]]) time.sleep(2) self.TargetID = 0 self.detect_flag = False self.x_offset = offset_config.get('x_offset') self.y_offset = offset_config.get('y_offset') self.z_offset = offset_config.get('z_offset') self.adjust_dist = True self.linearx_PID = (0.5, 0.0, 0.2) self.linearx_pid = simplePID(self.linearx_PID[0] / 1000.0, self.linearx_PID[1] / 1000.0, self.linearx_PID[2] / 1000.0) self.joint5 = Int16() self.count = False self.start_time = 0.0 self.index = Nonecallback image topic processing function,
xxxxxxxxxxdef callback(self,color_msg,depth_msg): rgb_image = self.rgb_bridge.imgmsg_to_cv2(color_msg, "rgb8") depth_image = self.depth_bridge.imgmsg_to_cv2(depth_msg, "32FC1") depth_to_color_image = cv.applyColorMap(cv.convertScaleAbs(depth_image, alpha=1.0), cv.COLORMAP_JET) frame = cv.resize(depth_image, (640, 480)) depth_image_info = frame.astype(np.float32) tags = self.at_detector.detect(cv2.cvtColor(rgb_image, cv2.COLOR_RGB2GRAY), False, None, 0.025) self.Center_x_list = list(range(len(tags))) self.Center_y_list = list(range(len(tags))) draw_tags(rgb_image, tags, corners_color=(0, 0, 255), center_color=(0, 255, 0)) key = cv2.waitKey(10) if key == 32: self.pubPos_flag = True if self.count==True: if (time.time() - self.start_time)>8: self.pubPos_flag = True self.count = False if len(tags) > 0 : for i in range(len(tags)): center_x, center_y = tags[i].center self.Center_x_list[i] = center_x self.Center_y_list[i] = center_y cur_id = tags[i].tag_id cx = center_x cy = center_y cz = depth_image_info[int(cy),int(cx)]/1000 print("cx: ",cx) print("cy: ",cy) print("cz: ",cz) pose = self.compute_heigh(cx,cy,cz) dist_detect = math.sqrt(pose[1] ** 2 + pose[0]** 2) dist_detect = dist_detect*1000 dist = 'dist: ' + str(dist_detect) + 'mm' cv.putText(rgb_image, dist, (int(cx)+5, int(cy)+15), cv.FONT_HERSHEY_SIMPLEX, 0.5, (255, 0, 0), 2) #If the current ID is the target ID, it means the target machine code has been found if cur_id == self.TargetID and self.pubPos_flag==True: print("Found the target.") #Change the value of self.detect_flag to indicate that the target ID machine code has been found self.detect_flag = True #Store the array index of tags of the target ID machine code self.index = i print("self.index: ",self.index) #If the target ID machine code is found and chassis adjustment is enabled, and the distance between the machine code block and the car base_link is outside the range [210, 220] if abs(dist_detect - 215.0)>5 and self.adjust_dist==True and self.detect_flag == True and self.index!=None: print("Adjusting") #Call move_dist to control the chassis movement and adjust the distance self.move_dist(dist_detect) #If the target ID machine code is found and the distance between the machine code block and the car base_link is within the range of [210, 220] elif abs(dist_detect - 215.0)<5 and self.detect_flag == True and self.index!=None: self.pubVel(0,0,0) self.adjust_dist = False tag = AprilTagInfo() tag.id = tags[self.index].tag_id #Find the target machine code through the array subscript and extract the center coordinates xy tag.x = float(self.Center_x_list[self.index]) tag.y = float(self.Center_y_list[self.index]) tag.z = depth_image_info[int(tag.y),int(tag.x)]/1000 vx = int(tags[self.index].corners[0][0]) - int(tags[self.index].corners[1][0]) vy = int(tags[self.index].corners[0][1]) - int(tags[self.index].corners[1][1]) target_joint5 = compute_joint5(vx,vy) print("target_joint5: ",target_joint5) self.joint5.data = int(target_joint5) if tag.z!=0 and self.pubPos_flag == True : #Publish machine code location topic message self.pos_info_pub.publish(tag) self.TargetJoint5_pub.publish(self.joint5) self.pubPos_flag = False self.index = None else: print("Invalid distance.") #If the machine code location topic is enabled but the target ID machine code is not found, the buzzer sounds once and the reset gesture topic is published if self.detect_flag == False and self.TargetID!=0 and self.pubPos_flag==True: self.pubPos_flag = False self.Beep_Loop() self.shake() print("Did not find the target.") self.TargetID = 0 reset = Bool() reset.data = True self.pub_reset_gesture.publish(reset) #If the machine code location topic is enabled but no machine code is found, the buzzer sounds and the reset gesture topic is published elif self.pubPos_flag==True and len(tags)==0: self.pubVel(0,0,0) self.Beep_Loop() self.shake() reset = Bool() reset.data = True self.pub_reset_gesture.publish(reset) self.pubPos_flag = False print("Did not find any target.") rgb_image = cv2.cvtColor(rgb_image, cv2.COLOR_RGB2BGR) cv2.imshow("result_image", rgb_image) cv2.imshow("depth_image", depth_to_color_image) key = cv2.waitKey(1)