Welcome to ROSMASTER M3 PRO repository
3.Multimodal visual understand+robotic arm grab
Multimodal Visual Understanding + Robotic Arm Grasping
Multimodal Visual Understanding + Robotic Arm Grasping1. Course Content2. Starting the Agent3. Running the Examples3.1 Starting the Program3.2 Test Cases3.2.1 Case 1: "Find the red cube in front of you and grasp it"3.2.2 Case 2: "Put the red block in front of you to the right of the blue block"3.2.3 Case 3: "Please help me remove the machine code in front of you that is taller than 5 centimeters"4. Source Code Analysis4.1 Case 14.2 Case Study 24.3 Case Study 3
1. Course Content
Run the example program, using the robot's visual understanding combined with robotic arm grasping for a comprehensive task.
[!NOTE]
- The only difference between the text version and the voice version is the method of command input; the text version does not include speech recognition and speech synthesis playback.
2. Starting the Agent
Note: If already started, there is no need to start again.
Enter the following command in the vehicle terminal:
sh start_agent.sh
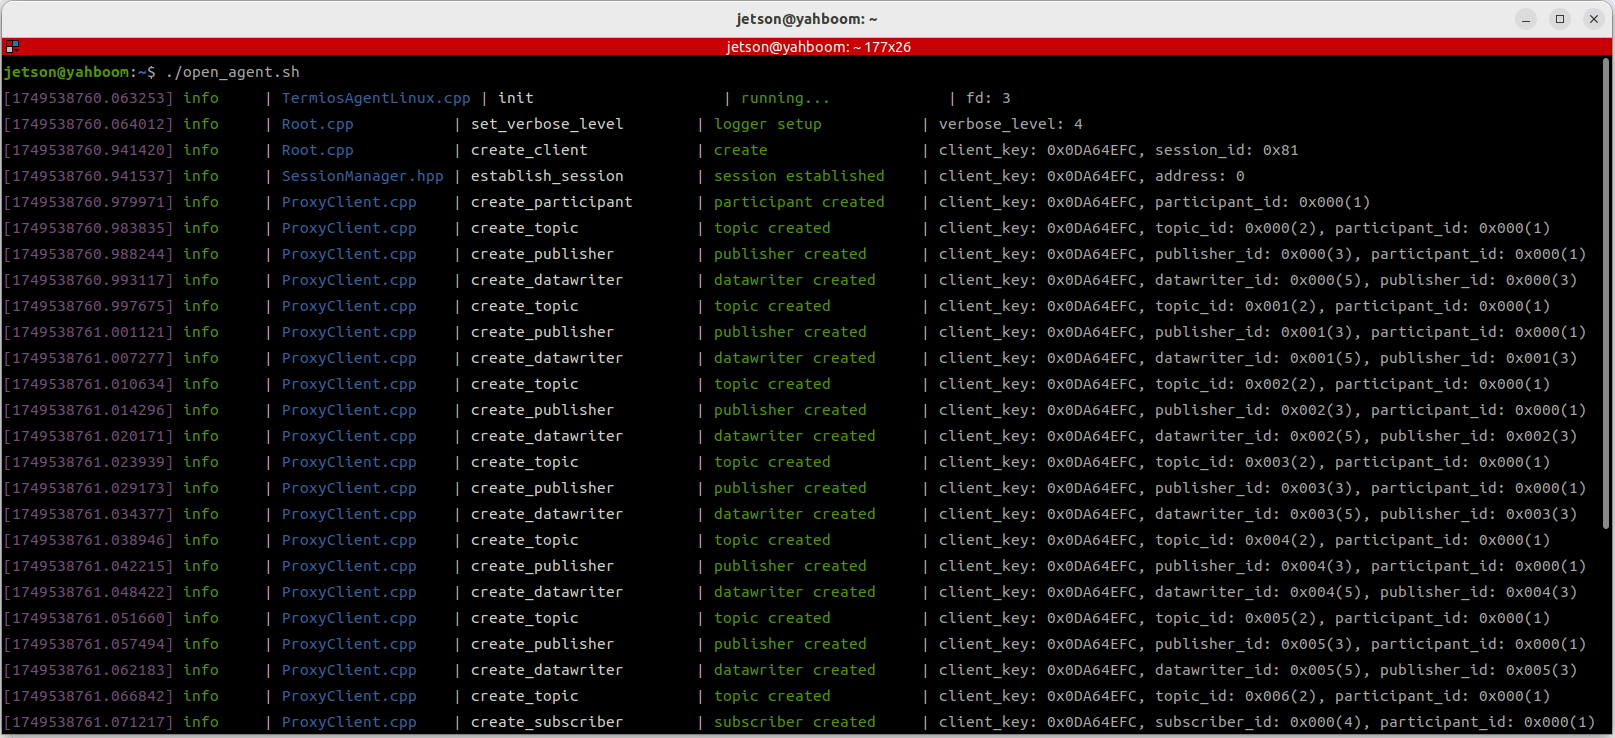
The terminal will print the following information, indicating a successful connection:
3. Running the Examples
3.1 Starting the Program
Connect to the vehicle's screen via VNC and start the AI agent function:
xxxxxxxxxxros2 launch multi_brains llm_agent_control.launch.py text_chat_mode:=True- Start text interaction in any terminal:
xxxxxxxxxxros2 run text_chat text_chat3.2 Test Cases
Here are four reference test cases; users can create their own dialogue commands.
- Find the red cube in front of you and grasp it.Wooden blocks used: 30x30x30 mm blocks.
- Place the red cube in front of you to the right of the blue cube.Wooden blocks used: 30x30x30 mm blocks.
- Please remove the machine code in front of you that is taller than 5 centimeters.Wooden blocks used: 30x30x30 mm blocks.
- Track machine code number three.Wooden blocks used: 40x40x40 mm blocks.
3.2.1 Case 1: "Find the red cube in front of you and grasp it"
Enter "Find the red cube in front of you and grasp it" in the virtual machine terminal. The terminal will print the following information:
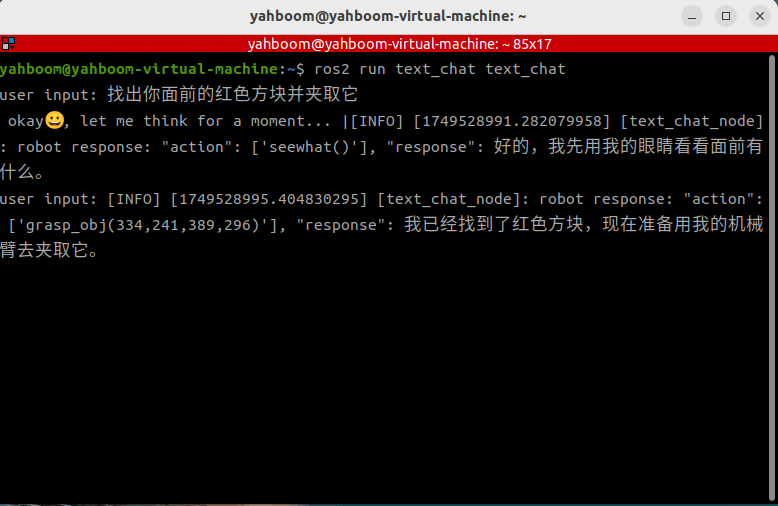
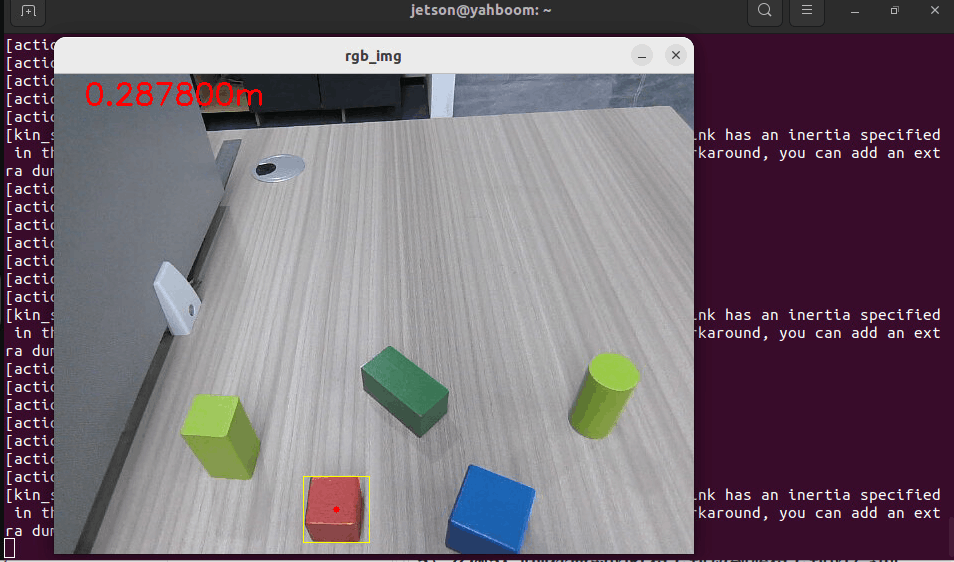
After the grasp_obj() function is called, a window titled rgb_img will open in the VNC screen, displaying the image from the robot's perspective. The robot will automatically adjust the distance to the target object. After the distance adjustment is complete, the robot will use the robotic arm to grasp the target object.
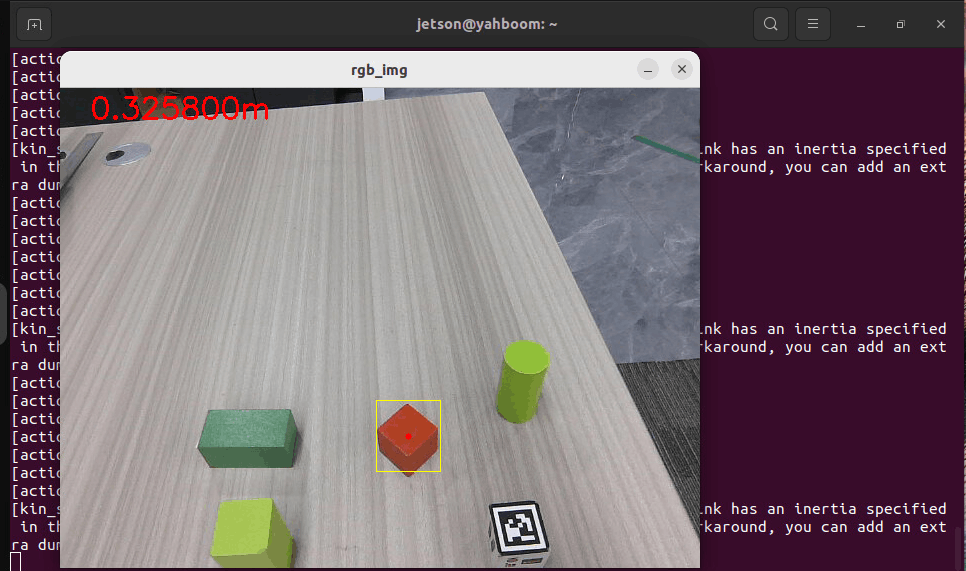
After the robot picks up an object, the robotic arm will remain in its current position. If you need the robotic arm to return to its initial state, you can use the following methods:
- Method 1: Enter the command: "Put down the block you just picked up" to make the robot put down the red block it just picked up.
- Method 2: Enter the command: "End the current task" to make the robot end the current task. After the task cycle ends, the robotic arm will reset to its initial posture.
Here, we use Method 2 as an example to make the robot end the task and reset the task cycle.
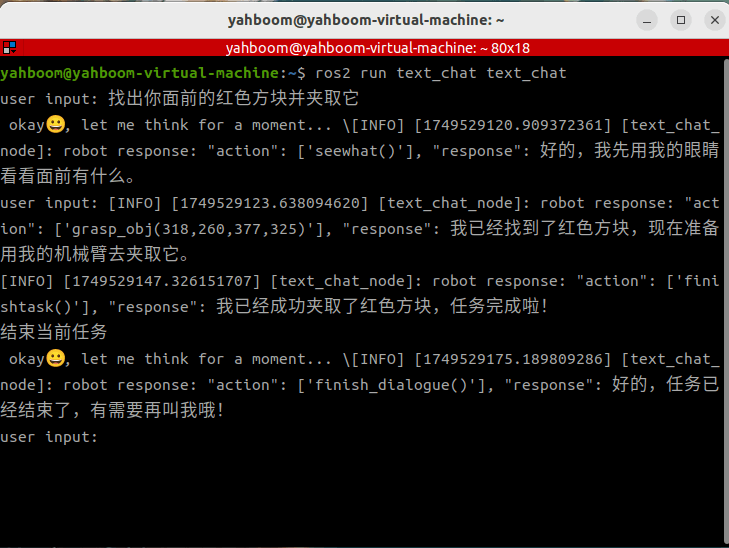
3.2.2 Case 2: "Put the red block in front of you to the right of the blue block"
- Enter "Put the red block in front of you to the right of the blue block" in the terminal. The terminal will print the following information:
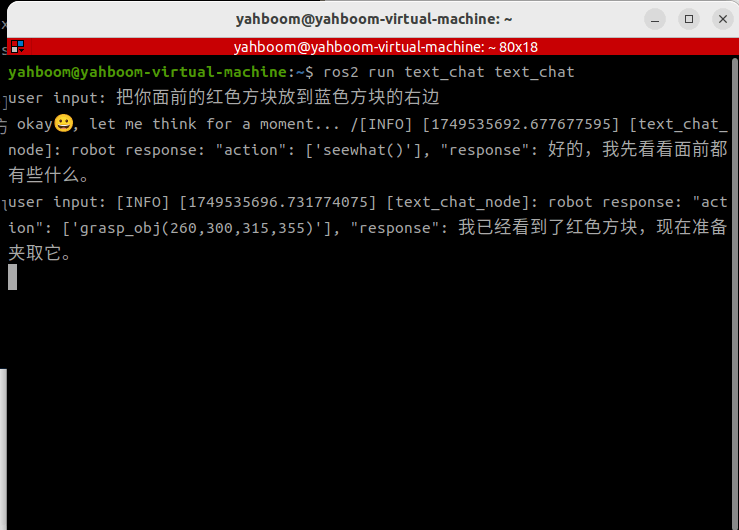
A window titled rgb_img will open in the VNC screen, displaying the image from the robot's perspective. The robot will automatically adjust the distance between itself and the target object. After the distance adjustment is complete, the robot will use its robotic arm to pick up the target object.
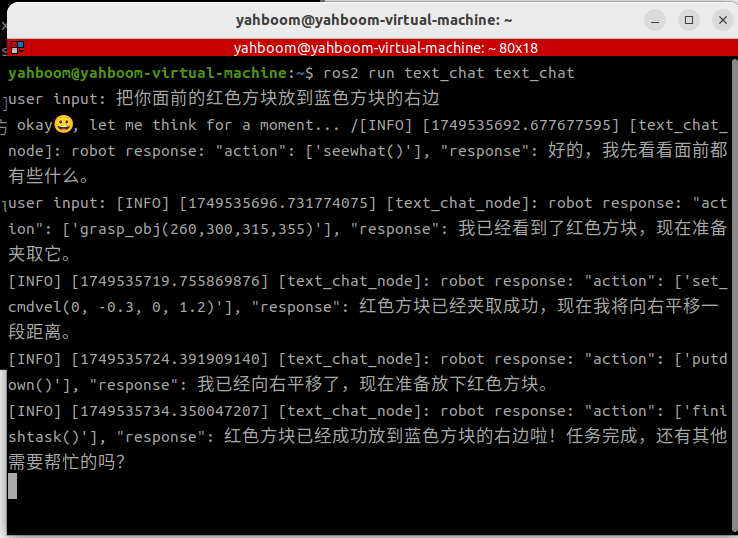
Then the robot will translate to the right for a certain distance, and then use its robotic arm to put down the red block it just picked up, and indicate that the task is complete.
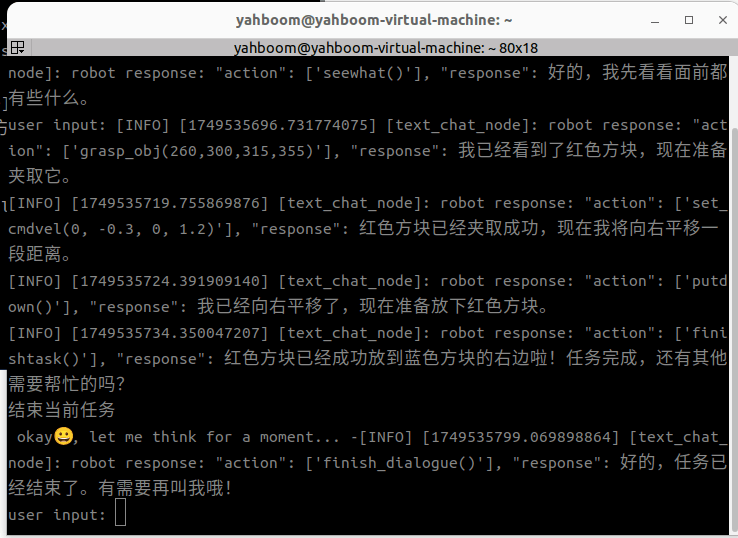
When commands such as "End current task" or "You can rest now," which indicate that the robot is no longer needed, are entered, the robot will end the current task.
3.2.3 Case 3: "Please help me remove the machine code in front of you that is taller than 5 centimeters"
Entering "Please help me remove the machine code in front of you that is taller than 5 centimeters" in the virtual machine terminal will print the following information:
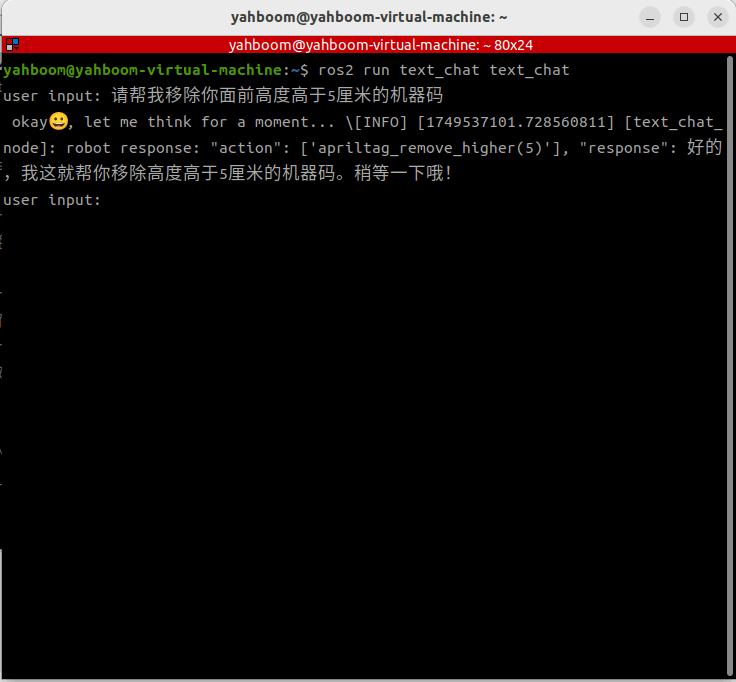
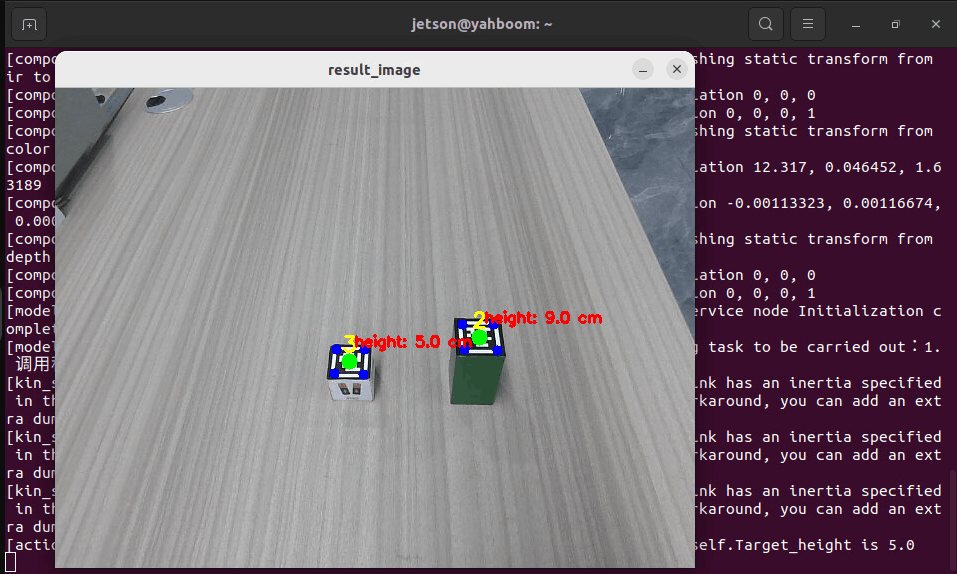
A window titled result_image will open in the VNC screen, displaying the image from the robot's perspective. The height of each machine code can be seen. After the distance measurement stabilizes, the robot will automatically adjust its distance from the target, and then use its robotic arm to pick up the machine code of the target height and move it to the right side of the robot.
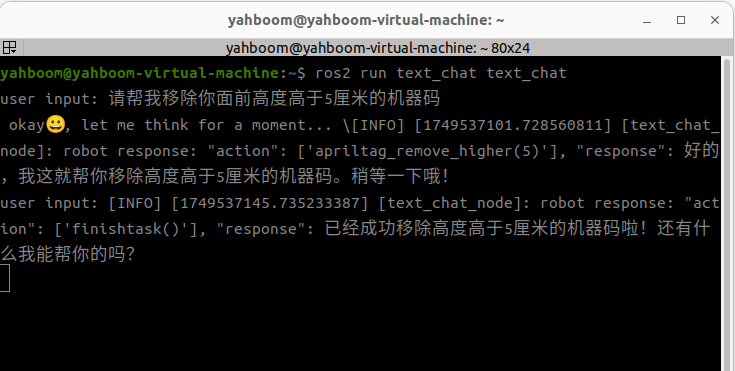
When you enter commands in the terminal such as "end current task" or "you can rest now," which no longer require the robot's action, the robot will end the current task.
4. Source Code Analysis
- Robot action source code path:
xxxxxxxxxx~/M3Pro_ws/src/multi_brains/multi_brains/action_service.py
4.1 Case 1
action_service.py program:
Case 1 uses the seewhat and grasp_obj methods in the ActionController class. The seewhat function mainly obtains the color image from the depth camera, which has been explained in the Multimodal Visual Understanding section. Here, we will explain the grasp_obj function.
The coordinate rules for objects in the robotic arm's grasping view are shown in the following figure:
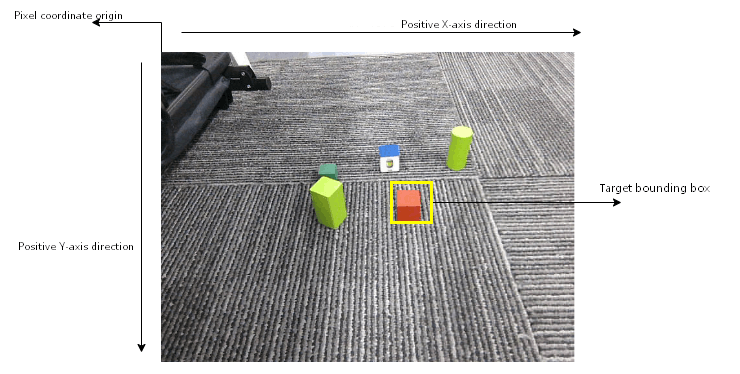
The grasp_obj(x1, y1, x2, y2) function is used to call the robotic arm to grasp the target object. The parameters are the coordinates of the top-left and bottom-right vertices of the bounding box of the object to be grasped (the top-left corner of the image is the pixel coordinate origin). For example, in Case 1, the bounding box coordinates of the red square to be grasped can be obtained from the large model's response: the top-left corner coordinates are (365, 200), and the bottom-right corner coordinates are (408, 261).
grasp_objstarts three subprocesses: grasp_desktop, KCF_follow, and ALM_KCF_Tracker_Node3, and passes the parameters given by the AI large model to the ALM_KCF_Tracker_Node node via topics.
x def grasp_obj(self, x1, y1, x2, y2) -> None: """grasp_obj: Grasping object x1, y1, x2, y2: Coordinates of the object's bounding box """ def __reset_grasp_obj(): kill_process_tree(self.grasp_obj_process_1.pid) kill_process_tree(self.grasp_obj_process_2.pid) kill_process_tree(self.grasp_obj_process_3.pid) self.grasp_obj_future = Future() cmd_1=['ros2', 'run', 'largemodel_arm', 'grasp_desktop'] cmd_2=['ros2', 'run', 'largemodel_arm', 'KCF_follow'] cmd_3=['ros2', 'run', 'M3Pro_KCF', 'ALM_KCF_Tracker_Node'] self.grasp_obj_process_1=subprocess.Popen(cmd_1) time.sleep(5.0) #Waiting for grasp_desktop to finish starting up self.grasp_obj_process_2=subprocess.Popen(cmd_2) self.grasp_obj_process_3=subprocess.Popen(cmd_3) time.sleep(1.0) x1 = int(x1) y1 = int(y1) x2 = int(x2) y2 = int(y2) self.object_position_pub.publish(Int16MultiArray(data=[x1, y1, x2, y2])) while not self.grasp_obj_future.done(): if self.interrupt_event.is_set(): __reset_grasp_obj() self.pubSix_Arm(self.init_joints) return None time.sleep(0.1) result = self.grasp_obj_future.result() if not self.interrupt_event.is_set(): if result.data == "grasp_obj_done": res = True else: res = False __reset_grasp_obj() if self.interrupt_event.is_set(): time.sleep(0.5) self.pubSix_Arm(self.init_joints) # Robotic arm retracted return res
After the grasping is complete, the KCF_follow node will publish a signal on the largemodel_arm_done topic with the content "grasp_obj_done", which sets the grasp_obj_future object in the largemodel_arm_done_callback callback function.
xxxxxxxxxx def action_feedback_callback(self, msg:String): ''' 外部动作反馈回调函数 / External action feedback callback function ''' if msg.data =="follow_line_finish": if not self.follow_line_clear_future.done(): self.follow_line_clear_future.set_result(msg) elif msg.data =="road_net_nav_succeeded": if not self.road_net_nav_future.done(): self.road_net_nav_future.set_result(msg) elif msg.data =="road_net_nav_failed": if not self.road_net_nav_future.done(): self.road_net_nav_future.set_result(msg) if msg.data in ["apriltag_sort_done", "apriltag_sort_failed"]: if not self.apriltag_sort_future.done(): self.apriltag_sort_future.set_result(msg) elif msg.data in ["apriltag_remove_higher_done","apriltag_remove_higher_failed"]: if not self.apriltag_remove_higher_future.done(): self.apriltag_remove_higher_future.set_result(msg) elif msg.data == "grasp_obj_done": if not self.grasp_obj_future.done(): self.grasp_obj_future.set_result(msg) elif msg.data == "color_remove_higher_done": if not self.color_remove_higher_future.done(): self.color_remove_higher_future.set_result(msg) elif msg.data == "follow_line_clear_future_done": if not self.follow_line_clear_future.done(): self.follow_line_clear_future.set_result(msg)
4.2 Case Study 2
- The
set_cmdvelfunction controls the robot's base movement by publishing thecmd_velvelocity topic.
xxxxxxxxxx def set_cmdvel(self, linear_x:str, linear_y:str, angular_z:str, duration:str)->None: ''' 发布cmd_vel速度指令 / Publish cmd_vel velocity command ''' linear_x = float(linear_x) linear_y = float(linear_y) angular_z = float(angular_z) duration = float(duration) twist = Twist() twist.linear.x = linear_x twist.linear.y = linear_y twist.angular.z = angular_z self._execute_action(twist, durationtime=duration) self.stop() return True
The putdown method is used to make the robotic arm put down the object it is holding.
xxxxxxxxxx def putdown(self): self.pubSix_Arm(self.putsown_joints) # Deployment of robotic arm time.sleep(4) self.pubSingle_Arm(6, 30, 1000) #The robotic arm opens its gripper and releases the object. time.sleep(3) self.pubSix_Arm(self.init_joints) # Robotic arm retracted return True
4.3 Case Study 3
- The
apriltag_remove_highermethod starts the externalgrasp_desktop_removeandapriltag_remove_highernodes via a subprocess. This is an example from the robotic arm chapter demonstrating the removal of machine code at a specified height.
xxxxxxxxxx def apriltag_remove_higher(self, target_high): '''Remove machine code at the specified height.''' def __reset_apriltag_remove_higher(): kill_process_tree(self.apriltag_remove_higher_process_1.pid) kill_process_tree(self.apriltag_remove_higher_process_2.pid) self.apriltag_remove_higher_future = Future() target_highf = float(target_high) / 100 cmd_1=['ros2', 'run', 'largemodel_arm', 'grasp_desktop_remove'] cmd_2=['ros2', 'run', 'largemodel_arm', 'apriltag_remove_higher','--ros-args','-p',f'target_high:={target_highf:.2f}'] self.apriltag_remove_higher_process_1=subprocess.Popen(cmd_1) self.apriltag_remove_higher_process_2=subprocess.Popen(cmd_2) while not self.apriltag_remove_higher_future.done(): if self.interrupt_event.is_set(): __reset_apriltag_remove_higher() self.stop() self.pubSix_Arm(self.init_joints) return None time.sleep(0.1) result = self.apriltag_remove_higher_future.result() if not self.interrupt_event.is_set(): if result.data == "apriltag_remove_higher_done": res=True elif result.data == "apriltag_remove_higher_failed": res= False __reset_apriltag_remove_higher() self.pubSix_Arm(self.init_joints) return res