Welcome to ROSMASTER M3 PRO repository
3.Lidar obstacle avoidance
Lidar obstacle avoidance
1. Content Description
This section describes how the program combines chassis control with fused radar data to detect obstacles in real time as the car moves forward and steer the car to avoid them based on their locations.
This section requires entering commands in the terminal. The terminal you open depends on your motherboard type. This section uses the Raspberry Pi 5 as an example. For Raspberry Pi and Jetson-Nano motherboards, you'll need to open a terminal and enter commands to enter a Docker container. Once inside the Docker container, enter the commands mentioned in this section in the terminal. For instructions on entering a Docker container, refer to the product tutorial [Robot Configuration and Operation Guide] - [Enter the Docker (Jetson-Nano and Raspberry Pi 5 users, see here).
Simply open the terminal on the Orin motherboard and enter the commands mentioned in this section.
2. Program startup
First, open the terminal and enter the following command to start the radar fusion and radar filtering programs.
ros2 launch yahboom_M3Pro_laser laser_driver.launch.pyNext, you can refer to this product tutorial [5. Chassis Control] - [2. Handle Control] to start the handle control to control the car conveniently. Press the R2 button on the handle to cancel and start the radar obstacle avoidance gameplay. If the handle control is not started, it will not affect the operation of this program. Enter the following command in the terminal to start the radar obstacle avoidance program,
xxxxxxxxxxros2 run yahboom_M3Pro_laser laser_AvoidanceAfter startup, as shown in the figure below, the radar will print out the situation of detecting surrounding obstacles and control the movement of the car.
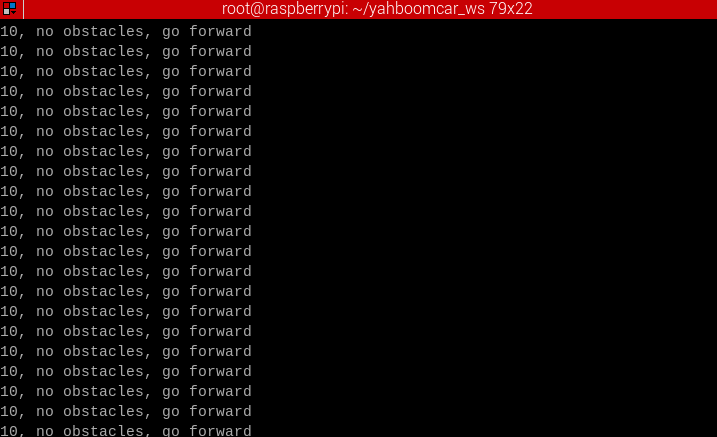
If there is no obstacle, the car will go straight forward; if there is an obstacle on the left, the car will turn right to avoid the obstacle and continue to move forward; if there is an obstacle on the right, the car will turn left to avoid the obstacle and continue to move forward.
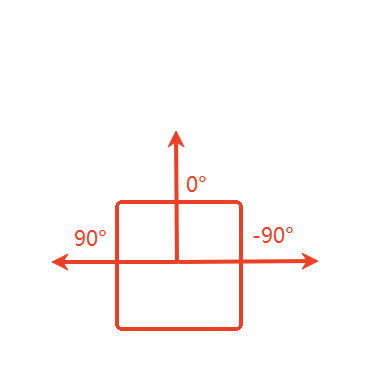
The obstacle avoidance detection distance set by the program is 0.825 meters, and the radar detection angle is 45 degrees to the left and right of 0 degrees. After the dual radar fusion, the radar data at 0 degrees is the front of the vehicle, the left half of the vehicle is 0 degrees-180 degrees, and the right half of the vehicle is -180 degrees-0 degrees. The radar starts from 0 degrees and rotates counterclockwise, as shown in the figure below.
3. Core code analysis
Program code path:
Raspberry Pi and Jetson-Nano board
The program code is in the running docker. The path in docker is /root/yahboomcar_ws/src/yahboom_M3Pro_laser/yahboom_M3Pro_laser/laser_Avoidance.py
Orin Motherboard
The program code path is /home/jetson/yahboomcar_ws/src/yahboom_M3Pro_laser/yahboom_M3Pro_laser/laser_Avoidance.py
Import the necessary library files,
xxxxxxxxxx#ros libimport rclpyfrom rclpy.node import Nodefrom geometry_msgs.msg import Twistfrom sensor_msgs.msg import LaserScan#commom libimport mathimport numpy as npimport timefrom time import sleepfrom yahboom_M3Pro_laser.common import *import osThe program initializes and creates publishers and subscribers,
xxxxxxxxxxdef __init__(self,name): super().__init__(name) #create a sub #Create a subscriber to subscribe to the fused radar topic message self.sub_laser=self.create_subscription(LaserScan,"/scan",self.registerScan,1) #Create a subscriber to subscribe to the handle remote control topic message self.sub_JoyState = self.create_subscription(Bool,'/JoyState',self.JoyStateCallback,1) #create a pub #Create a publisher to publish speed topic message self.pub_vel = self.create_publisher(Twist,'/cmd_vel',1) #declareparam #Forward linear speed self.declare_parameter("linear",0.3) self.linear = self.get_parameter('linear').get_parameter_value().double_value # Rotational angular velocity self.declare_parameter("angular",1.0) self.angular = self.get_parameter('angular').get_parameter_value().double_value # Radar detection angle self.declare_parameter("LaserAngle",45.0) self.LaserAngle = self.get_parameter('LaserAngle').get_parameter_value().double_value #The detection distance of the obstacle. If it is less than this value, it means there is an obstacle. self.declare_parameter("ResponseDist",0.55) self.ResponseDist = self.get_parameter('ResponseDist').get_parameter_value().double_value #The right obstacle count value self.Right_warning = 0 #Left obstacle count value self.Left_warning = 0 #Count of obstacles ahead self.front_warning = 0 #Handle control flag, the value is True means the handle controls the car, you need to press the R2 key on the handle to take handle control or enable handle control self.Joy_active = False #Obstacle counting threshold. Exceeding this value indicates that there is an obstacle ahead within the detection range. self.conut = 10registerScan radar topic callback function,
xxxxxxxxxxdef registerScan(self, scan_data): if not isinstance(scan_data, LaserScan): return ranges = np.array(scan_data.ranges) self.Right_warning = 0 self.Left_warning = 0 self.front_warning = 0 for i in range(len(ranges)): #Convert the radians in the radar topic data into degrees angle = (scan_data.angle_min + scan_data.angle_increment * i) * RAD2DEG #If it is greater than 0 degrees and less than 45 degrees or less than -45 degrees and greater than 0 degrees, and the distance corresponding to the angle is less than 1.5 times the set distance, it is considered that there is an obstacle ahead. if abs(angle) < self.LaserAngle and ranges[i] !=0.0: if ranges[i] <= self.ResponseDist*1.5: self.front_warning += 1 #If it is greater than 45 degrees and less than 90 degrees, and the distance corresponding to the angle is less than 1.5 times the set distance, it is considered that there is an obstacle on the left. if angle < ( 90 - self . LaserAngle ) < 90 and angle > 0 and ranges [ i ] ! = 0.0 : if ranges [ i ] < = self . ResponseDist * 1.5 : self . Left_warning += 1 #If it is greater than -90 degrees and less than -45 degrees, and the distance corresponding to the angle is less than 1.5 times the set distance, it is considered that there is an obstacle on the right. if angle < (90 - self.LaserAngle) < 90 and angle>0 and ranges[i] !=0.0: if ranges[i] <= self.ResponseDist*1.5: self.Left_warning += 1 #If self.Joy_active is True, publish the parking speed and exit this callback function if self.Joy_active: self.pub_vel.publish(Twist()) return twist = Twist() #Based on the obstacle count values in front, left, and right, determine which direction has obstacles and publish the speed topic based on the judgment results. if self.front_warning > self.conut and self.Left_warning > self.conut and self.Right_warning > self.conut: print ('1, there are obstacles in the left and right, turn right') twist.linear.x = self.linear twist.angular.z = -self.angular self.pub_vel.publish(twist) sleep(0.2) elif self.front_warning > self.conut and self.Left_warning <= self.conut and self.Right_warning > self.conut: print ('2, there is an obstacle in the middle right, turn left') twist.linear.x = 0.0 twist.angular.z = self.angular self.pub_vel.publish(twist) sleep(0.2) if self.Left_warning > self.conut and self.Right_warning <= self.conut: twist.linear.x = 0.0 twist.angular.z = -self.angular self.pub_vel.publish(twist) sleep(0.5) elif self.front_warning > self.conut and self.Left_warning > self.conut and self.Right_warning <= self.conut: print ('4. There is an obstacle in the middle left, turn right') twist.linear.x = 0.0 twist.angular.z = -self.angular self.pub_vel.publish(twist) sleep(0.2) if self.Left_warning <= self.conut and self.Right_warning > self.conut: twist.linear.x = 0.0 twist.angular.z = self.angular self.pub_vel.publish(twist) sleep(0.5) elif self.front_warning > self.conut and self.Left_warning < self.conut and self.Right_warning < self.conut: print ('6, there is an obstacle in the middle, turn left') twist.linear.x = 0.0 twist.angular.z = self.angular self.pub_vel.publish(twist) sleep(0.2) elif self.front_warning < self.conut and self.Left_warning > self.conut and self.Right_warning > self.conut: print ('7. There are obstacles on the left and right, turn right') twist.linear.x = 0.0 twist.angular.z = -self.angular self.pub_vel.publish(twist) sleep(0.4) elif self.front_warning < self.conut and self.Left_warning > self.conut and self.Right_warning <= self.conut: print ('8, there is an obstacle on the left, turn right') twist.linear.x = 0.0 twist.angular.z = -self.angular self.pub_vel.publish(twist) sleep(0.2) elif self.front_warning < self.conut and self.Left_warning <= self.conut and self.Right_warning > self.conut: print ('9, there is an obstacle on the right, turn left') twist.linear.x = 0.0 twist.angular.z = self.angular self.pub_vel.publish(twist) sleep(0.2) elif self.front_warning <= self.conut and self.Left_warning <= self.conut and self.Right_warning <= self.conut: print ('10, no obstacles, go forward') twist.linear.x = self.linear twist.angular.z = 0.0 self.pub_vel.publish(twist)