Welcome to DOGZILLA-Lite repository
5. Self-balancing mode
Self-balancing mode
1. Purpose
Understanding the robot dog's self-stabilization mode
2. Experimental path source code
Enter the robot dog system, end the robot dog program, enter "ip (ip is the robot dog's ip): 8888" in the browser, and enter the password "yahboom"

Then log in and go to cd ~/DOGZILLA_Lite_class/3.Dog Base Control/05.Stabilize Mode and run Stabilize_Mode.ipynb .
3. Experimental Phenomenon
After running the source code, choose whether to enable the self-balancing mode.
Balanced mode effects:
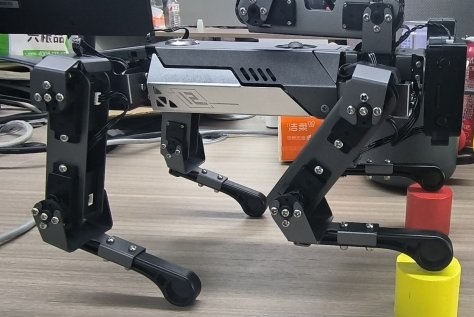
Turn off the Balance Mode effect:
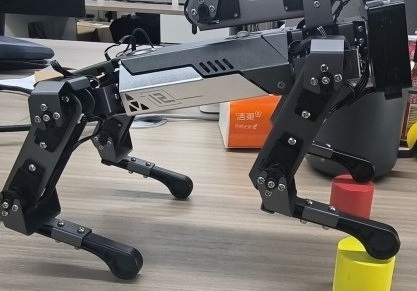
4. Main source code analysis
- dog.imu(mode)
- Incoming parameters: 0-turn off the self-stabilization mode 1-turn on the self-stabilization mode