yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Muto RS Robot📖
01.Introduction to Muto Robot
  • 1.Accessories introduction
  • 2.Precautions for battery
  • 3.FAQ
  • 4.MutoRS Study Guide
  • 5.Quick Start Guide
02.Assembly and write system
  • 1.Raspberry Pi write system
  • 2.Assembly video
03.Remote control course
  • 1.Open and Close APP Control Program
  • 2.Mobile APP Remote Control
  • 3.USB Wireless Controller Remote Control
  • 4.Web Host Computer Remote Control
04.Remote login operation
  • 1.SSH and VNC remote login
  • 2.Jupyter Lab login and running example code
05.AI Large Model Basicsnew
  • 1.AI Large Model Types and Principles
  • 2.RAG Retrieval Enhancement and Model Training Samples
  • 3.Embodied Intelligent Robot System Architecture
  • 4.Embodied Intelligent Functions Core Source Code
06.AI Large Model Developmentnew
  • 1.Register a model service provider account
  • 2.Configure API-KEY
  • 3.Introduction to Dify
  • 4.Dify Basic function
  • 5.AI large model development - Chatbot
  • 6.Deploy the RAG knowledge base
  • 7.RAG knowledge base + Chatbot
  • 8.AI agent workflow
  • 9.Custom wake-up response
  • 10.Core module testing tools
07.AI Large Model (Text Version)new
  • 0.MutoRS Model Setup & Details
  • 1.Semantic Understanding, Instruction Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding + Depth Camera Distance Q&A
  • 4.Multimodal Visual Understanding + Visual Line Following
  • 5.Multimodal Visual Understanding + Visual Following
  • 6.Multimodal Visual Understanding + SLAM Navigation
  • 7.Multimodal Visual Understanding + SLAM Navigation + Visual Line Following
  • 8.Intention Estimation + Multimodal Visual Understanding + SLAM Navigation + Visual Functions
08.AI Large Model (Voice Version)new
  • 0.MutoRS Model Setup & Details
  • 1.Semantic Understanding, Instruction Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding + Depth Camera Distance Q&A
  • 4.Multimodal Visual Understanding + Visual Line Following
  • 5.Multimodal Visual Understanding + Visual Following
  • 6.Multimodal Visual Understanding + SLAM Navigation
  • 7.Multimodal Visual Understanding + SLAM Navigation + Visual Line Following
  • 8.Intention Estimation + Multimodal Visual Understanding + SLAM Navigation + Visual Functions
09.AI Large Model (Fun Applications)new
  • 1.Versatile performer
  • 2.Action Imitation
  • 3.Problem Solving Expert
  • 4.Exploring Unfamiliar Environments
10.Robot basic course
  • 1)Control buzzer
  • 2)Control PWM servo
  • 3)Control bus servo
  • 4)Robot forward and backward
  • 5)Robot move left and right
  • 6)Robot rotate left and right
  • 7)Control height
  • 8)Control head
  • 9)Action group performance
  • 10)Read data
  • 11)Host computer control
  • 12)Camera driver
11.Voice control coursenew
  • 1.Control Muto motion
  • 2.Control Muto tracking
  • 3.Control Muto color recognition
  • 4.Control Muto color tracking
  • 5.Control multi-point navigation
12.AI vision course
  • 0)Color HSV Calibration
  • 1)Color recognition
  • 2)Color following
  • 3)Color recognition action group
  • 4)Face detection
  • 5)QR code recognition
  • 6)QR code instructions
  • 7)Visual line following
  • 8)Motion learning
  • 9)Synchronous action teaching
13.Mediapipe course
  • 1)Hand detection
  • 2)Attitude detection
  • 3)Overall inspection
  • 4)Face detection
  • 5)Face recognition
  • 6)Face effects
  • 7)Face detection
  • 8)3D object recognition
  • 9)Brush
  • 10)Finger control
  • 11)Gesture recognition
14.Depth camera course
  • 1)Depth camera use
  • 2)Internal reference calibration
  • 3)Web page real-time monitoring
  • 4)ROS+opencv application
  • 5)QR code creation and recognition
  • 6)AR vision
  • 7)Tracking
  • 8)Obstacle recognition
  • 9)Color tracking
  • 10)KCF object tracking
  • 11)RTAB-Map 3D mapping navigation
15.Lidar course
  • 1)About lidar
  • 2)Lidar obstacle avoidance
  • 3)Lidar tracking
  • 4)Lidar guard
  • 5)Patrol
  • 6)SLAM overview
  • 7)ROS2_Gmapping mapping algorithm
  • 8)ROS2_Cartographer mapping algorithm
  • 9)About ROS2 Navigation
  • 10)ROS2 navigation and avoid
  • 11) APP mapping
  • 12)APP navigation
16.Road network navigationnew
  • 1.Road network planning and navigation environment deployment
  • 2.Constructing pose maps
  • 3.Road network annotation
  • 4.Inter-road network planning and navigation
  • 5.Road network navigation under arbitrary poses
  • 6.Path replanning
17.Multi-machine control course
  • 1)Multi-vehicle control
  • 2)Multi-vehicle navigation
18.Robot chassis control
  • 1)Hexapod gait and kinematics
  • 2)Robot information release
  • 3)Robot control
  • 4)URDF model
19.Raspberry Pi course
  • 1)Python usage
  • 2)Use APT to install Python packages
  • 3)Python virtual environment
  • 4)GPIO Zero
  • 5)Pin output high and low levels
  • 6)Pin reads high and low levels
  • 7)Pin output PWM
  • 8)Serial communication
  • 9)I2C communication
20.OpenCV course
  • 1)Introduction to Open Source CV
  • 2)Image reading and display
  • 3)Picture writing
  • 4)Image Quality
  • 5)Pixel operations
  • 6)Image zoom
  • 7)Picture cut
  • 8)Picture pan
  • 9)Picture mirroring
  • 10)Affine transformation
  • 11)Picture rotation
  • 12)perspective transformation
  • 13)Grayscale processing
  • 14)Binary image
  • 15)Edge green detection
  • 16)Line segment drawing
  • 17)Rectangular circle drawing
  • 18)Text and picture drawing
21.Docker course
  • 1)Overview and installation
  • 2)Common commands
  • 3)Deeply understand and publish images
  • 4)Hardware interaction and data processing
  • 5)Enter docker container
  • 6)Robot development environment construction
  • 7)Update docker images
22.ROS2 basic course
  • 1) Introduction to ROS2
  • 2)ROS2 install Humble
  • 3)ROS2 development environment
  • 4)ROS2 workspace
  • 5)ROS2 function package
  • 6)ROS2 node
  • 7)ROS2 topic communication
  • 8)ROS2 service communication
  • 9)ROS2 action communication
  • 10)ROS2 custom interface message
  • 11)ROS2 parameter service case
  • 12)ROS2 meta-function package
  • 13)ROS2 distributed communication
  • 14)ROS2 DDS
  • 15)ROS2 time related API
  • 16)ROS2 common command tools
  • 17)ROS2 rviz2 use
  • 18)ROS2 rqt toolbox
  • 19)ROS2 Launch startup file configuration
  • 20)ROS2 recording and playback tool
  • 21)ROS2 URDF model
  • 22)ROS2 Gazebo simulation platform
  • 23)ROS2 TF2 coordinate transformation
23.Linux basic course
  • 1)Introduction to Linux system
  • 2)Ubuntu file system
  • 3)Ubuntu common commands
  • 4)Ubuntu common editors
  • 5)Ubuntu software operation commands
  • 6)Virtual machine installation
  • 7)SSH remote control
  • 8)VNC remote control
  • 9)Driver library and communication
  • 10)Static IP and hotspot mode
  • 11)Bind device ID
  • 12)Capacity expansion and resource allocation
  • 13)Back up system image
  • 14)Update system software sources
  • 15)Set root user password
  • 16)sudo free password
  • 17)Connect to WiFi network
  • 18)View system version
  • 19)Customized service management
  • 20.Back up system image
24.Mainboard Large Model Course
Offline large model (Text Interaction)
  • 0. AI large model image description
  • 1. Deployment of large AI model environments
  • 2. Installation of large model dialogue platform
  • 3. Meta AI Llama 3.2 model
  • 4. Alibaba Cloud Qwen3 Model
  • 5. Microsoft Phi-4-mini model
  • 6. DeepSeek DeepSeek-R1 model
  • 7. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 8. Google Gemma3 Visual Multimodal Large Model
  • 9. Llava Visual Multimodal Large Model
  • 10. MiniCPM-V Visual Multimodal Large Model
  • 11. Multimodal Visual Understanding Applications
  • 12. Multimodal Text-Based Image Application
  • 13. Multimodal Video Analysis Application
  • 14. Multimodal visual positioning applications
  • 15. Multimodal table scanning application
  • 16. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
Online large model (text interaction)
  • 1.OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal Visual Understanding Applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (voice interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
Download
  • RemoteCtrl_APP(iOS/Android)
  • Mapping_APP(iOS_Android)
  • SystemFile_For_RPi5
  • SystemFile_Jetson
  • SystemFile_RPi
  • Code
  • VM File
  • Hardware Info
  • Instruction Manual
  • Jetson_Boot_USB.tar.gz
  • ROS2_Basic_VM
Download ZIP

Welcome to Muto RS Robot repository

4)Hardware interaction and data processing

4.Hardware interaction and data processing


4.Hardware interaction and data processing4.1. Hardware mounting (port binding)4.2. Display of GUI in docker4.3.1. Use cp naming4.3.1.1. Copy files from the container to the host4.3.1.2. Copy files from the host to the container4.3.2. Use data volume4.3.2.1.Overview of data volumes4.3.2.2. Data volume usage

4.1. Hardware mounting (port binding)

  1. Establish udev rules (/etc/udev/rules.d/) in the host machine, see chapter [23.Linux basic course ---- 12.Bind device ID]
  2. Then when opening the container, mount the devices with the rules set into the docker container through parameters such as --device=/dev/myserial --device=/dev/rplidar and so on.
docker run -it --device=/dev/myserial --device=/dev/rplidar ubuntu:latest /bin/bash
  1. The device can be found in the docker container
xxxxxxxxxx
jetson@ubuntu:~$ docker images
REPOSITORY                   TAG       IMAGE ID       CREATED             SIZE
ubuntu                       1.0       78ca7be949b6   About an hour ago   69.2MB
pengan88/ubuntu              1.0       78ca7be949b6   About an hour ago   69.2MB
yahboomtechnology/ros-humble   3.4.0     49581aa78b6b   6 hours ago         24.3GB
yahboomtechnology/ros-humble   3.3.9     cefb5ac2ca02   4 days ago          20.5GB
yahboomtechnology/ros-humble   3.3.8     49996806c64a   4 days ago          20.5GB
yahboomtechnology/ros-humble   3.3.7     8989b8860d17   5 days ago          17.1GB
yahboomtechnology/ros-humble   3.3.6     326531363d6e   5 days ago          16.1GB
mysql                        latest    5371f8c3b63e   6 days ago          592MB
ubuntu                       latest    bab8ce5c00ca   6 weeks ago         69.2MB
hello-world                  latest    46331d942d63   13 months ago       9.14kB
jetson@ubuntu:~$ ll /dev | grep ttyUSB*
lrwxrwxrwx   1 root   root           7 Apr 23 18:07 myserial -> ttyUSB0
lrwxrwxrwx   1 root   root           7 Apr 23 18:07 rplidar -> ttyUSB1
crwxrwxrwx   1 root   dialout 188,   0 Apr 23 18:07 ttyUSB0
crwxrwxrwx   1 root   dialout 188,   1 Apr 23 18:07 ttyUSB1
jetson@ubuntu:~$ docker run -it   --device=/dev/myserial --device=/dev/rplidar ubuntu:latest  /bin/bash
root@03522257ba30:/# ls /dev   # There are already myserial and rplidar in docker
console  fd  full  mqueue  myserial  null  ptmx  pts  random  rplidar  shm  stderr  stdin  stdout  tty  urandom  zero


4.2. Display of GUI in docker

  1. Install on the host machine:
xxxxxxxxxx
sudo apt-get install tigervnc-standalone-server tigervnc-viewer
sudo apt-get install x11-xserver-utils
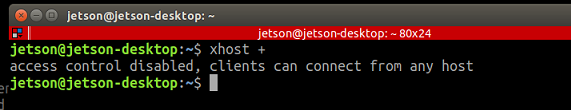
  1. Execute in the host machine: xhost +

After the following picture is displayed normally, perform 3 steps:
0

  1. Execute the command in the host machine to enter the container:
xxxxxxxxxx
docker run -it \                                    # Run the docker image interactively
--env="DISPLAY" \                                   # Turn on the display GUI interface
--env="QT_X11_NO_MITSHM=1" \                        # Use X11 port 1 for display
-v /tmp/.X11-unix:/tmp/.X11-unix \                  # Map the service node directory
yahboomtechnology/ros-foxy:3.3.9                    # Image name to be started
/bin/bash                                           # Execute the /bin/bash command within the container
  1. Test
xxxxxxxxxx
Execute in container:rviz2


4.3.1. Use cp naming

4.3.1.1. Copy files from the container to the host

​x
# command
docker cp container id: path within the container destination host path
​
# test
# Execute within the container and create a file test
jetson@ubuntu:~$ docker ps -a
CONTAINER ID   IMAGE           COMMAND       CREATED       STATUS                   PORTS     NAMES
c54bf9efae47   ubuntu:latest   "/bin/bash"   2 hours ago   Up 9 minutes                       funny_hugle
3b9c01839579   hello-world     "/hello"      3 hours ago   Exited (0) 3 hours ago             jovial_brown
jetson@ubuntu:~$ docker attach c5
root@c54bf9efae47:/# ls
bin  boot  dev  etc  home  lib  media  mnt  opt  proc  root  run  sbin  srv  sys  tmp  usr  var
root@c54bf9efae47:/# cd
root@c54bf9efae47:~# ls
root@c54bf9efae47:~# touch test.txt
root@c54bf9efae47:~# ls
test.txt
root@c54bf9efae47:~# pwd
/root 
root@c54bf9efae47:/# read escape sequence    #Press ctrl+P+Q to exit the container without stopping.
jetson@ubuntu:~$ docker cp c54bf9efae47:/root/test.txt  ~/
jetson@ubuntu:~$ ls      # The test.txt file has been copied in
Desktop  Documents  Downloads  fishros  Music  openvino  Pictures  Public  rootOnNVMe  run_docker.sh  sensors  snap  temp  Templates  test.txt  Videos


4.3.1.2. Copy files from the host to the container

xxxxxxxxxx
# command
docker cp Host file path container id: path within the container
​
#test
jetson@ubuntu:~$ docker ps -a
CONTAINER ID   IMAGE           COMMAND       CREATED       STATUS                   PORTS     NAMES
c54bf9efae47   ubuntu:latest   "/bin/bash"   2 hours ago   Up 5 minutes                       funny_hugle
3b9c01839579   hello-world     "/hello"      3 hours ago   Exited (0) 3 hours ago             jovial_brown
jetson@ubuntu:~$ ls
Desktop  Documents  Downloads  fishros  Music  openvino  Pictures  Public  rootOnNVMe  run_docker.sh  sensors  snap  temp  Templates  test.txt  Videos
jetson@ubuntu:~$ touch 11.txt
jetson@ubuntu:~$ ls
11.txt  Desktop  Documents  Downloads  fishros  Music  openvino  Pictures  Public  rootOnNVMe  run_docker.sh  sensors  snap  temp  Templates  test.txt  Videos
jetson@ubuntu:~$ docker cp 11.txt c54bf9efae47:/root/
jetson@ubuntu:~$ docker attach c5
root@c54bf9efae47:/# ls
bin  boot  dev  etc  home  lib  media  mnt  opt  proc  root  run  sbin  srv  sys  tmp  usr  var
root@c54bf9efae47:/# cd /root/
root@c54bf9efae47:~# ls     # 11.txt file has been copied in
11.txt  test.txt


4.3.2. Use data volume


4.3.2.1.Overview of data volumes

The application and running environment are packaged to form a container for operation. The operation can be accompanied by the container, but our requirements for data are that we hope to be persistent! It's like if you install a mysql and delete the container, it's equivalent to deleting the database and running away. This is definitely not okay! So we hope that it is possible to share data between containers. If the data generated by the docker container does not generate a new image through docker commit, so that the data is saved as part of the image, then when the container is deleted, the data will naturally be gone! This won't work!

In order to save data in docker we can use volumes! Let the data be mounted locally! This way the data will not be lost due to deletion of the container!

Features:

  1. Data volumes can share or reuse data between containers
  2. Changes in volumes can take effect directly
  3. Changes in the data volume will not be included in the mirror update
  4. The life cycle of the data volume continues until no container uses it.


4.3.2.2. Data volume usage

xxxxxxxxxx
# command
docker run -it -v Host absolute path directory: directory in the container image name
​
# test  
docker run -it -v /home/jetson/temp:/root/temp yahboomtechnology/ros-foxy:3.4.0 /bin/bash
​
The /home/jetson/temp directory in the host and the /root/temp directory in the container can share data, or they can be changed to other directories you want to share.


Deeply understand and publish images
Enter docker container

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文