yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Muto RS Robot📖
01.Introduction to Muto Robot
  • 1.Accessories introduction
  • 2.Precautions for battery
  • 3.FAQ
  • 4.MutoRS Study Guide
  • 5.Quick Start Guide
02.Assembly and write system
  • 1.Raspberry Pi write system
  • 2.Assembly video
03.Remote control course
  • 1.Open and Close APP Control Program
  • 2.Mobile APP Remote Control
  • 3.USB Wireless Controller Remote Control
  • 4.Web Host Computer Remote Control
04.Remote login operation
  • 1.SSH and VNC remote login
  • 2.Jupyter Lab login and running example code
05.AI Large Model Basicsnew
  • 1.AI Large Model Types and Principles
  • 2.RAG Retrieval Enhancement and Model Training Samples
  • 3.Embodied Intelligent Robot System Architecture
  • 4.Embodied Intelligent Functions Core Source Code
06.AI Large Model Developmentnew
  • 1.Register a model service provider account
  • 2.Configure API-KEY
  • 3.Introduction to Dify
  • 4.Dify Basic function
  • 5.AI large model development - Chatbot
  • 6.Deploy the RAG knowledge base
  • 7.RAG knowledge base + Chatbot
  • 8.AI agent workflow
  • 9.Custom wake-up response
  • 10.Core module testing tools
07.AI Large Model (Text Version)new
  • 0.MutoRS Model Setup & Details
  • 1.Semantic Understanding, Instruction Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding + Depth Camera Distance Q&A
  • 4.Multimodal Visual Understanding + Visual Line Following
  • 5.Multimodal Visual Understanding + Visual Following
  • 6.Multimodal Visual Understanding + SLAM Navigation
  • 7.Multimodal Visual Understanding + SLAM Navigation + Visual Line Following
  • 8.Intention Estimation + Multimodal Visual Understanding + SLAM Navigation + Visual Functions
08.AI Large Model (Voice Version)new
  • 0.MutoRS Model Setup & Details
  • 1.Semantic Understanding, Instruction Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding + Depth Camera Distance Q&A
  • 4.Multimodal Visual Understanding + Visual Line Following
  • 5.Multimodal Visual Understanding + Visual Following
  • 6.Multimodal Visual Understanding + SLAM Navigation
  • 7.Multimodal Visual Understanding + SLAM Navigation + Visual Line Following
  • 8.Intention Estimation + Multimodal Visual Understanding + SLAM Navigation + Visual Functions
09.AI Large Model (Fun Applications)new
  • 1.Versatile performer
  • 2.Action Imitation
  • 3.Problem Solving Expert
  • 4.Exploring Unfamiliar Environments
10.Robot basic course
  • 1)Control buzzer
  • 2)Control PWM servo
  • 3)Control bus servo
  • 4)Robot forward and backward
  • 5)Robot move left and right
  • 6)Robot rotate left and right
  • 7)Control height
  • 8)Control head
  • 9)Action group performance
  • 10)Read data
  • 11)Host computer control
  • 12)Camera driver
11.Voice control coursenew
  • 1.Control Muto motion
  • 2.Control Muto tracking
  • 3.Control Muto color recognition
  • 4.Control Muto color tracking
  • 5.Control multi-point navigation
12.AI vision course
  • 0)Color HSV Calibration
  • 1)Color recognition
  • 2)Color following
  • 3)Color recognition action group
  • 4)Face detection
  • 5)QR code recognition
  • 6)QR code instructions
  • 7)Visual line following
  • 8)Motion learning
  • 9)Synchronous action teaching
13.Mediapipe course
  • 1)Hand detection
  • 2)Attitude detection
  • 3)Overall inspection
  • 4)Face detection
  • 5)Face recognition
  • 6)Face effects
  • 7)Face detection
  • 8)3D object recognition
  • 9)Brush
  • 10)Finger control
  • 11)Gesture recognition
14.Depth camera course
  • 1)Depth camera use
  • 2)Internal reference calibration
  • 3)Web page real-time monitoring
  • 4)ROS+opencv application
  • 5)QR code creation and recognition
  • 6)AR vision
  • 7)Tracking
  • 8)Obstacle recognition
  • 9)Color tracking
  • 10)KCF object tracking
  • 11)RTAB-Map 3D mapping navigation
15.Lidar course
  • 1)About lidar
  • 2)Lidar obstacle avoidance
  • 3)Lidar tracking
  • 4)Lidar guard
  • 5)Patrol
  • 6)SLAM overview
  • 7)ROS2_Gmapping mapping algorithm
  • 8)ROS2_Cartographer mapping algorithm
  • 9)About ROS2 Navigation
  • 10)ROS2 navigation and avoid
  • 11) APP mapping
  • 12)APP navigation
16.Road network navigationnew
  • 1.Road network planning and navigation environment deployment
  • 2.Constructing pose maps
  • 3.Road network annotation
  • 4.Inter-road network planning and navigation
  • 5.Road network navigation under arbitrary poses
  • 6.Path replanning
17.Multi-machine control course
  • 1)Multi-vehicle control
  • 2)Multi-vehicle navigation
18.Robot chassis control
  • 1)Hexapod gait and kinematics
  • 2)Robot information release
  • 3)Robot control
  • 4)URDF model
19.Raspberry Pi course
  • 1)Python usage
  • 2)Use APT to install Python packages
  • 3)Python virtual environment
  • 4)GPIO Zero
  • 5)Pin output high and low levels
  • 6)Pin reads high and low levels
  • 7)Pin output PWM
  • 8)Serial communication
  • 9)I2C communication
20.OpenCV course
  • 1)Introduction to Open Source CV
  • 2)Image reading and display
  • 3)Picture writing
  • 4)Image Quality
  • 5)Pixel operations
  • 6)Image zoom
  • 7)Picture cut
  • 8)Picture pan
  • 9)Picture mirroring
  • 10)Affine transformation
  • 11)Picture rotation
  • 12)perspective transformation
  • 13)Grayscale processing
  • 14)Binary image
  • 15)Edge green detection
  • 16)Line segment drawing
  • 17)Rectangular circle drawing
  • 18)Text and picture drawing
21.Docker course
  • 1)Overview and installation
  • 2)Common commands
  • 3)Deeply understand and publish images
  • 4)Hardware interaction and data processing
  • 5)Enter docker container
  • 6)Robot development environment construction
  • 7)Update docker images
22.ROS2 basic course
  • 1) Introduction to ROS2
  • 2)ROS2 install Humble
  • 3)ROS2 development environment
  • 4)ROS2 workspace
  • 5)ROS2 function package
  • 6)ROS2 node
  • 7)ROS2 topic communication
  • 8)ROS2 service communication
  • 9)ROS2 action communication
  • 10)ROS2 custom interface message
  • 11)ROS2 parameter service case
  • 12)ROS2 meta-function package
  • 13)ROS2 distributed communication
  • 14)ROS2 DDS
  • 15)ROS2 time related API
  • 16)ROS2 common command tools
  • 17)ROS2 rviz2 use
  • 18)ROS2 rqt toolbox
  • 19)ROS2 Launch startup file configuration
  • 20)ROS2 recording and playback tool
  • 21)ROS2 URDF model
  • 22)ROS2 Gazebo simulation platform
  • 23)ROS2 TF2 coordinate transformation
23.Linux basic course
  • 1)Introduction to Linux system
  • 2)Ubuntu file system
  • 3)Ubuntu common commands
  • 4)Ubuntu common editors
  • 5)Ubuntu software operation commands
  • 6)Virtual machine installation
  • 7)SSH remote control
  • 8)VNC remote control
  • 9)Driver library and communication
  • 10)Static IP and hotspot mode
  • 11)Bind device ID
  • 12)Capacity expansion and resource allocation
  • 13)Back up system image
  • 14)Update system software sources
  • 15)Set root user password
  • 16)sudo free password
  • 17)Connect to WiFi network
  • 18)View system version
  • 19)Customized service management
  • 20.Back up system image
24.Mainboard Large Model Course
Offline large model (Text Interaction)
  • 0. AI large model image description
  • 1. Deployment of large AI model environments
  • 2. Installation of large model dialogue platform
  • 3. Meta AI Llama 3.2 model
  • 4. Alibaba Cloud Qwen3 Model
  • 5. Microsoft Phi-4-mini model
  • 6. DeepSeek DeepSeek-R1 model
  • 7. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 8. Google Gemma3 Visual Multimodal Large Model
  • 9. Llava Visual Multimodal Large Model
  • 10. MiniCPM-V Visual Multimodal Large Model
  • 11. Multimodal Visual Understanding Applications
  • 12. Multimodal Text-Based Image Application
  • 13. Multimodal Video Analysis Application
  • 14. Multimodal visual positioning applications
  • 15. Multimodal table scanning application
  • 16. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
Online large model (text interaction)
  • 1.OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal Visual Understanding Applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (voice interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
Download
  • RemoteCtrl_APP(iOS/Android)
  • Mapping_APP(iOS_Android)
  • SystemFile_For_RPi5
  • SystemFile_Jetson
  • SystemFile_RPi
  • Code
  • VM File
  • Hardware Info
  • Instruction Manual
  • Jetson_Boot_USB.tar.gz
  • ROS2_Basic_VM
Download ZIP

Welcome to Muto RS Robot repository

13)ROS2 distributed communication

13. ROS2 Distributed Communication

1. Concept

Multi-machine communication, or distributed communication, refers to a communication strategy that enables data exchange between different hosts over a network.

ROS2 itself is a distributed communication framework that facilitates communication between different devices. The middleware underlying ROS2 is DDS. When running on the same network, distributed communication is achieved through the DDS domain ID mechanism (ROS_DOMAIN_ID). The general process is as follows: Before starting a node, you can set the domain ID value. Nodes with the same domain ID can freely discover and communicate with each other. Conversely, if the domain ID values ​​are different, this communication is impossible. By default, all nodes start with domain ID 0. In other words, as long as they are on the same network, distributed communication can be achieved between different nodes on different ROS2 devices without any configuration.

Distributed communication has a wide range of application scenarios, including unmanned vehicle platooning, drone platooning, and remote control. These data exchanges all rely on distributed communication.

2. Implementation

2.1. Default Implementation

Distributed communication is achieved by simply placing the master and slave devices (you can have multiple devices) on the same network. For example, the master and slave devices can be connected to the same WiFi or router.

In Windows, setting the virtual machine to "bridge mode" will place them on the same network as the host.

Test:

Here, we assume we have two hosts, A and B. These can be any network-capable host, such as a virtual machine, Raspberry Pi, Jetson, x86/ARM host, or card motherboard. They only need to have the same version of the ROS2 environment installed.

  1. Execute on host A:

This demonstration shows the car running in Docker. Docker uses host mode. Simply put, host mode means the car shares the same network, so executing the command is identical to running the command on the car.

xxxxxxxxxx
ros2 run demo_nodes_py talker
  1. Host B executes:
xxxxxxxxxx
ros2 run demo_nodes_py listener

If the following display appears: The slaves can subscribe to the topics published by the host, multi-machine communication has been achieved.
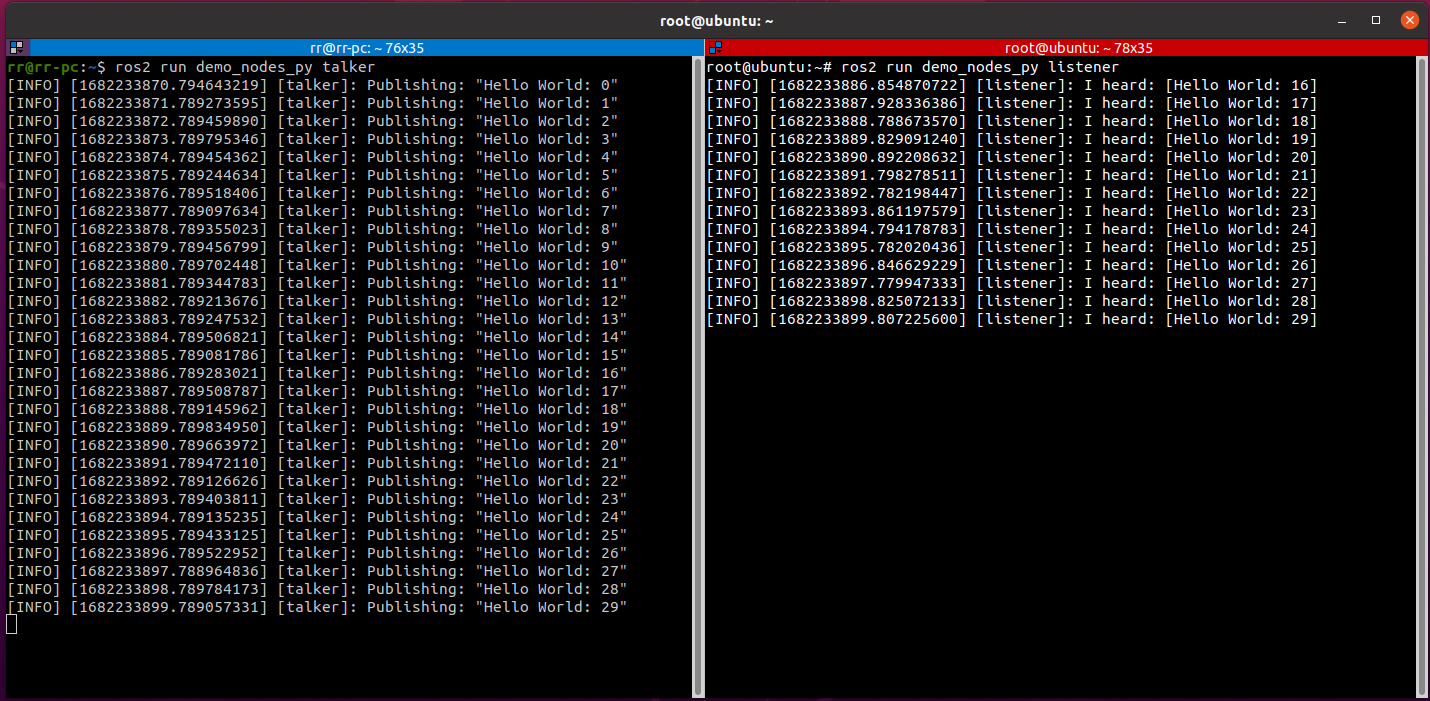
2.2. Distributed Network Grouping

If you are currently using other robots in your network, you can also set up a group for your robot to prevent interference from other robots.

ROS2 provides a DOMAIN mechanism, similar to grouping. Only computers in the same DOMAIN can communicate. We can assign both the host (car) and the slave (virtual machine) to the same group by adding the following line to their .bashrc files:

xxxxxxxxxx
$ export ROS_DOMAIN_ID=<your_domain_id>

If the host (car) and the slave (virtual machine) are assigned different IDs, they will not be able to communicate, thus achieving the purpose of grouping.

2.2.1 Example 1

  1. Execute on the host (car):

This demonstrates the car running in Docker, which uses host network mode. Simply put, host mode means the car shares the same network with the car, so the execution is identical to running on the car.

echo "export ROS_DOMAIN_ID=6" >> ~/.bashrc # The value 6 here refers to the ROS_DOMAIN_ID. It doesn't have to be 6, as long as it conforms to the ROS_DOMAIN_ID rules.
source ~/.bashrc
ros2 run demo_nodes_py talker
  1. Simultaneously, execute the following command on the slave machine [virtual machine]:
echo "export ROS_DOMAIN_ID=6" >> ~/.bashrc # This value matches the value on the master machine.
source ~/.bashrc
ros2 run demo_nodes_py listener

If the following message appears: The slave machine can subscribe to the topic published by the master machine in a timely manner, indicating that grouped multi-machine communication has been achieved.
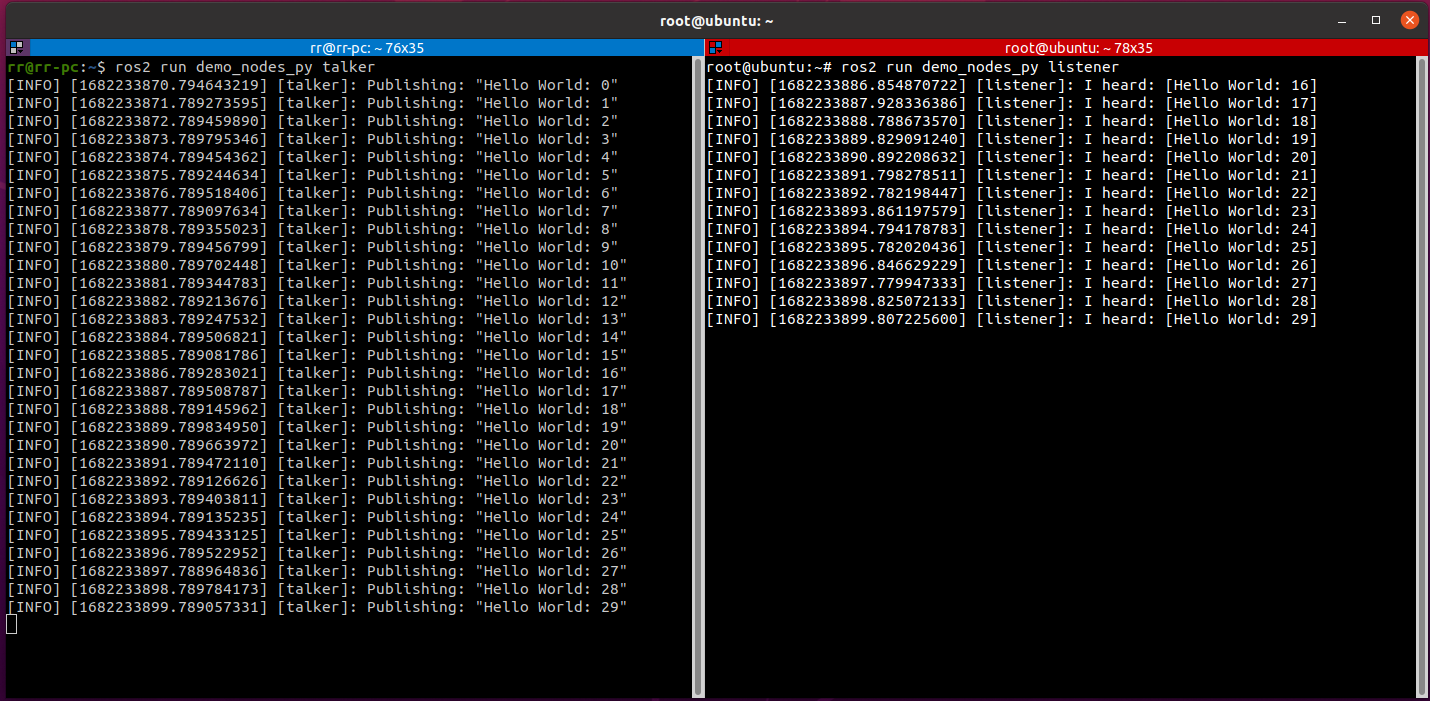
2.2.2 Case 2

Controlling turtle movement through distributed communication

  • Host A run command
xxxxxxxxxx
ros2 run turtlesim turtlesim_node
  • Host B run command
xxxxxxxxxx
ros2 run turtlesim turtle_teleop_key

3. Notes

Setting the ROS_DOMAIN_ID value is not arbitrary and is subject to certain constraints:

  1. It is recommended that the ROS_DOMAIN_ID value be between [0, 101], inclusive;
  2. The total number of nodes within each domain ID is limited and must be less than or equal to 120;
  3. If the domain ID is 101, the total number of nodes in that domain must be less than or equal to 54.

4. DDS Domain ID Calculation Rules (Advanced Knowledge)

The calculation rules for domain ID values ​​are as follows:

  1. DDS is based on the TCP/IP or UDP/IP network communication protocol. Network communication requires a specified port number, which is represented by a 2-byte unsigned integer and has a value range of [0, 65535].
  2. Port number assignment is also based on specific rules and cannot be used arbitrarily. According to the DDS protocol, port 7400 is used as the starting port, meaning the available ports are [7400, 65535]. Furthermore, according to the DDS protocol, each domain ID occupies 250 ports by default. Therefore, the number of domain IDs is: (65535 - 7400) / 250 = 232, corresponding to a value range of [0, 231].
  3. The operating system also sets some reserved ports. When using ports in DDS, you need to avoid these reserved ports to avoid conflicts. Different operating systems have different reserved ports. As a result, in Linux, the available domain IDs are [0, 101] and [215-231]. In Windows and Mac, the available domain IDs are [0, 166]. In summary, for compatibility across multiple platforms, it is recommended that domain IDs be within the range of [0, 101].
  4. Each domain ID occupies 250 ports by default, and each ROS2 node requires two ports. Furthermore, according to the DDS protocol, ports 1 and 2 within each domain ID's port range are the Discovery Multicast port and the User Multicast port. Ports 11 and 12 onwards are the Discovery Unicast port and the User Unicast port for the first node in the domain, and subsequent nodes occupy these ports in descending order. Therefore, the maximum number of nodes in a domain ID is: (250 - 10) / 2 = 120.
  5. Special case: For domain ID 101, the second half of the ports are reserved by the operating system, and the maximum number of nodes is 54.

The above calculation rules are sufficient for understanding.

ROS2 meta-function package
ROS2 DDS

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文