Welcome to Muto RS Robot repository
1)Hand detection
1.Hand detection
1.1. Introduction
MediaPipe is an open source data stream processing machine learning application development framework developed by Google. It is a graph-based data processing pipeline for building and using multiple forms of data sources, such as video, audio, sensor data, and any time series data. MediaPipe is cross-platform and can run on embedded platforms (Raspberry Pi, etc.), mobile devices (iOS and Android), workstations and servers, and supports mobile GPU acceleration. MediaPipe provides cross-platform, customizable ML solutions for real-time and streaming media. The core framework of MediaPipe is implemented in C++ and provides support for languages such as Java and Objective C. The main concepts of MediaPipe include Packet, Stream, Calculator, Graph and Subgraph.
MediaPipe Features:
- End-to-end acceleration: Built-in fast ML inference and processing accelerates even on commodity hardware.
- Build once, deploy anywhere: Unified solution for Android, iOS, desktop/cloud, web and IoT.
- Ready-to-use solutions: cutting-edge ML solutions that showcase the full capabilities of the framework.
- Free and open source: frameworks and solutions under Apache2.0, fully extensible and customizable.
1.2. MediaPipe Hands
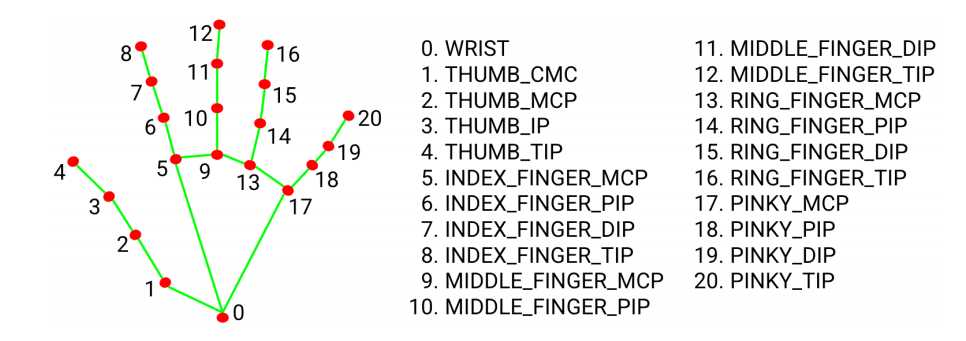
MediaPipe Hands is a high-fidelity hand and finger tracking solution. It uses machine learning (ML) to infer the 3D coordinates of 21 hands from a frame.
After hand detection on the entire image, the 21 3D hand joint coordinates in the detected hand area are accurately positioned through regression based on the hand mark model, that is, direct coordinate prediction. The model learns consistent internal hand pose representations and is robust even to partially visible hands and self-occlusion.
To obtain ground truth data, approximately 30K real-world images were manually annotated with 21 3D coordinates as shown below (Z values are obtained from the image depth map, if there is a Z value for each corresponding coordinate). To better cover possible hand poses and provide additional supervision on the nature of the hand geometry, high-quality synthetic hand models in various backgrounds are also drawn and mapped to corresponding 3D coordinates.
1.3. Hand detection
1.3.1.Startup
Note: Before running this case, please make sure that the [/dev/video0] device has been successfully mounted into the docker container, otherwise the camera will not be opened.
Enter the docker container and execute:
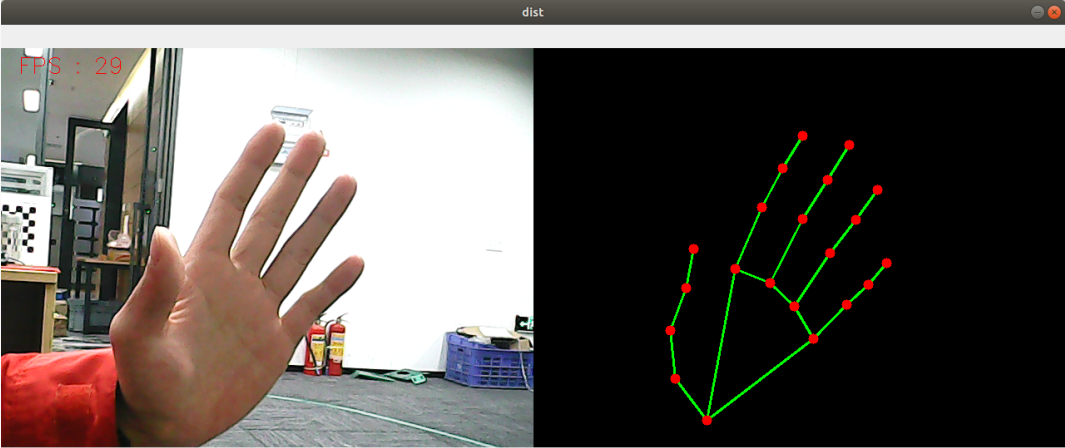
ros2 run yahboomcar_mediapipe 01_HandDetector
1.3.2. View point cloud data
Enter the docker container and execute:
xxxxxxxxxx#Run the point cloud publishing programros2 run yahboomcar_point pub_point#Start rviz to view point cloudrviz2
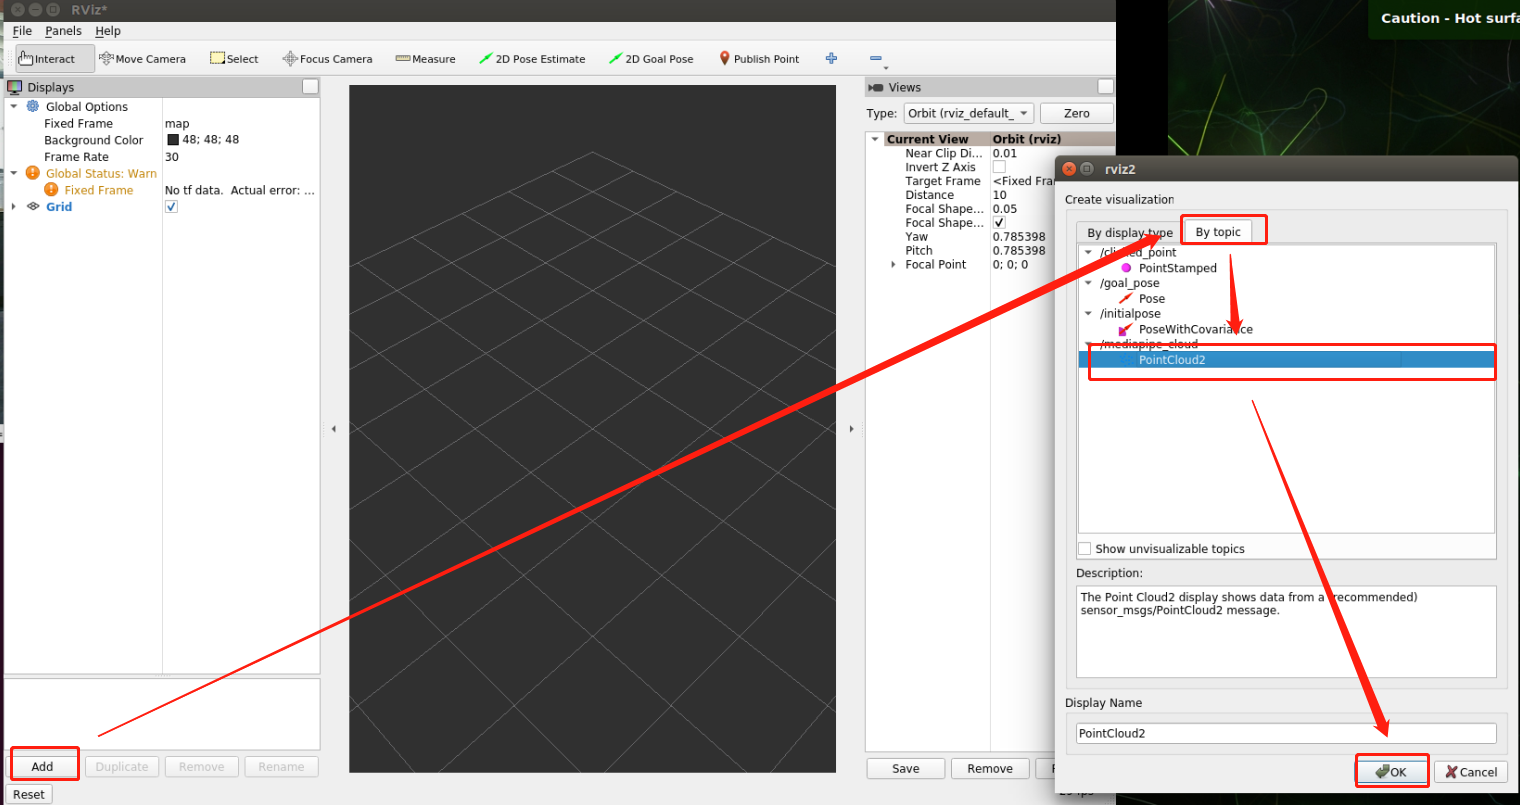
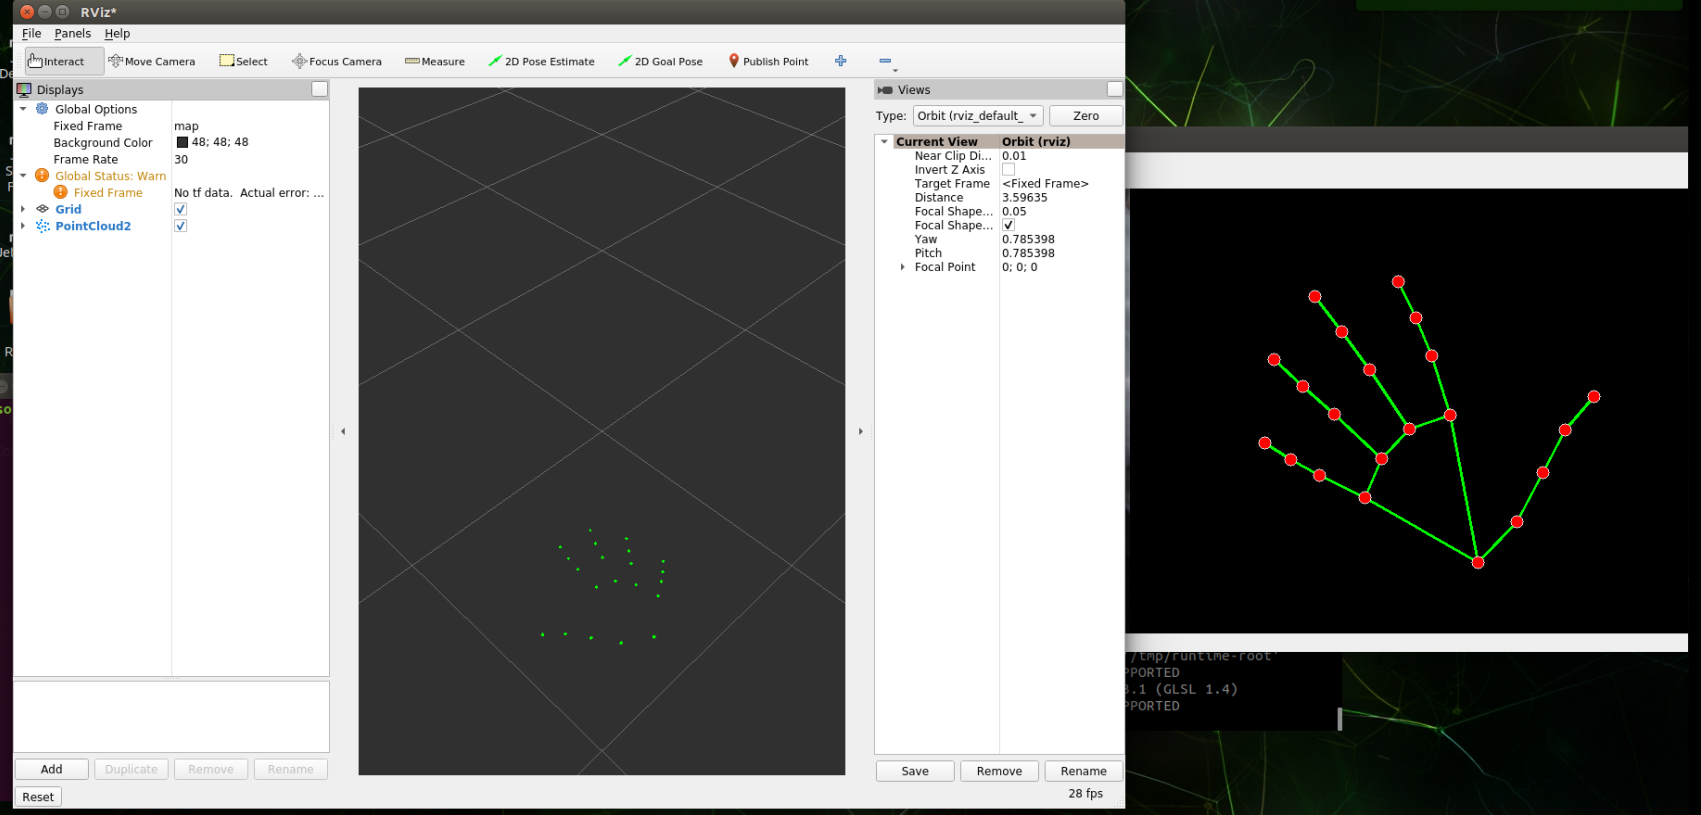
Follow the steps below to add a point cloud topic in rviz,
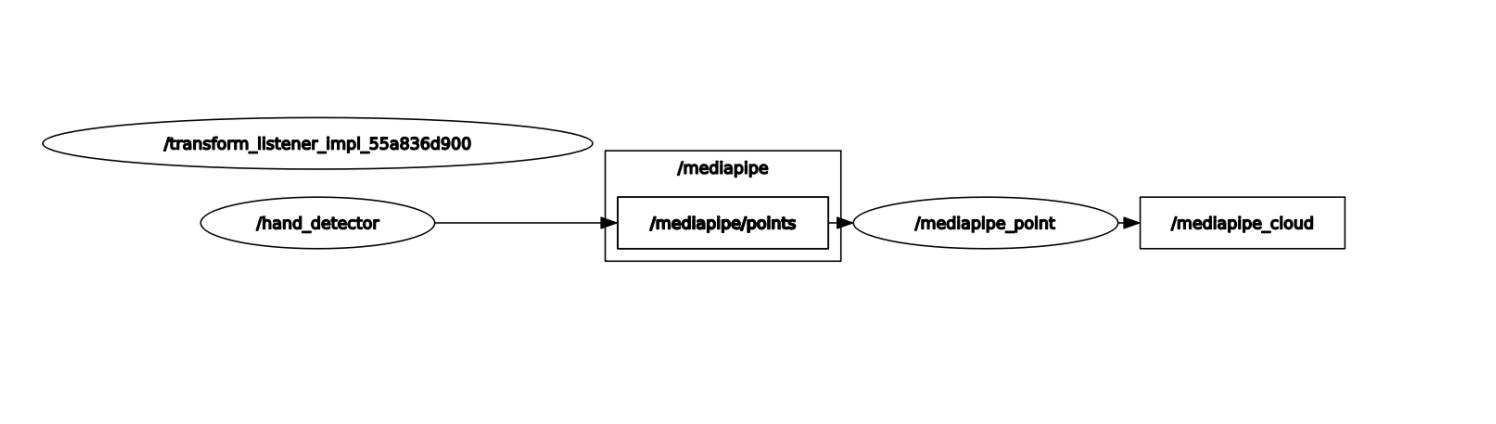
1.3.3. View node topic communication diagram
Enter the docker container and execute:
xxxxxxxxxxros2 run rqt_graph rqt_graph
1.3.4.Source code
Source code location:
xxxxxxxxxx/root/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/01_HandDetector.py
x#!/usr/bin/env python3# encoding: utf-8
#import ros libimport rclpyfrom rclpy.node import Nodefrom geometry_msgs.msg import Pointimport mediapipe as mp#import define msgfrom yahboomcar_msgs.msg import PointArray
#import commom libimport cv2 as cvimport numpy as npimport timeprint("import done")
class HandDetector(Node): def __init__(self,name, mode=False, maxHands=2, detectorCon=0.5, trackCon=0.5): super().__init__(name) self.mpHand = mp.solutions.hands self.mpDraw = mp.solutions.drawing_utils self.hands = self.mpHand.Hands( static_image_mode=mode, max_num_hands=maxHands, min_detection_confidence=detectorCon, min_tracking_confidence=trackCon) self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=6) self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=2, circle_radius=2) #create a publisher self.pub_point = self.create_publisher(PointArray,'/mediapipe/points',1000) def pubHandsPoint(self, frame, draw=True): pointArray = PointArray() img = np.zeros(frame.shape, np.uint8) img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) self.results = self.hands.process(img_RGB) if self.results.multi_hand_landmarks: for i in range(len(self.results.multi_hand_landmarks)): if draw: self.mpDraw.draw_landmarks(frame, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) self.mpDraw.draw_landmarks(img, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) for id, lm in enumerate(self.results.multi_hand_landmarks[i].landmark): point = Point() point.x, point.y, point.z = lm.x, lm.y, lm.z pointArray.points.append(point) self.pub_point.publish(pointArray) return frame, img def frame_combine(slef,frame, src): if len(frame.shape) == 3: frameH, frameW = frame.shape[:2] srcH, srcW = src.shape[:2] dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] else: src = cv.cvtColor(src, cv.COLOR_BGR2GRAY) frameH, frameW = frame.shape[:2] imgH, imgW = src.shape[:2] dst = np.zeros((frameH, frameW + imgW), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] return dst
def main(): print("start it") rclpy.init() hand_detector = HandDetector('hand_detector') capture = cv.VideoCapture(0) capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G')) capture.set(cv.CAP_PROP_FRAME_WIDTH, 640) capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480) print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS)) pTime = cTime = 0 while capture.isOpened(): ret, frame = capture.read() # frame = cv.flip(frame, 1) frame, img = hand_detector.pubHandsPoint(frame, draw=False) if cv.waitKey(1) & 0xFF == ord('q'): break cTime = time.time() fps = 1 / (cTime - pTime) pTime = cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) dist = hand_detector.frame_combine(frame, img) cv.imshow('dist', dist) # cv.imshow('frame', frame) # cv.imshow('img', img) capture.release() cv.destroyAllWindows()