Welcome to ROSMASTER X3 Plus repository
16.13 Mediapipe recognizes and tracks palm control robotic arm
13. Mediapipe recognition and tracking palm control robotic arm
13.1. Introduction
MediaPipe is an open source data stream processing machine learning application development framework developed by Google. It is a graph-based number
Data processing pipelines for building data sources that use multiple forms, such as video, audio, sensor data, and any time series data.
MediaPipe is cross-platform and can run on embedded platforms (Raspberry Pi, etc.), mobile devices (iOS and Android), workstations and servers
and supports mobile GPU acceleration. MediaPipe provides cross-platform, customizable ML solutions for live and streaming media.
13.2. Use
After the program is started and the camera captures the image, the robotic arm will follow the movement of the palm in the screen. The palm movement speed here should not be too fast, otherwise the image processing will not be able to keep up, which will cause lag.
xxxxxxxxxx#Raspberry Pi 5 master needs to enter docker first, please perform this step#If running the script into docker fails, please refer to ROS/07, Docker tutorial~/run_docker.shxxxxxxxxxxroslaunch arm_mediapipe mediaArm.launch # robot<PI5 needs to open another terminal to enter the same docker container
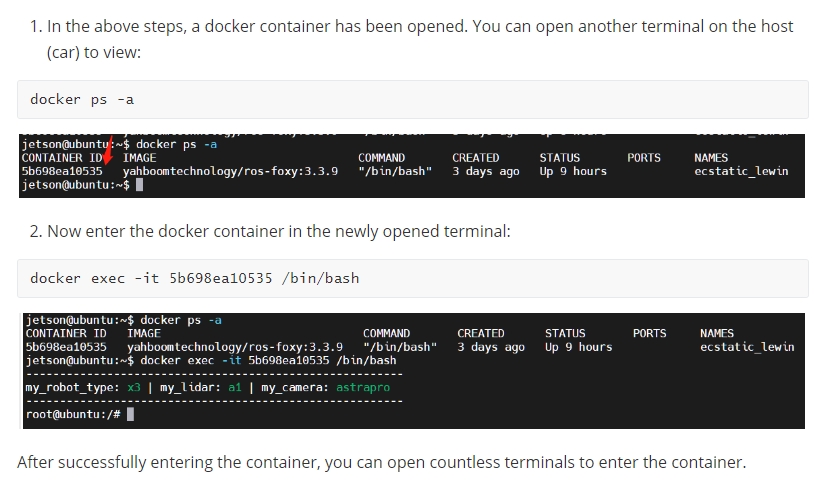
xxxxxxxxxxrosrun arm_mediapipe ArmCtrl.py #robotAfter starting, press R2 on the handle to turn on the function.
After the function is turned on, the robotic arm will move with the palm, and at the same time, the end clamp will also change with the opening and closing of the palm.
13.3. Core code analysis ArmCtrl.py
Code reference location
xxxxxxxxxx~/yahboomcar_ws/src/arm_mediapipe/scriptsCode analysis
1). Import important library files
xxxxxxxxxxfrom media_library import *Detect hands and obtain finger information
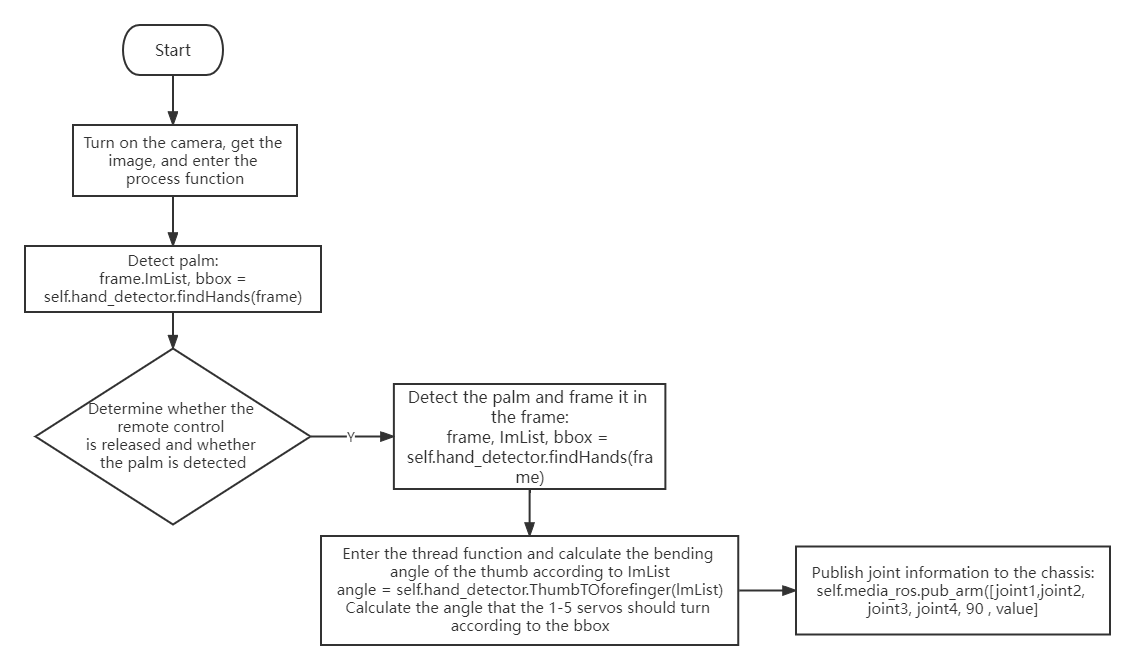
xxxxxxxxxxframe, lmList, bbox = self.hand_detector.findHands(frame)#bbox is the minimum and maximum xy value of the frame that frames the detected hand. This value is very important. By calculating the center coordinates, the position of the palm on the screen can be determined. The source code is in media_library.pyangle = self.hand_detector.ThumbTOforefinger(lmList)#Here you can calculate the bending angle of your thumb to control the opening and closing of the clamping jawsCalculate the angle of each steering gear
indexX = (bbox[0] + bbox[2]) / 2indexY = (bbox[1] + bbox[3]) / 2if indexY > 400: indexY = 400elif indexY < 200: indexY = 200joint2 = -0.4 * indexY + 170joint3 = 0.05 * indexY + 25joint4 = -0.125 * indexY + 85if 300 < indexX < 340: joint1 = 90else: joint1 = -0.3 * indexX + 186It can be seen that the index Calibrated according to the range.
13.4. Flowchart