Welcome to ROSMASTER X3 Plus repository
15.9 Voice control multi-point nagavation
7. Voice control multi-point navigation
7.1. Function description
By interacting with the voice recognition module on ROSMASTER, you can use your voice to let ROSMASTER navigate to point 1/2/3 on an established map. The R2 button on the handle can cancel/enable this function at any time. .
7.2. Start
xxxxxxxxxx#Raspberry Pi 5 master needs to enter docker first, please perform this step#If running the script into docker fails, please refer to ROS/07, Docker tutorial~/run_docker.sh7.2.1. Function package path
xxxxxxxxxx~/yahboomcar_ws/src/yahboomcar_voice_ctrl/7.2.2. Calibrate the target point for voice navigation
robot side
xxxxxxxxxxroslaunch yahboomcar_nav laser_bringup.launch #laser + yahboomcar<PI5 needs to open another terminal to enter the same docker container
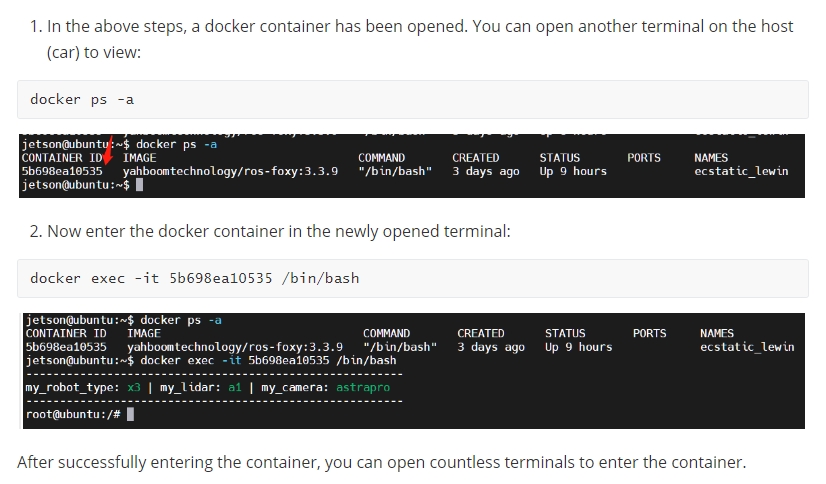
xxxxxxxxxxroslaunch yahboomcar_nav yahboomcar_navigation.launch use_rviz:=false map:=house #Open navigation, change house to the map name for mapping[use_rviz] Parameter: whether to open rviz.
[map] Parameters: map name, map to be loaded.
Turn on the visual interface (virtual machine side)
xxxxxxxxxxroslaunch yahboomcar_nav view_navigate.launchIn the map rviz, adjust the initial posture of ROSMASTER;
2), terminal input
xxxxxxxxxxrostopic echo /move_base_simple/goal
Use the 2D Nav Goal tool in rviz to give the car a target point in rviz, recorded as position 1. At this time, the coordinates of the target point will be printed out in the terminal window where you just viewed the data of /move_base_simple/goal. ,As shown below,
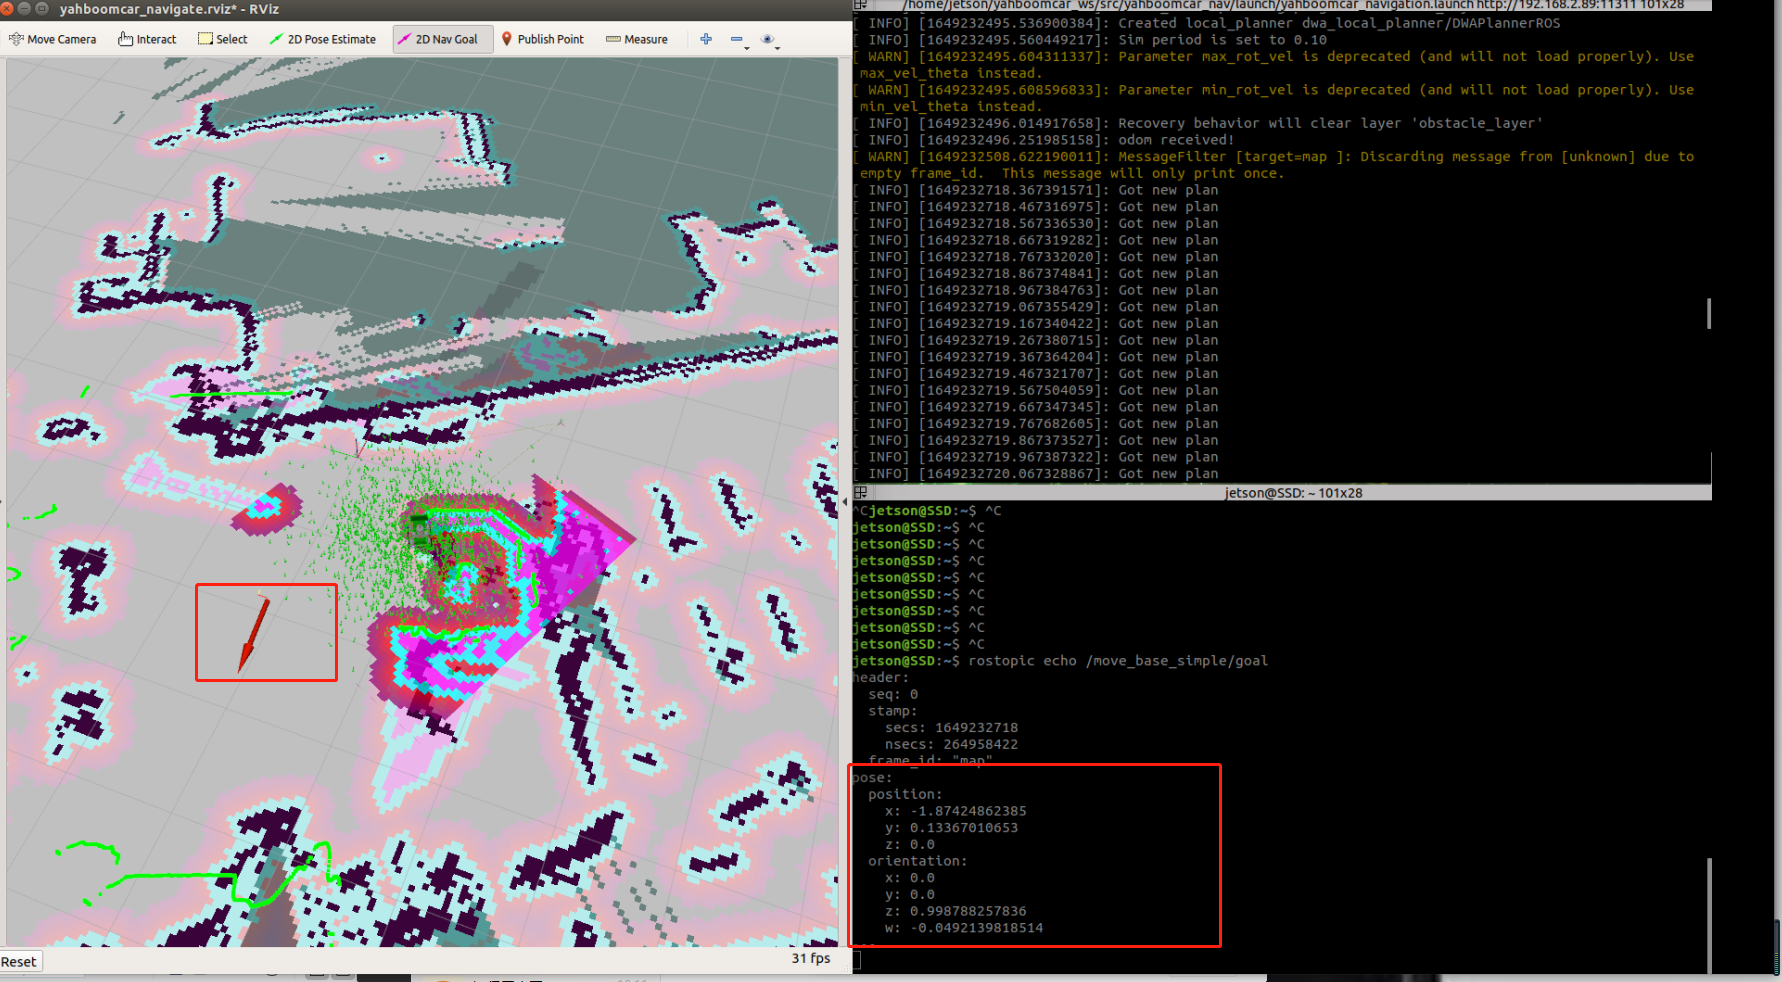
Just record the pose part of the data. Later, you need to send this part manually through the program.
Open ~/yahboomcar_ws/src/yahboomcar_voice_ctrl/scripts/voice_Ctrl_send_mark.py, and modify the pose data just recorded to the corresponding location.
xxxxxxxxxx pose.pose.position.x = 2.15381097794 pose.pose.position.y = -5.02386903763 pose.pose.orientation.z = 0.726492681307 pose.pose.orientation.w = 0.687174202082In addition to the two BC points, the position is also calibrated first, and then the calibrated value is modified into the function as an actual parameter.
7.2.2. Voice navigation
xxxxxxxxxxroslaunch yahboomcar_nav laser_bringup.launch #laser + yahboomcarroslaunch yahboomcar_nav yahboomcar_navigation.launch use_rviz:=false map:=house #Open navigation, change house to the map name for mappingpython ~/yahboomcar_ws/src/yahboomcar_voice_ctrl/scripts/voice_Ctrl_send_mark.pyAfter calibrating the initial pose in rviz, say "Hello, Xiaoya" to ROSMASTER to wake up the voice module. After hearing the voice module's feedback broadcast of "is", say to ROSMASTER "Navigate to position 1"; the voice module There will be a feedback message saying "Okay, heading to location 1". The same goes for other locations, as long as the coordinate values of the destinations of other points are written in the program.
7.3. Core code analysis
7.3.1. For the principle of navigation, please refer to the tutorial " 11. Lidar \ 12. Navigation and Obstacle Avoidance " The content of this section is mainly about judging the speech recognition results and packaging and sending
target point data,
xxxxxxxxxx#Pack target point data         speech_r = spe.speech_read()         if speech_r == 19 :             print("goal to one")             spe.void_write(speech_r)             pose.pose.position.x = 2.15381097794             pose.pose.position.y = -5.02386903763             pose.pose.orientation.z = 0.726492681307             pose.pose.orientation.w = 0.687174202082             pub_goal.publish(pose)         elif speech_r == 20 :             print("goal to show")             spe.void_write(speech_r)             pose.pose.position.x = 1.57744419575             pose.pose.position.y = 4.8174996376             pose.pose.orientation.z = -0.683335654604             pose.pose.orientation.w = 0.730104364558             pub_goal.publish(pose)                     elif speech_r == 21 :             print("goal to three")             spe.void_write(speech_r)             pose.pose.position.x = -1.08106160164             pose.pose.position.y = 1.30198049545             pose.pose.orientation.z = -0.0132771070267             pose.pose.orientation.w = 0.99991185533             pub_goal.publish(pose)                     elif speech_r == 32 :             print("goal to four")             spe.void_write(speech_r)             pose.pose.position.x = -1.08106160164             pose.pose.position.y = 1.30198049545             pose.pose.orientation.z = -0.0132771070267             pose.pose.orientation.w = 0.99991185533             pub_goal.publish(pose)
         elif speech_r == 33 :             print("goal to Origin")             spe.void_write(speech_r)             pose.pose.position.x = -1.08106160164             pose.pose.position.y = 1.30198049545             pose.pose.orientation.z = -0.0132771070267             pose.pose.orientation.w = 0.99991185533             pub_goal.publish(pose)         elif speech_r == 0 :             pub_cmdVel.publish(Twist())S
7.3.2. Program flow chart
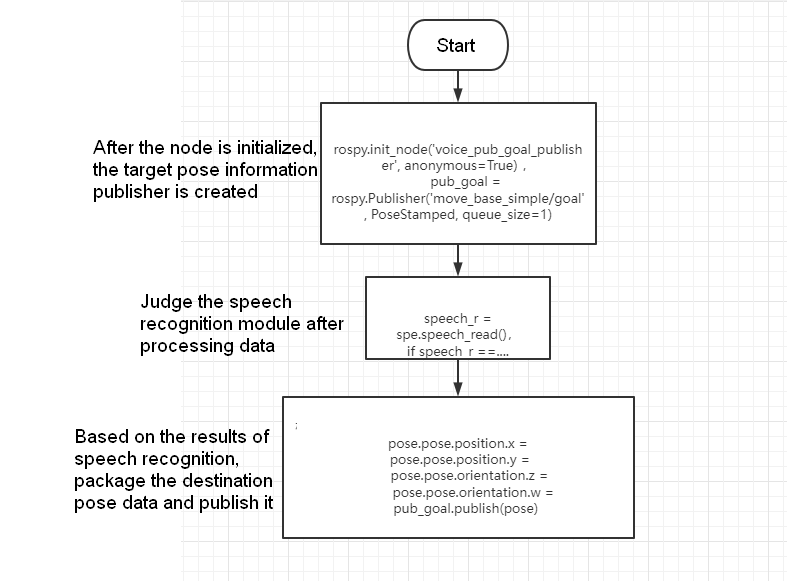
For complete code, please refer to:
xxxxxxxxxx~/yahboomcar_ws/src/yahboomcar_voice_ctrl/scripts/voice_Ctrl_send_mark.py7.3.3. Function module communication table
| Function words | Speech recognition module results | Voice broadcast content |
|---|---|---|
| Navigate to location 1 | 19 | OK, heading to location 1 |
| Navigate to location 2 | 20 | OK, heading to location 2 |
| Navigate to No. 3 | 21 | OK, heading to No. 3 |
| Navigate to No. 4 | 32 | OK, heading to No. 4 |
| Return to origin | 33 | OK, returning to origin |