yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
K230 Vision Module📖
1. Quick Start
  • 0.Get start
  • 1. K230 firmware download and burning
  • 2. Install the programming environment
  • 3. Debug and run routines
  • 4. Offline running routine
  • 5. Micropython Quick Start
  • 6. GUI Program Instructions
  • 7.K230 module bracket installation tutorial
  • 8.K230 module 2DOF PTZ installation tutorial
2. Basic Courses
  • 1.FPIOA pin assignment
  • 2.RGB lights
  • 3.Buzzer
  • 4.Buttons
  • 5.Serial communication
  • 6.I2C communication
  • 7.PWM
  • 8.WDT watchdog
  • 9.Timer
  • 10.Fourier Transform
  • 11.SHA256 encryption
  • 12.AES encryption
  • 13.Multithreading
  • 14.File reading and writing
  • 15.Image Display
  • 16.Touch Display
  • 17.Camera display
  • 18.Image Flip
  • 19.Camera
3. Draw the image
  • 1. Draw the lines
  • 2. Draw the circle
  • 3. Draw the rectangle
  • 4. Draw the ellipse
  • 5. Draw the arrow
  • 6. Draw the crosshairs
  • 7. Draw text
  • 8. Draw key points
4. Graphics detection
  • 1. Line segment detection
  • 2. Rectangle Detection
  • 3. Circle detection
  • 4. Object edge detection
  • 5. Line inspection basics:fast linear regression
5. Color recognition
  • 1. Color recognition
  • 2. Object Counting
  • 3. Multi-color recognition
  • 4. K230 Color Line Patrol
6.1 CV_lite Image Processing Special Topic
  • 1.Introduction to cv_litenew
  • 2.cv_lite API Reference Manualnew
  • 3.Color Block Recognition - Grayscale Imagenew
  • 4.Color Block Recognition - Color Imagenew
  • 5.Circle Recognition - Grayscale Imagenew
  • 6.Circle Recognition - Color Imagenew
  • 7.Corner Recognition - Grayscale Imagenew
  • 8.Corner Recognition - Color Imagenew
  • 9.Edge Recognition - Grayscale Imagenew
  • 10. Edge Recognition - Color Imagenew
  • 11. Rectangle Recognition - Grayscale Imagenew
  • 12.Rectangle Recognition - Color Imagenew
  • 13.Rectangle recognition combined with corner recognition - grayscale imagenew
  • 14.Rectangle recognition combined with corner recognition - color imagenew
  • 15.Image Binarization - Grayscalenew
  • 16.Image Binarization - Color Imagenew
  • 17.Exposure Adjustmentnew
  • 18.Image Black Hat Operationsnew
  • 19.Image Color Histogramnew
  • 20.Image Closingnew
  • 21.Image Expansionnew
  • 22.Image Corrosionnew
  • 23.Gaussian Blurnew
  • 24.Gradient Transformationnew
  • 25.Mean Fuzzynew
  • 26.Image Openingnew
  • 27.Image Top Hat Operationnew
  • 28.PnP rangingnew
  • 29.Find rectangles and measure distancesnew
  • 30.Image grayscale world white balancenew
6.2 OpenCV Image Processing Special Topicnew
  • 1. OpenCV Introduction
  • 2. OpenCV API Reference
  • 3. Image Basic Transforms
  • 4. Morphological Operations
  • 5. Color Segmentation and Shape Classification
  • 6. Corner and Centroid Detection
  • 7. Hough Circle Detection
  • 8. Hough Line Detection
  • 9. Contour Analysis
  • 10. Drawing Functions
  • 11. Template Matching
  • 12. Image Blur Filtering
  • 13. Edge Detection
  • 14. Thresholding
  • 15. Color Segmentation
  • 16. Histogram and Pixel Transformation
  • 17. Arithmetic and Bitwise Operations
  • 18. Channel Operation and Statistics
  • 19. Image File Read and Write
  • 20. Pixel Level Transformation
7. Code type recognition
  • 1.Barcode recognition
  • 2.QR code recognition
  • 3.AprilTag tag recognition
  • 4.DM code recognition
8. Face Recognition
  • 1.[Must-read] General code structure and prerequisite knowledge of AI vision routines
  • 2.Face Detection
  • 3.Facial key point recognition
  • 4.Face orientation detection
  • 5.Face 3D Network
  • 6.Gaze direction detection
  • 7.Register for face recognition
9. Human body characteristics
  • 1. Human body detection
  • 2. Human key point detection
  • 3. Human posture recognition
  • 4. Fall detection
  • 5. Palm detection
  • 6. Palm key point detection
  • 7. Palm key point classification
  • 8. Gesture Recognition
  • 9. Dynamic gesture recognition
  • 10. Rock, Paper, Scissors
10. Scenario Application
  • 1.OCR character detection
  • 2.OCR character recognition
  • 3.yolov8n target detection
  • 4.yolov8n segmentation
  • 5. Self-learning object recognition
  • 6. License plate detection
  • 7. License Plate Recognition
  • 8. Target Tracking
  • 9. Fruit classification
  • 10. Garbage classification
  • 11. Road sign recognition
11. Audio and video processing
  • 1. Audio Recording
  • 2. Play Audio
  • 3. Video Recording
  • 4. Play Video
  • 5. Keyword wake-up
12. Network Basics
  • 1. Wireless network connection
  • 2. AP hotspot mode
  • 3. TCP-Server Example
  • 4. TCP-Client Example
  • 5. UDP-Server Example
  • 6. UDP-Client Example
  • 7. HTTP-Server Example
  • 8. HTTP-Client Example
  • 9. MQTT Quick Start
  • 10. MQTT-Publisher
  • 11. MQTT-Subscriber
  • 12. RTSP real-time image transmission
  • 13. RTSP real-time image transmission combined with AIDemo
  • 14. Call OpenRouter large model aggregation service
  • 15. Open the Resource Monitoring Panel
13. LVGL Graphical Interface
  • 1. Introduction to LVGL
  • 2. Create a button
  • 3. Create a slider
  • 4. Create an Image
  • 5. Create a text box and keyboard
14. GUI Code Tutorial & Secondary Development
  • 01.GUI System Architecture
  • 02.Core Engine Initialization
  • 03.Application Discovery Mechanism in GUI
  • 04.Desktop Layout Algorithm
  • 05.Advanced UI Styling
  • 06.BaseApp Base Class Analysis
  • 07.Hello_World Practical
  • 08.GUI Application Lifecycle and Resource Management
15. Train your own model
  • 1. Local deployment of yolo training environment
  • 2. Use online platforms for training
16.Touch Course
  • 1.Touch point detectionnew
  • 2.Touch Paintingnew
  • 3.Touch to take a photonew
17. Multi-master communication (purchased separately)
ESP32-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
Jetson-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
MSPM0G3507-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
Pico-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
raspberrypi-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
RDK-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
STM32-K230
  • 1. stm32_k230 color recognition
  • 2. stm32_k230 barcode recognition
  • 3. stm32_k230 QR code recognition
  • 4. stm32_k230Apriltag code recognition
  • 5. stm32_k230DM code recognition
  • 6. stm32_k230 face detection
  • 7.stm32_k230 looking direction
  • 8. stm32_k230 face recognition
  • 9. stm32_k230 human body detection
  • 10. stm32_k230 fall detection
  • 11. stm32_k230 palm detection
  • 12. stm32_k230 gesture recognition
  • 13. stm32_k230OCR character recognition
  • 14. stm32_k230 object detection
  • 15. stm32_k230 target tracking
  • 16. stm32_k230 self-learning object recognition
  • 17.stm32_k230 license plate recognition
Arduino-K230
  • 1.arduino_k230 color recognition
  • 2.arduino_k230 barcode recognition
  • 3.arduino_k230 QR code recognition
  • 4.arduino_k230 Apriltag code recognition
  • 5.arduino_k230 DM code recognition
  • 6.arduino_k230 face detection
  • 7.arduino_k230 looking direction
  • 8.arduino_k230 face recognition
  • 9.arduino_k230 human body detection
  • 10.arduino_k230 fall detection
  • 11.arduino_k230 palm detection
  • 12.arduino_k230 gesture recognition
  • 13.arduino_k230 OCR character recognition
  • 14.arduino_k230 object detection
  • 15.arduino_k230 target tracking
  • 16.arduino_k230 self-learning object recognition
  • 17.arduino_k230 license plate recognition
Microbit-K230
  • 1.microbit_k230 color recognition
  • 2.microbit_k230 barcode recognition
  • 3.microbit_k230 QR code recognition
  • 4.microbit_k230 Apriltag code recognition
  • 5.microbit_k230 DM code recognition
  • 6.microbit_k230 face detection
  • 7.microbit_k230 looking direction
  • 8.microbit_k230 face recognition
  • 9.microbit_k230 human body detection
  • 10.microbit_k230 fall detection
  • 11.microbit_k230 palm detection
  • 12.microbit_k230 gesture recognition
  • 13.microbit_k230 OCR character recognition
  • 14.microbit_k230 object detection
  • 15.microbit_k230 target tracking
  • 16.microbit_k230 self-learning object recognition
  • 17.microbit_k230 license plate recognition
MSPM0G3519-K230
  • 1. K230 Color Recognitionnew
  • 2. K230 Barcode Recognitionnew
  • 3. K230 QR Code Recognitionnew
  • 4. K230 Apriltag Code Recognitionnew
  • 5. K230 DM Code Recognitionnew
  • 6. K230 Face Detectionnew
  • 7. K230 Gaze Directionnew
  • 8. K230 Face Recognitionnew
  • 9. K230 Human Body Detectionnew
  • 10. K230 Fall Detectionnew
  • 11. K230 Palm Detectionnew
  • 12. K230 Gesture Recognitionnew
  • 13. K230 OCR Character Recognitionnew
  • 14. K230 Object Detectionnew
  • 15. K230 Target Trackingnew
  • 16. K230 Self-learning Object Recognitionnew
  • 17. K230 License Plate Recognitionnew
18.Extension case (purchase separately)
For 2DOF Electric Platform
  • 1.Moving target control and automatic tracking system
  • 2.Human body recognition alarm
  • 3.Gesture Recognition
  • 4.Rock Paper Scissors
  • 5.Fruit sorting
  • 6.Color Tracking
  • 7.Face Tracking
MSPM0G3507 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual tracking
  • 2.Color tracking
  • 3.Color response
  • 4.Road sign recognition
  • 5.Machine code tracking
  • 6.QR code recognition action
  • 7.Autonomous avoid
  • 8.License plate tracking
  • 9.Face tracking
  • 10.Gaze direction tracking
  • 11.Palm tracking
  • 12.Target tracking
  • 13.Human body tracking
  • 14.OCR character recognition action
STM32 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual tracking
  • 2.Color tracking
  • 3.Color response
  • 4.Road sign recognition
  • 5.Machine code tracking
  • 6.QR code recognition action
  • 7.Autonomous avoid
  • 8.License plate tracking
  • 9.Face tracking
  • 10.Gaze direction tracking
  • 11.Palm tracking
  • 12.Target tracking
  • 13.Human body tracking
  • 14.OCR character recognition action
MSPM0G3519 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual trackingnew
  • 2.Color trackingnew
  • 3.Color responsenew
  • 4.Road sign recognitionnew
  • 5.Machine code trackingnew
  • 6.QR code recognition actionnew
  • 7.Autonomous avoidnew
  • 8.License plate trackingnew
  • 9.Face trackingnew
  • 10.Gaze direction trackingnew
  • 11.Palm trackingnew
  • 12.Target trackingnew
  • 13.Human body trackingnew
  • 14.OCR character recognition actionnew
19. Expansion case(purchase separately)new
  • 1.Motion target control and Auto track system
  • 2.Vehicle-mounted balance ball motion control system
Download
  • Manual
  • CanMV IDE
  • Software Tools
  • Firmware
  • Source Code
  • Appendix
Download ZIP

Welcome to K230 Vision Module repository

17.Camera display

Camera display

Camera displayIntroduction to the results of routine experimentsCode ExplanationComplete codeCamera related APIConstructor2.1 sensor.reset2.2 sensor.set_framesize2.3 sensor.set_pixformat2.4 sensor.set_hmirror2.5 sensor.set_vflip2.6 sensor.run2.7 sensor.stop2.8 sensor.snapshot


Introduction to the results of routine experiments

In this section, we will call the camera and display the image captured by the camera in the IDE frame buffer.

We use CanMV IDE to open the sample code and connect K230 to the computer via USB.

Click the Run button in the lower left corner of the CanMV IDE, and you can see the image captured by the camera displayed in the frame buffer in the upper right corner of the IDE.
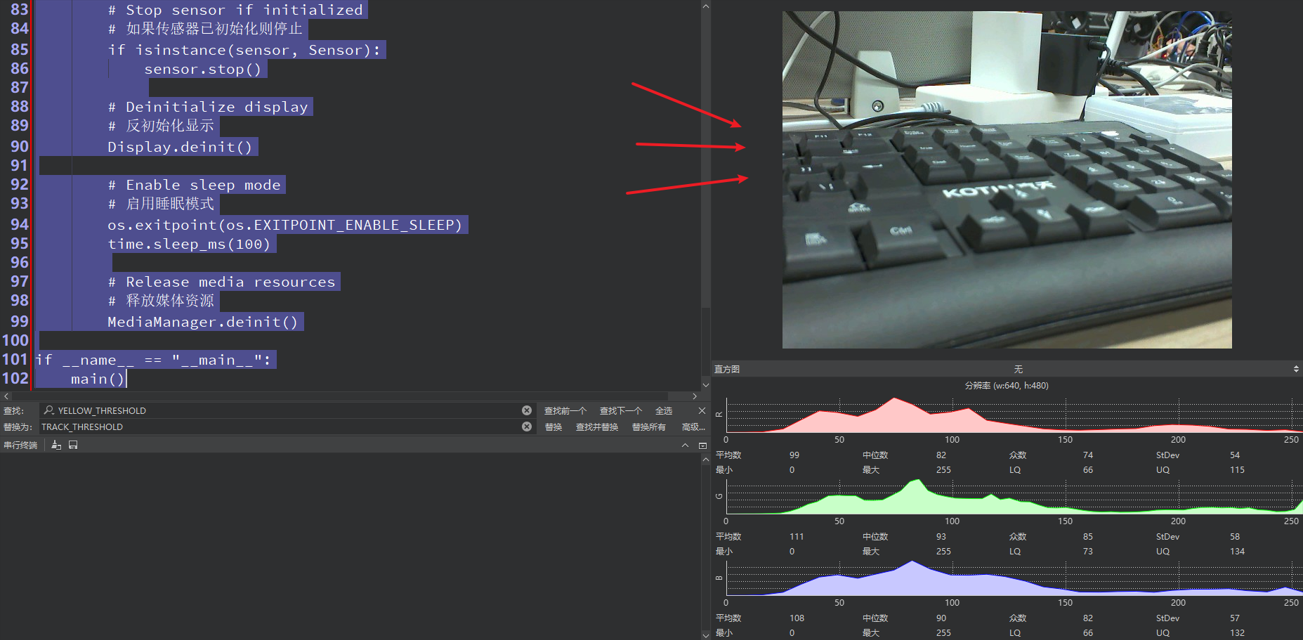
image-20250211095846642

Code Explanation

The source code file for this tutorial is located in [Source Code/02.Basic/17.sensor.py]

Complete code

xxxxxxxxxx
# 导入必要的模块:时间、数学、操作系统、垃圾回收、系统
# (Import necessary modules: time, math, os, garbage collection, system)
import time, math, os, gc, sys
​
# 导入媒体相关模块:传感器、显示、媒体管理
# (Import media-related modules: sensor, display, media manager)
from media.sensor import *
from media.display import *
from media.media import *
​
# 定义图像宽度和高度常量
# (Define image width and height constants)
WIDTH = 640
HEIGHT = 480
​
# 初始化传感器变量为空
# (Initialize sensor variable as None)
sensor = None
​
try:
    # 使用默认配置构造传感器对象,设置指定宽度和高度
    # (Construct a Sensor object with default configuration, setting specified width and height)
    sensor = Sensor(width = WIDTH, height = HEIGHT, fps=30)
    
    # 传感器复位
    # (Reset the sensor)
    sensor.reset()
    
    # 设置水平镜像(当前被注释)
    # (Set horizontal mirror - currently commented out)
    # sensor.set_hmirror(False)
    
    # 设置垂直翻转(当前被注释)
    # (Set vertical flip - currently commented out)
    # sensor.set_vflip(False)
​
    # 设置通道0的输出尺寸
    # (Set channel 0 output size)
    sensor.set_framesize(width = WIDTH, height = HEIGHT)
    
    # 设置通道0的输出格式为RGB565
    # (Set channel 0 output format to RGB565)
    sensor.set_pixformat(Sensor.RGB565)
​
    # 使用IDE作为输出目标初始化显示
    # (Initialize display using IDE as output target)
    Display.init(Display.ST7701, width = WIDTH, height = HEIGHT, to_ide = True)
​
    # 初始化媒体管理器
    # (Initialize the media manager)
    MediaManager.init()
    
    # 启动传感器运行
    # (Start the sensor running)
    sensor.run()
​
    # 创建时钟对象用于计算帧率
    # (Create a clock object to calculate frames per second)
    fps = time.clock()
​
    # 主循环
    # (Main loop)
    while True:
        # 帧率计时器tick
        # (Tick the FPS timer)
        fps.tick()
​
        # 检查是否应该退出程序
        # (Check if the program should exit)
        os.exitpoint()
​
        # 从传感器获取一帧图像
        # (Capture a frame from the sensor)
        img = sensor.snapshot()
​
        # 在屏幕上显示结果图像
        # (Display the resulting image on screen)
        Display.show_image(img)
        
        # 执行垃圾回收
        # (Perform garbage collection)
        gc.collect()
​
        # 打印当前帧率
        # (Print the current frames per second)
        print(fps.fps())
        
except KeyboardInterrupt as e:
    # 捕获键盘中断异常(用户手动停止)
    # (Catch keyboard interrupt exception - user manually stops)
    print(f"user stop")
except BaseException as e:
    # 捕获所有其他异常
    # (Catch all other exceptions)
    print(f"Exception '{e}'")
finally:
    # 无论如何都执行清理工作
    # (Perform cleanup regardless of how the program exits)
    
    # 停止传感器运行(如果传感器对象存在)
    # (Stop the sensor if the sensor object exists)
    if isinstance(sensor, Sensor):
        sensor.stop()
        
    # 反初始化显示
    # (Deinitialize the display)
    Display.deinit()
​
    # 设置退出点,允许进入睡眠模式
    # (Set exit point to enable sleep mode)
    os.exitpoint(os.EXITPOINT_ENABLE_SLEEP)
    
    # 短暂延时100毫秒
    # (Brief delay of 100 milliseconds)
    time.sleep_ms(100)
​
    # 释放媒体缓冲区
    # (Release media buffer)
    MediaManager.deinit()

Camera related API

The following content is excerpted from the CanMV Sensor API chapter

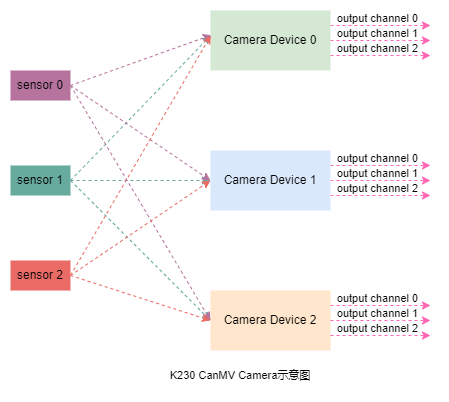
The module of the CanMV K230 platform sensoris responsible for image acquisition and data processing. The module provides a set of high-level APIs that developers can use to easily obtain images of different formats and sizes without having to understand the specific implementation of the underlying hardware.
camera-block-diagram

Sensor 0, sensor 1, and sensor 2 represent three image input sensor devices; Camera Device 0, Camera Device 1, and Camera Device 2 correspond to the corresponding image processing units; output channel 0, output channel 1, and output channel 2 indicate that each image processing unit supports up to three output channels. Through software configuration, different sensor devices can be flexibly mapped to the corresponding image processing units.

The module of CanMV K230 sensorsupports the simultaneous access of up to three image sensors, each of which can independently complete the acquisition, capture and processing of image data. In addition, each video channel can output three channels of image data in parallel for further processing by the back-end module. In actual applications, the specific number of sensors supported, input resolution and number of output channels will be limited by the hardware configuration and memory size of the development board, so a comprehensive evaluation is required based on project requirements.

Constructor

describe

csi idConstruct an object from a and an image sensor type Sensor.

In image processing applications, users usually need to create an Sensorobject first. CanMV K230 software can automatically detect the built-in image sensor, without the user manually specifying the specific model, just set the maximum output resolution and frame rate of the sensor. For information about supported image sensors, see the image sensor support list . If the set resolution or frame rate does not match the default configuration of the current sensor, the system will automatically adjust to the optimal configuration. The final configuration can be viewed in the log, for example use sensor 23, output 640x480@90.

grammar

xxxxxxxxxx
sensor = Sensor(id, [width, height, fps])

parameter

Parameter namedescribeInput/Outputillustrate
idcsiPort, support 0-2, please refer to the hardware schematic diagram for specific portsenterOptional. The default value is different for different development boards.
widthsensorMaximum output image widthenterOptional, default1920
heightsensorMaximum output image heightenterOptional, default1080
fpssensorMaximum output image frame rateenterOptional, default30

Return Value

Return Valuedescribe
Sensor ObjectSensor Object

Example

xxxxxxxxxx
sensor = Sensor(id=0)
sensor = Sensor(id=0, width=1280, height=720, fps=60)
sensor = Sensor(id=0, width=640, height=480)

2.1 sensor.reset

describe

Resets sensorthe object. SensorYou must call this function after constructing the object to continue executing other operations.

grammar

xxxxxxxxxx
sensor.reset()

parameter

Parameter namedescribeInput/Output
none

Return Value

Return Valuedescribe
none

Example

# Initialize sensor device 0 and sensor OV5647
sensor.reset()

2.2 sensor.set_framesize

describe

Sets the output image size for the specified channel. The user can configure the output image size via framesizethe parameter or by specifying widthand directly. The width is automatically aligned to 16 pixels wide .height

grammar

xxxxxxxxxx
sensor.set_framesize(framesize=FRAME_SIZE_INVALID, chn=CAM_CHN_ID_0, alignment=0, **kwargs)

parameter

Parameter namedescribeInput/Output
framesizeSensor output image sizeenter
chnSensor output channel numberenter
widthOutput image width, kw_argenter
heightOutput image height, kw_argenter

Return Value

Return Valuedescribe
none

Precautions

  • The output image size must not exceed the actual output capability of the image sensor.
  • The maximum output image size for each channel is limited by the hardware.

Example

xxxxxxxxxx
# Configure sensor device 0, output channel 0, output image size 640x480
sensor.set_framesize(chn=CAM_CHN_ID_0, width=640, height=480)
​
# Configure sensor device 0, output channel 1, output image size 320x240
sensor.set_framesize(chn=CAM_CHN_ID_1, width=320, height=240)

2.3 sensor.set_pixformat

describe

Configure the image sensor output image format for the specified channel.

grammar

xxxxxxxxxx
sensor.set_pixformat(pix_format, chn=CAM_CHN_ID_0)

parameter

Parameter namedescribeInput/Output
pix_formatOutput image formatenter
chnSensor output channel numberenter

Return Value

Return Valuedescribe
none

Example

# Configure sensor device 0, output channel 0, output NV12 format
sensor.set_pixformat(sensor.YUV420SP, chn=CAM_CHN_ID_0)
​
# Configure sensor device 0, output channel 1, output RGB888 format
sensor.set_pixformat(sensor.RGB888, chn=CAM_CHN_ID_1)

2.4 sensor.set_hmirror

describe

Configure whether the image sensor is horizontally mirrored.

grammar

xxxxxxxxxx
sensor.set_hmirror(enable)

parameter

Parameter namedescribeInput/Output
enableTrueEnable horizontal mirror function FalseDisable horizontal mirror functionenter

Return Value

Return Valuedescribe
none

Example

xxxxxxxxxx
sensor.set_hmirror(True)

2.5 sensor.set_vflip

describe

Configure whether the image sensor is flipped vertically.

grammar

xxxxxxxxxx
sensor.set_vflip(enable)

parameter

Parameter namedescribeInput/Output
enableTrueTurn on the vertical flip function FalseTurn off the vertical flip functionenter

Return Value

Return Valuedescribe
none

Example

xxxxxxxxxx
sensor.set_vflip(True)

2.6 sensor.run

describe

Enables output of the image sensor. This must be done before calling .MediaManager.init()

grammar

xxxxxxxxxx
sensor.run()

Return Value

Return Valuedescribe
none

Precautions

  • When multiple sensors (up to 3) are used simultaneously, only one of them runneeds to be executed.

Example

# Start the sensor device output data stream
sensor.run()

2.7 sensor.stop

describe

Stops image sensor output. This method must be called before .MediaManager.deinit()

grammar

xxxxxxxxxx
sensor.stop()

Return Value

Return Valuedescribe
none

Precautions

  • If multiple image sensors are used simultaneously (maximum 3), each sensor must be called separatelystop .

Example

# Stop the data stream output of sensor device 0
sensor.stop()

2.8 sensor.snapshot

describe

Capture a frame of image data from the specified output channel.

grammar

xxxxxxxxxx
sensor.snapshot(chn=CAM_CHN_ID_0)

parameter

Parameter namedescribeInput/Output
chnSensor output channel numberenter

Return Value

Return Valuedescribe
image objectCaptured image data
otherCapture failed

Example

xxxxxxxxxx
# Capture a frame of image data from channel 0 of sensor device 0
sensor.snapshot()
Touch Display
Image Flip

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文