yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
K230 Vision Module📖
1. Quick Start
  • 0.Get start
  • 1. K230 firmware download and burning
  • 2. Install the programming environment
  • 3. Debug and run routines
  • 4. Offline running routine
  • 5. Micropython Quick Start
  • 6. GUI Program Instructions
  • 7.K230 module bracket installation tutorial
  • 8.K230 module 2DOF PTZ installation tutorial
2. Basic Courses
  • 1.FPIOA pin assignment
  • 2.RGB lights
  • 3.Buzzer
  • 4.Buttons
  • 5.Serial communication
  • 6.I2C communication
  • 7.PWM
  • 8.WDT watchdog
  • 9.Timer
  • 10.Fourier Transform
  • 11.SHA256 encryption
  • 12.AES encryption
  • 13.Multithreading
  • 14.File reading and writing
  • 15.Image Display
  • 16.Touch Display
  • 17.Camera display
  • 18.Image Flip
  • 19.Camera
3. Draw the image
  • 1. Draw the lines
  • 2. Draw the circle
  • 3. Draw the rectangle
  • 4. Draw the ellipse
  • 5. Draw the arrow
  • 6. Draw the crosshairs
  • 7. Draw text
  • 8. Draw key points
4. Graphics detection
  • 1. Line segment detection
  • 2. Rectangle Detection
  • 3. Circle detection
  • 4. Object edge detection
  • 5. Line inspection basics:fast linear regression
5. Color recognition
  • 1. Color recognition
  • 2. Object Counting
  • 3. Multi-color recognition
  • 4. K230 Color Line Patrol
6.1 CV_lite Image Processing Special Topic
  • 1.Introduction to cv_litenew
  • 2.cv_lite API Reference Manualnew
  • 3.Color Block Recognition - Grayscale Imagenew
  • 4.Color Block Recognition - Color Imagenew
  • 5.Circle Recognition - Grayscale Imagenew
  • 6.Circle Recognition - Color Imagenew
  • 7.Corner Recognition - Grayscale Imagenew
  • 8.Corner Recognition - Color Imagenew
  • 9.Edge Recognition - Grayscale Imagenew
  • 10. Edge Recognition - Color Imagenew
  • 11. Rectangle Recognition - Grayscale Imagenew
  • 12.Rectangle Recognition - Color Imagenew
  • 13.Rectangle recognition combined with corner recognition - grayscale imagenew
  • 14.Rectangle recognition combined with corner recognition - color imagenew
  • 15.Image Binarization - Grayscalenew
  • 16.Image Binarization - Color Imagenew
  • 17.Exposure Adjustmentnew
  • 18.Image Black Hat Operationsnew
  • 19.Image Color Histogramnew
  • 20.Image Closingnew
  • 21.Image Expansionnew
  • 22.Image Corrosionnew
  • 23.Gaussian Blurnew
  • 24.Gradient Transformationnew
  • 25.Mean Fuzzynew
  • 26.Image Openingnew
  • 27.Image Top Hat Operationnew
  • 28.PnP rangingnew
  • 29.Find rectangles and measure distancesnew
  • 30.Image grayscale world white balancenew
6.2 OpenCV Image Processing Special Topicnew
  • 1. OpenCV Introduction
  • 2. OpenCV API Reference
  • 3. Image Basic Transforms
  • 4. Morphological Operations
  • 5. Color Segmentation and Shape Classification
  • 6. Corner and Centroid Detection
  • 7. Hough Circle Detection
  • 8. Hough Line Detection
  • 9. Contour Analysis
  • 10. Drawing Functions
  • 11. Template Matching
  • 12. Image Blur Filtering
  • 13. Edge Detection
  • 14. Thresholding
  • 15. Color Segmentation
  • 16. Histogram and Pixel Transformation
  • 17. Arithmetic and Bitwise Operations
  • 18. Channel Operation and Statistics
  • 19. Image File Read and Write
  • 20. Pixel Level Transformation
7. Code type recognition
  • 1.Barcode recognition
  • 2.QR code recognition
  • 3.AprilTag tag recognition
  • 4.DM code recognition
8. Face Recognition
  • 1.[Must-read] General code structure and prerequisite knowledge of AI vision routines
  • 2.Face Detection
  • 3.Facial key point recognition
  • 4.Face orientation detection
  • 5.Face 3D Network
  • 6.Gaze direction detection
  • 7.Register for face recognition
9. Human body characteristics
  • 1. Human body detection
  • 2. Human key point detection
  • 3. Human posture recognition
  • 4. Fall detection
  • 5. Palm detection
  • 6. Palm key point detection
  • 7. Palm key point classification
  • 8. Gesture Recognition
  • 9. Dynamic gesture recognition
  • 10. Rock, Paper, Scissors
10. Scenario Application
  • 1.OCR character detection
  • 2.OCR character recognition
  • 3.yolov8n target detection
  • 4.yolov8n segmentation
  • 5. Self-learning object recognition
  • 6. License plate detection
  • 7. License Plate Recognition
  • 8. Target Tracking
  • 9. Fruit classification
  • 10. Garbage classification
  • 11. Road sign recognition
11. Audio and video processing
  • 1. Audio Recording
  • 2. Play Audio
  • 3. Video Recording
  • 4. Play Video
  • 5. Keyword wake-up
12. Network Basics
  • 1. Wireless network connection
  • 2. AP hotspot mode
  • 3. TCP-Server Example
  • 4. TCP-Client Example
  • 5. UDP-Server Example
  • 6. UDP-Client Example
  • 7. HTTP-Server Example
  • 8. HTTP-Client Example
  • 9. MQTT Quick Start
  • 10. MQTT-Publisher
  • 11. MQTT-Subscriber
  • 12. RTSP real-time image transmission
  • 13. RTSP real-time image transmission combined with AIDemo
  • 14. Call OpenRouter large model aggregation service
  • 15. Open the Resource Monitoring Panel
13. LVGL Graphical Interface
  • 1. Introduction to LVGL
  • 2. Create a button
  • 3. Create a slider
  • 4. Create an Image
  • 5. Create a text box and keyboard
14. GUI Code Tutorial & Secondary Development
  • 01.GUI System Architecture
  • 02.Core Engine Initialization
  • 03.Application Discovery Mechanism in GUI
  • 04.Desktop Layout Algorithm
  • 05.Advanced UI Styling
  • 06.BaseApp Base Class Analysis
  • 07.Hello_World Practical
  • 08.GUI Application Lifecycle and Resource Management
15. Train your own model
  • 1. Local deployment of yolo training environment
  • 2. Use online platforms for training
16.Touch Course
  • 1.Touch point detectionnew
  • 2.Touch Paintingnew
  • 3.Touch to take a photonew
17. Multi-master communication (purchased separately)
ESP32-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
Jetson-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
MSPM0G3507-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
Pico-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
raspberrypi-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
RDK-K230
  • 1.k230 color recognition
  • 2.k230 barcode recognition
  • 3.k230 QR code recognition
  • 4.k230Apriltag code recognition
  • 5.k230DM code recognition
  • 6.k230 face detection
  • 7.k230 gaze direction
  • 8.k230 face recognition
  • 9.k230 human body detection
  • 10.k230 fall detection
  • 11.k230 palm detection
  • 12.k230 gesture recognition
  • 13.k230OCR character recognition
  • 14.k230 object detection
  • 15.k230 target tracking
  • 16.k230 self-learning object recognition
  • 17.k230 license plate recognition
STM32-K230
  • 1. stm32_k230 color recognition
  • 2. stm32_k230 barcode recognition
  • 3. stm32_k230 QR code recognition
  • 4. stm32_k230Apriltag code recognition
  • 5. stm32_k230DM code recognition
  • 6. stm32_k230 face detection
  • 7.stm32_k230 looking direction
  • 8. stm32_k230 face recognition
  • 9. stm32_k230 human body detection
  • 10. stm32_k230 fall detection
  • 11. stm32_k230 palm detection
  • 12. stm32_k230 gesture recognition
  • 13. stm32_k230OCR character recognition
  • 14. stm32_k230 object detection
  • 15. stm32_k230 target tracking
  • 16. stm32_k230 self-learning object recognition
  • 17.stm32_k230 license plate recognition
Arduino-K230
  • 1.arduino_k230 color recognition
  • 2.arduino_k230 barcode recognition
  • 3.arduino_k230 QR code recognition
  • 4.arduino_k230 Apriltag code recognition
  • 5.arduino_k230 DM code recognition
  • 6.arduino_k230 face detection
  • 7.arduino_k230 looking direction
  • 8.arduino_k230 face recognition
  • 9.arduino_k230 human body detection
  • 10.arduino_k230 fall detection
  • 11.arduino_k230 palm detection
  • 12.arduino_k230 gesture recognition
  • 13.arduino_k230 OCR character recognition
  • 14.arduino_k230 object detection
  • 15.arduino_k230 target tracking
  • 16.arduino_k230 self-learning object recognition
  • 17.arduino_k230 license plate recognition
Microbit-K230
  • 1.microbit_k230 color recognition
  • 2.microbit_k230 barcode recognition
  • 3.microbit_k230 QR code recognition
  • 4.microbit_k230 Apriltag code recognition
  • 5.microbit_k230 DM code recognition
  • 6.microbit_k230 face detection
  • 7.microbit_k230 looking direction
  • 8.microbit_k230 face recognition
  • 9.microbit_k230 human body detection
  • 10.microbit_k230 fall detection
  • 11.microbit_k230 palm detection
  • 12.microbit_k230 gesture recognition
  • 13.microbit_k230 OCR character recognition
  • 14.microbit_k230 object detection
  • 15.microbit_k230 target tracking
  • 16.microbit_k230 self-learning object recognition
  • 17.microbit_k230 license plate recognition
MSPM0G3519-K230
  • 1. K230 Color Recognitionnew
  • 2. K230 Barcode Recognitionnew
  • 3. K230 QR Code Recognitionnew
  • 4. K230 Apriltag Code Recognitionnew
  • 5. K230 DM Code Recognitionnew
  • 6. K230 Face Detectionnew
  • 7. K230 Gaze Directionnew
  • 8. K230 Face Recognitionnew
  • 9. K230 Human Body Detectionnew
  • 10. K230 Fall Detectionnew
  • 11. K230 Palm Detectionnew
  • 12. K230 Gesture Recognitionnew
  • 13. K230 OCR Character Recognitionnew
  • 14. K230 Object Detectionnew
  • 15. K230 Target Trackingnew
  • 16. K230 Self-learning Object Recognitionnew
  • 17. K230 License Plate Recognitionnew
18.Extension case (purchase separately)
For 2DOF Electric Platform
  • 1.Moving target control and automatic tracking system
  • 2.Human body recognition alarm
  • 3.Gesture Recognition
  • 4.Rock Paper Scissors
  • 5.Fruit sorting
  • 6.Color Tracking
  • 7.Face Tracking
MSPM0G3507 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual tracking
  • 2.Color tracking
  • 3.Color response
  • 4.Road sign recognition
  • 5.Machine code tracking
  • 6.QR code recognition action
  • 7.Autonomous avoid
  • 8.License plate tracking
  • 9.Face tracking
  • 10.Gaze direction tracking
  • 11.Palm tracking
  • 12.Target tracking
  • 13.Human body tracking
  • 14.OCR character recognition action
STM32 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual tracking
  • 2.Color tracking
  • 3.Color response
  • 4.Road sign recognition
  • 5.Machine code tracking
  • 6.QR code recognition action
  • 7.Autonomous avoid
  • 8.License plate tracking
  • 9.Face tracking
  • 10.Gaze direction tracking
  • 11.Palm tracking
  • 12.Target tracking
  • 13.Human body tracking
  • 14.OCR character recognition action
MSPM0G3519 wheeled chassis V1/V2 combined with K230 application case
  • 1.Visual trackingnew
  • 2.Color trackingnew
  • 3.Color responsenew
  • 4.Road sign recognitionnew
  • 5.Machine code trackingnew
  • 6.QR code recognition actionnew
  • 7.Autonomous avoidnew
  • 8.License plate trackingnew
  • 9.Face trackingnew
  • 10.Gaze direction trackingnew
  • 11.Palm trackingnew
  • 12.Target trackingnew
  • 13.Human body trackingnew
  • 14.OCR character recognition actionnew
19. Expansion case(purchase separately)new
  • 1.Motion target control and Auto track system
  • 2.Vehicle-mounted balance ball motion control system
Download
  • Manual
  • CanMV IDE
  • Software Tools
  • Firmware
  • Source Code
  • Appendix
Download ZIP

Welcome to K230 Vision Module repository

9. Dynamic gesture recognition

Dynamic gesture recognition

Dynamic gesture recognitionRoutine Experiment EffectCode ExplanationGesture recognition key codeflow chart


Routine Experiment Effect

In this section, we will learn how to use K230 to realize the human body detection function.

The example code is in [Source code/08.Body/09.dynamic_gesture.py]

After connecting to the IDE, run the code and wait for the routine to run and load the model. (It takes about 8 to 10 seconds)
image-20250214211026973

After waiting for the routine to run and load the model, we put our hand in front of the camera and wait for the gesture icon to appear in the upper left corner. The appearance of this icon means that K230 is ready to recognize gestures, and we can perform the corresponding gesture waving behavior. The specific operation can be seen in the following animation:

1

Serial port output function has been added

After detecting the gesture, the following serial output format will be sent

$dir#

The '$' represents the beginning of the data, and the '#' represents the end of the data.

dir is the direction, 0 is up, 1 is left, 2 is down, 3 is right, 4 is unchanged

*Note: The current code will send multiple serial port data when a gesture is recognized. You can filter it on the receiving end.

Code Explanation

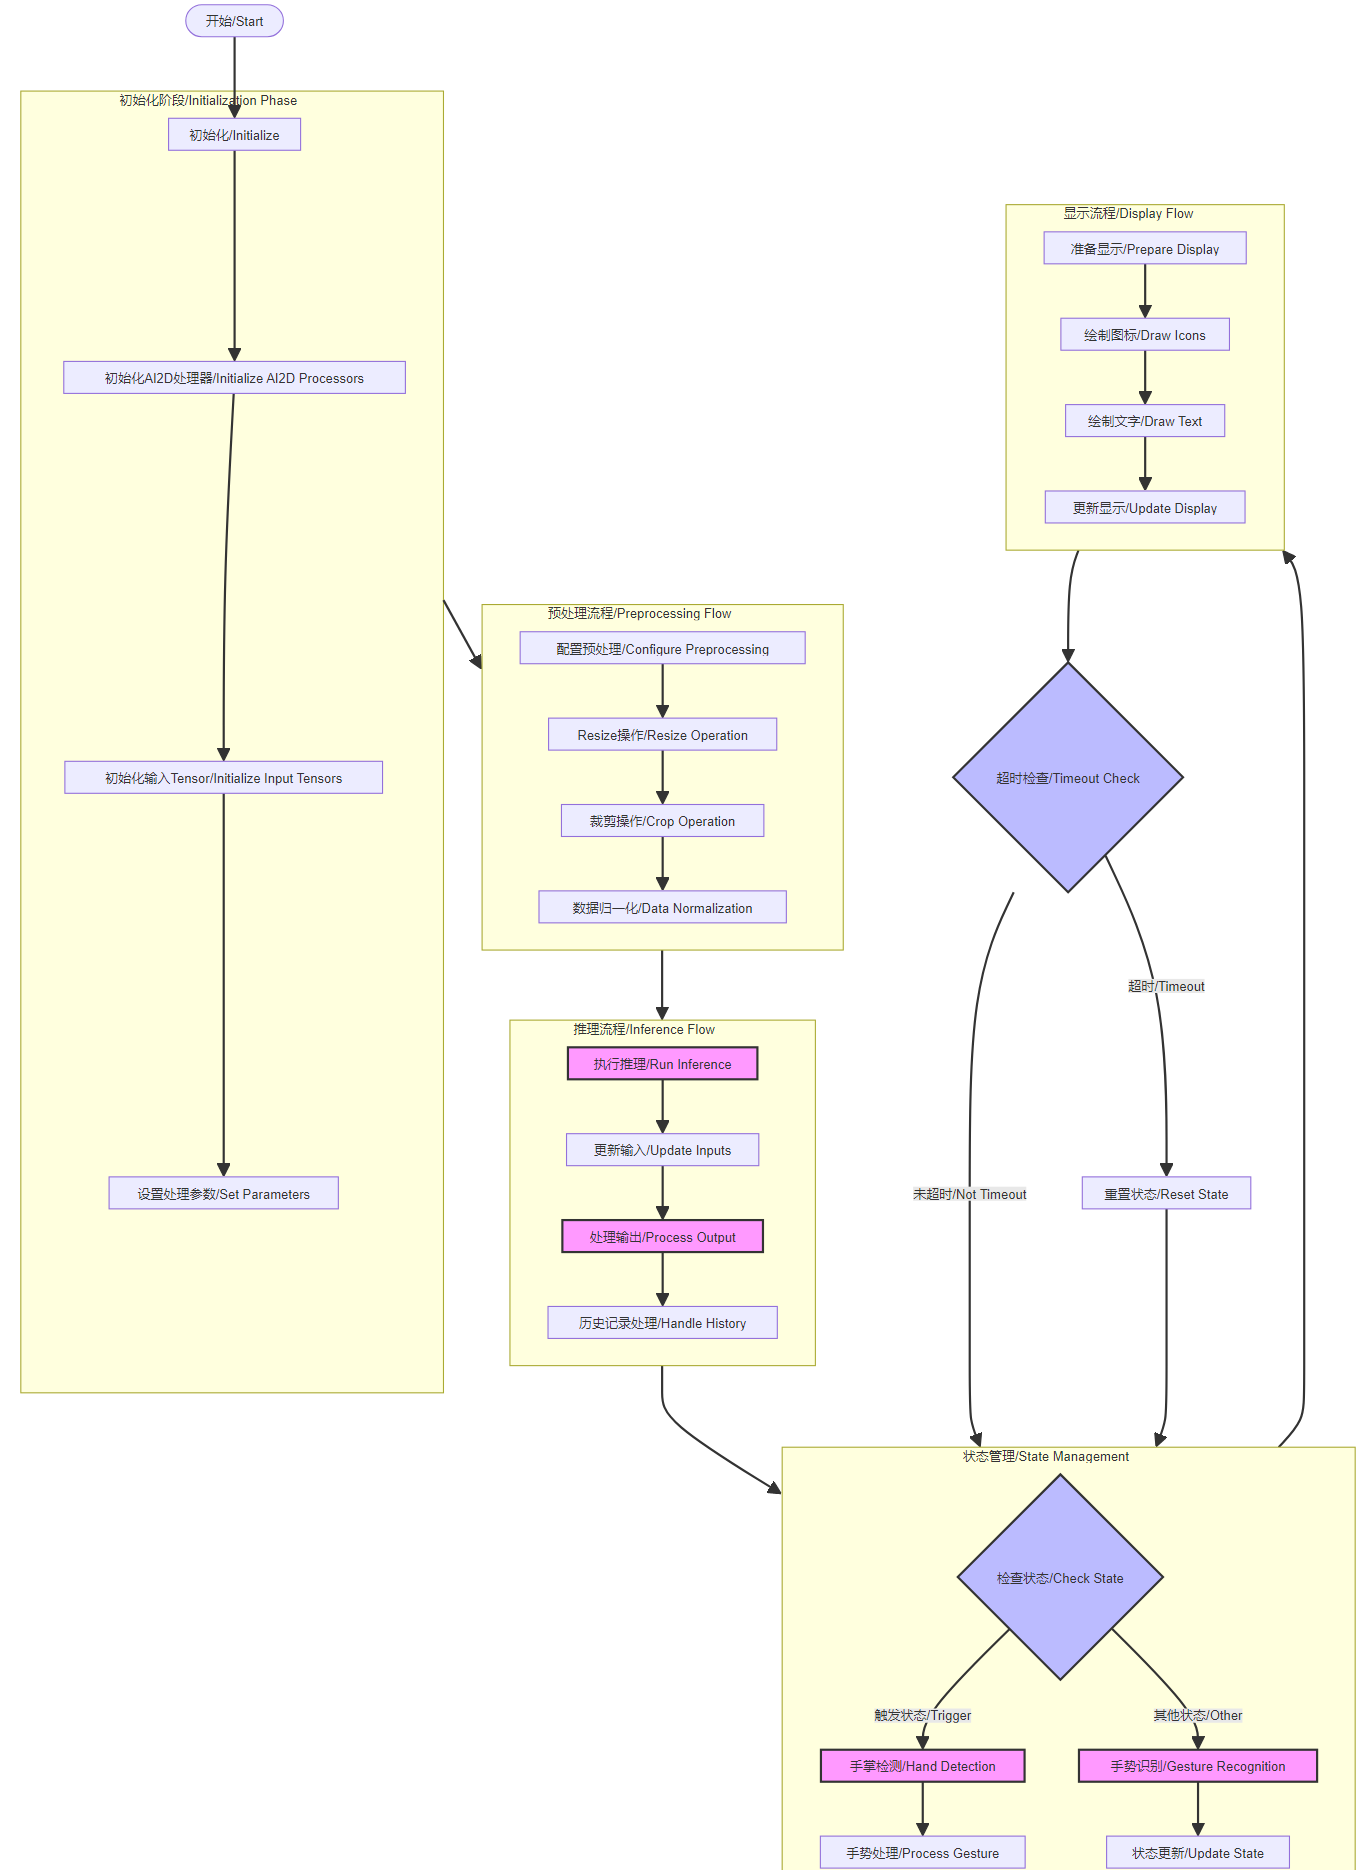
There is too much complete code in this section, so only the key parts of the code are explained here

Gesture recognition key code

xxxxxxxxxx
    def run(self, input_np):
​
        """
        运行手势识别 / Run gesture recognition
​
        参数 / Parameter:
        input_np: 输入图像 / Input image
​
        返回 / Returns:
        根据当前状态返回检测结果或识别结果 / Returns detection or recognition results based on current state
        """
        if self.cur_state == self.TRIGGER:
            # 手掌检测模式 / Hand detection mode
            det_boxes = self.hand_det.run(input_np)
            boxes = []
            gesture_res = []
​
            for det_box in det_boxes:
                # 获取检测框坐标 / Get detection box coordinates
                x1, y1, x2, y2 = det_box[2], det_box[3], det_box[4], det_box[5]
                w, h = int(x2 - x1), int(y2 - y1)
​
                # 过滤无效检测框 / Filter invalid detection boxes
                if (h < (0.1 * self.rgb888p_size[1])):
                    continue
                if (w < (0.25 * self.rgb888p_size[0]) and
                    ((x1 < (0.03 * self.rgb888p_size[0])) or
                     (x2 > (0.97 * self.rgb888p_size[0])))):
                    continue
                if (w < (0.15 * self.rgb888p_size[0]) and
                    ((x1 < (0.01 * self.rgb888p_size[0])) or
                     (x2 > (0.99 * self.rgb888p_size[0])))):
                    continue
​
                # 执行关键点检测 / Perform keypoint detection
                self.hand_kp.config_preprocess(det_box)
                hk_results, gesture_str = self.hand_kp.run(input_np)
                boxes.append(det_box)
                gesture_res.append((hk_results, gesture_str))
​
            return boxes, gesture_res
        else:
            # 动态手势识别模式 / Dynamic gesture recognition mode
            idx, avg_logit = self.dg.run(input_np, self.his_logit, self.history)
            return idx, avg_logit
​
    def draw_result(self, pl, output1, output2):
        """
        绘制识别结果 / Draw recognition results
​
        参数 / Parameters:
        pl: 绘图层对象 / Drawing layer object
        output1: 第一阶段输出(检测框) / First stage output (detection boxes)
        output2: 第二阶段输出(关键点和手势) / Second stage output (keypoints and gestures)
        """
        # 清空绘图缓存 / Clear drawing cache
        pl.osd_img.clear()
        draw_img_np = np.zeros((self.display_size[1], self.display_size[0], 4), dtype=np.uint8)
        draw_img = image.Image(self.display_size[0], self.display_size[1],
                            image.ARGB8888, alloc=image.ALLOC_REF, data=draw_img_np)
​
        if self.cur_state == self.TRIGGER:
            # 触发状态下的处理 / Processing in trigger state
            for i in range(len(output1)):
                hk_results, gesture = output2[i][0], output2[i][1]
​
                # 检测到"five"或"yeah"手势 / Detect "five" or "yeah" gesture
                if ((gesture == "five") or (gesture == "yeah")):
                    # 计算手势方向向量 / Calculate gesture direction vector
                    v_x = hk_results[24] - hk_results[0]
                    v_y = hk_results[25] - hk_results[1]
                    angle = self.hand_kp.hk_vector_2d_angle([v_x,v_y], [1.0,0.0])
                    if (v_y > 0):
                        angle = 360 - angle
​
                    # 根据角度判断手势方向 / Determine gesture direction based on angle
                    if ((70.0 <= angle) and (angle < 110.0)):  # 向上 / Upward
                        if ((self.pre_state != self.UP) or (self.pre_state != self.MIDDLE)):
                            self.vec_flag.append(self.pre_state)
                        if ((len(self.vec_flag) > 10) or (self.pre_state == self.UP) or
                            (self.pre_state == self.MIDDLE) or (self.pre_state == self.TRIGGER)):
                            draw_img_np[:self.bin_height,:self.bin_width,:] = self.shang_argb
                            self.cur_state = self.UP
​
                    elif ((110.0 <= angle) and (angle < 225.0)):  # 向右 / Rightward
                        if (self.pre_state != self.RIGHT):
                            self.vec_flag.append(self.pre_state)
                        if ((len(self.vec_flag) > 10) or (self.pre_state == self.RIGHT) or
                            (self.pre_state == self.TRIGGER)):
                            draw_img_np[:self.bin_width,:self.bin_height,:] = self.you_argb
                            self.cur_state = self.RIGHT
​
                    elif((225.0 <= angle) and (angle < 315.0)):  # 向下 / Downward
                        if (self.pre_state != self.DOWN):
                            self.vec_flag.append(self.pre_state)
                        if ((len(self.vec_flag) > 10) or (self.pre_state == self.DOWN) or
                            (self.pre_state == self.TRIGGER)):
                            draw_img_np[:self.bin_height,:self.bin_width,:] = self.xia_argb
                            self.cur_state = self.DOWN
​
                    else:  # 向左 / Leftward
                        if (self.pre_state != self.LEFT):
                            self.vec_flag.append(self.pre_state)
                        if ((len(self.vec_flag) > 10) or (self.pre_state == self.LEFT) or
                            (self.pre_state == self.TRIGGER)):
                            draw_img_np[:self.bin_width,:self.bin_height,:] = self.zuo_argb
                            self.cur_state = self.LEFT
​
                    self.m_start = time.time_ns()
                self.his_logit = []
​
        else:
            # 非触发状态下的处理 / Processing in non-trigger state
            idx, avg_logit = output1, output2[0]
​
            # 处理不同状态下的手势动作 / Handle gesture actions in different states
            if (self.cur_state == self.UP):
                draw_img_np[:self.bin_height,:self.bin_width,:] = self.shang_argb
                if ((idx == 15) or (idx == 10)):  # 向上挥动确认 / Upward wave confirmation
                    self.vec_flag.clear()
                    if (((avg_logit[idx] >= 0.7) and (len(self.his_logit) >= 2)) or
                        ((avg_logit[idx] >= 0.3) and (len(self.his_logit) >= 4))):
                        self.s_start = time.time_ns()
                        self.cur_state = self.TRIGGER
                        self.draw_state = self.DOWN
                        self.history = [2]
                    self.pre_state = self.UP
                elif ((idx == 25) or (idx == 26)):  # 中间位置确认 / Middle position confirmation
                    self.vec_flag.clear()
                    if (((avg_logit[idx] >= 0.4) and (len(self.his_logit) >= 2)) or
                        ((avg_logit[idx] >= 0.3) and (len(self.his_logit) >= 3))):
                        self.s_start = time.time_ns()
                        self.cur_state = self.TRIGGER
                        self.draw_state = self.MIDDLE
                        self.history = [2]
                    self.pre_state = self.MIDDLE
                else:
                    self.his_logit.clear()
​
            # 处理其他方向的状态(RIGHT/DOWN/LEFT)的逻辑类似
            # Similar logic for other directional states (RIGHT/DOWN/LEFT)
            elif (self.cur_state == self.RIGHT):
                draw_img_np[:self.bin_width,:self.bin_height,:] = self.you_argb
                if  ((idx==16)or(idx==11)) :
                    self.vec_flag.clear()
                    if (((avg_logit[idx] >= 0.4) and (len(self.his_logit) >= 2)) or ((avg_logit[idx] >= 0.3) and (len(self.his_logit) >= 3))):
                        self.s_start = time.time_ns()
                        self.cur_state = self.TRIGGER
                        self.draw_state = self.RIGHT
                        self.history = [2]
                    self.pre_state = self.RIGHT
                else:
                    self.his_logit.clear()
            elif (self.cur_state == self.DOWN):
                draw_img_np[:self.bin_height,:self.bin_width,:] = self.xia_argb
                if  ((idx==18)or(idx==13)):
                    self.vec_flag.clear()
                    if (((avg_logit[idx] >= 0.4) and (len(self.his_logit) >= 2)) or ((avg_logit[idx] >= 0.3) and (len(self.his_logit) >= 3))):
                        self.s_start = time.time_ns()
                        self.cur_state = self.TRIGGER
                        self.draw_state = self.UP
                        self.history = [2]
                    self.pre_state = self.DOWN
                else:
                    self.his_logit.clear()
            elif (self.cur_state == self.LEFT):
                draw_img_np[:self.bin_width,:self.bin_height,:] = self.zuo_argb
                if ((idx==17)or(idx==12)):
                    self.vec_flag.clear()
                    if (((avg_logit[idx] >= 0.4) and (len(self.his_logit) >= 2)) or ((avg_logit[idx] >= 0.3) and (len(self.his_logit) >= 3))):
                        self.s_start = time.time_ns()
                        self.cur_state = self.TRIGGER
                        self.draw_state = self.LEFT
                        self.history = [2]
                    self.pre_state = self.LEFT
                else:
                    self.his_logit.clear()
​
            self.elapsed_time = round((time.time_ns() - self.m_start)/1000000)
​
            # 超时处理 / Timeout handling
            if ((self.cur_state != self.TRIGGER) and (self.elapsed_time > 2000)):
                self.cur_state = self.TRIGGER
                self.pre_state = self.TRIGGER
​
        # 绘制结果显示 / Draw result display
        self.elapsed_ms_show = round((time.time_ns()-self.s_start)/1000000)
        if (self.elapsed_ms_show < 1000):
            # 根据不同状态绘制不同的箭头和文字 / Draw different arrows and text based on state
            if (self.draw_state == self.UP):
                draw_img.draw_arrow(self.display_size[0]//2, self.display_size[1]//2,
                                self.display_size[0]//2, self.display_size[1]//2-100,
                                (155,170,190,230), thickness=13)
                draw_img.draw_string_advanced(self.display_size[0]//2-50,
                                            self.display_size[1]//2-50, 32, "向上 UP")
            elif (self.draw_state == self.LEFT):
                draw_img.draw_arrow(self.display_size[0]//2, self.display_size[1]//2,
                                self.display_size[0]//2-100, self.display_size[1]//2,
                                (155,170,190,230), thickness=13)
                draw_img.draw_string_advanced(self.display_size[0]//2-50,
                                            self.display_size[1]//2-50, 32, "向左 LEFT")
            elif (self.draw_state == self.DOWN):
                draw_img.draw_arrow(self.display_size[0]//2,self.display_size[1]//2,self.display_size[0]//2,self.display_size[1]//2+100, (155,170,190,230), thickness=13)                             # 判断为向下挥动时,画一个向下的箭头
                draw_img.draw_string_advanced(self.display_size[0]//2-50,self.display_size[1]//2-50,32,"向下 DOWN")
            elif (self.draw_state == self.RIGHT):
                draw_img.draw_arrow(self.display_size[0]//2,self.display_size[1]//2,self.display_size[0]//2+100,self.display_size[1]//2, (155,170,190,230), thickness=13)                               # 判断为向左挥动时,画一个向左的箭头
                draw_img.draw_string_advanced(self.display_size[0]//2-50,self.display_size[1]//2-50,32,"向右 RIGHT")
            elif (self.draw_state == self.MIDDLE):
                draw_img.draw_circle(self.display_size[0]//2,self.display_size[1]//2,100, (255,170,190,230), thickness=2, fill=True)                       # 判断为五指捏合手势时,画一个实心圆
                draw_img.draw_string_advanced(self.display_size[0]//2-50,self.display_size[1]//2-50,32,"中间 MIDDLE")
        else:
            self.draw_state = self.TRIGGER
​
        # 更新显示 / Update display
        pl.osd_img.copy_from(draw_img)

flow chart

image-20250214211753224

Gesture Recognition
Rock, Paper, Scissors

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文