Welcome to K230 Vision Module repository
12. Image Blur Filtering
Image Blur Filtering
Image Blur FilteringPrefaceExample ResultsPrinciple ExplanationWhy Filtering is NeededCode OverviewInitialize Camera and Display ModuleCreate Sharpening Kernel and Set ModeExecute FilteringWrite Back to Original Frame and DisplayGarbage Collection and Resource ReleaseParameter Adjustment Notes
Preface
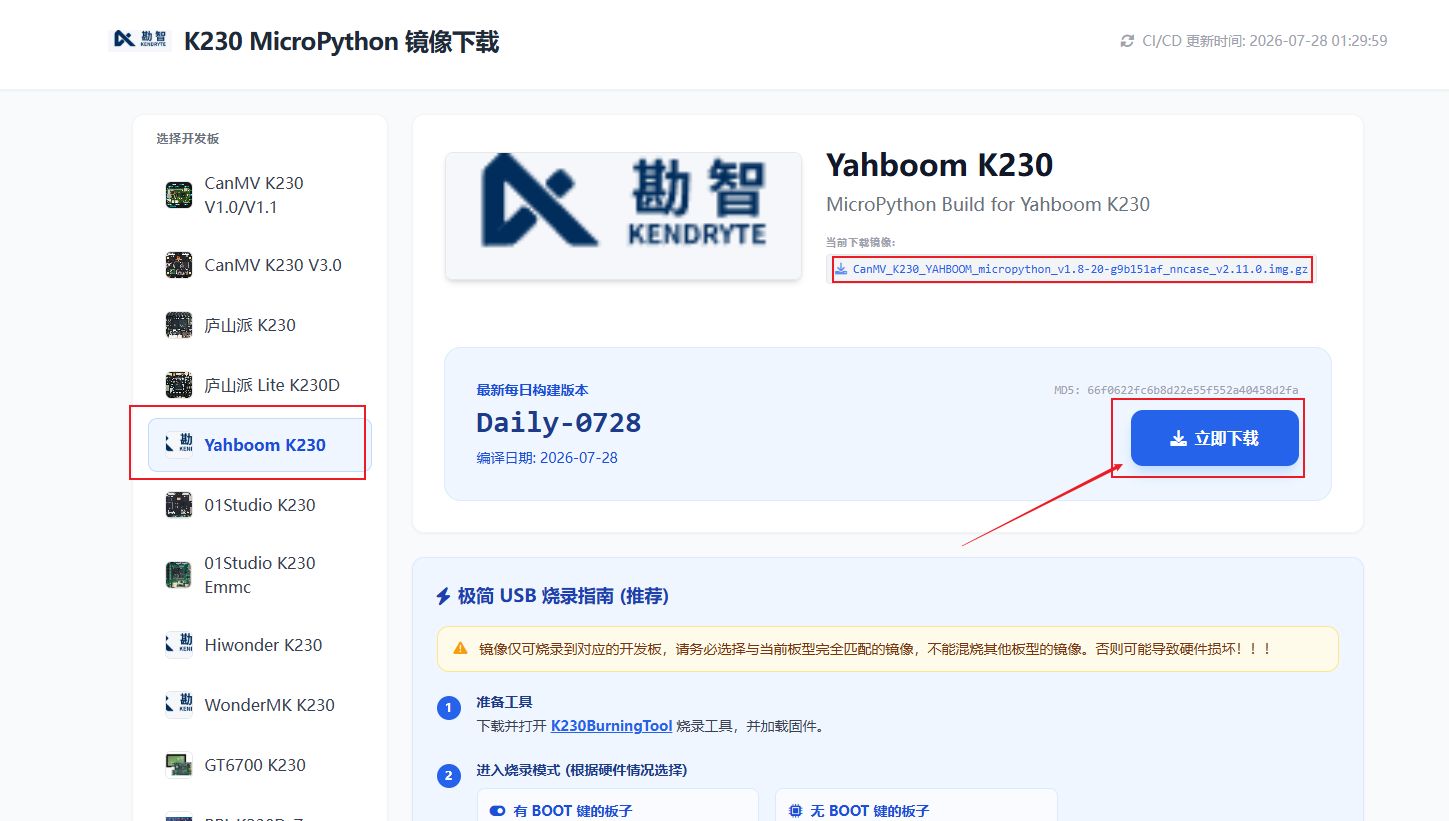
This tutorial applies to firmware version: CanMV_K230_YAHBOOM_micropython_v1.8-13. You can download it from the Jianan website https://download.kendryte.com/developer/releases/canmv_k230_micropython/daily_build/
Example Results
Run the example code for this section 10.camera_filter_blur.py.
This section demonstrates Gaussian, mean, median, bilateral, box filtering, and custom sharpening kernels on a 640×480 live image. Changing the mode allows you to compare the visual effects and frame rates of different filtering methods.
Principle Explanation
Why Filtering is Needed
Image filtering computes new pixel values from neighboring pixels, which can be used for denoising, smoothing, edge preservation, or sharpening. Different methods have varying effects on noise types, edges, and computation load.
| Method | Key Feature | Common Uses |
|---|---|---|
| Gaussian Filter | Closer to center means higher weight | Random noise, edge detection preprocessing |
| Mean Filter | Equal weight averaging of neighbors | Fast smoothing |
| Median Filter | Takes median of neighbors | Salt and pepper noise |
| Bilateral Filter | Considers both spatial distance and color difference | Edge-preserving denoising |
| Box Filter | Rectangular neighbor sum or average | Fast local statistics |
| Custom Convolution | Uses specified weight matrix | Sharpening, edge enhancement, etc. |
Larger filter kernels provide wider smoothing range but also increase computation and temporary array overhead.
Code Overview
Initialize Camera and Display Module
W, H = 640, 480sensor = Sensor(width=1280, height=960, fps=90)sensor.reset()sensor.set_framesize(width=W, height=H)sensor.set_pixformat(Sensor.RGB888)Display.init(Display.ST7701, width=640, height=480, to_ide=True)sensor.run()time.sleep(0.5)Create Sharpening Kernel and Set Mode
xsharpen = np.array([ [-1.0, -1.0, -1.0], [-1.0, 9.0, -1.0], [-1.0, -1.0, -1.0]])mode = 0The sharpening kernel has a center weight of 9 and the surrounding 8 positions are -1, totaling 1, so it enhances local differences while roughly preserving overall brightness.
| mode | Function | Current Parameters |
|---|---|---|
| 0 | GaussianBlur | 7×7, sigma auto, source default |
| 1 | blur | 7×7 |
| 2 | medianBlur | aperture 7 |
| 3 | bilateralFilter | d=7, sigmaColor=50, sigmaSpace=50 |
| 4 | boxFilter | 7×7, normalized |
| 5 | filter2D | 3×3 sharpening kernel |
Execute Filtering
xxxxxxxxxxif mode == 0: out = cv2.GaussianBlur(img_np, (7, 7), 0)elif mode == 1: out = cv2.blur(img_np, (7, 7))elif mode == 2: out = cv2.medianBlur(img_np, 7)elif mode == 3: out = cv2.bilateralFilter(img_np, 7, 50, 50)elif mode == 4: out = cv2.boxFilter(img_np, -1, (7, 7), normalize=True)else: out = cv2.filter2D(img_np, -1, sharpen)ddepth=-1 means the output depth matches the input. Out-of-range results in 8-bit images are handled according to API rules. Pay attention to highlight and dark area saturation when sharpening.
Write Back to Original Frame and Display
xxxxxxxxxximg_np[:, :, :] = outDisplay.show_image(img)The output array is written back to the shared frame for display. If the original image is still needed afterwards, complete related calculations or explicitly copy the required areas before overwriting.
Garbage Collection and Resource Release
xxxxxxxxxxif fc % 10 == 0: gc.collect()finally: sensor.stop() Display.deinit() os.exitpoint(os.EXITPOINT_ENABLE_SLEEP) time.sleep_ms(100)Parameter Adjustment Notes
- Kernel Size: Start with 3×3 or 5×5 for Gaussian, mean, and box filters. 7×7 is the current example value.
- Median Aperture: Should be an odd number greater than 1; larger aperture significantly increases computation.
- Bilateral Filter: Larger sigmaColor means pixels with greater color differences also affect each other; sigmaSpace controls the spatial neighborhood range.
- Sharpening Strength: The current kernel is relatively strong and will also amplify noise. You can reduce the center weight while keeping the kernel weight sum close to 1.
- Frame Rate Comparison: Bilateral and median filtering are usually slower than mean and Gaussian filtering. Test under the same scene and display settings.
- Edge Detection Preprocessing: When you need to reduce noise while preserving edges as much as possible, start with small-kernel Gaussian filtering rather than directly using large-kernel blurring.