Welcome to K230 Vision Module repository
4.k230Apriltag code recognition
k230Apriltag code recognition
k230Apriltag code recognitionk230 and RDK X5 communication1. Experimental Prerequisites2. Experimental wiring3. Main code explanation4. Experimental Phenomenon
k230 and RDK X5 communication
1. Experimental Prerequisites
This tutorial uses the RDK X5 development board, and the corresponding example path is [14.export\RDK-K230\04_k230_apriltag.py].
K230 needs to run the [14.export\CanmvIDE-K230\04.find_apriltag.py] program to start the experiment. It is recommended to download it as an offline program.
Things you need:
Windows computer RDK X5 development board USB to TTL module K230 visual module (including TF card with image burned in) Type-C data cable Connection cable
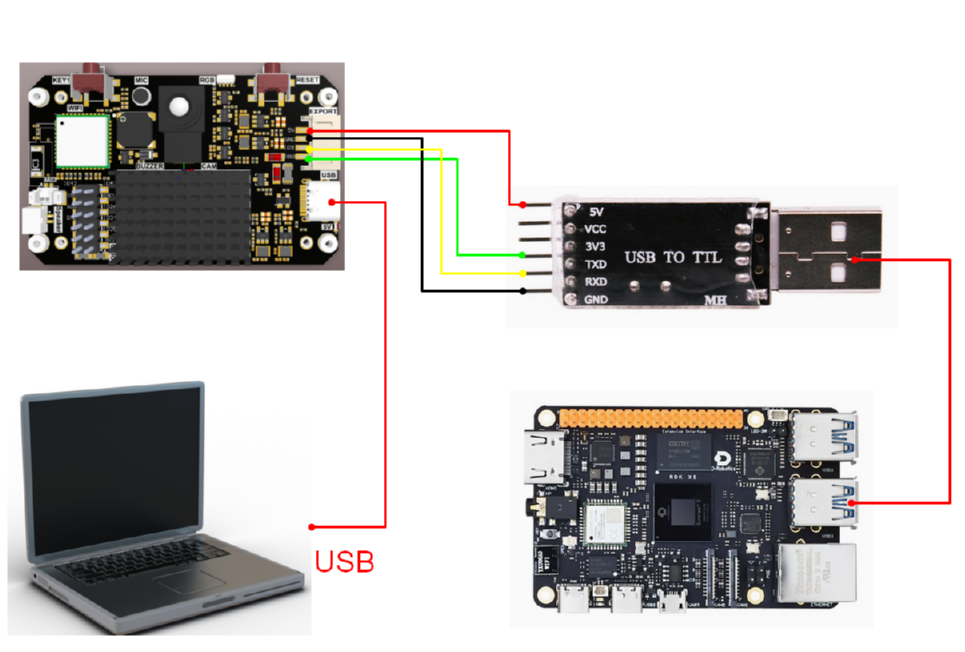
2. Experimental wiring
| k230 vision module | USB to TTL module |
|---|---|
| 5V | VCC |
| GND | GND |
| TXD(IO9) | RxD |
| RXD(IO10) | TXD |
3. Main code explanation
ximport serialcom="/dev/ttyUSB0"ser = serial.Serial(com, 115200)FUNC_ID = 4def parse_data(data): if data[0] == ord('$') and data[len(data)-1] == ord('#'): data_list = data[1:len(data)-1].decode('utf-8').split(',') data_len = int(data_list[0]) data_id = int(data_list[1]) if data_len == len(data) and data_id == FUNC_ID: # print(data_list) x = int(data_list[2]) y = int(data_list[3]) w = int(data_list[4]) h = int(data_list[5]) id = int(data_list[6]) degrees = int(data_list[7]) return x, y, w, h, id, degrees elif (data_len != len(data)): print("data len error:", data_len, len(data)) elif(data_id != FUNC_ID): print("func id error:", data_id, FUNC_ID) return -1, -1, -1, -1, -1, -1while True: if ser.in_waiting: data = ser.readline() # print("rx:", data) x, y, w, h, id, degrees = parse_data(data.rstrip(b'\n')) print("apriltag:x:%d, y:%d, w:%d, h:%d, id:%d, degrees:%d" % (x, y, w, h, id, degrees))The above program is for parsing K230 data. Only when it complies with specific protocols can the corresponding data be parsed.
in
- x: is the horizontal coordinate of the upper left corner of the recognized box
- y: is the vertical coordinate of the upper left corner of the recognized box
- w: is the width of the recognized frame
- h: is the length of the recognized frame
- id: is the tag number of apriltag
- degrees: is the rotation angle of apriltag
4. Experimental Phenomenon
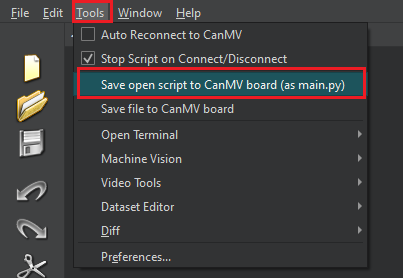
- After connecting the cables, the k230 visual module runs offline. After K230 is connected to Canmv IDE, open the corresponding program, click [Save open script to CanMV board (as main.py)] on the toolbar, and then restart K230.
- Transfer the program file to the system, open the terminal and enter the corresponding directory, then run the following command to start the program.
xxxxxxxxxxpython3 04_k230_apriltag.py
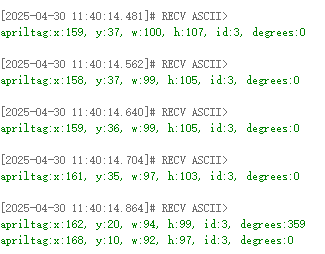
- When the K230 camera image recognizes the AprilTag code, the terminal will parse and print out the information transmitted by the K230.
in
x: is the horizontal coordinate of the upper left corner of the recognized box
y: is the vertical coordinate of the upper left corner of the recognized box
w: is the width of the recognized frame
h: is the length of the recognized frame
id: is the tag number of apriltag
degrees: is the rotation angle of apriltag
As shown in the figure below