Welcome to MicroROS V2 Robot Car repository
5. Lidar Patrol
LiDAR Patrol
1. Course Content
- Run the demo program, set the patrol route in the dynamic parameter tuner, then click start. The robot moves along the configured patrol route, while the LiDAR scans for obstacles within the configured laser angle and obstacle detection distance. If an obstacle is present, the robot stops and the buzzer sounds; if there is no obstacle, it continues patrolling.
2. Demo
xxxxxxxxxxros2 launch microros_v2_bringup lidar_demo.launch.py demo:=laser_patrol
- Click the laser_patrol node in the left options panel of the
rqt_reconfigurepanel. If there is no node in the left options right after startup, click Refresh below to refresh
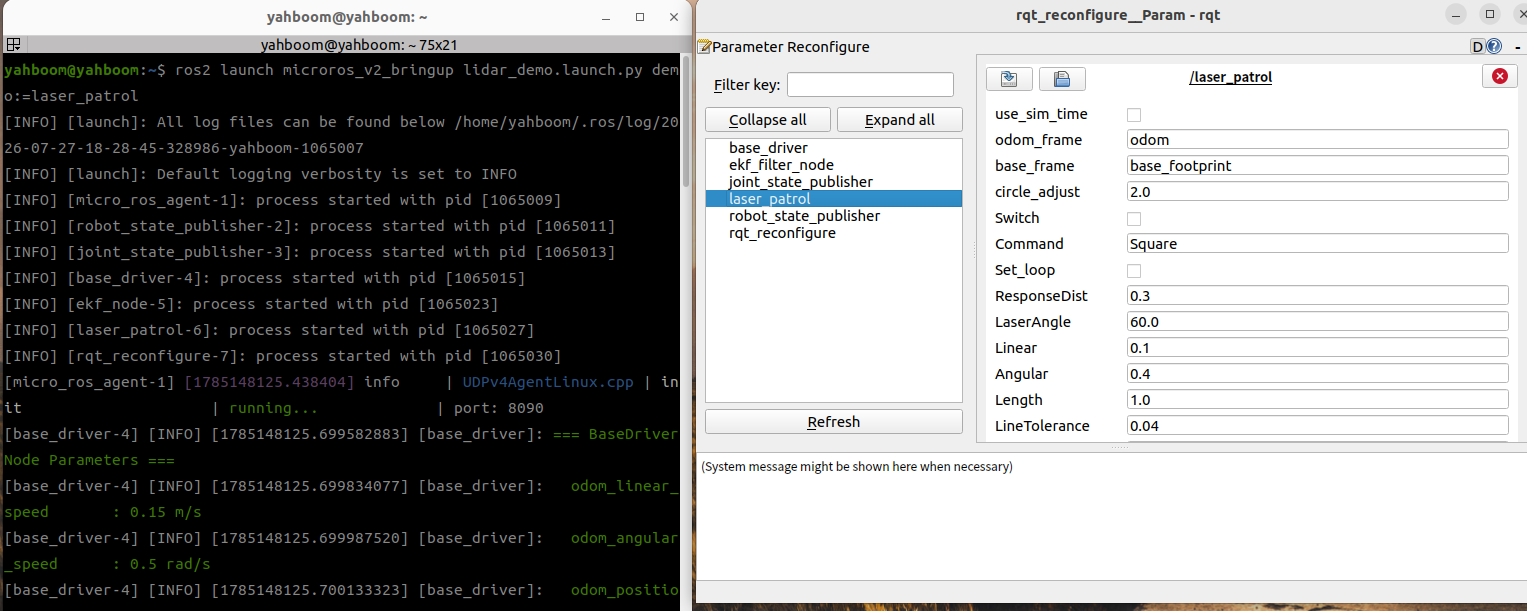
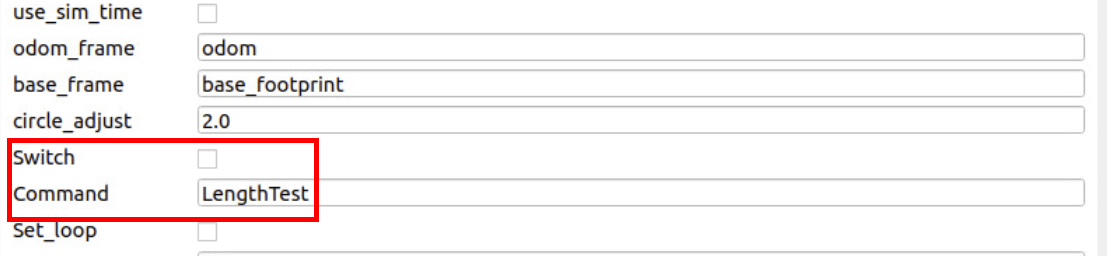
- Fill in the preset patrol route in [Command], then tick Switch to start the robot's patrol state
[!TIP]
rqt_reconfigurepanel parameter descriptions:
odom_frame: name of the odometry coordinate framebase_frame: name of the base coordinate framecircle_adjust: when the patrol route is a circle, this value can be used as a coefficient to adjust the circle size; see the code for detailsSwitch: play mode switchCommand: patrol route, with the following options: [LengthTest] - line patrol, [Circle] - circle patrol, [Square] - square patrol, [Triangle] - triangle patrol.Set_loop: re-patrol switch; when set, the robot will continue looping patrol along the set routeResponseDist: obstacle detection distanceLaserAngle: laser detection angleLinear: linear velocity magnitudeAngular: angular velocity magnitudeLength: straight-line motion distanceRotationTolerance: allowed tolerance for rotation errorLineTolerance: allowed tolerance for straight-line motion error
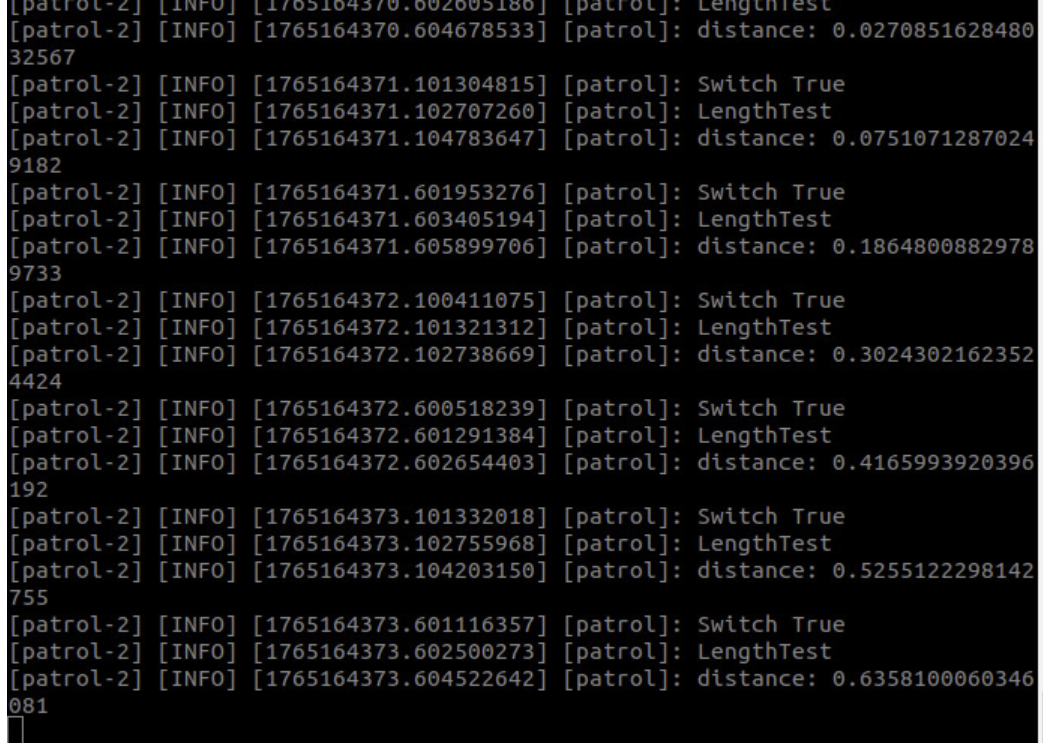
- After setting the route in [Command], click Switch to start patrolling. The terminal prints the following information:
- If there is an obstacle on the patrol path, the robot stops and the terminal displays obstacles

3. Source Code Analysis
Source code path:
xxxxxxxxxx$HOME/microros_ws/src/common_demo/common_demo/lidar/laser_patrol.py
The patrol node uses a timer-driven + state machine architecture, with the following core logic:
Dynamic parameter loading: At the beginning of each cycle, the
on_timercallback reads all configurations from the parameter server (Switch,Command,ResponseDist,Linear,Angular,Length,LaserAngle,LineTolerance,RotationTolerance, etc.), supporting real-time adjustment viarqt_reconfigure.Patrol route dispatch: When
Switch=True, the corresponding patrol mode is selected according to theCommandstring:LengthTest: line patrol, callsadvancing(self.Length)to move forward the specified distanceCircle: circle patrol, callsSpin(360)to rotate 360° in placeSquare: square patrol, callsSquare()to execute the sequence of four sides and four cornersTriangle: triangle patrol, callsTriangle()to execute the sequence of three sides and three corners
Task completion handling: After each patrol function returns
True,Switchis automatically set toFalseandCommandto"finish", entering the stopped state.Loop patrol logic: When
Switch=FalseandCommand="finish":- If
Set_loop=True: restoreCommandto the original route (command_src), setSwitchback toTrue, and continue the next patrol round - If
Set_loop=False: remain in the stopped state without auto-restart
- If
Obstacle avoidance mechanism: Inside each patrol function (
advancing,Spin,Square,Triangle), laser detection is continuously performed. When the distance to an obstacle ahead is ≤ResponseDistand the angle is within ±LaserAngle, the robot immediately stops and triggers the buzzer, then continues executing after the obstacle moves away.
x def on_timer(self): # print("self.error: ",self.error) self.Switch = self.get_parameter("Switch").get_parameter_value().bool_value self.Command = self.get_parameter("Command").get_parameter_value().string_value self.Set_loop = self.get_parameter("Set_loop").get_parameter_value().bool_value self.ResponseDist = ( self.get_parameter("ResponseDist").get_parameter_value().double_value ) self.Linear = self.get_parameter("Linear").get_parameter_value().double_value self.Angular = self.get_parameter("Angular").get_parameter_value().double_value self.Length = self.get_parameter("Length").get_parameter_value().double_value self.LaserAngle = ( self.get_parameter("LaserAngle").get_parameter_value().double_value ) self.LineTolerance = ( self.get_parameter("LineTolerance").get_parameter_value().double_value ) self.RotationTolerance = ( self.get_parameter("RotationTolerance").get_parameter_value().double_value ) self.RotationScaling = ( self.get_parameter("RotationScaling").get_parameter_value().double_value ) index = 0 if self.Switch == True: index = 0 self.get_logger().info("Switch True") if self.Command == "LengthTest": self.command_src = "LengthTest" self.get_logger().info("LengthTest") advancing = self.advancing(self.Length) if advancing == True: self.Switch = rclpy.parameter.Parameter( "Switch", rclpy.Parameter.Type.BOOL, False ) all_new_parameters = [self.Switch] self.set_parameters(all_new_parameters) self.Command = rclpy.parameter.Parameter( "Command", rclpy.Parameter.Type.STRING, "finish" ) all_new_parameters = [self.Command] self.set_parameters(all_new_parameters) elif self.Command == "Circle": self.command_src = "Circle" spin = self.Spin(360) if spin == True: self.get_logger().info("spin done") # self.Command = "finish" self.Switch = rclpy.parameter.Parameter( "Switch", rclpy.Parameter.Type.BOOL, False ) all_new_parameters = [self.Switch] self.set_parameters(all_new_parameters) self.Command = rclpy.parameter.Parameter( "Command", rclpy.Parameter.Type.STRING, "finish" ) all_new_parameters = [self.Command] self.set_parameters(all_new_parameters) elif self.Command == "Square": self.command_src = "Square" square = self.Square() if square == True: self.Command = rclpy.parameter.Parameter( "Command", rclpy.Parameter.Type.STRING, "finish" ) all_new_parameters = [self.Command] self.set_parameters(all_new_parameters) elif self.Command == "Triangle": self.command_src = "Triangle" triangle = self.Triangle() if triangle == True: self.Command = rclpy.parameter.Parameter( "Command", rclpy.Parameter.Type.STRING, "finish" ) all_new_parameters = [self.Command] self.set_parameters(all_new_parameters) else: self.pub_cmdVel.publish(Twist()) self.pub_beep.publish(UInt16(data=0)) self.get_logger().info("Switch False") if self.Command == "finish": self.get_logger().info("finish") if self.Set_loop == True: self.get_logger().info("Continute") self.Command = rclpy.parameter.Parameter( "Command", rclpy.Parameter.Type.STRING, self.command_src ) all_new_parameters = [self.Command] self.set_parameters(all_new_parameters) self.Switch = rclpy.parameter.Parameter( "Switch", rclpy.Parameter.Type.BOOL, True ) all_new_parameters = [self.Switch] self.set_parameters(all_new_parameters) else: self.get_logger().info("Not loop") self.Switch = rclpy.parameter.Parameter( "Switch", rclpy.Parameter.Type.BOOL, False ) all_new_parameters = [self.Switch] self.set_parameters(all_new_parameters)