Welcome to MicroROS V2 Robot Car repository
2. Open Source CV Geometric Transformation
OpenCV Geometric Transforms
1. Experiment Objective
Master image geometric transforms: scaling, translation, cropping, mirror flipping, and other basic spatial transform operations.
2. Experiment Principle
1. Keyword Explanation
| Keyword | Description |
|---|---|
| Affine transform | The combination of linear transforms (rotation, scaling, translation) with translation, preserving the parallel relationship of lines in the image |
| Translation matrix | A 2×3 transform matrix of the form [[1,0,tx],[0,1,ty]] that moves pixels along the x and y axes |
| Bilinear interpolation | The interpolation algorithm used by default in cv2.resize(), computing new pixel values from the weighted average of the surrounding 2×2 pixels |
| ROI | Region of Interest; a sub-region cropped from the original image via array slicing |
2. Technical Architecture
This experiment is a pure offline Python script. The core of geometric transforms is coordinate mapping — for each pixel coordinate in the output image, the transform matrix is used to compute its corresponding coordinate in the input image, which is then sampled and filled.
Data flow: local image → cv2.imread() → build the transform matrix (or slice directly) → cv2.warpAffine() / cv2.resize() → side-by-side comparison display in two windows.
3. Experiment Steps
1. Hardware Preparation
| Hardware | Requirement |
|---|---|
| PTZ version | ✅ Supported |
| No-PTZ version | ✅ Supported |
| Required peripherals | None (local image processing, no need to start the car) |
2. Startup Method
Mode 1: Translation
python3 ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_image_panning.pyMode 2: Cropping
xxxxxxxxxxpython3 ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_image_cropping.pyMode 3: Mirror flipping
xxxxxxxxxxpython3 ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_image_mirroring.pyMode 4: Scaling (zoom out + zoom in)
xxxxxxxxxxpython3 ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_zoom_out_in.py3. Operation Instructions
After each script runs, a window pops up displaying the original image and the transformed result side by side:
opencv_image_panning.py: original image + result translated 30 pixels down and to the rightopencv_image_cropping.py: original image + cropped ROI region (y=0~100, x=100~200)opencv_image_mirroring.py: original image + vertically mirrored flip (vertically stacked)opencv_zoom_out_in.py: original image + zoomed out 50% + zoomed in 200%
Press q to exit.
4. Stop Method
Press q to close all OpenCV windows and exit the program.
4. Experiment Phenomena
- Understand geometric operations such as
cv2.warpAffine(),cv2.resize(), and NumPy slicing - Windows display the original image and the transformed result side by side
Original image: The input image for geometric transform operations; all transforms are compared and displayed against this image.
Translation: The image is moved by the specified number of pixels along the x/y axes, with black fill areas appearing on the right and bottom.
Cropping: Crops a local region of the image via NumPy array slicing img[y1:y2, x1:x2].
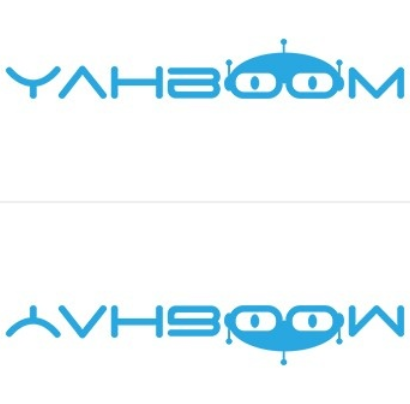
Mirroring: Achieves vertical flipping by copying pixels row by row, producing a top-bottom symmetric effect.
Zoom out: Uses cv2.resize() to scale the image dimensions down proportionally; the pixel count decreases but the main content is preserved.
Zoom in: Uses cv2.resize() to scale the image dimensions up proportionally, with the interpolation algorithm filling in the new pixels.
5. Program Analysis
Source code path:
- Script directory:
~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/- Test image:
~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/images/yahboom.png
1. Core Logic Analysis
The four geometric transforms share the same execution framework; they differ in the transform parameters and API calls.
Affine translation (opencv_image_panning.py)
x# Source file: ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_image_panning.pyimport cv2import numpy as npif __name__ == '__main__': img = cv2.imread('~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/images/yahboom.png', cv2.IMREAD_UNCHANGED) if img is None: print("Image read failed, please check that the images/yahboom.png path is correct") exit() imgInfo = img.shape height = imgInfo[0] width = imgInfo[1] # Define the translation matrix: move 30 pixels to the right and 30 pixels down matShift = np.float32([[1, 0, 30], [0, 1, 30]]) dst = cv2.warpAffine(img, matShift, (width, height)) while True: cv2.imshow("yahboom", img) cv2.imshow('yahboom_panned', dst) action = cv2.waitKey(10) & 0xFF if action == ord('q') or action == 113: break cv2.destroyAllWindows()Key logic notes:
np.float32([[1,0,tx],[0,1,ty]])builds a 2×3 affine translation matrix;txandtyare the displacement (in pixels) along the x and y directions respectivelycv2.warpAffine(src, M, dsize)applies an affine transform to the image; the third parameter specifies the output canvas size- After translation, the areas vacated by the original pixels are filled with black (value 0)
Image cropping (opencv_image_cropping.py)
xxxxxxxxxx# Source file: ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_image_cropping.pyimport cv2if __name__ == '__main__': img = cv2.imread('/home/l_jh/microros_ws/src/microros_v2_opencv_base_pkg/scripts/images/yahboom.png', cv2.IMREAD_UNCHANGED) if img is None: print("Image read failed, please check that the images/yahboom.png path is correct") exit() dst = img[0:100, 100:200] while True: cv2.imshow("yahboom", img) cv2.imshow('yahboom_cropped', dst) action = cv2.waitKey(10) & 0xFF if action == ord('q') or action == 113: break cv2.destroyAllWindows()Key logic notes:
img[y1:y2, x1:x2]uses NumPy array slicing to directly extract a pixel subset without calling any OpenCV API- This is the most efficient of all geometric transforms — a zero-copy view that only changes the access boundaries
- Slice intervals are left-closed and right-open:
0:100means indices 0~99
Scaling (opencv_zoom_out_in.py)
xxxxxxxxxx# Source file: ~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/opencv_geometric_transformation/opencv_zoom_out_in.pyimport cv2if __name__ == '__main__': img = cv2.imread('~/microros_ws/src/microros_v2_opencv_base_pkg/scripts/images/yahboom.png', cv2.IMREAD_UNCHANGED) if img is None: print("Image read failed, please check that the images/yahboom.png path is correct") exit() print(img.shape) x, y = img.shape[0:2] img_zoom_out = cv2.resize(img, (int(y / 2), int(x / 2))) img_zoom_in = cv2.resize(img, (y * 2, x * 2)) while True: cv2.imshow("yahboom", img) cv2.imshow('yahboom_zoom_out', img_zoom_out) cv2.imshow('yahboom_zoom_in', img_zoom_in) action = cv2.waitKey(10) & 0xFF if action == ord('q') or action == 113: break cv2.destroyAllWindows()Key logic notes:
cv2.resize(src, dsize)scales the image to the target size;dsizeis in(width, height)format- Note that
img.shapereturns(height, width), while the second parameter ofcv2.resizeexpects(width, height)— the two orders are reversed - Bilinear interpolation (
INTER_LINEAR) is used by default; zooming out and zooming in share the same API
2. Key Parameters
| Parameter | Type | Default | Description |
|---|---|---|---|
matShift's tx/ty | float32 | 30, 30 | Translation amount (pixels); positive values move right/down |
warpAffine's dsize | tuple | (width, height) | Output canvas size; if the same size as the original image, the overflowing parts are cropped |
resize's dsize | tuple | — | Target size (width, height); note the order difference from shape |
| NumPy slice range | slice | — | img[y1:y2, x1:x2], a left-closed right-open interval |
3. Node Notes
This experiment is a pure Python script and does not use ROS2 nodes. The script uses if __name__ == '__main__': as its entry point and runs independently in a desktop environment.
6. Common Problems
| Problem | Cause | Solution |
|---|---|---|
| The transformed image goes out of bounds | Output size not adjusted | Enlarge the output canvas size or reduce the translation amount |
resize size error | width/height order reversed | cv2.resize takes (width, height), while img.shape is (height, width) |
| The cropped region is empty | Slice index out of bounds | Make sure the slice range is within the original image size: y2 ≤ height, x2 ≤ width |