yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
MicroROS V2 Robot Car📖
01.Introduction
  • 0.Unboxing Video
  • 1. Readme Learning Route
  • 2. Must Read Before Use
  • 3. Introduction to MicroROS V2 Control Board
  • 4. Introduction to LiDAR
  • 5. Introduction to ESP32 Camera Module
  • 6. FAQ
  • 7. About Charging
02.Assembly course
  • Assembly Video
03.Preparation
  • 1. Quickly Start
  • 2. Write Firmware
  • 3. Install VM and Start System
  • 4. Configure VM and Connect Robot
  • 5. Connect to MicroROS Agent
04.Quick start control course
  • 1. VM Keyboard Remote Control
  • 2. VM Handle Remote Control
  • 3. USB Handle Control
05.Robot control course
  • 1. Robot Information Release
  • 2. Robot Keyboard Control
  • 3. Robot Handle Control
  • 4. Robot State Estimation
  • 5. Linear Speed Calibration
  • 6. Angular Velocity Calibration
  • 7. Robot URDF Model
06.Lidar course
  • 1. Precautions for LiDAR Mapping and Navigation
  • 2. Lidar Avoid
  • 3. Lidar Following
  • 4. Lidar Guard
  • 5. Lidar Patrol
  • 6. Gmapping Mapping
  • 7. Cartographer Mapping
  • 8. Cartographer Quickly Repositioning Navigation
  • 9. Slam Toolx Mapping
  • 10. Navigation2 Single Point Navigation
  • 11. Navigation2 Multi Point Navigation
  • 12. Ros Robot App Mapping And Navigation
07.Road network planning
  • 1. Introduction to Road Network Planning and Quick Start
  • 2. Build a Pose Map
  • 3. Road Network Annotation
  • 4. Planning and Navigation Between Road Networks
  • 5. Road Network Navigation in Any Pose
  • 6. Path Replanning
08.Vision basic course
OpenCV Image Processing
  • 1. Introduction to OpenCV Source CV
  • 2. Open Source CV Geometric Transformation
  • 3. Open Source CV Image Processing and Drawing Text Line Segments
  • 4. Open Source CV Image Beautification
09.Visual General Course (For Standard&Superior version)
4. Yolov11&26 Visual Recognition
  • 1. YOLO Environment Setup
  • 2. CLI Usage
  • 3. Object Detection
  • 4. Instance Segmentation
  • 5. Pose Estimation
  • 6. Image Classification
  • 7. Oriented Bounding Boxes Object Detection
  • 8. Model Prediction
1. ESP32 Visual Recognition Module Configuration
  • 1. Serial Port Configuration WiFi Instructions
  • 2. Use ESP32 Camera Module in Robot Car
  • 3. Servo PTZ Calibration
2. OpenCV Visual Recognition
  • 1. Human Pose Estimation
  • 2. Object Detection
  • 3. AR Vision
  • 4. QR Code
  • 5. Color Recognition
  • 6. Facial Recognition
  • 7. AprilTag Machine Code Recognition
3. Mediapipe Visual Recognition
  • 1. Hand Detection
  • 2. Pose Detection
  • 3. Holistic Detection
  • 4. Facial Detection
  • 5. Facial Recognition
  • 6. Facial Special Effects
  • 7. 3D Object Recognition
  • 8. Brush
  • 9. Gesture Recognition
  • 10. Palm Target Localization
  • 11. Fingertip Trajectory Recognition
10.Visual Advanced Course (Just for Standard version)
1. Visual Control
  • 1. QR Code Recognition Control Action
  • 2. AprilTag Control Car Action Group
  • 3. Gesture Control Car Action Group
  • 4. Visual Line Tracking
2. Visual Tracking
  • 1. Color Tracking
  • 2. Facial Tracking
  • 3. QR Code Tracking
  • 4. Object Recognition And Tracking
  • 5. Mediapipe Palm Tracking
  • 6. Mediapipe Gesture Tracking
  • 7. Mediapipe Human Pose Tracking
  • 8. KCF Object Tracking
  • 9. AprilTag Machine Code Tracking
3. Visual Following
  • 1. Color Follow
  • 2. Face Follow
  • 3. QR Code Follow
  • 4. Mediapipe Palm Follow
  • 5. Mediapipe Gesture Follow
  • 6. Mediapipe Human Posture Follow
  • 7. AprilTag Machine Code Follow
  • 8. Object Follow
11.Visual Advanced Course (Just for Superior version)
1. Visual Control
  • 1. QR Code Recognition Control Action
  • 2. AprilTag Control Car Action Group
  • 3. Gesture Control Car Action Group
  • 4. Visual Line Tracking
2. Visual Tracking
  • 1. Color Tracking
  • 2. Facial Tracking
  • 3. QR Code Tracking
  • 4. YOLO Object Recognition and Tracking
  • 5. Mediapipe Palm Tracking
  • 6. Mediapipe Gesture Tracking
  • 7. Mediapipe Human Pose Tracking
  • 8. KCF Object Tracking
  • 9. AprilTag Machine Code Tracking
3. Visual Follow
  • 1. Color Follow
  • 2. Face Follow
  • 3. QR Code Follow
  • 4. Mediapipe Palm Follow
  • 5. Mediapipe Gesture Follow
  • 6. Mediapipe Human Pose Follow
  • 7. AprilTag Machine Code Follow
  • 8. Object Follow
12.AI Large Model Basic and Applications Course
1. AI Large Model Preparation
  • 1.AI Large Model Preparation
2. AI Large Model Basic Course
  • 1. AI Large Model Types and Principles
  • 2. RAG Retrieval Augmented and Training Samples
  • 3. Embodied Intelligent System Architecture
  • 4. Embodied Intelligence Core Source Code
3. AI Large Model Development
  • 1. Register Model Service Account
  • 2. Configure API KEY
  • 3. Dify Introduction
  • 4. Dify Basic Features
  • 5. RAG Knowledge Base Deployment
  • 6. AI Application Development Chatbot
  • 7. RAG Knowledge Base and Chatbot
  • 8. AI Agent Workflow
4. AI Large Model (Text Version)
  • 1. Semantic Understanding and Instruction Following
  • 2. Multimodal Visual Understanding
  • 3. Multimodal Visual Understanding + Basic Control
  • 4. Multimodal Visual Understanding + Object Following
  • 5. Multimodal Visual Understanding + Visual Line Following
  • 6. Multimodal Visual Understanding + SLAM Navigation
  • 7. Multimodal Visual Understanding + SLAM Navigation + Visual Line Following
  • 8. Multimodal Visual Understanding + SLAM Navigation + Object Following
  • 9. Intent Inference + Multimodal Visual Understanding + SLAM Navigation
13.Openclaw Basics Course
  • 1. Openclaw Introduction
  • 2. Openclaw Core Concepts
  • 3. Openclaw Api-Key Configuration
  • 4. Openclaw Switching Models
  • 5. Openclaw System Prompt
  • 6. Openclaw Common CLI Command
14. Openclaw Interaction Course
  • 1. Openclaw Webchat Interaction
  • 2. Openclaw Tui Interaction
  • 3. Openclaw Whatsapp Interaction
15.Openclaw Development Course
  • 1. Openclaw Robot Mcp Service Integration
  • 2. Robot CLI Command Tools
  • 3. Robot-Control Plugin Tools
  • 4. Openclaw Skills Development
  • 5. Openclaw Scheduled Tasks
  • 6. Openclaw Multi Agent System
  • 7. Openclaw Proactive Interaction
  • 8. Openclaw Vector Memory
16.Openclaw Embodied Intelligence Course
  • 1. OpenClaw Natural Interaction + Basic Control
  • 2. OpenClaw Natural Interaction + Slam Navigation
  • 3. OpenClaw Natural Interaction + Multimodal Visual Understand
  • 4. OpenClaw Natural Interaction + Multimodal Visual Understand + Slam Navigation + Visual Follow
  • 5. OpenClaw Natural Interaction + Multimodal Visual Understand + Slam Navigation + Visual Track
17.Multi-machine Course
  • 1. Multi Machine Handle Control
  • 2. Multi Machine Keyboard Control
  • 3. Multi Machine Navigation
18.MicroROS-V2 Control Board Development Environment
  • 1. Set Up the ESP32-IDF Development Environment
  • 2. ESP32-IDF Configuration Tool
  • 3. ESP Flash Tool Flashing Firmware
  • 4. Install ESP32 Microros Components
  • 5. Install And Start Microros Agent
19.MicroROS-V2 Control Board ESP32 Basic Course
  • 1. Led Light Up
  • 2. Button Function
  • 3. Drive Buzzer
  • 4. Oled
  • 5. Usb Host Function
  • 6. Serial Communication
  • 7. Battery Voltage Detection
  • 8. Drive Pwm Servo
  • 9. Drive Motors
  • 10. Read Motor Encoder Data
  • 11. Pid Motor Speed Control
  • 12. Robot Kinematics Analysis Theory
  • 13. Read Imu Data
  • 14. Read Lidar Data
  • 15. Flash Data Storage
  • 16. Custom Partition Table
  • 17. Bluetooth Communication
  • 18. Wifi Connection
  • 19. ESP32 Visual Recognition Module
20.MicroROS-V2 Control Board Micro_ros Basic Course
  • 1. Publish Topics
  • 2. Subscribe To Topics
  • 3. Multi Topic Subscription And Publishing
  • 4. Subscribe To Buzzer Topic
  • 5. Subscribe To Pwm Servo Topic
  • 6. Subscribe To Speed Control Topic
  • 7. Publish Odometry Topic
  • 8. Publish Imu Data Topic
  • 9. Publish Lidar Data Topic
21. Linux System Course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
22.Docker Course
  • 1.Docker overview and docker installation
  • 2.Common commands for docker image containers
  • 3.Docker images deeply understand and publish images
23.ROS Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • Mapping_APP(iOS_Android)
  • Code
  • Software_Tools
  • VM_System_File
  • 3D_Model_File
  • ESP32_Firmware
  • Dify LLM Base
  • Instruction_Manual
  • VMware
Download ZIP

Welcome to MicroROS V2 Robot Car repository

3. Multi Machine Navigation

Multi-Machine Navigation

Multi-Machine Navigation1. Course Overview2. Preparation3. Run the Case4. Source Code Analysis4.1 multi_robot_base.launch4.2 multi_robot_demo.launch

1. Course Overview

  • Run the example program and use two MicroRosV2 robots to navigate in the same map.
  • This tutorial demonstrates two MicroRosV2 robots; robot1: PTZ servo version (ptz), robot2: fixed camera version (no_ptz);
  • There is no limit on the number or model type of robots actually used. Fill in the robot_names and camera_types startup parameters according to the actual situation.


2. Preparation

  • Build at least one grid map. Refer to the content of the previous chapter, LiDAR Gameplay.
  • Complete the prerequisite courses Multi-machine Handle Control and Multi-machine Keyboard Control, and complete the Agent proxy configuration and Domain ID configuration for the robot chassis.


3. Run the Case

xxxxxxxxxx
ros2 launch microros_v2_bringup multi_robot_demo.launch.py demo:=navigation robot_names:=robot1,robot2 camera_types:=ptz,no_ptz

[!IMPORTANT]

Parameter description

  • robot_names: List of robot names, separated by English commas. For example, robot1,robot2 means two MicroRosV2 robots.
  • camera_types: List of camera model types, separated by English commas. For example, ptz,no_ptz means the camera types of the two robots; the order matches the order of robot_names.


  • Use 2D Pose Estimate to initialize the pose of robot1 and robot2 respectively. There are two "2D Pose Estimate" tools on rviz: the first is the tool for setting the initial pose of robot1, and the second is the tool for setting the initial pose of robot2. Use these two tools respectively to give the initial poses to the two robots.
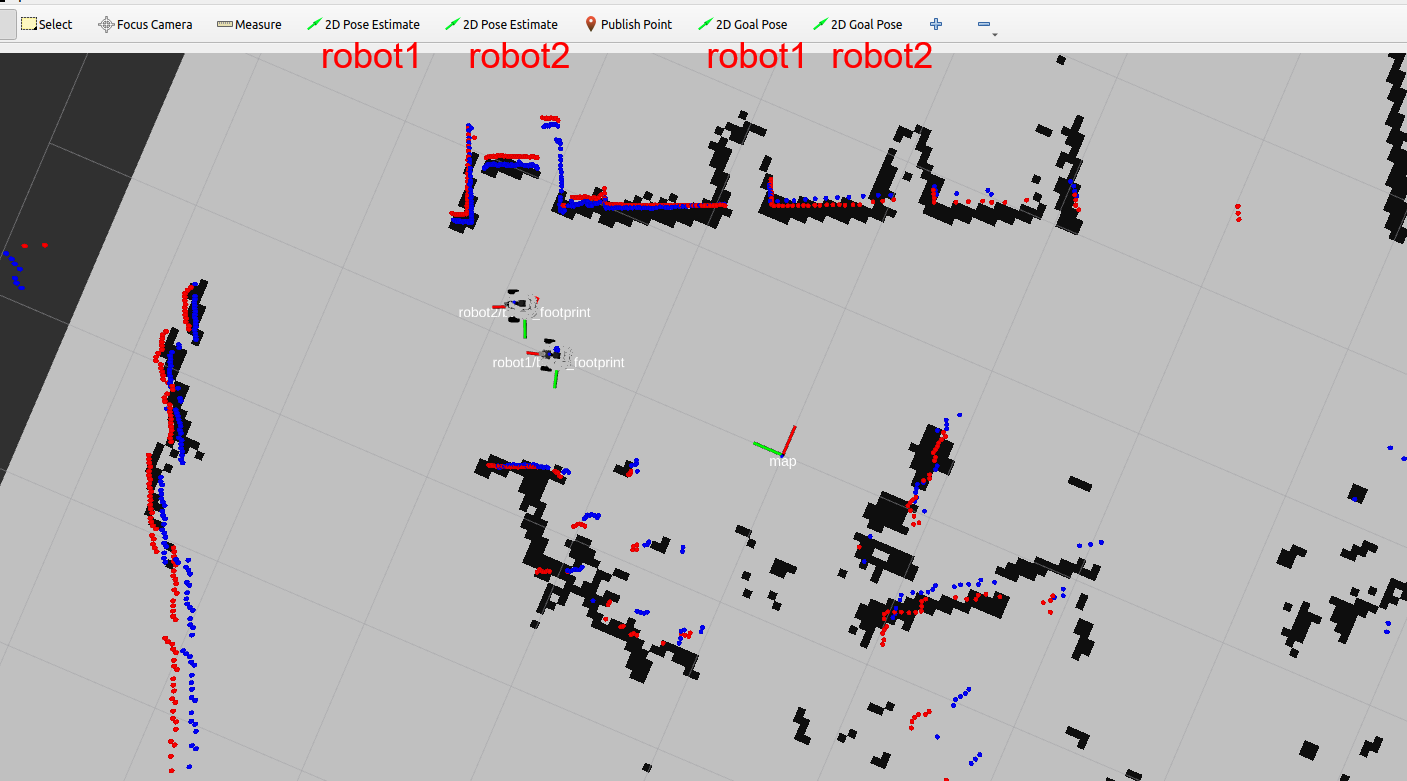
image-20260728204726943


  • Then use the 2D Goal Pose tool to give different goal points to the two robots: there are two "2D Goal Pose" tools on rviz, the first is the tool for setting the goal point of robot1, and the second is the tool for setting the goal point of robot2. Use these two tools respectively to give goal points to the two robots.
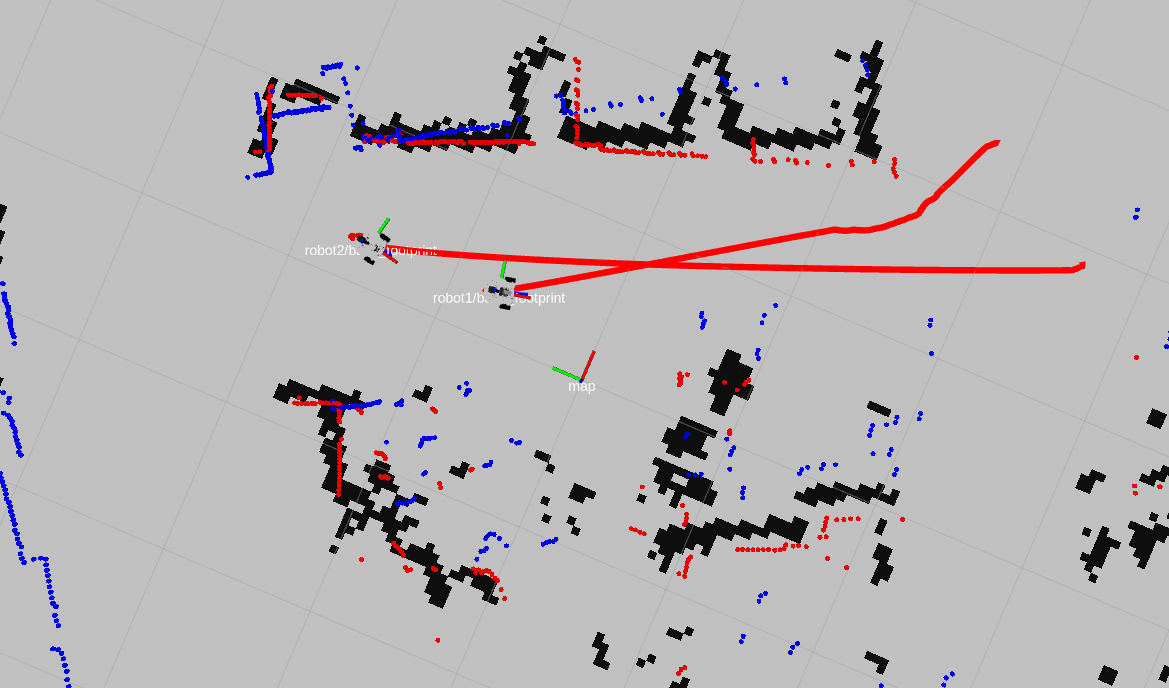
image-20260728204856970


4. Source Code Analysis

4.1 multi_robot_base.launch

  • File path
xxxxxxxxxx
$HOME/microros_ws/src/microros_v2_bringup/launch/multi_robot_base.launch.py


multi_robot_base.launch.py is the chassis base launch file of the multi-machine system. It is responsible for creating independent namespaced nodes for each robot:

  1. Parameter parsing: Parses the list of robot names from robot_names and the list of camera model types from camera_types; if only one camera type is passed in, it is automatically extended to all robots, and an error is reported when the counts do not match.

  2. Shared nodes: micro_ros_agent (UDP 8090) launches only one instance globally (skipped if already running), and multi_robot_sync is responsible for distributing the keyboard/handle commands to each robot's /cmd_vel, /beep, and /cmd_ptz_angle.

  3. Independent nodes per robot: Iterates over robot_names and creates the following for each robot:

    • robot_state_publisher: Loads the URDF via xacro, passes in camera_type and namespace, and publishes the TF transforms of that robot
    • joint_state_publisher: Subscribes to ptz_status and publishes the PTZ joint states
    • ekf_filter_node: Loads ekf.yaml, adds the namespace prefix to odom_frame, base_link_frame, world_frame as well as the input topics (such as robot1/odom_raw), enabling independent EKF fusion for each robot
xxxxxxxxxx
def launch_setup(context, *args, **kwargs):
    # robot name list, e.g. "robot1,robot2"
    robot_names = [n.strip().strip('/') for n in
                   LaunchConfiguration('robot_names').perform(context).split(',') if n.strip()]
​
    # camera type per robot: ptz | no_ptz | basic_car
    camera_types = [c.strip() for c in
                    LaunchConfiguration('camera_types').perform(context).split(',') if c.strip()]
    if len(camera_types) == 1:
        camera_types = camera_types * len(robot_names)
    if len(camera_types) != len(robot_names):
        raise RuntimeError(
            f'camera_types count ({len(camera_types)}) does not match robot_names count ({len(robot_names)})')
​
    robot_urdf=os.path.join(get_package_share_directory('robot_description'),'urdf','microros_v2.urdf.xacro')
    ekf_params=os.path.join(get_package_share_directory('microros_v2_bringup'),'config','ekf.yaml')
​
    # single micro_ros_agent shared by all robots
    mircoros_agent=Node(
        package='micro_ros_agent',
        executable='micro_ros_agent',
        output='screen',
        arguments=['udp4', '--port', '8090', '-v', LaunchConfiguration('micro_ros_agent_verbose')],
    )
​
    # single command-sync node, fans out cmd_vel/beep/cmd_ptz_angle to every robot
    multi_robot_sync=Node(
        package='common_demo',
        executable='multi_robot_sync',
        name='multi_robot_sync',
        output='screen',
        parameters=[{'robot_names': robot_names}],
    )
​
    actions = [
        LogInfo(msg='micro_ros_agent already running, skip.') if is_process_running('micro_ros_agent udp4') else mircoros_agent,
        multi_robot_sync,
    ]
​
    # per-robot nodes: robot_state_publisher / joint_state_publisher / ekf
    for name, camera_type in zip(robot_names, camera_types):
        prefix = f'{name}/'
        robot_description = Command(
            ["xacro", " ", robot_urdf," ", "camera_type:=", camera_type," ", "namespace:=", name] )
​
        robot_state_publisher_node = Node(
            package='robot_state_publisher',
            executable='robot_state_publisher',
            namespace=name,
            parameters=[{'robot_description': ParameterValue(robot_description, value_type=str)}],
            arguments=['--ros-args','--log-level','warn']
        )
        joint_publisher_node=Node(
            package='joint_state_publisher',
            executable='joint_state_publisher',
            namespace=name,
            parameters=[{'source_list': ["ptz_status"]}],
            arguments=['--ros-args','--log-level','warn']
        )
​
        #ekf_odom
        ekf_odom=Node(
            package='robot_localization',
            executable='ekf_node',
            name="ekf_filter_node",
            namespace=name,
            parameters=[ekf_params,
            {
                'odom_frame': f'{prefix}odom',
                'base_link_frame': f'{prefix}base_footprint',
                'world_frame': f'{prefix}odom',
                # chassis firmware topics are already namespaced
                'odom0': f'/{prefix}odom_raw',
                'imu0': f'/{prefix}imu',
            }],
            remappings=[('odometry/filtered', 'odom')]
        )
​
        actions += [
            robot_state_publisher_node,
            joint_publisher_node,
            ekf_odom,
        ]
​
    return actions
​
​
def generate_launch_description():
    # Declare arguments
    declared_arguments = []
    declared_arguments.append(
        DeclareLaunchArgument(
            'robot_names',
            default_value='robot1,robot2',
            description='Comma-separated robot namespaces, e.g. robot1,robot2'
        )
    )
    declared_arguments.append(
        DeclareLaunchArgument(
            'camera_types',
            default_value='ptz',
            description='Camera type per robot (ptz | no_ptz | basic_car): single value for all robots, '
                        'or comma-separated list matching robot_names, e.g. ptz,basic_car'
        )
    )
    declared_arguments.append(
        DeclareLaunchArgument(
            'micro_ros_agent_verbose',
            default_value='4',
            description='micro-ROS agent verbosity level (0-6)'
        )
    )
​
    return LaunchDescription([
        *declared_arguments,
        OpaqueFunction(function=launch_setup),
    ])
​


4.2 multi_robot_demo.launch

  • File path
xxxxxxxxxx
$HOME/microros_ws/src/microros_v2_bringup/launch/multi_robot_demo.launch.py

multi_robot_demo.launch.py is the launch file for multi-machine navigation. On the basis of multi_robot_base.launch.py, it loads the complete Nav2 navigation stack for each robot:

  1. Global map service: Starts a map_server to load the shared grid map. All robots use the same map, which is automatically activated by lifecycle_manager_map.

  2. Dynamic rewriting of the parameter file: The template file nav2_multi_robot_params.yaml contains the <robot_ns> placeholder. At startup, ReplaceString replaces it with the actual robot name, and then root_key=name wraps the parameters under the corresponding namespace, ensuring that /robot1/controller_server reads the configuration of robot1.

  3. Navigation nodes per robot: Iterates over robot_names and starts the complete Nav2 navigation stack for each robot:

    • amcl: Localization node, subscribes to the global map topic /map, and outputs the pose under that robot's namespace
    • controller_server: Path tracking controller
    • planner_server: Global path planner
    • behavior_server: Behaviors such as obstacle avoidance and rotation
    • bt_navigator: Behavior tree navigation dispatcher

The key difference from single-robot navigation: all robots share the same map_server and the global TF tree (no /tf remapping), and each robot's AMCL and costmaps are isolated by namespace without affecting each other.

​x
    robot_names = [n.strip().strip('/') for n in
                   LaunchConfiguration('robot_names').perform(context).split(',') if n.strip()]
    map_file = os.path.join(os.path.expanduser('~'), 'map',
                            LaunchConfiguration('map').perform(context))
    bringup_dir = get_package_share_directory('microros_v2_bringup')
    params_template = os.path.join(bringup_dir,'config','nav2_multi_robot_params.yaml')
​
    # single global map server shared by all robots
    actions = [
        Node(
            package='nav2_map_server',
            executable='map_server',
            name='map_server',
            output='screen',
            parameters=[{'yaml_filename': map_file, 'use_sim_time': False}],
        ),
        Node(
            package='nav2_lifecycle_manager',
            executable='lifecycle_manager',
            name='lifecycle_manager_map',
            output='screen',
            parameters=[{'autostart': True, 'node_names': ['map_server']}],
        ),
    ]
​
    lifecycle_nodes = ['amcl', 'controller_server', 'planner_server',
                       'behavior_server', 'bt_navigator', 'waypoint_follower']
    for name in robot_names:
        # rewrite '<robot_ns>' TF-frame placeholders, then wrap the file under the
        # namespace root key so params match /robotN/xxx node names
        params_file = ParameterFile(
            RewrittenYaml(
                source_file=ReplaceString(
                    source_file=params_template,
                    replacements={'<robot_ns>': name}),
                root_key=name,
                param_rewrites={},
                convert_types=True),
            allow_substs=True)
​
        # NOTE: no /tf remapping here, all robots share the global TF tree
        actions += [
            Node(
                package='nav2_amcl',
                executable='amcl',
                name='amcl',
                namespace=name,
                output='screen',
                parameters=[params_file],
                # humble amcl has no map_topic param, remap to the shared global map
                remappings=[('map', '/map')],
            ),
            Node(
                package='nav2_controller',
                executable='controller_server',
                namespace=name,
                output='screen',
                parameters=[params_file],
            ),
            Node(
                package='nav2_planner',
                executable='planner_server',
                name='planner_server',
                namespace=name,
                output='screen',
                parameters=[params_file],
            ),
            Node(
                package='nav2_behaviors',
                executable='behavior_server',
                name='behavior_server',
                namespace=name,
                output='screen',
                parameters=[params_file],
            ),
            Node(
                package='nav2_bt_navigator',
                executable='bt_navigator',
                name='bt_navigator',
                namespace=name,
                output='screen',
                parameters=[params_file],
            ),
            Node(
                package='nav2_waypoint_follower',
                executable='waypoint_follower',
                name='waypoint_follower',
                namespace=name,
                output='screen',
                parameters=[params_file],
            ),
            Node(
                package='nav2_lifecycle_manager',
                executable='lifecycle_manager',
                name='lifecycle_manager_navigation',
                namespace=name,
                output='screen',
                parameters=[{'autostart': True, 'node_names': lifecycle_nodes}],
            ),
        ]
    return actions
Multi Machine Keyboard Control
Set Up the ESP32-IDF Development Environment

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文