Welcome to Jetson Orin NANO Developer Kit repository
02.Deep segmentation
Isaac ROS Depth Segmentation
Isaac ROS Depth Segmentation official website link: https://nvidia-isaac-ros.github.io/repositories_and_packages/isaac_ros_depth_segmentation/index.html
Overview
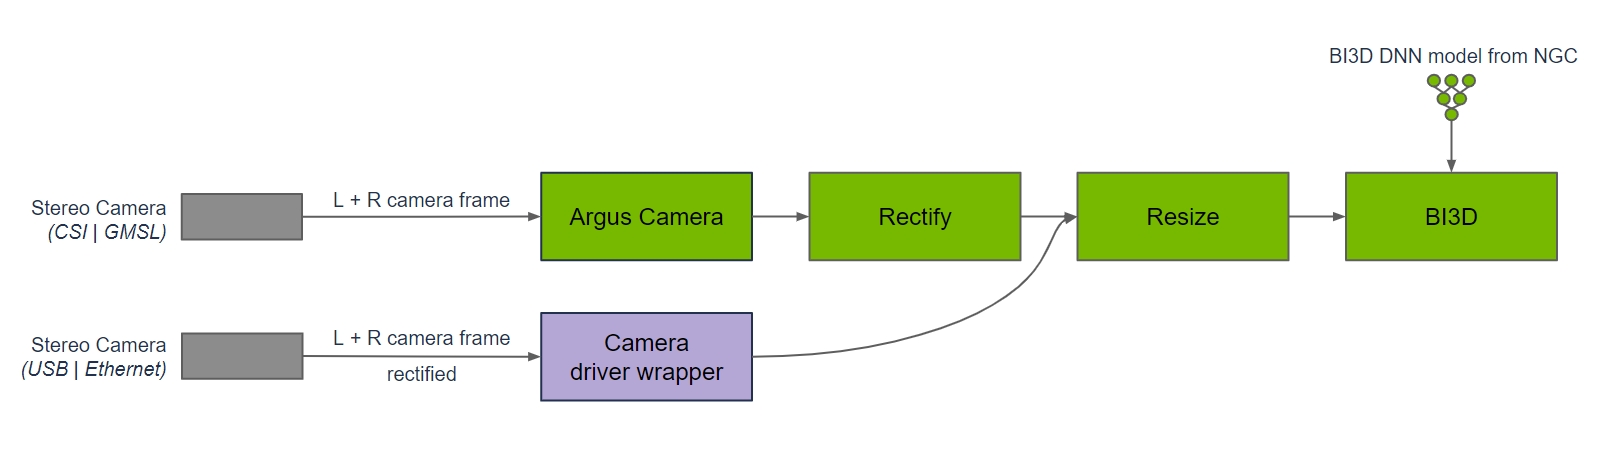
Isaac ROS Depth Segmentation provides NVIDIA-accelerated packages for depth segmentation. Bi3D uses the optimized DNN model to perform binarized depth estimation on stereo images, which can determine whether an obstacle is within a proximity field and estimate the ground free space.
Quick Experience
First use the command below to start the container
./run_isaac.sh
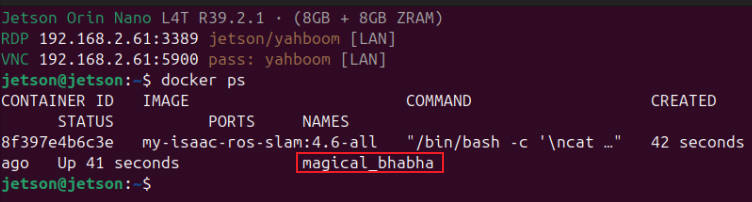
Then confirm the container on the host with docker ps, and open four container terminals with docker exec -it <container name> bash; each terminal should use the same ROS/FastDDS environment, for example:
Note: The terminals below all execute inside the container:
After the power mode is set to MAXN, an overcurrent warning may pop up when running the case; ignore it.
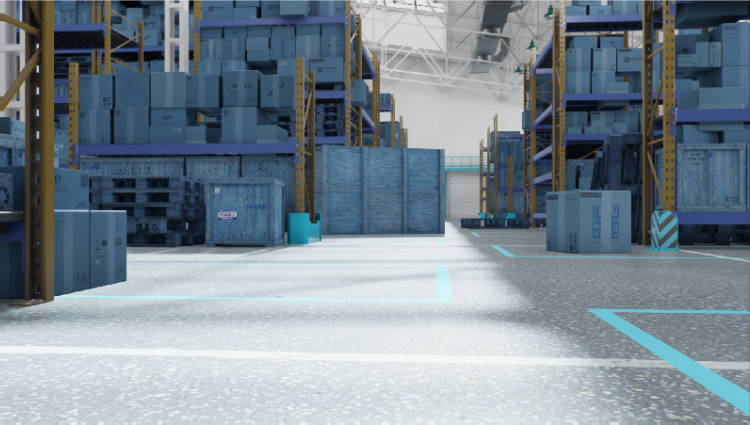
Terminal A: Start Nano pool=8 ESS. The input image is 1920×1080, and the model input is 960×576:
xxxxxxxxxxros2 launch /workspaces/isaac_ros-dev/launch/ess_nano_pool8.launch.py \ engine_file_path:=/workspaces/isaac_ros-dev/isaac_ros_assets/models_pending/dnn_stereo_disparity/dnn_stereo_disparity_v4.1.0_onnx_trt10.16/ess.engine \ ess_plugin_file_path:=/workspaces/isaac_ros-dev/isaac_ros_assets/models_pending/dnn_stereo_disparity/dnn_stereo_disparity_v4.1.0_onnx_trt10.16/plugins/aarch64/ess_plugins.so \ input_image_width:=1920 input_image_height:=1080 \ model_input_width:=960 model_input_height:=576Terminal B: Play the input in a loop at 0.25× speed:
xxxxxxxxxxros2 bag play /workspaces/isaac_ros-dev/isaac_ros_assets/isaac_ros_ess/rosbags/ess_rosbag \ --loop --rate 0.25 --remap \ /left/camera_info:=/left/camera_info_rect \ /right/camera_info:=/right/camera_info_rectTerminal C: Run the depth segmentation post-processing:
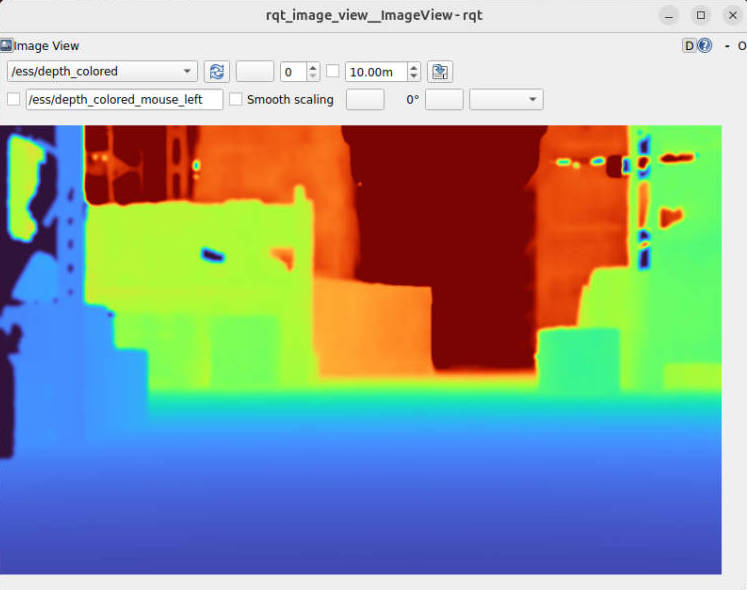
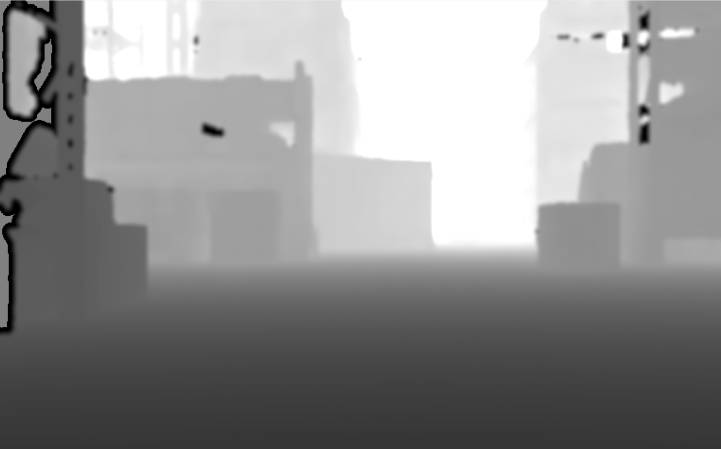
xxxxxxxxxxpython3 /workspaces/isaac_ros-dev/ess_segmentation.pyTerminal D: Open rqt image view and select /ess/depth_segmentation in Topic:
xxxxxxxxxxros2 run rqt_image_view rqt_image_view