Welcome to Jetson Orin NANO Developer Kit repository
23.ROS2 TF2 coordinate transformation
23. ROS 2 TF2 Coordinate Transformation
pip Installation Note: Ubuntu 24.04 marks the system Python as "externally managed" according to PEP 668, so installing directly with pip may report
externally-managed-environment.--break-system-packagesallows pip to install packages in this environment; a virtual environment usually does not need this argument, but this tutorial keeps it for consistent commands.
1. Introduction to TF2
The coordinate frame is a concept we are very familiar with, and it is also an important foundation in robotics. In a complete robot system, there are many coordinate frames. How should the positional relationships between these coordinate frames be managed? ROS provides us with a powerful coordinate frame management tool: TF2.
TF system reference: tf: The transform library | IEEE Conference Publication | IEEE Xplore
2. Coordinate Frames in Robots
In a mobile robot system, coordinate frames are equally crucial. For example, the center point of a mobile robot is the base coordinate frame Base Link, the position of the LiDAR is called the laser coordinate frame laser link, and when the robot moves, the odometry accumulates the position. The reference frame of this position is called the odometry coordinate frame odom. The odometry also has accumulated errors and drift, and the reference frame of the absolute position is called the map coordinate frame map.
The relationships between coordinate frames layer by layer are complex. Some are relatively fixed, and some change constantly. The seemingly simple coordinate frames also become complex in the spatial range, so a good coordinate frame management system is particularly important.
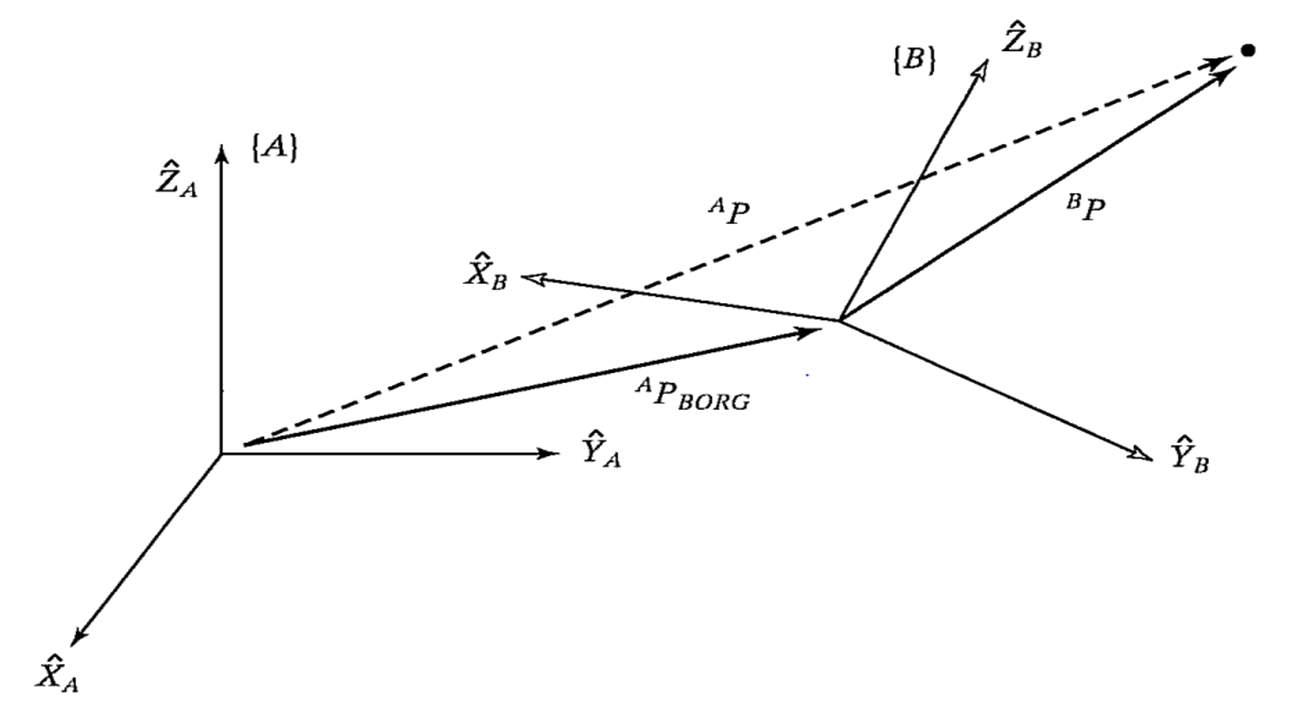
The basic theory of coordinate frame transformation relationships is explained in every robotics textbook. It can be decomposed into two parts, translation and rotation, and is described by a four-by-four matrix. When coordinate frames are drawn in space, the transformation relationship between the two is actually a mathematical description of vectors.
The underlying principle of the TF function in ROS is the encapsulation of these mathematical transformations. For detailed theoretical knowledge, please refer to robotics textbooks. We mainly explain how to use the TF coordinate management system.
3. TF Command Line Operations
Let's first use an example with two turtles to understand a robot following algorithm based on coordinate frames. For ease of demonstration, this lesson is best operated in a virtual machine
3.1. Installing Related Tools
This example requires installing the corresponding package, the tf turtle simulator case, and the tf tree visualization tool.
sudo apt install ros-${ROS_DISTRO}-turtle-tf2-py ros-${ROS_DISTRO}-tf2-toolssudo pip3 install transforms3d --break-system-packagessudo apt install ros-${ROS_DISTRO}-rqt-tf-tree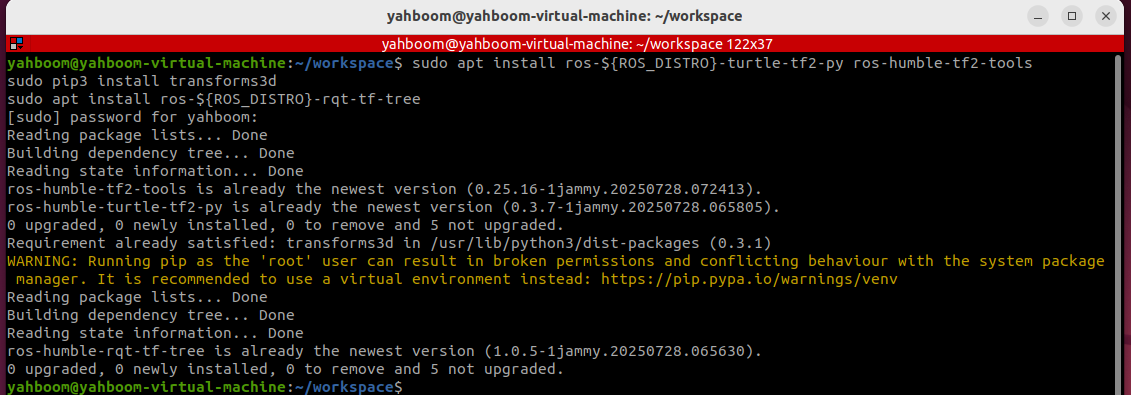
3.2. Starting Up
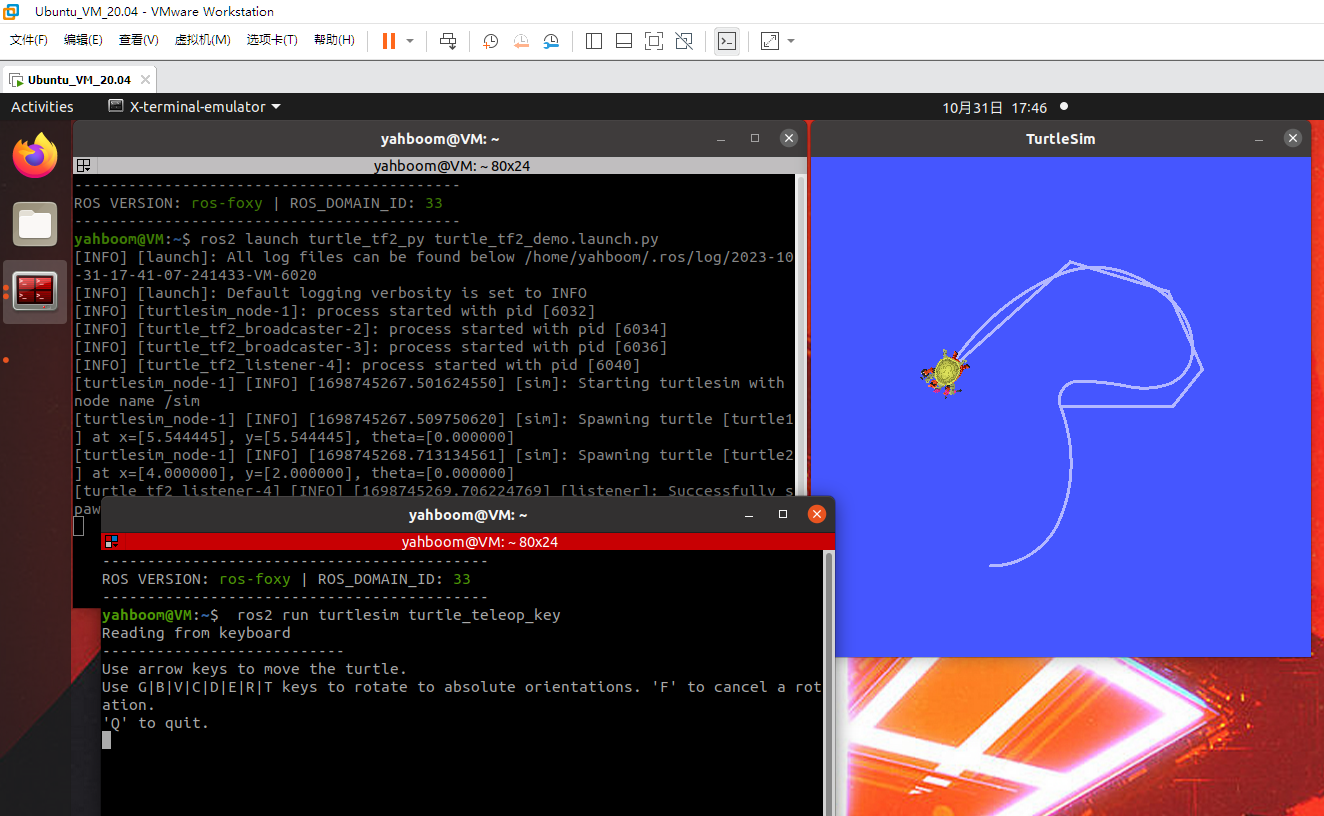
Then it can be started with a launch file. After that, we can control one of the turtles, and the other turtle follows automatically.
xxxxxxxxxxros2 launch turtle_tf2_py turtle_tf2_demo.launch.pyros2 run turtlesim turtle_teleop_keyWhen we control one turtle to move, the other turtle also follows.
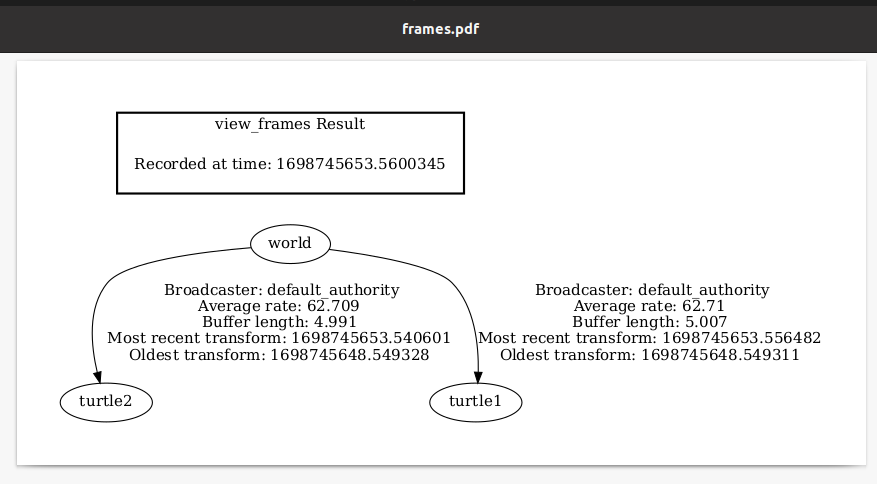
3.3. Viewing the TF Tree
xxxxxxxxxxros2 run rqt_tf_tree rqt_tf_tree
The TF transformation tree can be seen in the rqt window.
3.4. Querying Coordinate Transformation Information
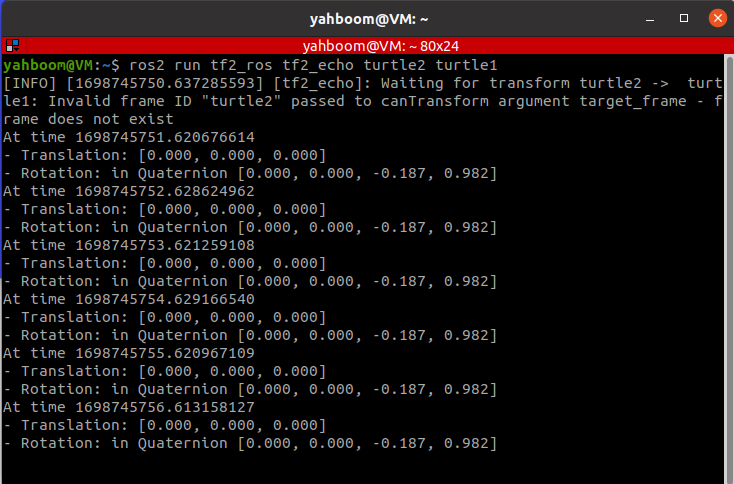
Only seeing the structure of the coordinate frames is not enough. If we want to know the specific relationship between two coordinate frames, we can view it with the tf2_echo tool:
xxxxxxxxxxros2 run tf2_ros tf2_echo turtle2 turtle1After running successfully, the terminal prints the transformation values of the coordinate frames in a loop.
3.5. Coordinate Frame Visualization
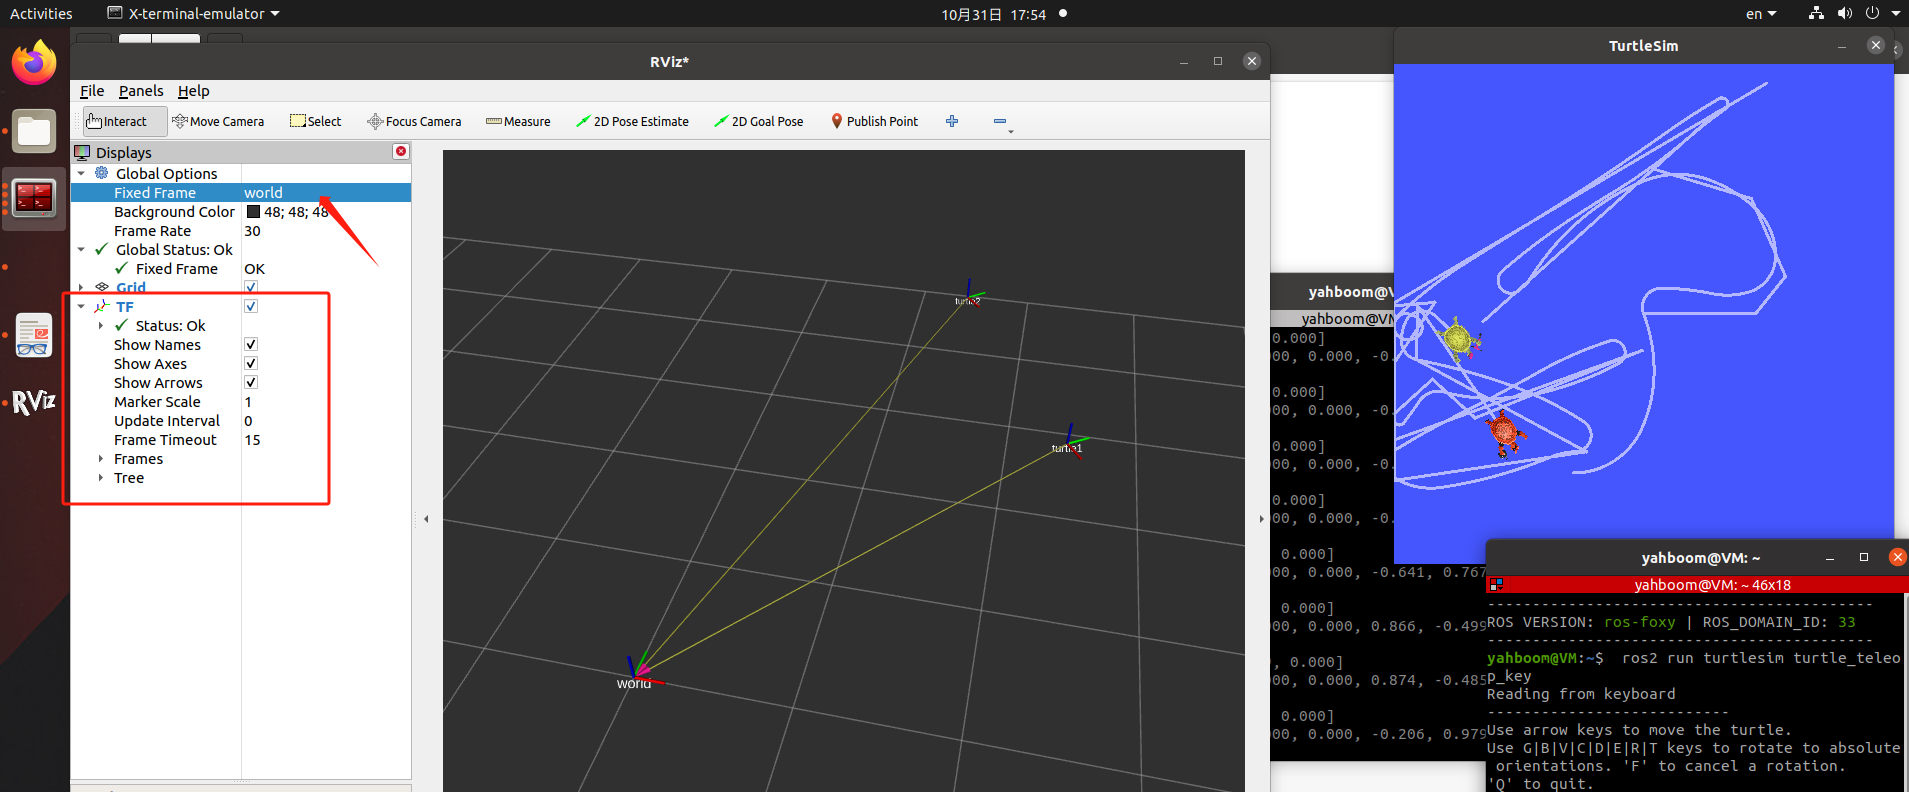
Run rviz2, and then add the TF display plugin.
xxxxxxxxxxrviz2
Set the reference coordinate frame in rivz2 to: world, add the TF display, and then make the turtle move. The coordinate axes in Rviz start to move. Isn't this more intuitive!
4. Static Coordinate Transformation
The so-called static coordinate transformation means that the relative position between two coordinate frames is fixed, such as the position between the LiDAR and base_link.
Example: For ease of demonstration, this lesson is best operated in a virtual machine
4.1. Publishing the Pose from A to B
xxxxxxxxxxros2 run tf2_ros static_transform_publisher 0 0 3 0 0 3.14 A B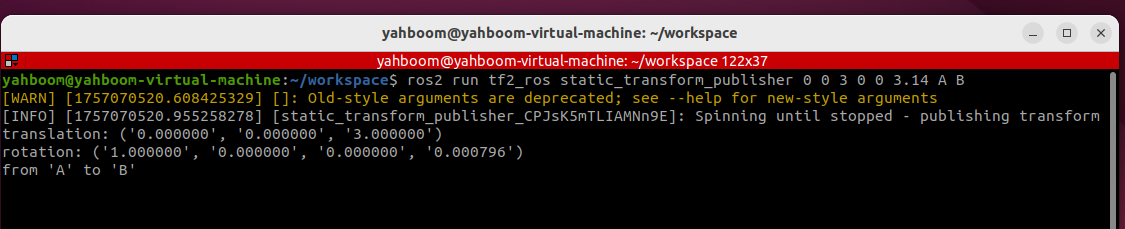
4.2. Listening/Obtaining the TF Relationship
xxxxxxxxxxros2 run tf2_ros tf2_echo A B
4.3. RIVZ Visualization
Run rviz2, and then add the TF display plugin.
xxxxxxxxxxrviz2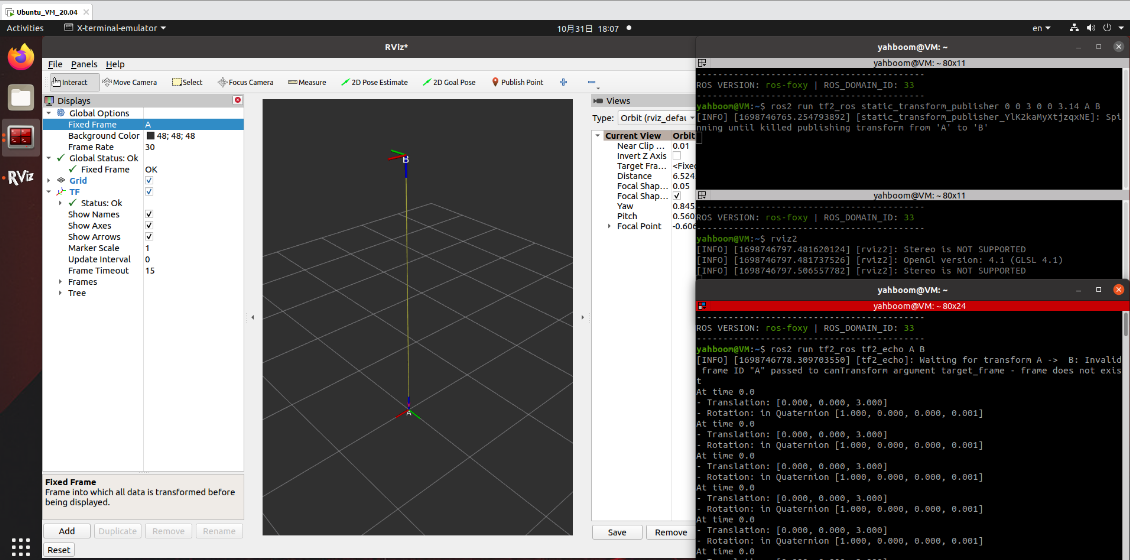
5. Case Introduction
In the previous lesson, the TF relationship in the turtle following case provided by the system was explained. In this lesson, we implement this function ourselves.
Course Content:
Implementing the turtle following case through programming
Mastering the implementation of a dynamic broadcaster through programming
Mastering the implementation of listening to the coordinate transformation between coordinate frames through programming
Mastering the use of PID control to convert physical quantities (distance, angle) into velocity control quantities
Advanced Content:
Understanding the function of the TF system to transform coordinate frames across the time dimension
6. Principle Analysis of the Turtle Following Case
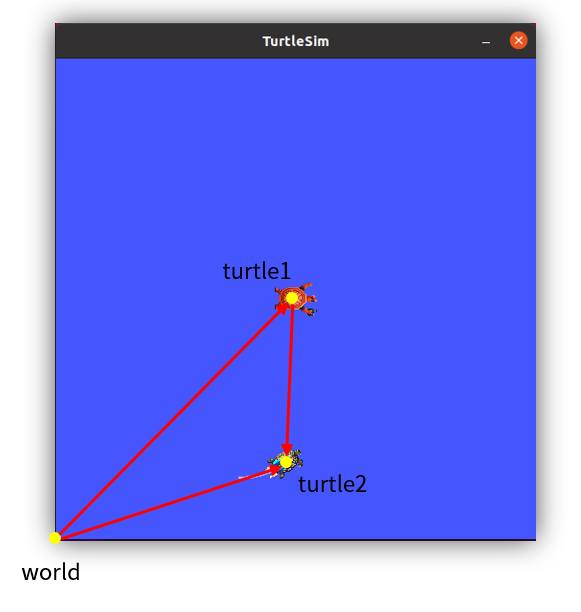
In the simulator with two turtles, we can define three coordinate frames. For example, the global reference frame of the simulator is called world, and the turtle1 and turtle2 coordinate frames are at the center points of the two turtles. In this way, the relative position of the turtle1 and world coordinate frames can represent the position of turtle 1, and the same applies to turtle 2.
To make turtle 2 move toward turtle 1, we draw a connecting line between them and add an arrow. How about that, does it remind you of the vector calculation learned in high school? We say that the description method of coordinate transformation is a vector, so in this following example, TF can solve it very well.
The length of the vector represents the distance, and the direction represents the angle. With the distance and the angle, we can calculate the velocity by setting an arbitrary time, can't we? Then comes the encapsulation and publication of the velocity topic, and turtle 2 can move.
So the core of this example is to implement the vector calculation through coordinate frames. The two turtles keep moving, so this vector also has to be calculated according to a certain period, which requires the dynamic broadcasting and listening of TF.
7. Creating a New Package
Create a new package in the src directory of the workspace to store our files.
xxxxxxxxxxros2 pkg create pkg_tf --build-type ament_python --dependencies rclpy --node-name turtle_tf_broadcasterAfter executing the above command, the pkg_tf package is created, and a turtle_tf_broadcaster node is also created with the related configuration files already configured. Add the following code to the file 【turtle_tf_broadcaster.py】:
ximport rclpy # ROS2 Python interface libraryfrom rclpy.node import Node # ROS2 node classfrom geometry_msgs.msg import TransformStamped # Coordinate transformation messageimport tf_transformations # TF coordinate transformation libraryfrom tf2_ros import TransformBroadcaster # TF coordinate transformation broadcasterfrom turtlesim.msg import Pose # turtlesim turtle pose message
class TurtleTFBroadcaster(Node):
def __init__(self, name): super().__init__(name) # Initialize the parent class of the ROS2 node
self.declare_parameter('turtlename', 'turtle') # Create a parameter for the turtle name self.turtlename = self.get_parameter( # Prefer the parameter value set externally, otherwise use the default value 'turtlename').get_parameter_value().string_value
self.tf_broadcaster = TransformBroadcaster(self) # Create and initialize a broadcast object for TF coordinate transformation
self.subscription = self.create_subscription( # Create a subscriber that subscribes to the pose message of the turtle Pose, f'/{self.turtlename}/pose', # Use the turtle name obtained from the parameter self.turtle_pose_callback, 1)
def turtle_pose_callback(self, msg): # Create a callback function that processes the turtle pose message and converts the pose message into a coordinate transformation transform = TransformStamped() # Create a message object of the coordinate transformation
transform.header.stamp = self.get_clock().now().to_msg() # Set the timestamp of the coordinate transformation message transform.header.frame_id = 'world' # Set the source coordinate frame of the coordinate transformation transform.child_frame_id = self.turtlename # Set the target coordinate frame of the coordinate transformation transform.transform.translation.x = msg.x # Set the translation along X, Y, and Z in the coordinate transformation transform.transform.translation.y = msg.y transform.transform.translation.z = 0.0 q = tf_transformations.quaternion_from_euler(0, 0, msg.theta) # Convert Euler angles to quaternions (roll, pitch, yaw) transform.transform.rotation.x = q[0] # Set the rotation along X, Y, and Z in the coordinate transformation (quaternion) transform.transform.rotation.y = q[1] transform.transform.rotation.z = q[2] transform.transform.rotation.w = q[3]
# Send the transformation self.tf_broadcaster.sendTransform(transform) # Broadcast the coordinate transformation; after the turtle pose changes, the coordinate transformation information is updated in time
def main(args=None): rclpy.init(args=args) # Initialize the ROS2 Python interface node = TurtleTFBroadcaster("turtle_tf_broadcaster") # Create and initialize a ROS2 node object rclpy.spin(node) # Wait in a loop for ROS2 to exit node.destroy_node() # Destroy the node object rclpy.shutdown() # Shut down the ROS2 Python interfaceNext, create a file 【turtle_following.py】 in the same directory as turtle_tf_broadcaster.py, and add the following code:
xxxxxxxxxximport mathimport rclpy                                              # ROS2 Python interface libraryfrom rclpy.node import Node                               # ROS2 node classimport tf_transformations                                 # TF coordinate transformation libraryfrom tf2_ros import TransformException                    # Exception class of TF coordinate transformationfrom tf2_ros.buffer import Buffer                         # Buffer class that stores coordinate transformation informationfrom tf2_ros.transform_listener import TransformListener  # Listener class that listens to coordinate transformationsfrom geometry_msgs.msg import Twist                       # ROS2 velocity control messagefrom turtlesim.srv import Spawn                           # Service interface for turtle spawningclass TurtleFollowing(Node):
    def __init__(self, name):        super().__init__(name)                                      # Initialize the parent class of the ROS2 node
        self.declare_parameter('source_frame', 'turtle1')           # Create a parameter for the source coordinate frame name        self.source_frame = self.get_parameter(                     # Prefer the parameter value set externally, otherwise use the default value            'source_frame').get_parameter_value().string_value
        self.tf_buffer = Buffer()                                   # Create a buffer that stores coordinate transformation information        self.tf_listener = TransformListener(self.tf_buffer, self)  # Create a listener for coordinate transformations
        self.spawner = self.create_client(Spawn, 'spawn')           # Create a client that requests turtle spawning        self.turtle_spawning_service_ready = False                  # Flag of whether the turtle spawning service has been requested        self.turtle_spawned = False                                 # Flag of whether the turtle has been spawned successfully
        self.publisher = self.create_publisher(Twist, 'turtle2/cmd_vel', 1) # Create the velocity topic of the following turtle
        self.timer = self.create_timer(1.0, self.on_timer)         # Create a timer with a fixed period to control the motion of the following turtle
    def on_timer(self):        from_frame_rel = self.source_frame                         # Source coordinate frame        to_frame_rel   = 'turtle2'                                 # Target coordinate frame
        if self.turtle_spawning_service_ready:                     # If the turtle spawning service has been requested            if self.turtle_spawned:                                # If the following turtle has been spawned                try:                    now = rclpy.time.Time()                        # Get the current time of the ROS system                    trans = self.tf_buffer.lookup_transform(       # Listen to the coordinate transformation from the source coordinate frame to the target coordinate frame at the current moment                        to_frame_rel,                        from_frame_rel,                        now)                except TransformException as ex:                   # If the coordinate transformation fails to be obtained, enter the exception report                    self.get_logger().info(                        f'Could not transform {to_frame_rel} to {from_frame_rel}: {ex}')                    return
                msg = Twist()                                      # Create a velocity control message                scale_rotation_rate = 1.0                          # Calculate the angular velocity according to the turtle angle                msg.angular.z = scale_rotation_rate * math.atan2(                    trans.transform.translation.y,                    trans.transform.translation.x)
                scale_forward_speed = 0.5                          # Calculate the linear velocity according to the turtle distance                msg.linear.x = scale_forward_speed * math.sqrt(                    trans.transform.translation.x ** 2 +                    trans.transform.translation.y ** 2)
                self.publisher.publish(msg)                        # Publish the velocity command, and the turtle follows            else:                                                  # If the following turtle has not been spawned                if self.result.done():                             # Check whether the turtle has been spawned                    self.get_logger().info(                        f'Successfully spawned {self.result.result().name}')                    self.turtle_spawned = True                else:                                              # The following turtle is still not spawned                    self.get_logger().info('Spawn is not finished')        else:                                                      # If the turtle spawning service has not been requested            if self.spawner.service_is_ready():                    # If the turtle spawning server is ready                request = Spawn.Request()                          # Create request data                request.name = 'turtle2'                           # Set the content of the request data, including the turtle name, xy position, and orientation                request.x = float(4)                request.y = float(2)                request.theta = float(0)
                self.result = self.spawner.call_async(request)     # Send the service request                self.turtle_spawning_service_ready = True          # Set the flag to indicate that the request has been sent            else:                self.get_logger().info('Service is not ready')     # Prompt that the turtle spawning server is not ready yet

def main(args=None):    rclpy.init(args=args)                       # Initialize the ROS2 Python interface    node = TurtleFollowing("turtle_following")  # Create and initialize a ROS2 node object    rclpy.spin(node)                            # Wait in a loop for ROS2 to exit    node.destroy_node()                         # Destroy the node object    rclpy.shutdown()                            # Shut down the ROS2 Python interface
Create a launch folder in the pkg_tf package, create a file 【turtle_following.launch.py】 in the launch folder, and add the following content:
xxxxxxxxxxfrom launch import LaunchDescriptionfrom launch.actions import DeclareLaunchArgumentfrom launch.substitutions import LaunchConfigurationfrom launch_ros.actions import Node
def generate_launch_description():        return LaunchDescription([        DeclareLaunchArgument('source_frame', default_value='turtle1', description='Target frame name.'),        Node(            package='turtlesim',            executable='turtlesim_node',        ),        Node(            package='pkg_tf',            executable='turtle_tf_broadcaster',            name='broadcaster1',            parameters=[                {'turtlename': 'turtle1'}            ]        ),        Node(            package='pkg_tf',            executable='turtle_tf_broadcaster',            name='broadcaster2',            parameters=[                {'turtlename': 'turtle2'}            ]        ),        Node(            package='pkg_tf',            executable='turtle_following',            name='listener',            parameters=[                {'source_frame': LaunchConfiguration('source_frame')}            ]        ),     ])
8. Editing the Configuration File
8.1. Configuration in setup.py
Import the related libraries
xxxxxxxxxximport osfrom glob import globAdd the node information of turtle_following, and add the following command to copy the launch file to the shared directory in install
xxxxxxxxxx(os.path.join('share',package_name,'launch'),glob('launch/*')),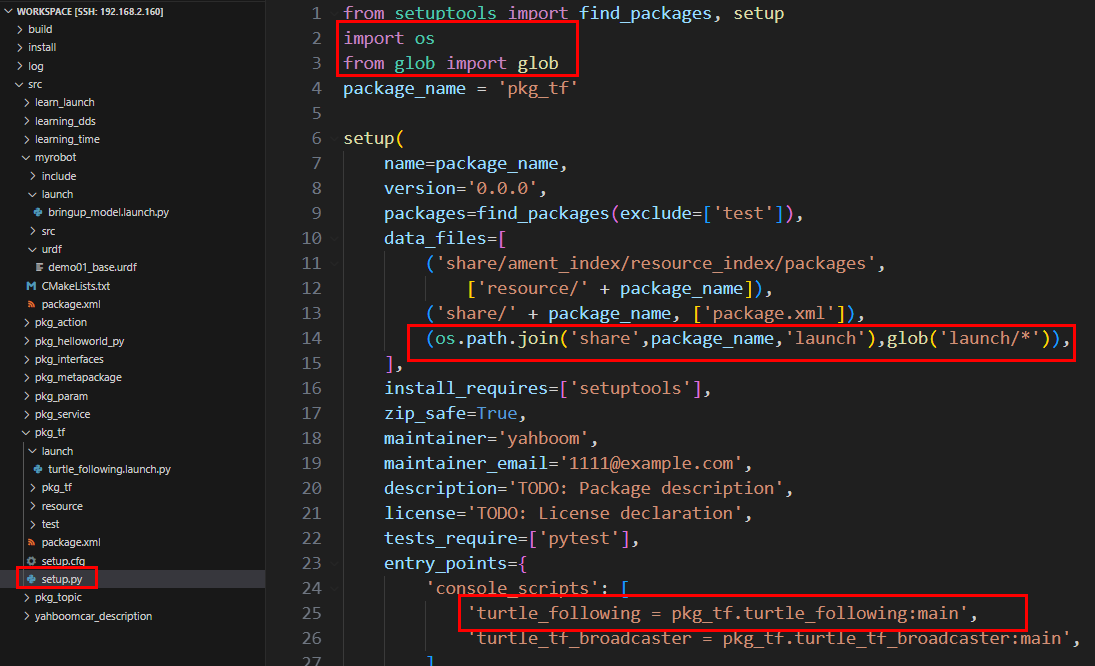
9. Building the Package
xxxxxxxxxxcolcon build --packages-select pkg_tf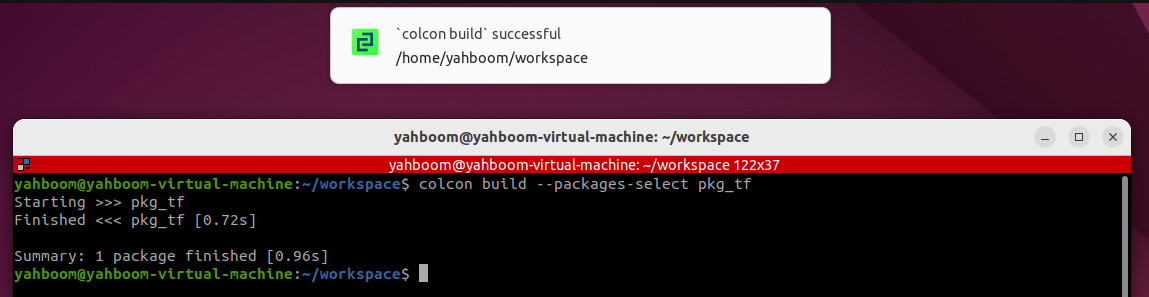
10. Running the Program
Refresh the terminal environment variables, and then run
xxxxxxxxxxros2 launch pkg_tf turtle_following.launch.py
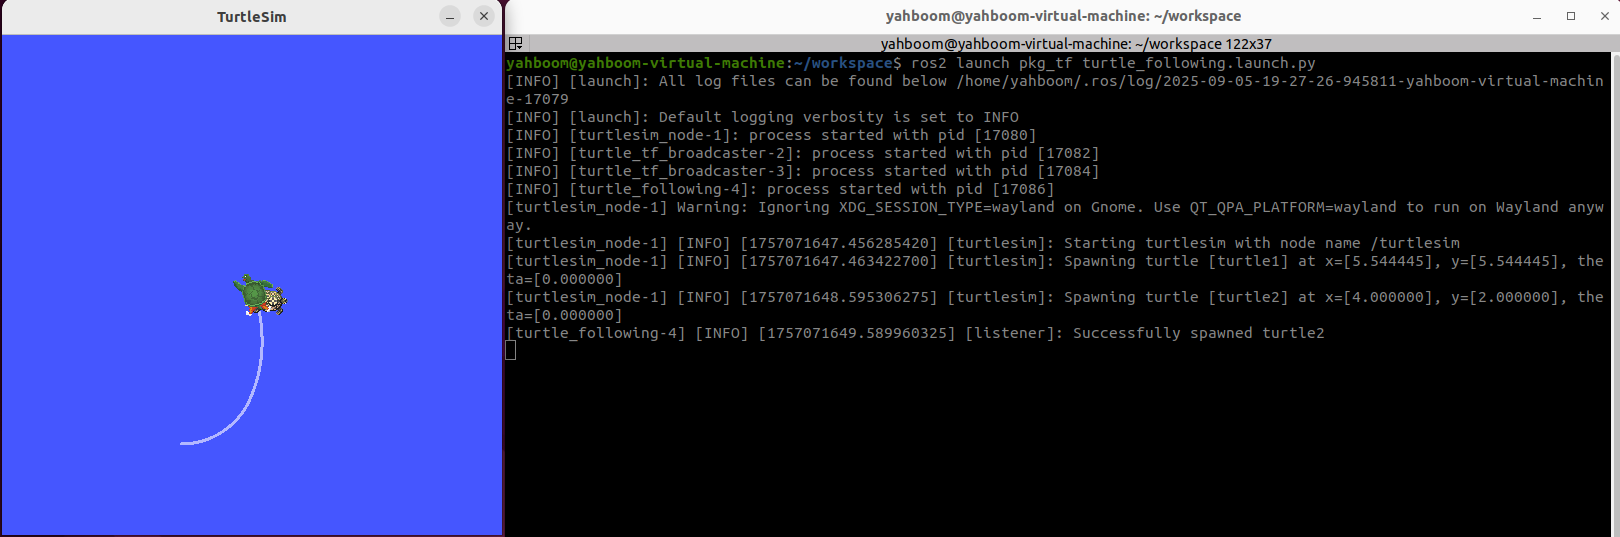
Start the turtle keyboard control node to control the first turtle, and the second turtle follows automatically
xxxxxxxxxxros2 run turtlesim turtle_teleop_key
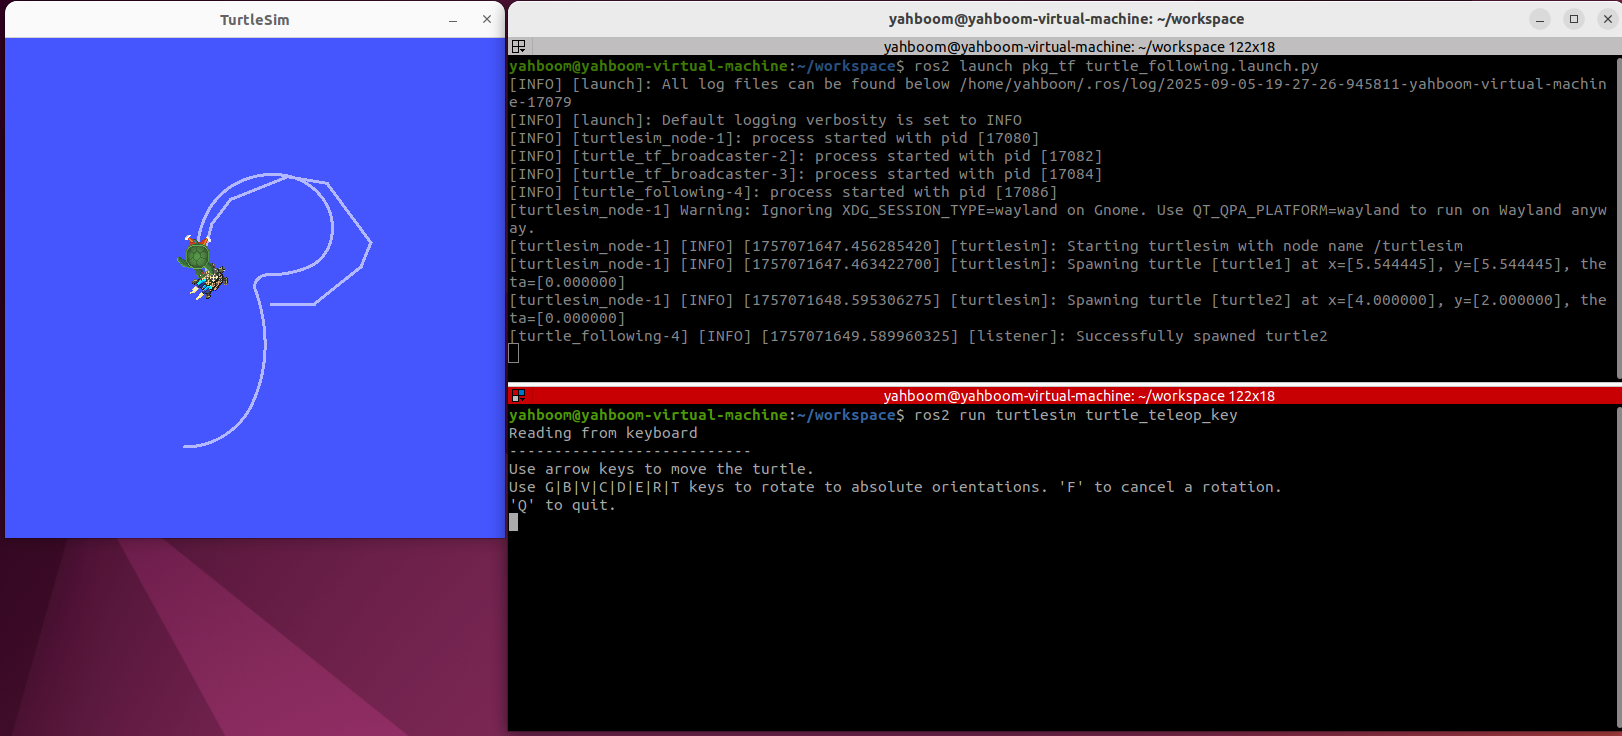
In this terminal, press the up, down, left, and right arrow keys on the keyboard to control one turtle to move, and then the other turtle follows until they overlap.
11. Advanced Content
Understand the ability of TF to transform across the time dimension
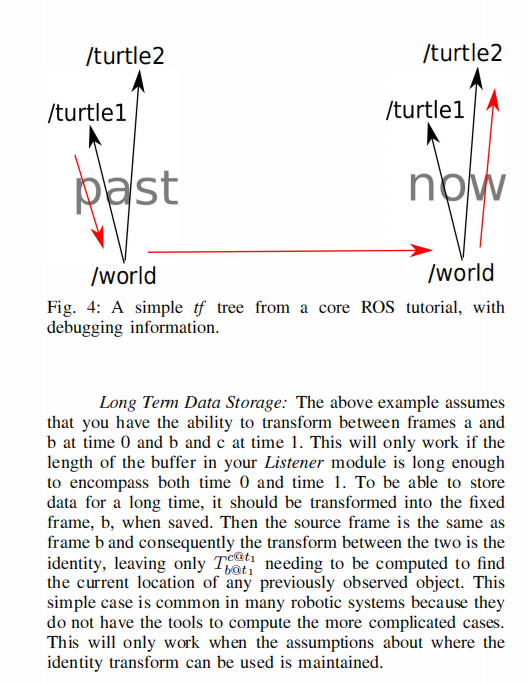
Buffer can automatically cache all TF transformation relationships in the TF system within the past 10 s through the buffer (any cache duration can be set by yourself through the Buffer constructor parameters). All transformations in the buffer are based on timestamps, and all transformations are continuously traceable. Even if the two coordinate frames are at different time points, the coordinate transformation relationship between them can still be found. For this point, you can refer to the reference document for designing the TF system, which explains the principle in detail (the document is in this lesson's folder, or through the link at the beginning of this section).
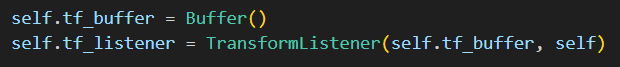
The following is a supplement to the turtle following case above. The red arrow indicates that the transformation between two coordinate frames at different time points can be found across time.