Welcome to Jetson Orin NANO Developer Kit repository
10.ROS2 custom interface message
10. ROS 2 Custom Interface Message
1. Introduction to Communication Interfaces
In the ROS system, whether it is a topic, a service, or an action, an important concept is always involved—the communication interface.
Communication is not a monologue; it involves two or more parties exchanging information. What is the content of the exchange? To make it easy for everyone to understand, we can define a standard structure for the transmitted data, and this is the communication interface.
Interfaces can reduce the dependencies between programs, making it easier for us to use other people's code and for others to use our code. This is the core goal of ROS: reducing the reinvention of the wheel.
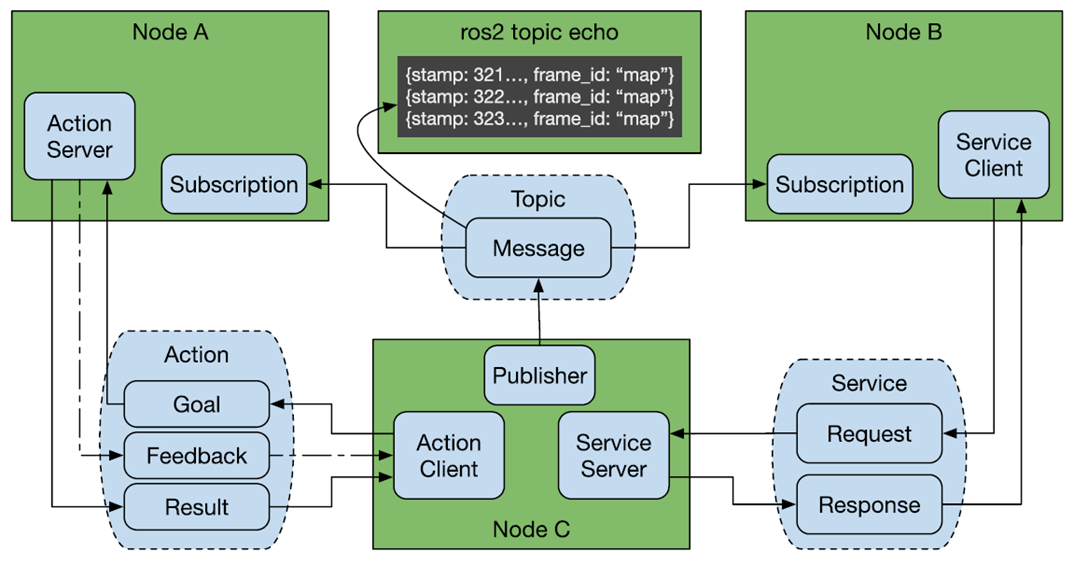
ROS has three commonly used communication mechanisms, namely topics, services, and actions. Only through the interfaces defined in each type of communication can various nodes be organically connected together.
2. Process of Creating a Custom Interface
The process of creating a custom interface message is similar to the process of writing an executable program in a package. The main steps are as follows:
Create an interface package;
Create and edit .msg files, .srv files, and .action files
Edit the configuration file;
Compile;
Test.
3. Creating a Custom Action Communication Interface
In the 【11. ROS 2 Action Communication Server Implementation】 case, we have already demonstrated the complete process of creating an action communication interface. You can go back and review it first; it will not be repeated here.
4. Creating a Custom Topic Communication Interface
In the 【ROS 2 Action Communication Server Implementation】 course, we have already created the custom interface package. Create a new msg folder under the package pkg_interfaces, create a new Person.msg file in the msg folder, and enter the following content in the file:
string nameint32 agefloat64 height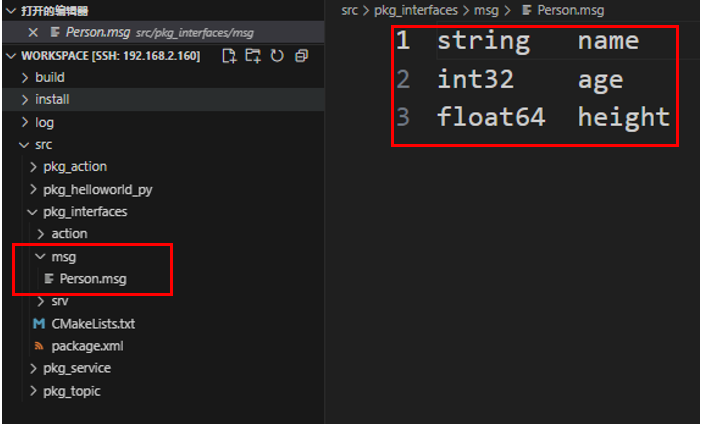
Add the following configuration to package.xml and CMakeLists.txt:
CMakeLists.txt
xxxxxxxxxxrosidl_generate_interfaces(${PROJECT_NAME} "action/Progress.action" "msg/Person.msg")package.xml
xxxxxxxxxx<buildtool_depend>rosidl_default_generators</buildtool_depend><exec_depend>rosidl_default_runtime</exec_depend><depend>action_msgs</depend><member_of_group>rosidl_interface_packages</member_of_group>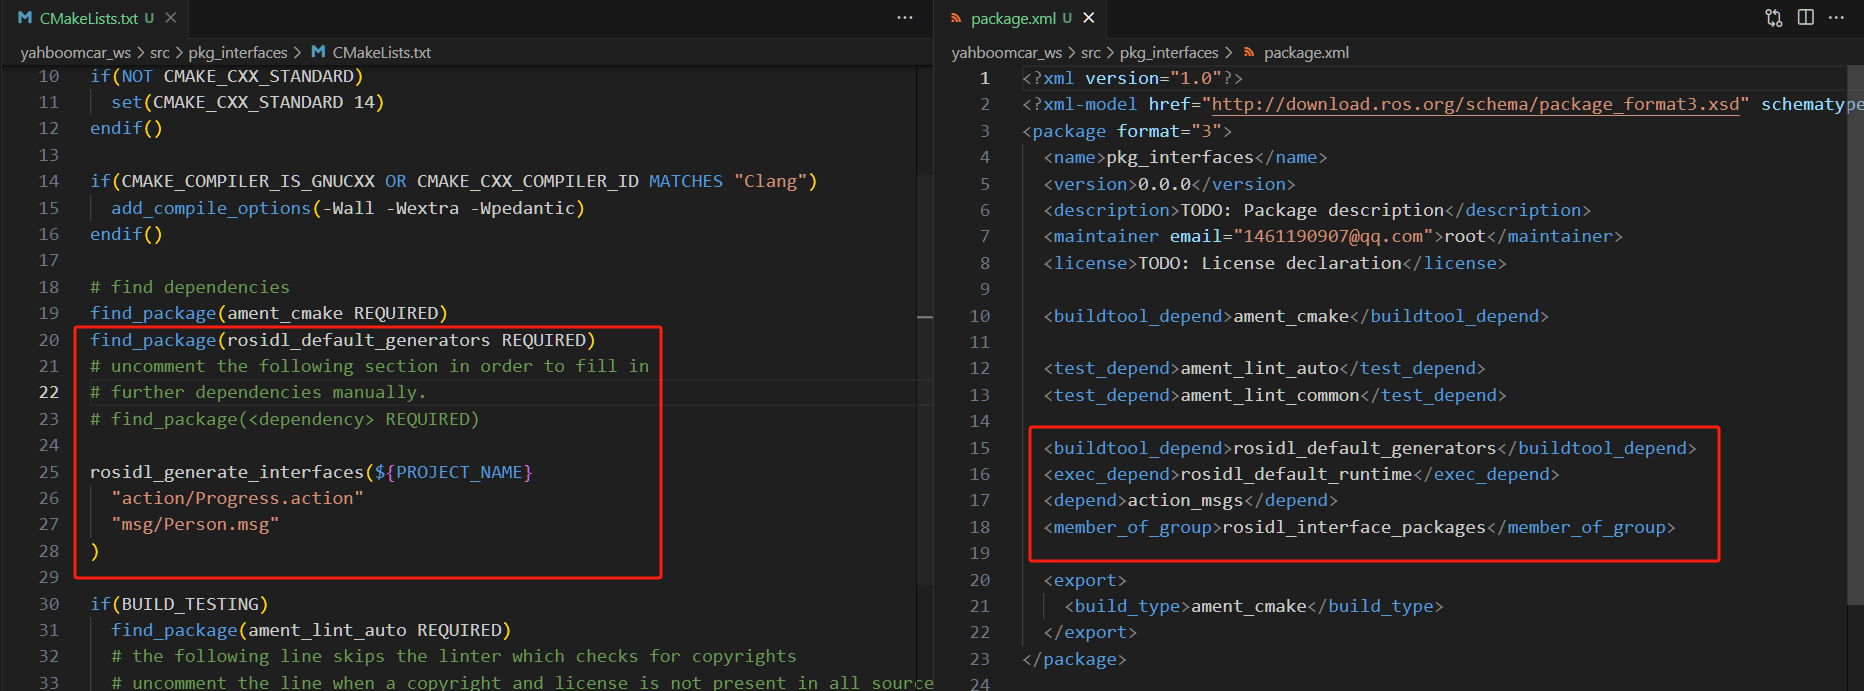
In the terminal, enter the current workspace and compile the package:
xxxxxxxxxxcolcon build --packages-select pkg_interfaces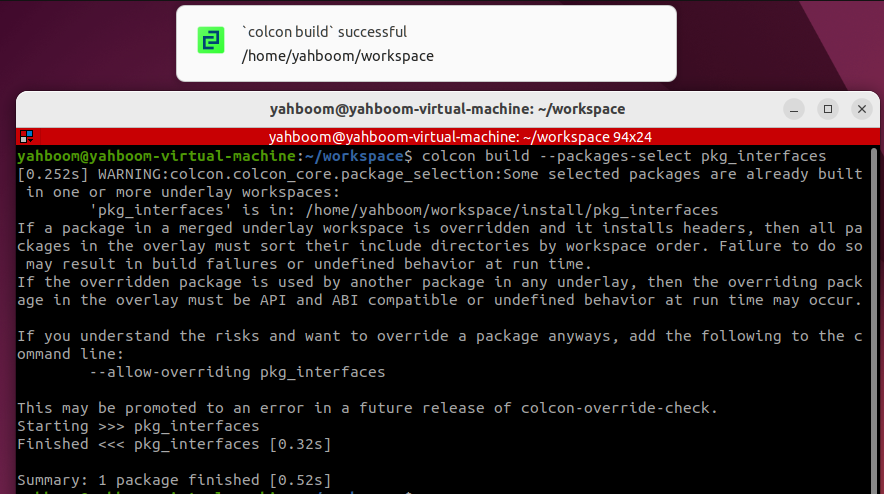
Test whether the interface is normal
Refresh the environment variables first
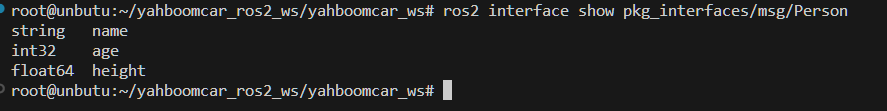
xxxxxxxxxxsource install/setup.bash Check the interface type
xxxxxxxxxxros2 interface show pkg_interfaces/msg/PersonUnder normal circumstances, the terminal will output content identical to the Person.msg file.
5. Creating a Custom Service Communication Interface
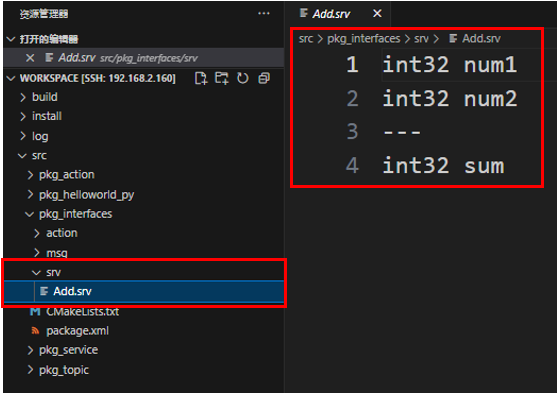
In the 【ROS 2 Action Communication Server Implementation】 course, we have already created the custom interface package. Create a new srv folder under the package pkg_interfaces, create a new Add.srv file in the srv folder, and enter the following content in the file:
xxxxxxxxxxint32 num1int32 num2---int32 sum
Add the following configuration to package.xml and CMakeLists.txt:
CMakeLists.txt
xxxxxxxxxxrosidl_generate_interfaces(${PROJECT_NAME} "action/Progress.action" "msg/Person.msg" "srv/Add.srv")package.xml
xxxxxxxxxx<buildtool_depend>rosidl_default_generators</buildtool_depend><exec_depend>rosidl_default_runtime</exec_depend><depend>action_msgs</depend><member_of_group>rosidl_interface_packages</member_of_group>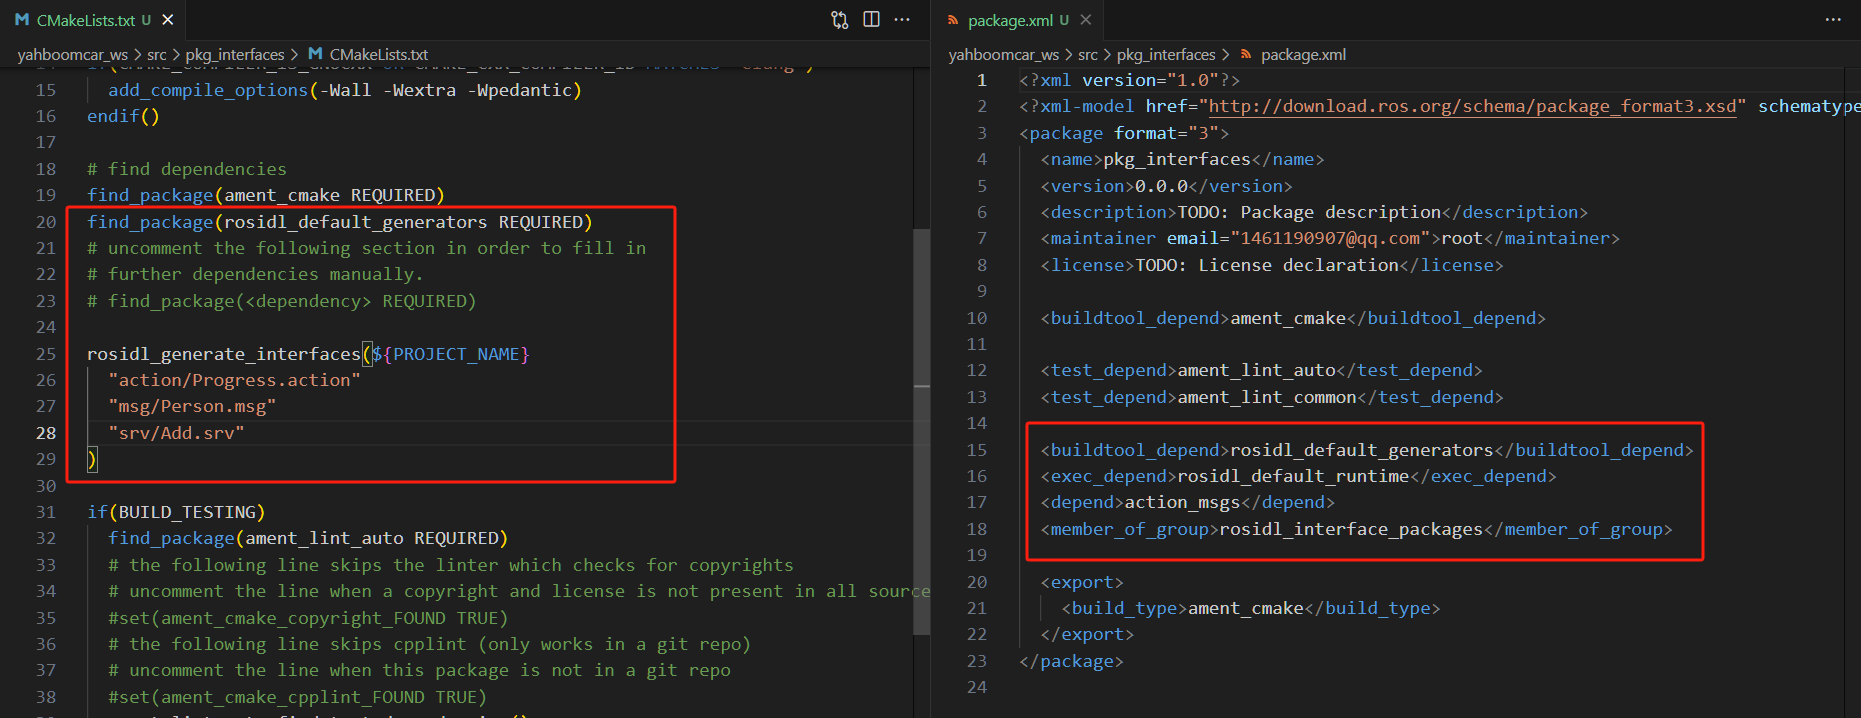
In the terminal, enter the current workspace and compile the package:
xxxxxxxxxxcd ~/yahboomcar_ros2_ws/yahboomcar_wscolcon build --packages-select pkg_interfacessource install/setup.bash
Test
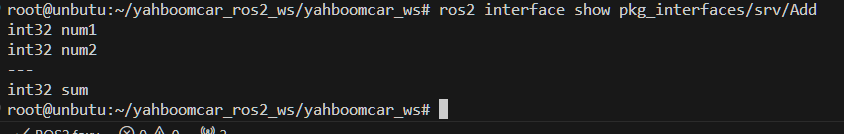
xxxxxxxxxxros2 interface show pkg_interfaces/srv/Add
Under normal circumstances, the terminal will output content identical to the Person.msg file.