yahboom
HomeTutorialsProduct
Solution
Blog
Online Store
About Us
EN/中文
Store
Jetson Orin NANO Developer Kit📖
01.Get started
  • 01. Learning route
  • 02. Get started quickly
  • 03. System Update Notes
  • 04. Disabling automatic updates and troubleshooting issues
  • 05. Jetson Orin Nano official kit screwdriver instructions
02.Jetson basic course
  • 01.Jetson board introduction
  • 02.Write Jetson original system
  • 03.Installing Jetson environment
  • 04.Backup SSD system
  • 05.Restore initial image system
  • 06.Upgrade to SUPER version (Optional)
  • 07.Write SUPER boot (Must read)
  • 08.SSD expansion
  • 09.Jetpack old system upgraded to Yahboom SUPER factory system
  • 10.Write the system onto your own SSD
03.Basic setting course
  • 01.Basic knowledge
  • 02.Network configuration
  • 03.SSH remote login
  • 04.VNC remote control
  • 05.RDP remote control
  • 06.Remote file transfer
  • 07.Jtop tool
  • 08.Exchange space expansion
  • 09.Use VSCode
  • 10.Use VMware
  • 11.Modify screen resolution
04.GPIO control course
  • 01.GPIO description
  • 02.GPIO library installation
  • 03.GPIO reading
  • 04.GPIO output
  • 05.Serial communication
  • 06.I2C communication
05.Vision basic course
  • 01.CSI camera preview
  • 02.USB camera preview
  • 03.Use Jupyter Lab
  • 04.Use JetCam
06.OpenCV basic course
  • 01.Image reading
  • 02.Image saving
  • 03.Image modification
  • 04.Image scaling
  • 05.Image cropping
  • 06.Image translation
  • 07.Image mirroring
  • 08.Image grayscale conversion
  • 09.Image binarization
  • 10.Image edge detection
  • 11.Add line segments
  • 12.Add rectangles
  • 13.Add circular shape
  • 14.Add ellipses
  • 15.Add polygons
  • 16.Add Text
  • 17.Preview USB camera image
  • 18.Preview CSI camera image
07.Vision advanced course
01.Environment construction
  • 01.TensorFlow
  • 02.PyTorch
  • 03.Torchvision
02.DeepStream development
  • 01.DeepStream environment
  • 02.License plate detection and recognition
  • 03.Parallel multi-model inference
  • 04.Object embedding vector generation
  • 05.Pose recognition
  • 06.NV optical flow anomaly detection
  • 07.Single-view 3D tracking
  • 08.Multi-view 3D tracking
03.NVIDIA TAO toolkit application
  • 01.Traffic scene object detection
  • 02.Person object detection
  • 03.Vehicle brand classification
  • 04.Vehicle model classification
  • 05.License plate detection and recognition
  • 06.Person semantic segmentation
  • 07.Retail product detection and recognition
  • 08.Person feature extraction and matching (ReID)
  • 09.Person action and pose classification
  • 10.Transformer-based person detection
  • 11.3D human skeleton detection
  • 12.LiDAR 3D point cloud detection
04.YOLO11 development
  • 01.YOLO environment construction
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training conversion
  • 11.Model prediction
05.Mediapipe development
  • 01.Mediapipe environment
  • 02.Hand detection
  • 03.Face detection
  • 04.Face effects
  • 05.3D object recognition
  • 06.Virtual brush
  • 07.Gesture recognition
  • 08.Finger control
  • 09.Posture estimation
  • 10.Face mask
  • 11.Overall detection
  • 12.Green scene removal(Human)
06.YOLO26 development
  • 01.YOLO environment construction
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training conversion
  • 11.Model prediction
07.QR code recognition
  • QR code recognition
08.Docker basic course
  • 01.Docker introduction
  • 02.Docker installation
  • 03.Docker command
  • 04.Docker usage
  • 05.Docker interaction
09.ROS2-Jazzy
01.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Jazzy
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
02.ROS2 vision course
  • 01.Camera preview (USB)
  • 02.Camera preview (CSI)
  • 03.Camera calibration (USB)
  • 04.Camera calibration (CSI)
  • 05.AR vision (USB)
  • 06.AR vision (CSI)
10.Large model basic course
01.Offline large model
  • 01.AI large model environment deployment
  • 02.Install large model dialogue platform
  • 03.Meta AI - Llama model
  • 04.Alibaba Cloud - Qwen model
  • 05.Microsoft - Phi-4-mini model
  • 06.DeepSeek - DeepSeek model
  • 07.Alibaba Cloud - Qwen-VL visual multimodal large model
  • 08.Google - Gemma visual multimodal large model
  • 9.Llava visual multimodal large model
  • 10.MiniCPM-V visual multimodal large model
  • 11.High-quality vision-language grounding (LocateAnything)
02.Online large model
  • 01.Tongyi Qianwen large model
  • 02.OpenRouter large model API aggregation platform
11.Large model application practice
01.Voice interaction application
  • 1.Voice interaction hardware connection (Must read)
  • 2.Offline speech to text (ASR)
  • 3.Offline text to speech (TTS)
  • 4.AI large model voice interaction
  • 5.AI large model offline voice assistant
02.Multimodal large model application (Online_Offline large model + Text_Voice interaction)
  • 01.Multimodal visual understand application
  • 02.Multimodal text image application
  • 03.Multimodal video analysis application
  • 04.Multi module visual position application
  • 05.Multimodal table scanning application
  • 06.Multimodal autonomous agent application
12.NVIDIA Isaac ROS course
  • 01.Build Isaac ROS environment
  • 02.Deep segmentation
  • 03.DNN stereoscopic depth
  • 04.Free space segmentation
  • 05.Image distortion processing
  • 06.Image segmentation
  • 07.3D scene reconstruction and mapping
  • 08.Object detection
  • 09.3D attitude estimation
  • 10.Visual SLAM
13.OpenClaw deployment and basic usage
01.OpenClaw deployment and introduction
  • 01.Quick start with the pre-configured environment (Recommended)
  • 02.OpenClaw Deployment
  • 03.OpenClaw WhatsApp Plugin Application
  • 04.OpenClaw WebChat Interaction
  • 05.OpenClaw TUI Interaction
  • 06.OpenClaw Tools Introduction
  • 07.OpenClawGate Gateway User Manual
  • 08.OpenClaw Features Overview
  • 09.OpenClawHub Introduction (Skill Installation)
02.OpenClaw basic application
  • 01.OpenClaw Application - File Management
  • 02.OpenClaw Application - Camera
  • 03.OpenClaw Application - Browser Control
  • 04.OpenClaw Application - Script Execution
  • 05.OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 06.OpenClaw Application - Dedicated AI Assistant
  • 07.OpenClaw Web Search Capability Configuration
03.NVIDIA official Agent Skills application
  • 01.AI-assisted development with VS Code or Cursor
  • 02.Jetson device skills
  • 03.Jetson BSP custom agent skills
14.OpenClaw advanced development
01.Preparation Before Use
  • 01.Peripheral Hardware Configuration
  • 02.OpenClaw API-KEY Configuration
  • 03.OpenClaw Model Switching
  • 04.OpenClaw Prompts
  • 05.AI Voice Interaction Configuration
  • 06.Three Dialogue Configuration Tests
02.OpenClaw AI Programming Peripheral Control
  • 1. Servo Control
  • 2. RGB Strip
  • 3. OLED Display
  • 4. Temperature and Humidity Sensor
  • 5. Camera Application
  • 6. AI Script Peripheral Control
03.OpenClaw Peripheral Integration Applications
  • 1. Plant Care Assistant
  • 2. AI Calorie Estimation
  • 3. AI Rock Paper Scissors Game
  • 4. AI Pet
  • 5. AI Weather Station
  • 6. Temperature Humidity Dashboard
  • 7. Scheduled Tasks
Download
  • System_File
  • VMFile_BootFile
  • 3D Model File
  • DataSheet
  • Software_Tools
  • Code
  • Manual
Download ZIP

Welcome to Jetson Orin NANO Developer Kit repository

06.Three Dialogue Configuration Tests

OpenClaw Three Dialogue Solution Configuration Tests

OpenClaw Three Dialogue Solution Configuration Tests1. Course Overview2. Three Dialogue Solutions Introduction2.1 whatsapp Solution2.2 TUI Solution2.3 Voice Interaction Solution3. whatsapp Dialogue Configuration and Testing3.1 Install whatsapp Plugin3.2 Testing Method3.3 Common Problems4. TUI Dialogue Configuration and Testing4.1 Startup Method4.2 Testing Method5. AI Voice Interaction Configuration and Testing5.1 Pre-startup Preparation5.2 Startup Method5.3 Testing Method5.4 Judgment Criteria5.5 Common Problems6. Three Solutions Comparison7. Recommended Testing Order

1. Course Overview

This course will introduce three common dialogue methods in OpenClaw, and provide their respective configuration and testing methods:

  • whatsapp dialogue

  • Local TUI dialogue

  • AI voice interaction dialogue

After completing this course, you will be able to choose the most suitable dialogue method for your scenario and complete basic verification.

Note: whatsapp robot and AI voice interaction use the default model. If you need to change the default large model, see [03. OpenClaw Model Switching]

2. Three Dialogue Solutions Introduction

2.1 whatsapp Solution

Suitable scenarios:

  • Mobile phone remote control

  • Let multiple people experience OpenClaw together

Features:

  • No need to stay by the device all the time

  • Suitable for demonstrating "remote natural language control"

2.2 TUI Solution

Suitable scenarios:

  • Local debugging

  • Quick testing

  • Troubleshooting model and skill invocation issues

Features:

  • Most direct

  • Easiest to see commands and return results

2.3 Voice Interaction Solution

Suitable scenarios:

  • Complete AI interaction experience

  • Voice wake-up and voice control

  • Desktop assistant-style experience

Features:

  • Strongest sense of interaction

3. whatsapp Dialogue Configuration and Testing

If optional AI voice module + speaker are selected, whatsapp dialogue, tui, whatsapp dialogue need to broadcast OpenClaw's reply content. You can run the following program in terminal. AI voice module dialogue does not need to run repeatedly

  • Modify whether to enable broadcast parameter

/home/jetson/voice_to_openclaw/.env
xxxxxxxxxx
ENABLE_TTS=true
TTS_ENGINE=xunfei_ws
TTS_API_URL=wss://tts-api.xfyun.cn/v2/tts
TTS_VOICE=x4_xiaoyan
TTS_SAMPLE_RATE=16000
TTS_VOLUME=50
TTS_TIMEOUT=60
XUNFEI_TTS_SPEED=50
XUNFEI_TTS_PITCH=50
XUNFEI_TTS_TEXT_ENCODING=UTF8
XUNFEI_TTS_SIGN_HOST=ws-api.xfyun.cn
WAKE_ACK_TEXT=I am here.
TTS_MAX_CHARS=200
TTS_TRUNCATE_MODE=smart
TTS_LOCK_PATH=/tmp/voice_to_openclaw_tts.lock
# Terminal log language: zh / en
UI_LANGUAGE=en
xxxxxxxxxx
ENABLE_TTS=true  #This parameter controls whether to broadcast. After modification and saving, run the following program in terminal
  • Terminal input

xxxxxxxxxx
cd ~/voice_to_openclaw
source .venv/bin/activate
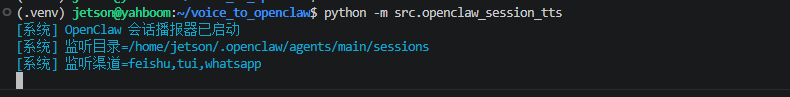
python -m src.openclaw_session_tts

image-20260529190411588

3.1 Install whatsapp Plugin

Terminal input:

xxxxxxxxxx
openclaw channels login --channel whatsapp

After execution, a QR code will usually appear.
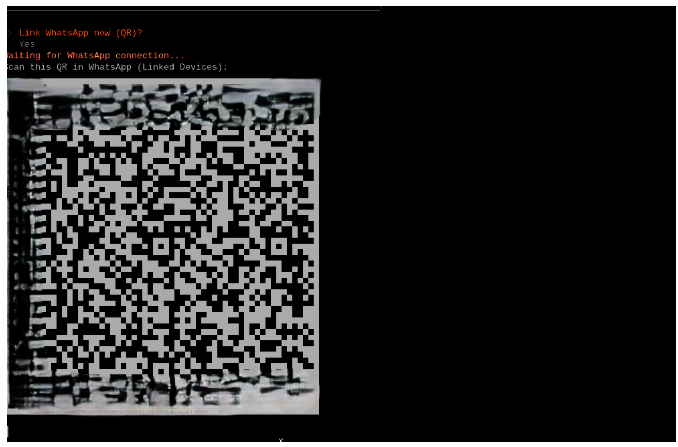
image-20260428121135578

  • Scan the QR code on the mobile phone to connect. "Linked after restart" appears, proving the connection is successful

image-20260509154627581

  • Open the newly created conversation to see the conversation ID
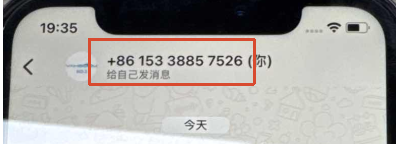
image-20260509155008132

  • Fill this into "allowFrom" in the openclaw.json file:

xxxxxxxxxx
nano /home/jetson/.openclaw/openclaw.json
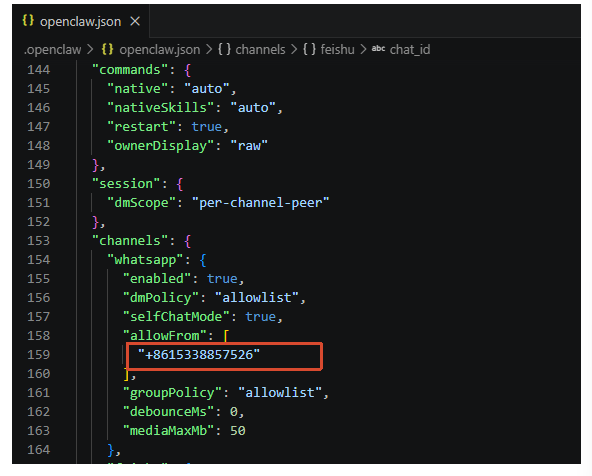
image-20260509155030351


  • Restart OpenClaw gateway

xxxxxxxxxx
openclaw gateway restart

3.2 Testing Method

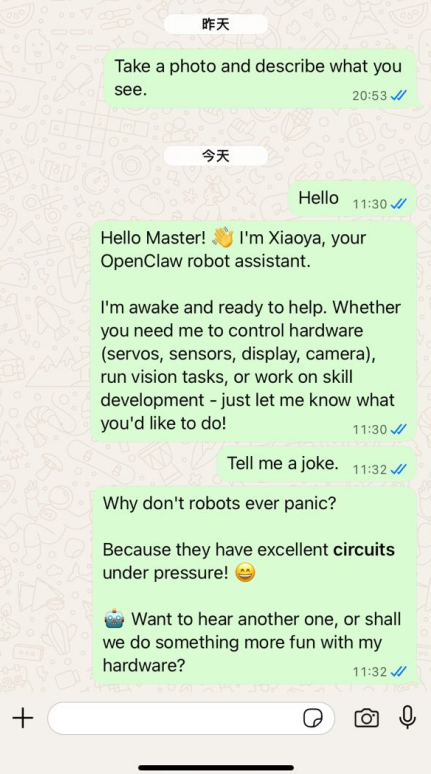
After creation, you can directly send test messages in whatsapp, for example:

  • Tell me a joke

image-20260428121335021


3.3 Common Problems

  • Cannot create robot after scanning code: First check network

  • Created successfully but no reply: Check if OpenClaw gateway has restarted successfully


4. TUI Dialogue Configuration and Testing

4.1 Startup Method

Terminal input:

xxxxxxxxxx
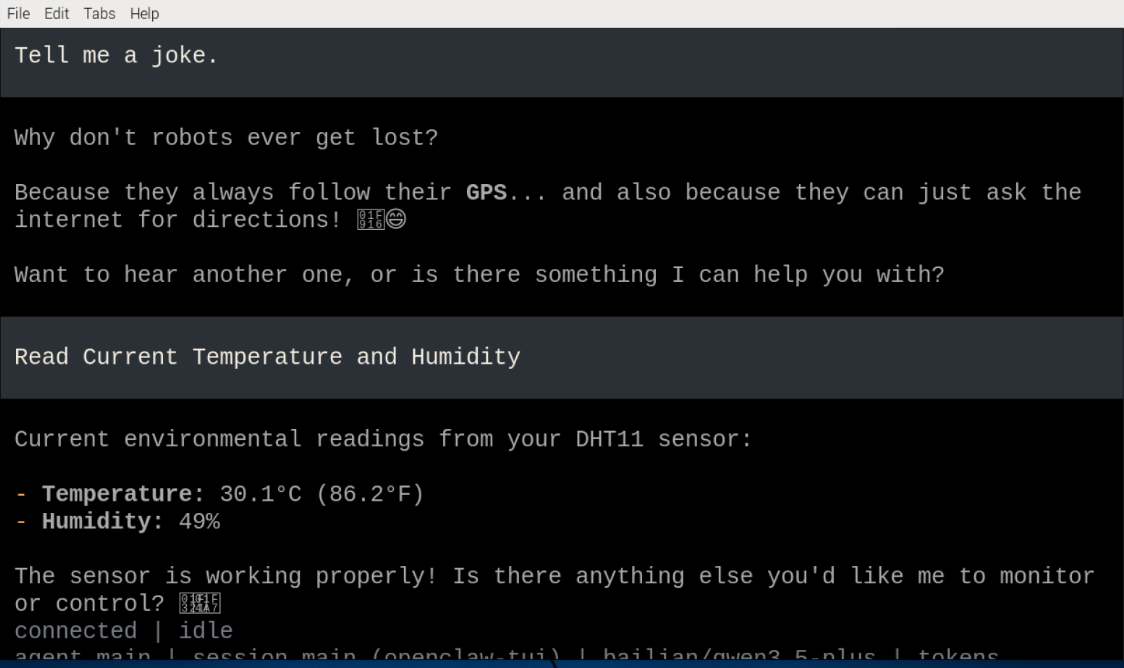
openclaw tui

If startup is successful, you will enter the local terminal dialogue interface.
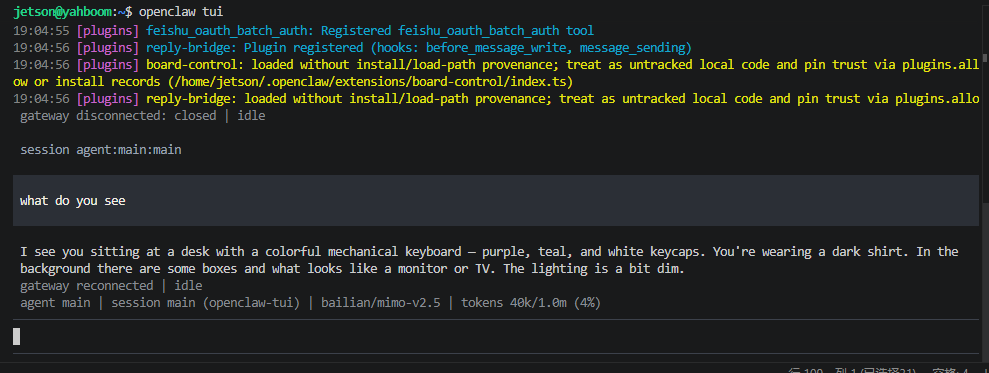
image-20260529190525361

4.2 Testing Method

It is recommended to first input the simplest dialogue content:

  • Tell me a joke

  • Introduce yourself

If basic dialogue is normal, then test a hardware-related command, for example:

  • Turn RGB light to red

  • Display hello on OLED

  • Read current temperature and humidity

image-20260428121606743

5. AI Voice Interaction Configuration and Testing

5.1 Pre-startup Preparation

  • Requires optional AI voice interaction module + speaker

5.2 Startup Method

xxxxxxxxxx
cd /home/jetson/voice_to_openclaw
source .venv/bin/activate
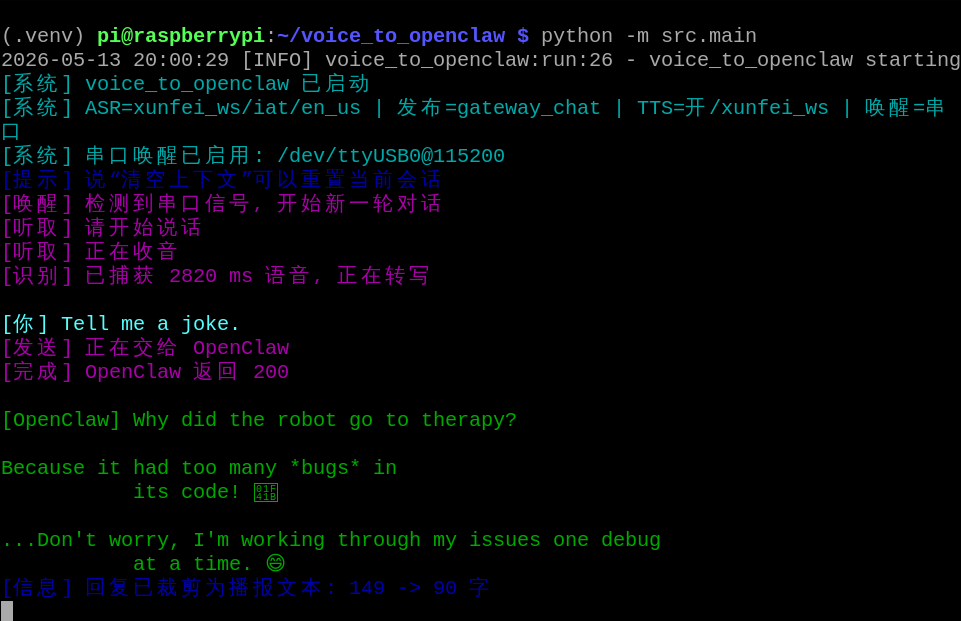
python -m src.main

5.3 Testing Method

If using serial wake mode, first trigger wake-up with "Hello, Xiaoya".

Then you can try saying:

  • Tell me a joke

  • Turn on RGB light

  • Display "Welcome to OpenClaw" on OLED

image-20260529190557153

5.4 Judgment Criteria

If voice method can complete recognition and receive OpenClaw reply, it indicates the following items are probably normal:

  • Microphone collection is normal

  • ASR is normal

  • OpenClaw publishing pipeline is normal

  • [Optional] TTS is normal

5.5 Common Problems

  • No response to wake-up: First check serial wake configuration

  • Can wake up but cannot recognize: Check ASR and API-KEY

  • Can recognize but does not execute: Check OpenClaw gateway configuration

  • Has return but no broadcast: Check TTS switch and speaker

6. Three Solutions Comparison

SolutionSuitable ScenariosAdvantagesRecommended Positioning
whatsappRemote control, classroom demonstrationsConvenient for mobile and multi-person experienceDemonstrate "remote natural language control"
TUILocal debugging, command verificationMost direct, easiest to troubleshootPreferred basic debugging solution
Voice interactionVoice wake-up, complete experienceStrongest sense of interactionFinal demonstration solution

7. Recommended Testing Order

It is recommended to complete the three dialogue solution tests in the following order:

  1. First test openclaw tui

  2. Then test whatsapp robot

  3. Finally test AI voice interaction

AI Voice Interaction Configuration
Servo Control

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文