Welcome to Jetson Orin NANO Developer Kit repository
18.ROS2 rqt toolbox
18. ROS 2 Rqt Toolbox
The folder of this tutorial contains a demo animation git file, so you can intuitively see the operation flow of the case in this lesson
1. Introduction to Rqt
Rqt is another modular visualization tool provided by ROS. As its name suggests, like Rviz, it is also developed based on the QT visualization tool. Before use, we need to install it with a command like this, and then we can start it with the rqt command.
2. Installation
Generally, the Rqt toolbox is installed by default as long as the desktop version is installed;
If the full version was not installed when installing ROS and you need it, you can install it as follows
sudo apt install ros-${ROS_DISTRO}-rqt*
3. Startup
Common rqt startup commands are:
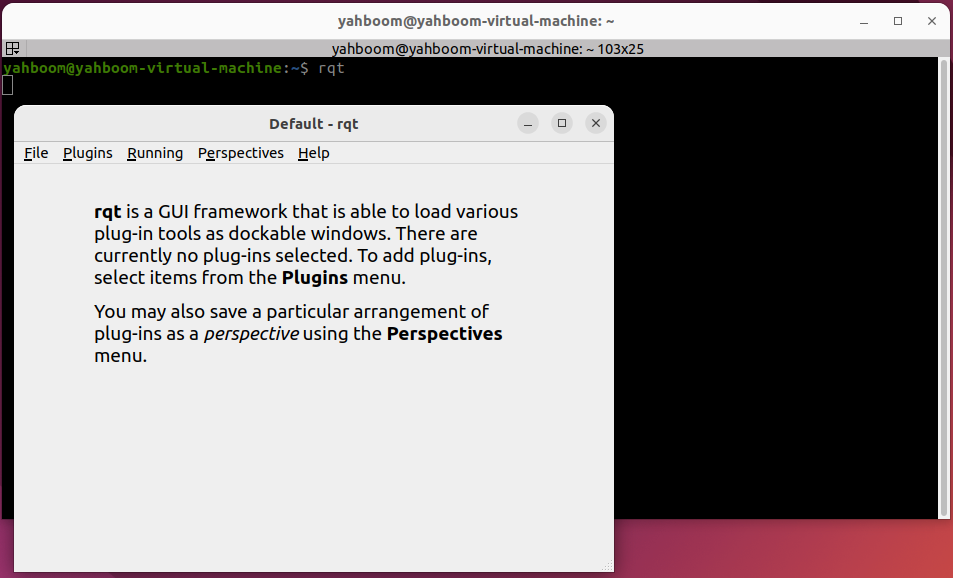
Method 1:
rqt
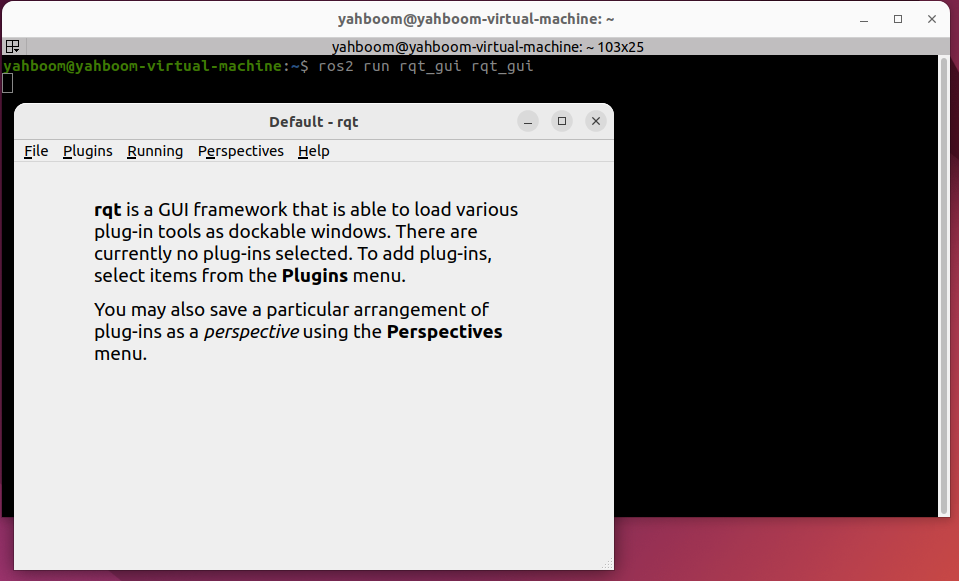
Method 2:
ros2 run rqt_gui rqt_gui
4. Plugin Usage
After starting rqt, you can add the required plugins through the plugins section:
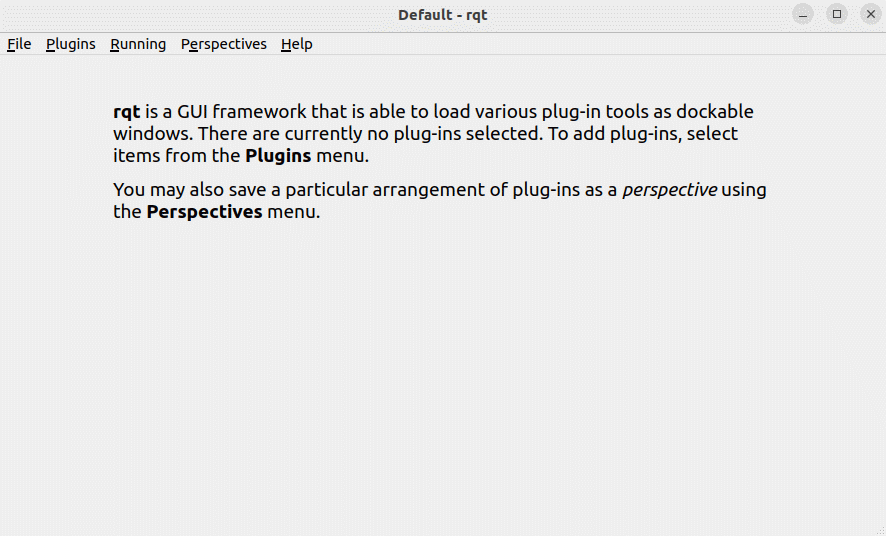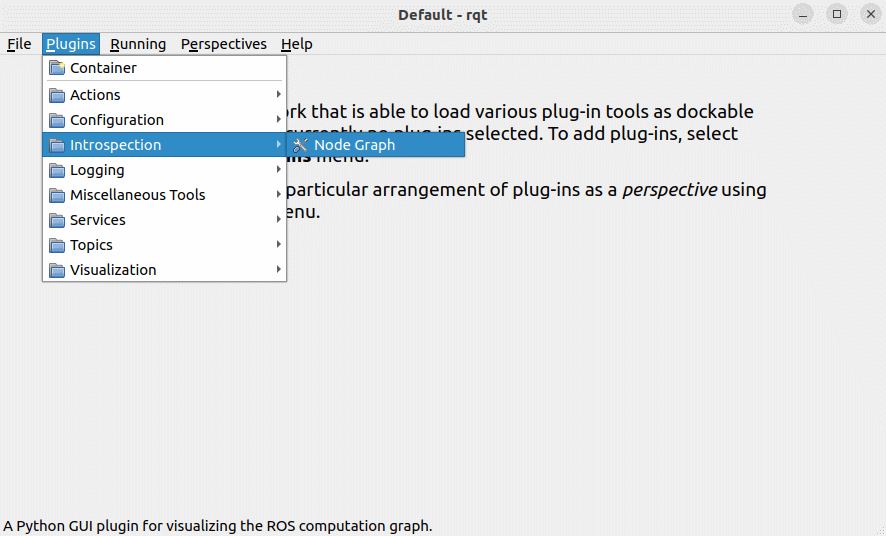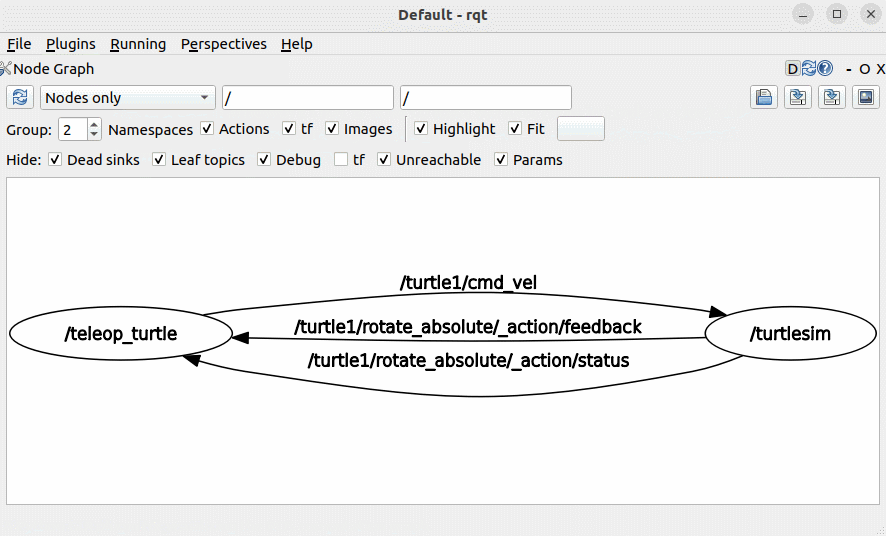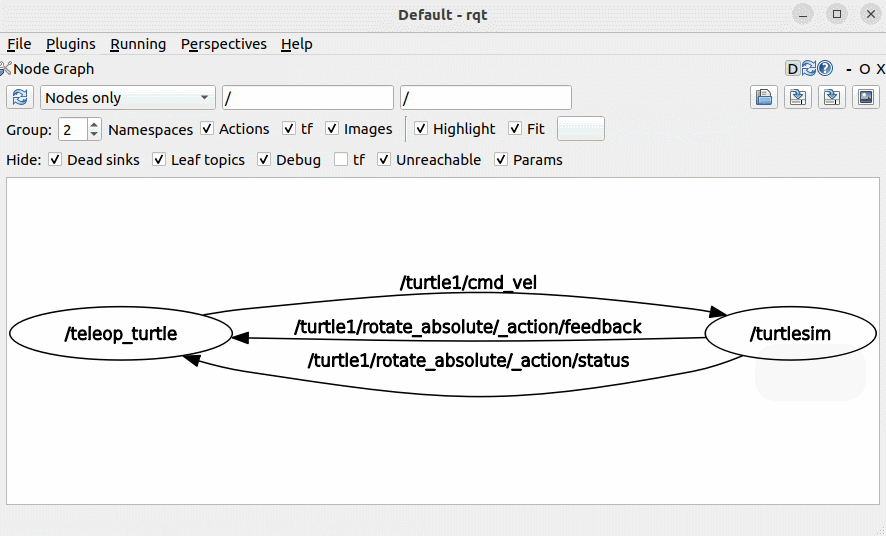
The plugins section contains plugins related to topics, services, actions, parameters, logs, and so on. You can select them as needed to conveniently implement debugging of ROS 2 programs. Usage examples are as follows.
4.1. Topic Plugin
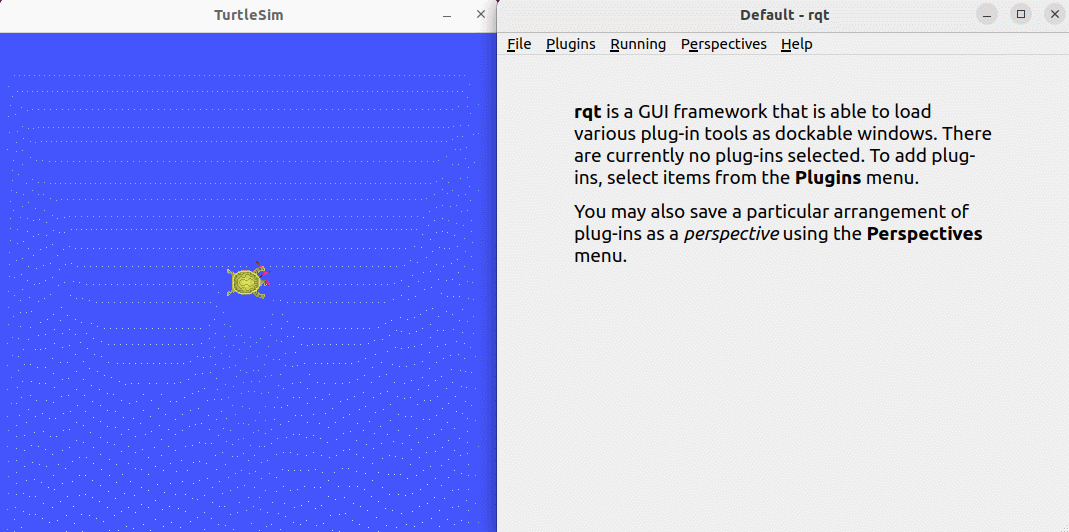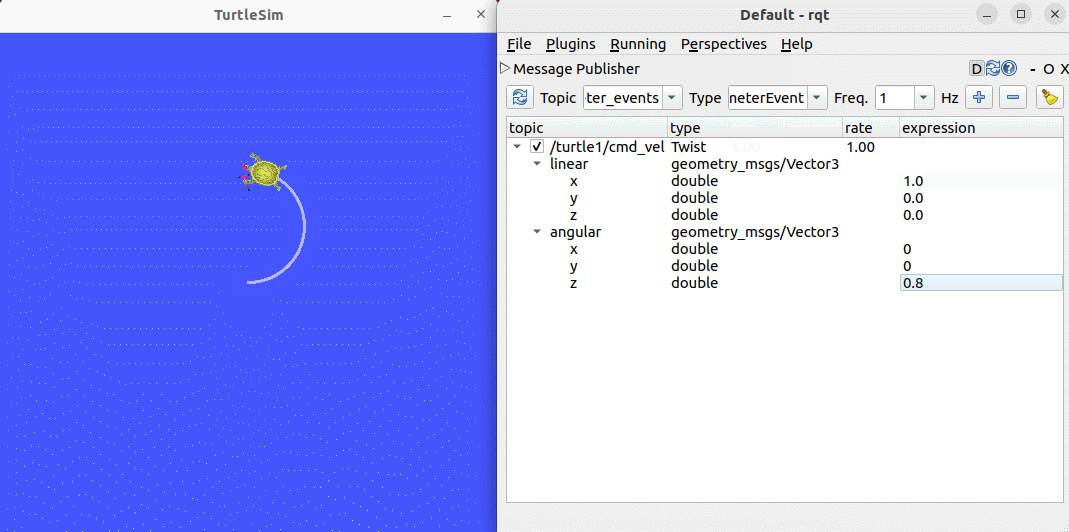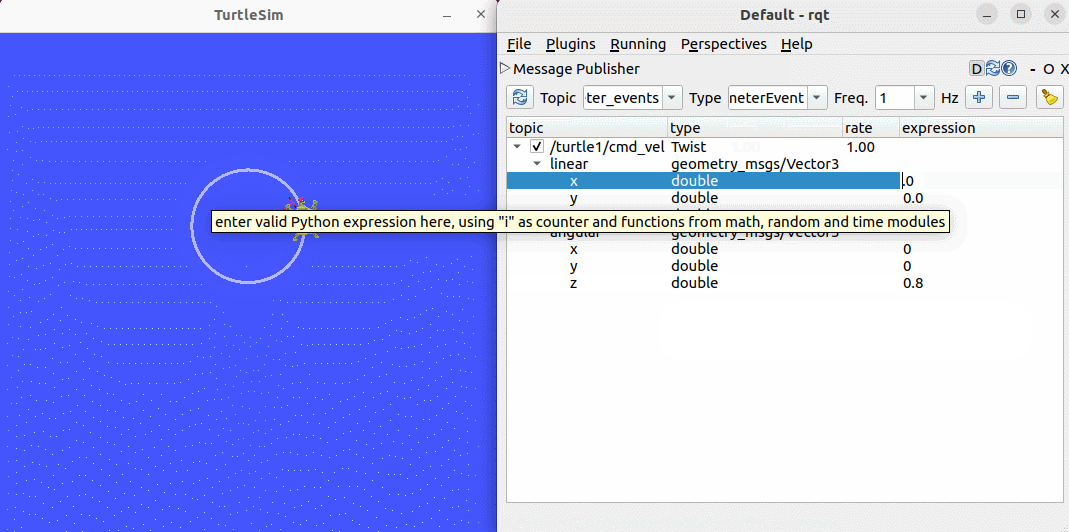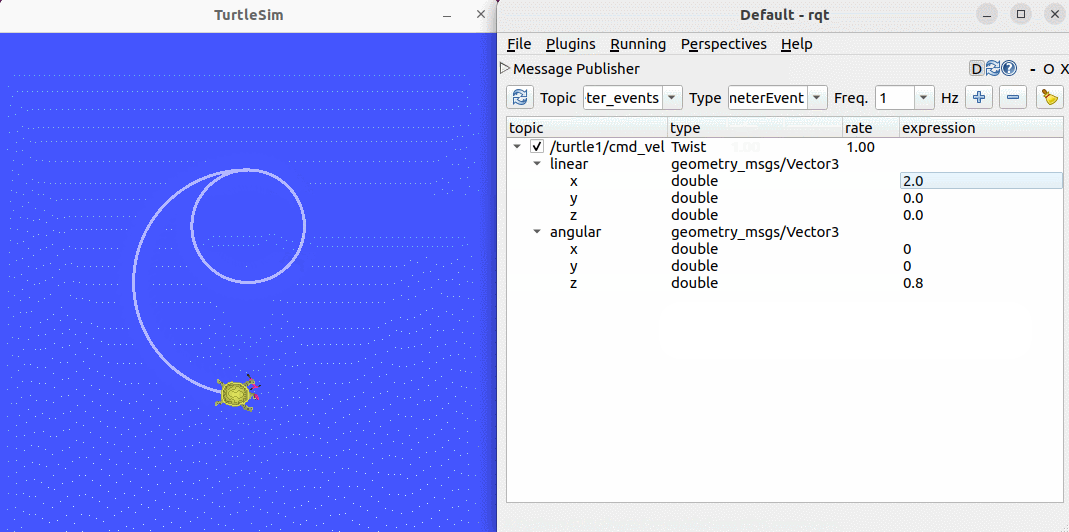
Add the topic plugin and send velocity commands to control the turtle's movement.
4.2. Service Plugin
Add the service plugin and send a request to spawn a turtle at a specified position.
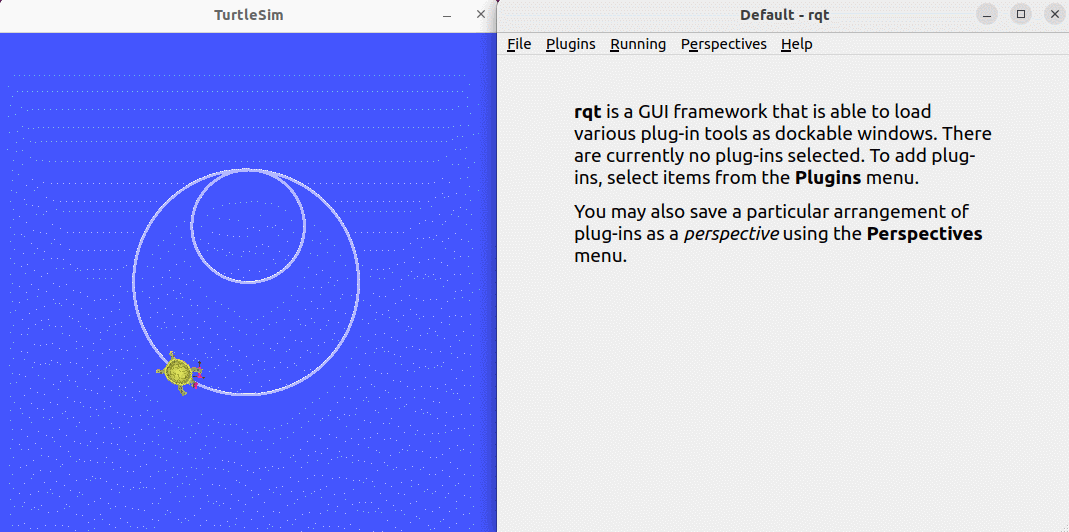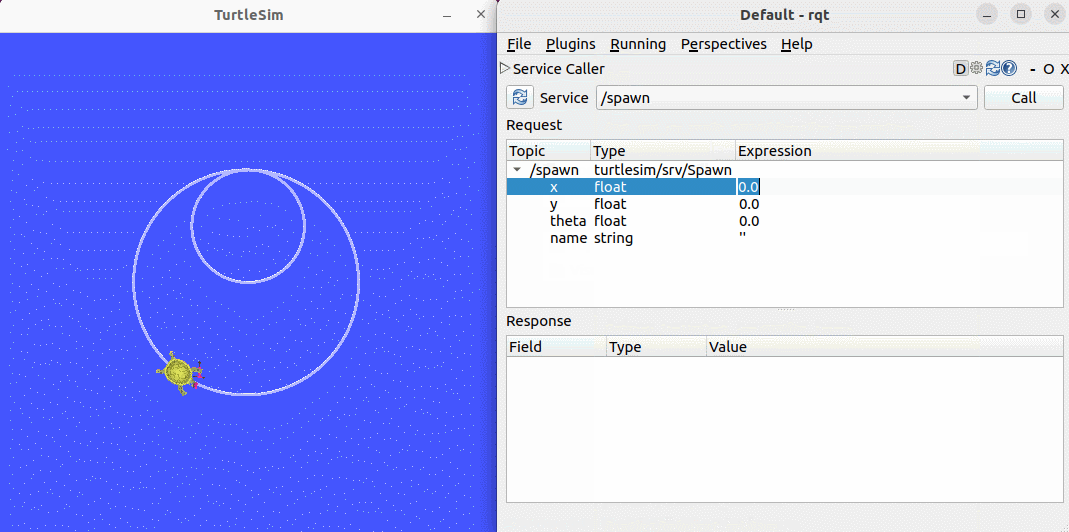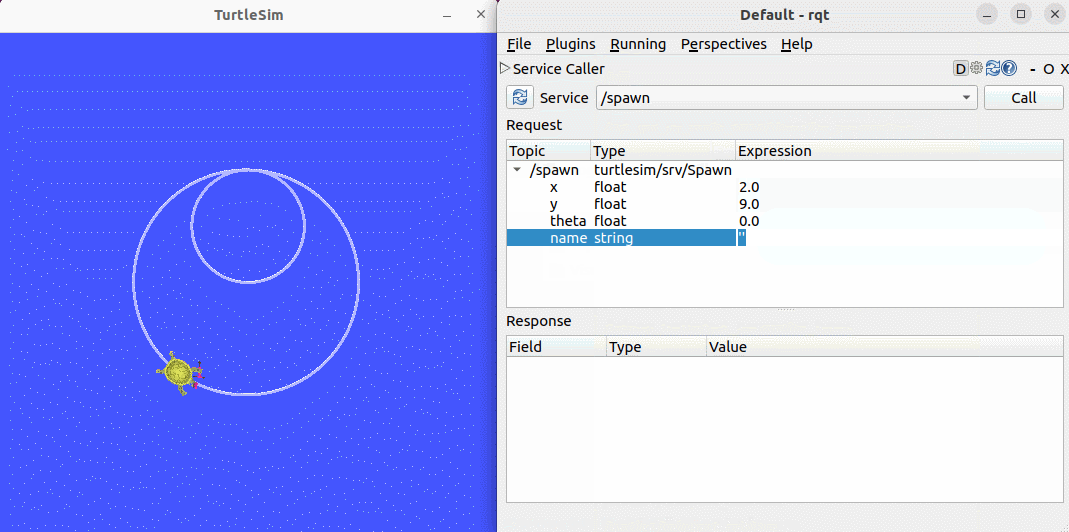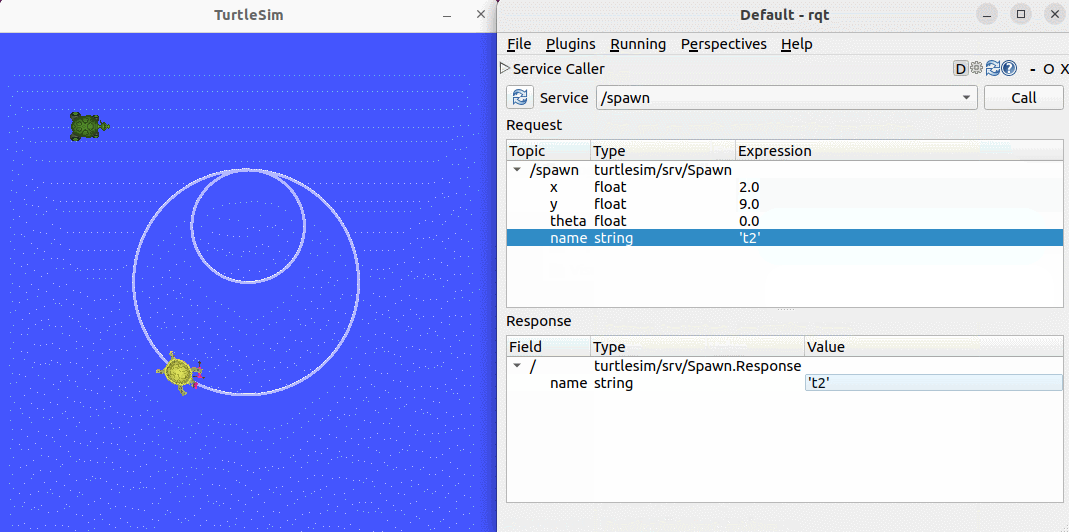
4.3. Parameter Plugin
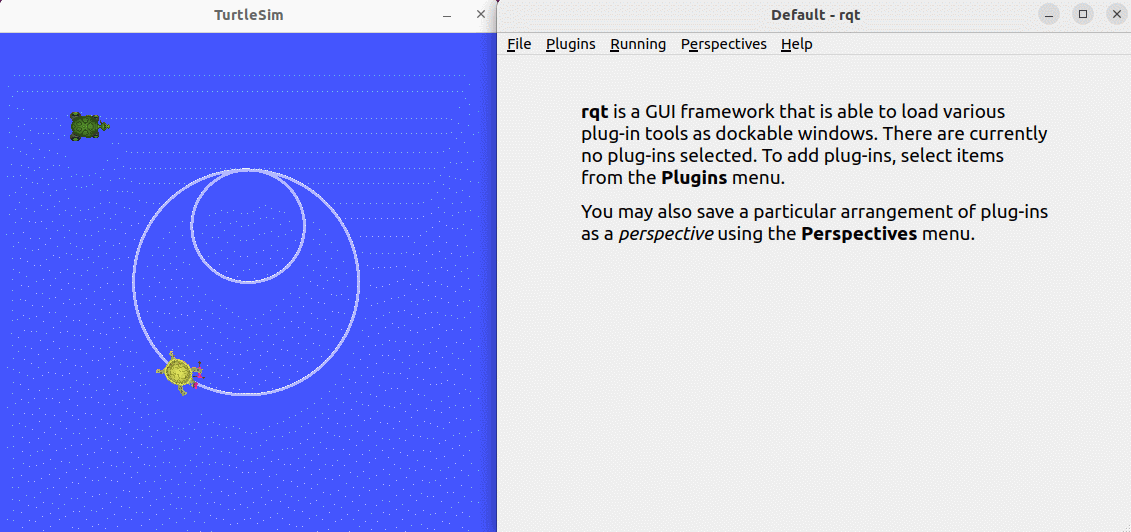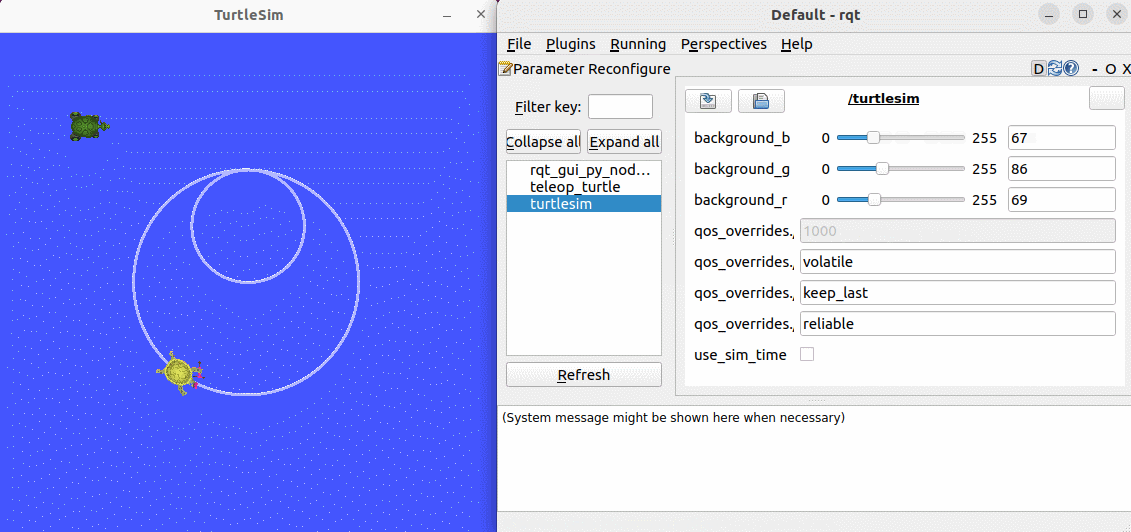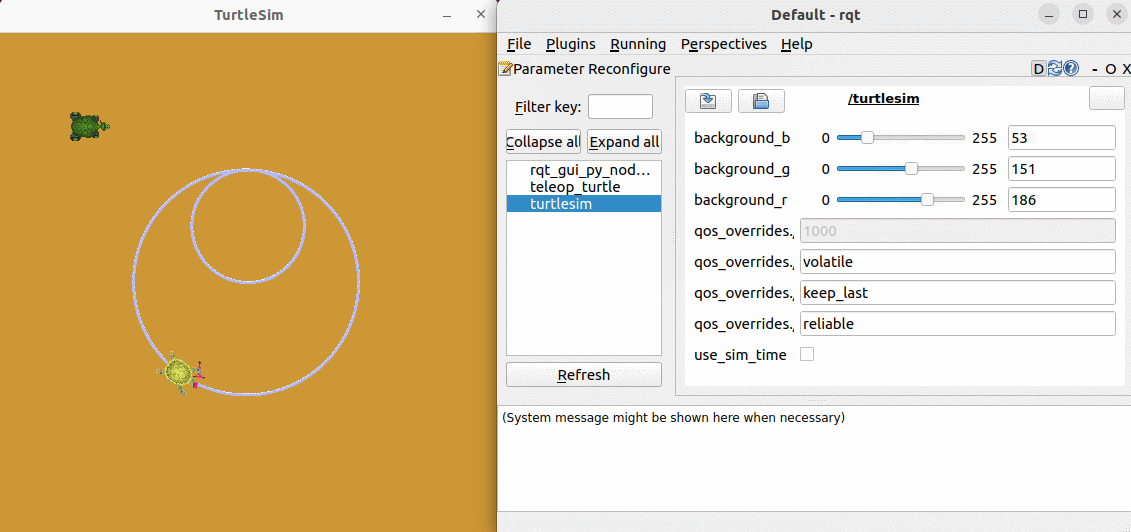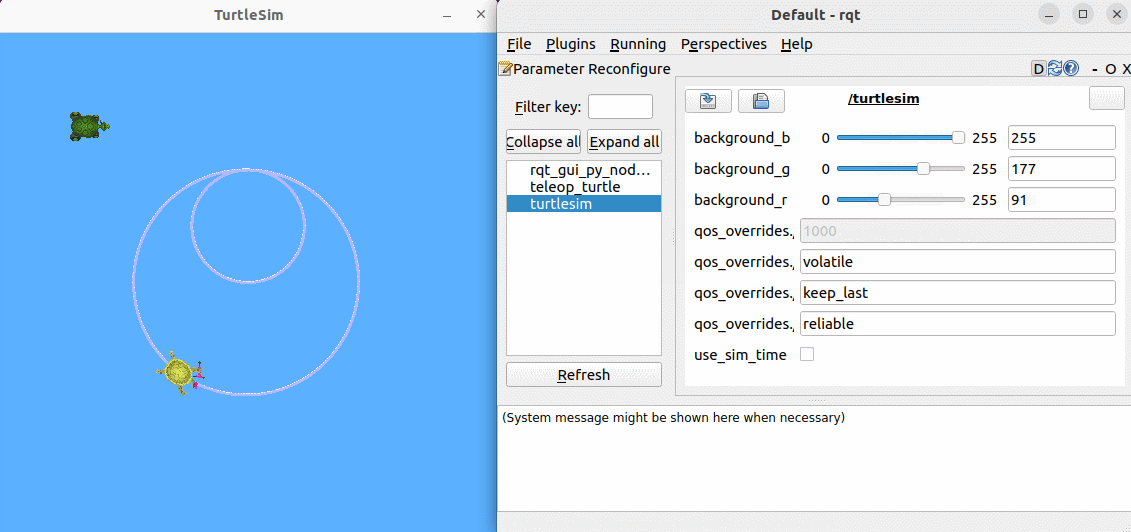
Dynamically change the background color of the turtle window through the parameter plugin.