yahboom
HomeTutorialsProduct
Solution
Blog
Online Store
About Us
EN/中文
Store
ROSMASTER M1 PRO📖
0.Robot Configuration and Operation Guidelines
  • 0.Unboxing and Review
  • 1.Assembly Videos
  • 2.User Manual
  • 3.Enter Docker (For Raspberry Pi)
  • 4.FAQ
  • 5.RobotManager User Guide
1.Chassis Control Course
  • 1.Robot Information Publishing
  • 2.Robot Handle Control
  • 3.Robot Keyboard Control
  • 4.Linear Velocity Calibration
  • 5.Angular Velocity Calibration
  • 6.Robot URDF Model
  • 7.Robot EKF State Estimation
2.Lidar Course
  • 1.Lidar Introduction And Use
  • 2.Lidar Obstacle Avoidance
  • 3.Lidar Following
  • 4.Lidar Guard
  • 5.Lidar Patrol
  • 6.GMapping-SLAM Mapping
  • 7.Cartographer-SLAM Mapping
  • 8.Slam-Toolbox Mapping
  • 9.Lifelong Mode Mapping
  • 10.Navigation2 Single Point Navigation
  • 11.Navigation2 Multi Point Navigation
  • 12.Cartographer Relocalization Navigation
  • 13.Slam-Toolbox Localization Navigation
  • 14.Synchronous Mapping And Navigation
  • 15.Aruco Visual Relocalization Navigation
  • 16.Mobile App Mapping And Navigation
3.USB Camera-Depth Camera Course
  • 1.USB Camera Introduction
  • 2.USB Camera Intrinsic Calibration
  • 3.Nuwa-HP60C Camera Introduction (Depth Camera Only)
  • 4.Depth Pseudo Color Image (Depth Camera Only)
  • 5.Depth Camera Distance Measurement (Depth Camera Only)
  • 6.Block Volume Calculation (Depth Camera Only)
  • 7.Edge Detection (Depth Camera Only)
  • 8.RTAB-Map SLAM Mapping (Depth Camera Only)
  • 9.RTAB-Map Navigation (Depth Camera Only)
4.Robotic Arm and 3D Space Gripping Course
  • 1.Robotic Arm Basic Usage
  • 2.Robotic Arm Kinematics
  • 3.Robotic Arm Chassis Coordination Control
  • 4.AprilTag ID Sorting
  • 5.AprilTag Height Anomaly Sorting
  • 6.AprilTag Tracking and Grasping
  • 7.Color Block Sorting
  • 8.Color Block Height Anomaly Sorting
  • 9.Color Block Tracking and Grasping
  • 10.Wood Block Shape Sorting
  • 11.KCF Tracking and Grasping Objects
  • 12.Mediapipe Gesture ID Sorting AprilTag
  • 13.Mediapipe Gesture Height Sorting AprilTag
  • 14.Desktop Tracking and Grasping AprilTag
  • 15.3D Spatial Tracking AprilTag
  • 16.Transformer Model Tracking Algorithm
  • 17.Line Following Obstacle Clearing
5.Road network planning and navigation
  • 1.Introduction To Road Network Planning
  • 2.Road Network Annotation
  • 3.Planning And Navigation Between Waypoints
  • 4.Road Network Navigation In Any Pose
  • 5.Path Re-planning
6.OpenClaw Basic Course
  • 1.Introduction to OpenClaw
  • 2.OpenClaw Core Concepts
  • 3.OpenClaw API-KEY Configuration
  • 4.OpenClaw Switch Models
  • 5.OpenClaw System Prompt Words
  • 6.OpenClaw Common CLI Commands
7.OpenClaw Interaction Method
  • 1.OpenClaw Webchat Interaction
  • 2.OpenClaw Tui Interaction
  • 3.OpenClaw Voice Dialogue Interaction
  • 4.OpenClaw WhatsApp Interaction
8.OpenClaw Development
  • 1.OpenClaw Connecting to Robot MCP Service
  • 2.Robot CLI Command Tool
  • 3.robot-control Plugin Tool
  • 4.reply-bridge Plugin Tool
  • 5.OpenClaw Multimodal Vision
  • 6.OpenClaw Chassis Control
  • 7.OpenClaw Robotic Arm Control
  • 8.OpenClaw Skills Development
  • 9.OpenClaw Scheduled Tasks
  • 10.OpenClaw Multi-Agent Intelligent Agent
  • 11.OpenClaw Active Interaction
  • 12.OpenClaw Vector Memory
9.OpenClaw Embodied intelligent application
  • 1.OpenClaw Target Tracking
  • 2.OpenClaw Arm Tracking And Grasping
  • 3.OpenClaw Arm Fixed-point Placement
  • 4.OpenClaw Waste Sorting
  • 5.OpenClaw SLAM Mapping And Navigation
  • 6.OpenClaw Navigation Transport
  • 7.OpenClaw AprilTag Grasping
  • 8.OpenClaw Color Line Patrol
  • 9.OpenClaw Visual Distance Measurement
10.OpenClaw scenario sandbox
  • 1.Map Description and Props Placement
  • 2.Building the Sandbox Map
  • 3.Visual Relocalization Marker
  • 4.Map Mapping Marker
  • 5.Sandbox Scenario Comprehensive Case
11.AI Large Model Basics
  • 1.AI Large Model Types and Principles
  • 2.RAG Retrieval Enhancement and Model Training Samples
  • 3.Embodied Intelligent Robot System Architecture
  • 4.Embodied Intelligent Functions Core Source Code
12.AI large Model Development
  • 1.Register a Model Service Provider Account
  • 2.Configuring API-KEY
  • 3.Introduction to Dify
  • 4.Basic Dify Features
  • 5.AI Large Model Development - Chatbot
  • 6.Deploy the RAG Knowledge Base
  • 7.RAG Knowledge Base + Chatbot
  • 8.AI Agent Workflow
  • 9.Custom Wake-up Response
13.AI Model - Voice Version
  • 1.Semantic Understanding and Command Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding and Robotic Arm Gripping
  • 4.Multimodal Visual Understanding and SLAM Navigation
  • 5.Robotic arm gripping+Multimodal visual understand+SLAM navigation
  • 6.Intention Understanding
14.AI Model - Text Version
  • 1.Semantic Understanding and Command Following
  • 2.Multimodal Visual Understanding
  • 3.Multimodal Visual Understanding and Robotic Arm Gripping
  • 4.Multimodal Visual Understanding and SLAM Navigation
  • 5.Robotic arm gripping+Multimodal visual understand+SLAM navigation
  • 6.Intention estimation
15.Mediapipe Visual Course
  • 1.Hand detection
  • 2.Posture detection
  • 3.Overall detection
  • 4.Facial Landmark Detection
  • 5.Face detection
  • 6.Face special effects
  • 7.3D object recognition
  • 8.Brush
  • 9.Finger control
  • 10.Palm target positioning
  • 11.Fingertip trajectory recognition
  • 12.Fingertip gesture control robotic arm
  • 13.Gesture grabbing and releasing objects
  • 14.Finger control robotic arm
  • 15.Medipipe gesture control robotic arm action group
16.MoveIt2 Simulation Course
  • 1.MovelT2 configuration
  • 2.MovelT2 simulation-reality linkage
  • 3.Random movement
  • 4.Forward kinematics design
  • 5.Inverse kinematics design
  • 6.Cartesian path
  • 7.Trajectory Planning
  • 8.Collision Detection
  • 9.Scene Design
  • 10.3D perception obstacle‑avoidance
17.Multi-vehicle Course
  • 1.Multi-vehicle Control
  • 2.Multi-vehicle Navigation
  • 3.Multi-vehicle Formation
18.YOLO26 Development
  • 1.CLI Use
  • 2.Object Detection
  • 3.Instance Segmentation
  • 4.Pose Estimation
  • 5.Image Classification
  • 6.Oriented Object Detection
  • 7.YOLOv26 + DeepSORT Tracking
  • 8.Monocular Depth Estimation
19.Control Board STM32 Driver Course
  • 0.Notes (Must Read)
  • 1.About Expansion Board
  • 2.STM32 Development Environment
  • 3.Button Control
  • 4.FreeRTOS Application
  • 5.Serial Communication
  • 6.SBUS Model Aircraft Remote Control
  • 7.CAN Bus Communication
  • 8.RGB Colorful Light Bar
  • 9.Timer Interrupt to Control PWM Servo
  • 10.Control Serial Port Servos
  • 11.Nine-axis Attitude Sensor to Obtain Data
  • 12.Control Motor
  • 13.Timer Captures the Encoder Data
  • 14.1 Kinematic Analysis of Mecanum Wheel
  • 14.2 Kinematic Analysis of Ackerman
  • 14.3 Kinematic Analysis of 4WD
  • 15.PID Control Robot Movement
20.Docker Course
  • 1.Docker Introduction and Installation
  • 2.Docker Basic Commands
  • 3.Docker Submission and Multi-Terminal Access
  • 4. Docker Startup Script
  • 5.Docker-Vscode Environment Construction
21.Image Processing Basics Course
  • 1. Introduction to Open Source CV
  • 2. Image reading and display
  • 3. Image writing
  • 4. Image quality
  • 5. Pixel Operation
  • 6. Image zoom
  • 7. Image cutting
  • 8. Image translation
  • 9. Image Mirroring
  • 10. Affine Transformation
  • 11. Image Rotation
  • 12. Perspective Transformation
  • 13. Grayscale processing
  • 14. Image Binarization
  • 15. Edge Detection
  • 16. Line drawing
  • 17. Rectangle and circle drawing
  • 18. Drawing text and pictures
22.Linux System Course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
23.ROS2 Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
24.Main Control Course
Jetson Orin Nano_NX
  • 1.Jetson Orin board introduction
  • 2.Restore the factory image system
  • 3.Backup SSD system
  • 4.SSD expansion
  • 5.Network configuration
  • 6.SSH remote login
  • 7.VNC remote control
  • 8.Remote file transfer
  • 9.Jtop tool
  • 10.Exchange space expansion
Raspberry Pi
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Update and upgrade operating system
  • 6. Introduction to raspi-config tool
  • 7. config.txt file description
  • 8. Network Configuration
  • 9. remote access
  • 10. Transfer files remotely
  • 11. Set display resolution and rotation
  • 12. Set screen to sleep
  • 13. Play audio and video
  • 14. Using USB camera
  • 15. Using MIPI camera
  • 16. Get real-time temperature of Raspberry Pi
RDKX5
  • 1.Introduction to RDK X5 board
  • 2.Write system file
  • 3.Hardware interface description
  • 4.Install case and other accessories
  • 5.Network configuration
  • 6.Remote login
  • 7.Update system
  • 8.srpi-config user guide
  • 9.config. txt configuration file
  • 10.Self-startup setting
  • 11.RDK exclusive command usage
  • 12.Linux command usage
  • 13.GPIO readwrite operation
  • 14.Image classification algorithm
  • 15.Use USB camera
  • 16.Use MIPI camera
  • 17.Binocular camera depth algorithm
  • 18. Controlling RGB Cooling Fans
Download
  • System File
  • Code
  • 3D Model File
  • Software Tools
  • Hardware_Info
  • Deb function package
  • Dify AI Agent
Download ZIP

Welcome to ROSMASTER M1 PRO repository

2.STM32 Development Environment

2. STM32 development environment

2. STM32 development environment 2.1. Introduction to STM32CubeIDE 2.2. download the installation package 2.3. start the installation 2.4. New construction 2.5. pin configuration 2.6. write code 2.7. Compiler 2.8. Burn program 2.9. Program phenomenon

2.1. Introduction to STM32CubeIDE

STM32CubeIDE is an all-in-one multi-OS development tool, an advanced C/C++ development platform with peripheral configuration, code generation, code compilation and debugging functions for STM32 microcontrollers and microprocessors. It is based on the Eclipse®/CDT™ framework and GCC toolchain for development, and GDB for debugging, selects an STM32 microprocessor and then creates a project and generates initialization code, supports graphical configuration of STM32 clocks and pins, etc. Content, support Windows, Linux, Mac mainstream platforms, very powerful and practical.

2.2. download the installation package

Open the following link with a computer browser:

https://www.st.com/en/development-tools/stm32cubeide.html

According to the download of the computer system, here we take the installation of version 1.9.0 in the Win10 system as an example, select the latest version to download.

If you have an account on my.st.com, you can log in directly and download the software. If you don't want to log in now, simply provide your name and email address in the form below to download the software.
image-20220309100601767

2.3. start the installation

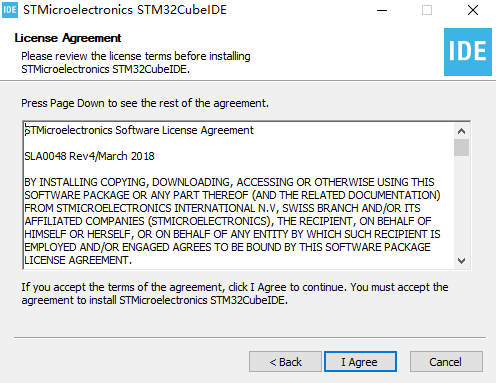
Double-click to open the installation package. Then just follow the tutorial.
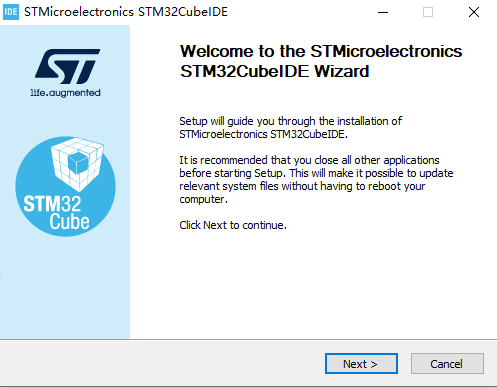
image-20220309100702670

image-20220309100727187

The installation path can be modified according to the actual situation, be careful not to have Chinese.
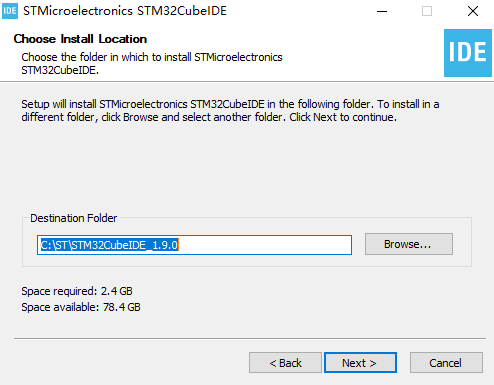
image-20220309100759937

Check the driver, and then click Install to install.
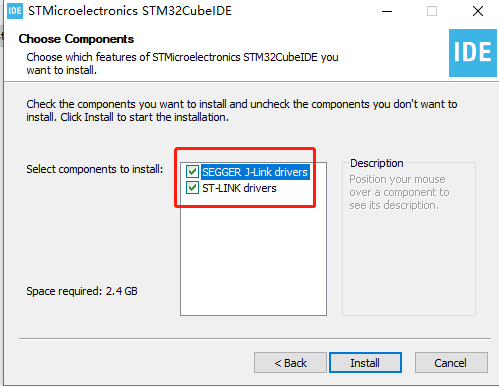
image-20220309100939458

Then wait for the installation to complete.
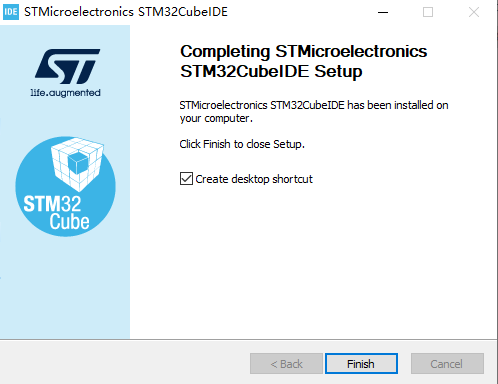
image-20220309101409033

2.4. New construction

  1. Double-click the shortcut on the desktop to open STM32CubeIDE. You need to select a workspace. The save path can be selected according to the actual path (do not bring Chinese).

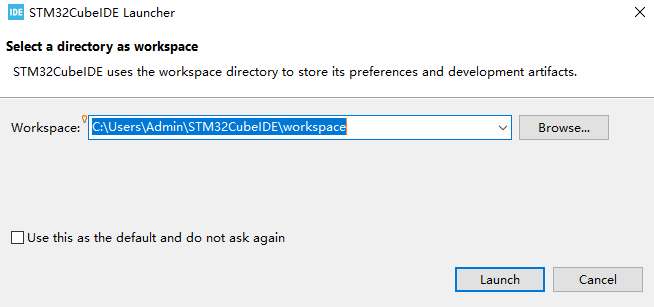
image-20220309101938781

image-20220309103807055

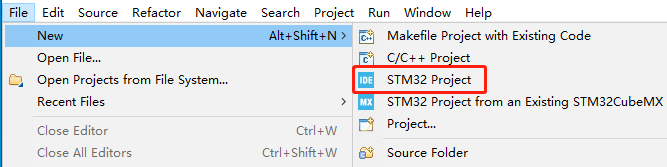
  1. Click File->New->STM32 Project.

image-20220309103950961

  1. Search and select the chip STM32F103RCT6, then click Next in the lower right corner to enter the next step.
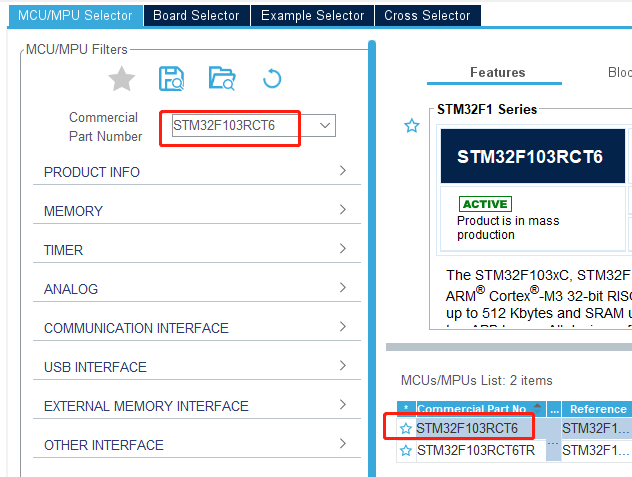
image-20220309104523552

  1. Enter the project name, take LED as an example here, other parameters can be defaulted.
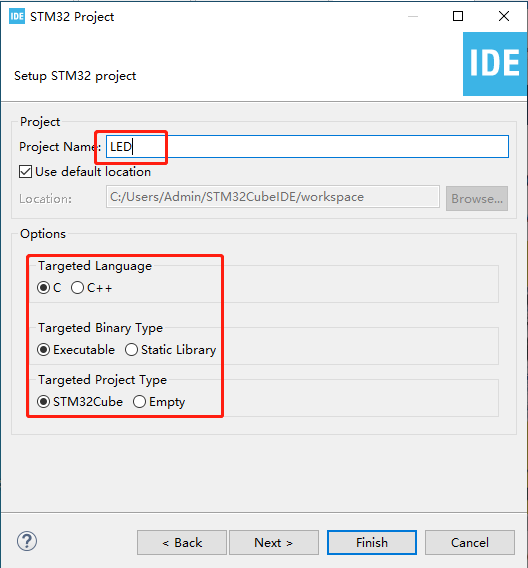
image-20220309104753828

  1. Click Yes, and the graphical content will be loaded.
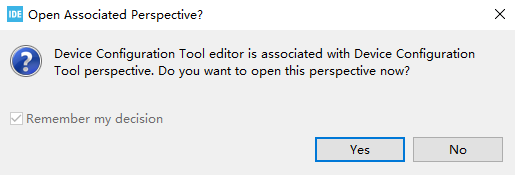
image-20220309104926020

After completion, it will look like the following picture:
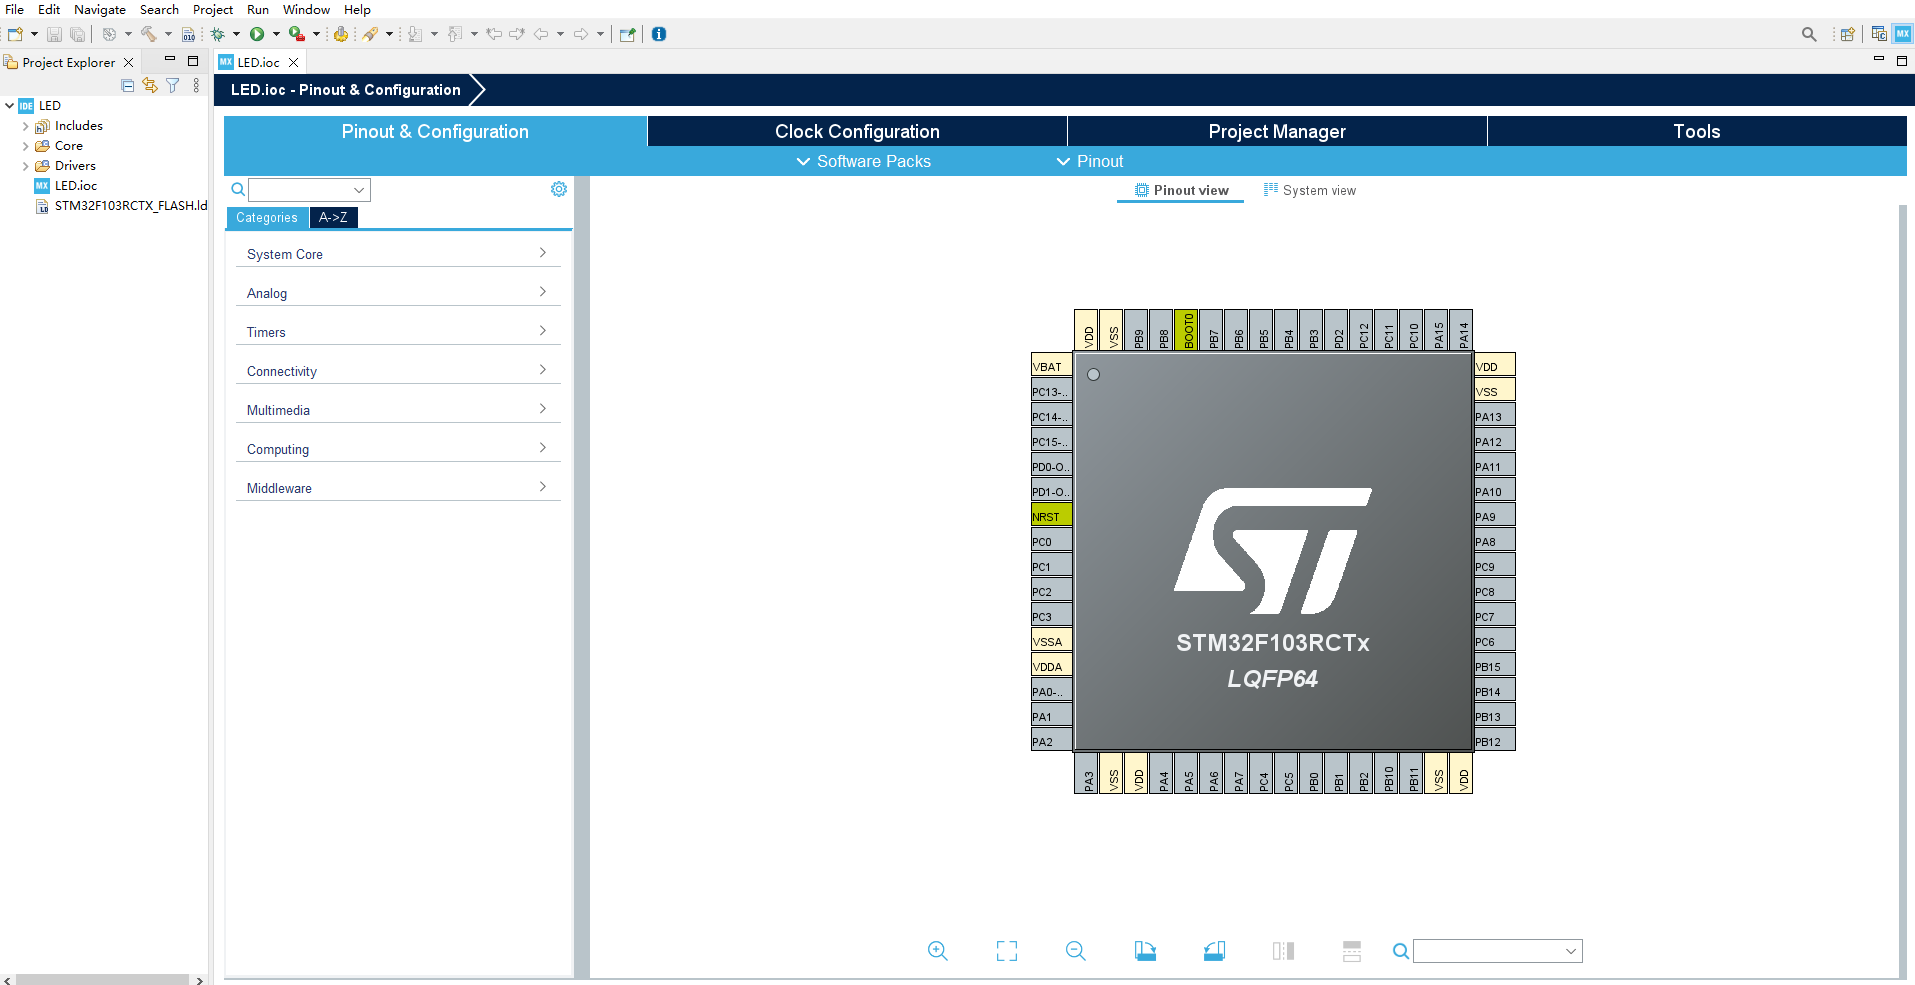
image-20220309105514825

2.5. pin configuration

  1. First need Debug information, click SYS->Debug under Pinout&Configuration and select Serial Wire.
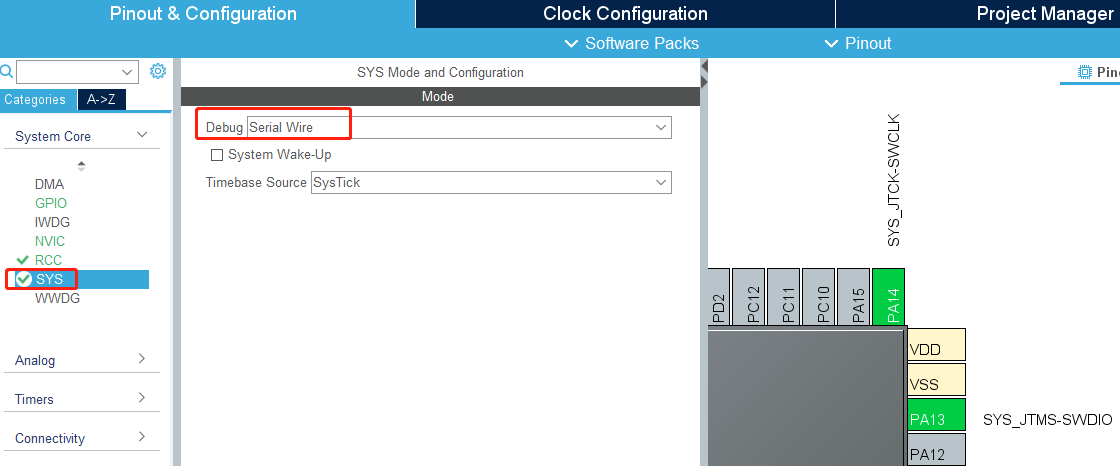
image-20220309111832426

  1. Modify the system clock of STM32. According to the schematic diagram, the external crystal oscillator is 8M frequency.
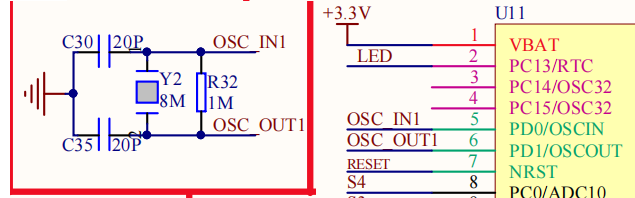
image-20220309110118096

Select RCC->HSE in Pinout&Configuration and select Crystal/Ceramic Resonator. The HSE is the external clock, and the LSE is the internal clock. Using the external clock can be more stable and efficient than the internal clock.
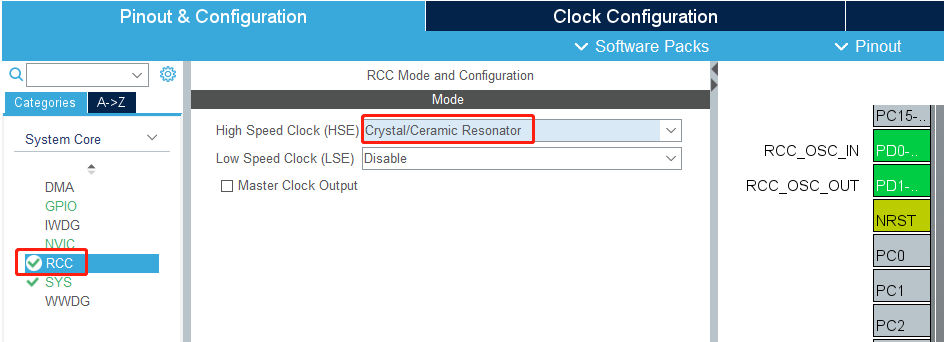
image-20220309110240836

Switch to Clock Configuration to modify the frequency of HCLK to 72, and press Enter to confirm.
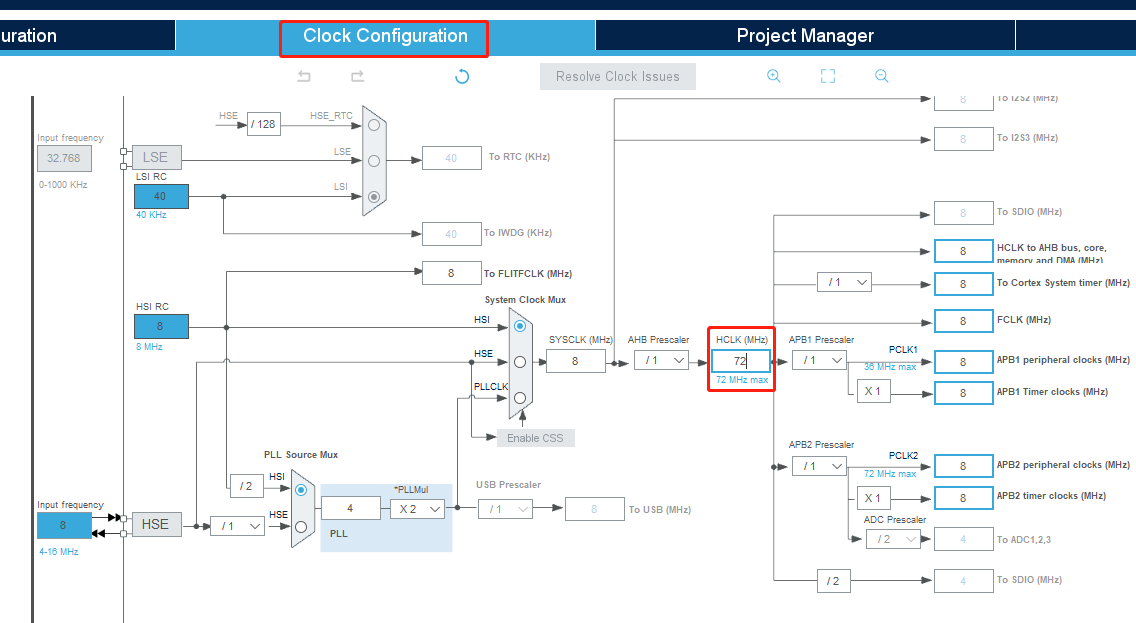
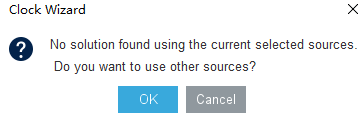
image-20220309110757303

image-20220309110728487

  1. Increase the LED pin configuration. It can be seen from the schematic diagram that the LED is connected to the PC13 pin.
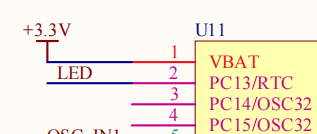
image-20220309112325122

Set the PC13 pin to GPIO_Output, and modify the Label to LED for convenience.
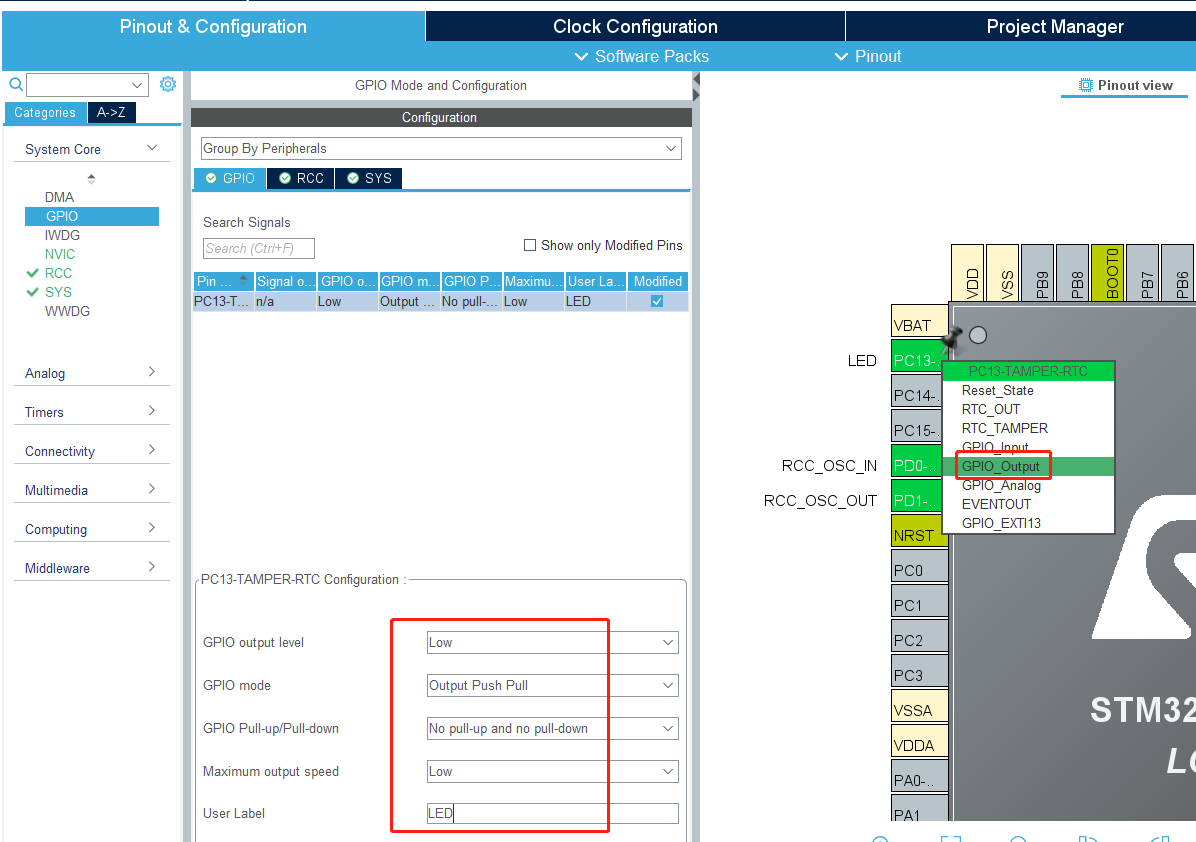
image-20220309112613410

Then press Ctrl+S to save, tick Remember my decision, and click Yes. This will automatically generate the code every time you save.
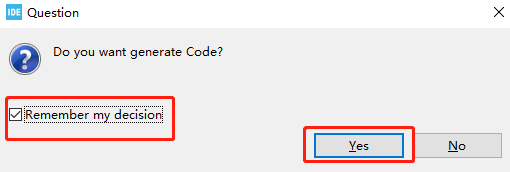
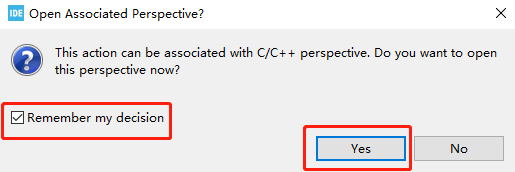
image-20220309112812784

image-20220309112931421

2.6. write code

  1. Since the initialization code of the system has been generated by the graphical configuration in the previous step, we only need to add the functions to be implemented.

Find the main function in the main.c file, and add the content to control the LED light under while(1). The function is that the LED light flashes every 200 milliseconds. Press Ctrl+S to save the code.
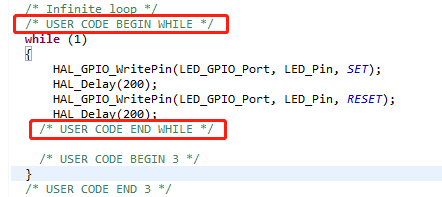
image-20220309114143099

Note: The code content needs to be added between USER CODE BEGIN and USER CODE END. Otherwise, the content of the code will be overwritten after the code is generated by the graphical tool next time, and the content added between USER CODE BEGIN and USER CODE END will not be overwritten. Don't write Chinese comments in it, there may be garbled characters.

2.7. Compiler

  1. Add the function of generating HEX files.

Click Project->Properties->C/C++ Build->Settings->MCU Post build outputs in turn, and then check the box before Convert to Intel Hex file(-O ihex), as shown in the following figure.
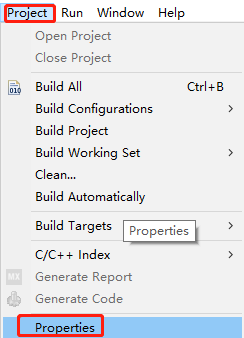
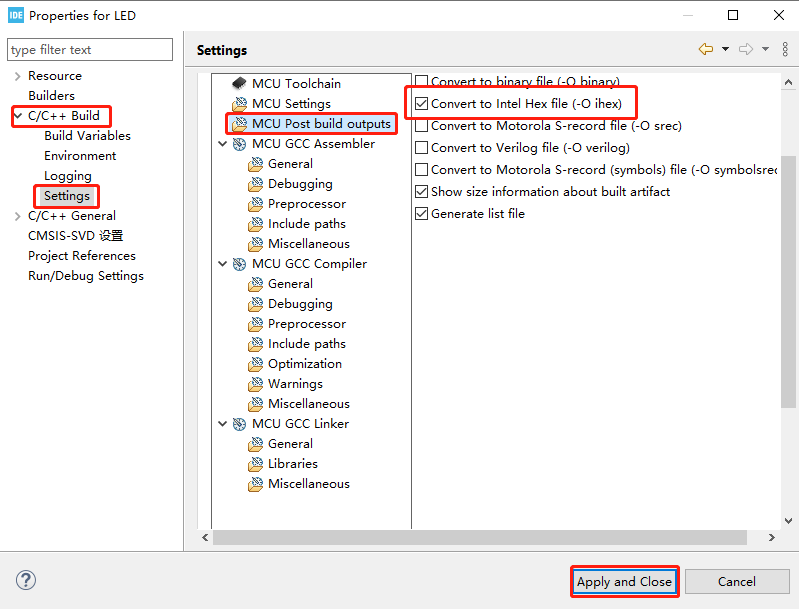
image-20220401105445775

image-20220401105123327

  1. Click the hammer in the toolbar to start compiling the project.
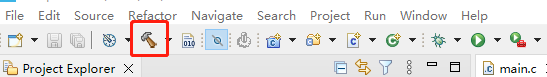
image-20220401105951706

STM32CubeIDE will pop up the Console console and see 0 errors in compilation, and 0 warnings means the compilation is successful. As shown in the figure below, the file name generated by the project is LED.hex, and this file is saved in the Debug folder of the project directory.
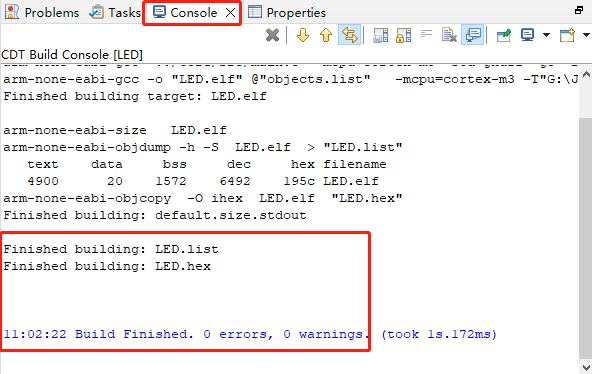
image-20220401110314069

2.8. Burn program

  1. Install the CH340 driver

Since the USB communication of the Rosmaster expansion board uses the CH340 chip, the driver of the CH340 chip needs to be installed. If the computer has already installed the CH340 driver, there is no need to install it again.

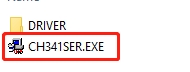
Unzip the [Uart drive (CH340).zip] in the course materials, double-click to open the CH341SER.EXE program
img

Click Install. After the installation is complete, you will be prompted that the installation was successful.
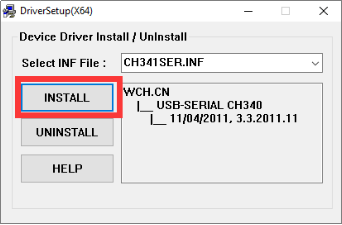
image-20220518182102920

  1. Download the burning software

This time burning Rosmaster expansion board microcontroller firmware requires mcuisp (or flymcu) burning software, please go to http://www.mcuisp.com website to download mcuisp (or flymcu) burning software; you can also use the data provided directly mcuisp software.

The mcuisp software is a green version software, which does not need to be installed. Double-click to open it to use.

  1. Connect the device

Before connecting the Rosmaster to the computer, please unplug the Micro USB data cable and power cable connecting the expansion board to the Jetson Nano.

Insert one end of the USB data cable into the USB port of the computer, and the other end into the Micro USB port of the Rosmaster expansion board.
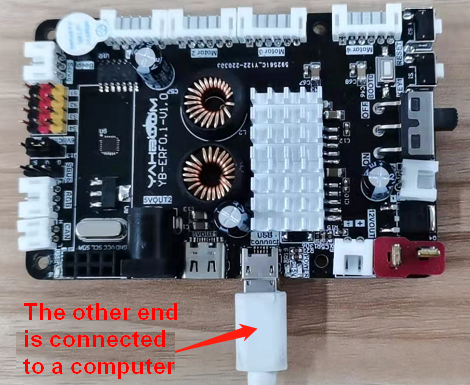
image-20220401112853890

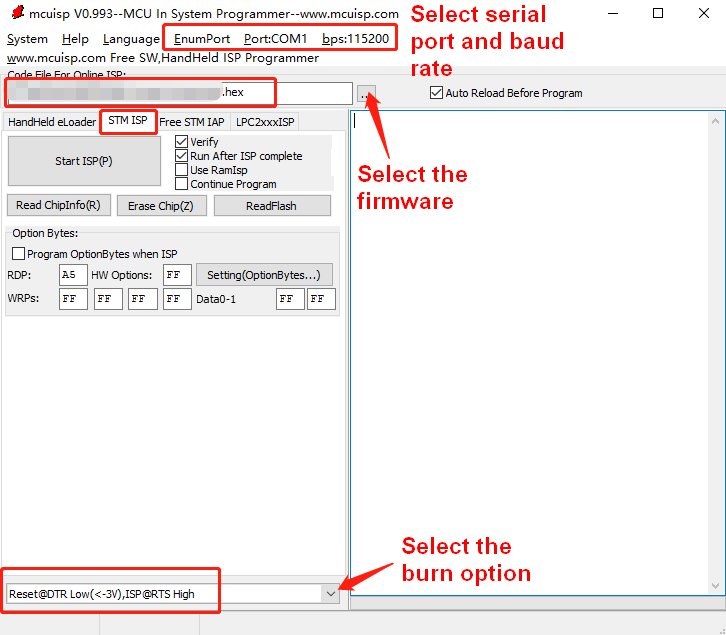
  1. Configure the burning software

image-20220518183424715

When searching for a serial port, if there are multiple serial port numbers, it is not confirmed which one is the Rosmaster. Solution 1: Unplug other USB ports and search again; Solution 2: First unplug the Rosmaster USB data cable, click Search Serial Port, write down the searched serial port number, insert the Rosmaster USB data cable, search the serial port again, and compare before and after Twice, the newly added serial port number is the serial port number of the Rosmaster.

When selecting firmware, you need to select the LED.hex file in the Debug folder of the project directory.

The last is the configuration selection at the bottom. Be sure to select the option of [DTR low-level reset, RTS high-level into BootLoader] option, otherwise the download may fail.

  1. Burn program

Please put the microcontroller on the expansion board into the programming mode first:

First press and hold the BOOT0 key on the expansion board, then press the RESET key, and finally release the BOOT0 key.
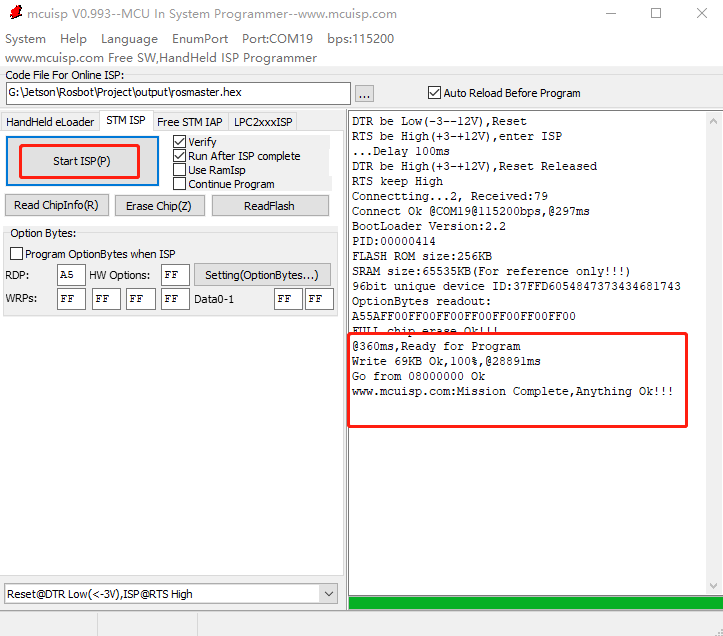
image-20220519092505207

Click [Start Programming], and the mcuisp burning software will burn the firmware we selected in the previous step to the microcontroller on the Rosmaster expansion board. When the prompt appears on the right side [www.mcuisp.com:Mission Complete,Anything Ok!!!], it means that the download is successful.

Notice:

①Before starting programming, please confirm that the serial port number of the Rosmaster is accessible, that is, there is no serial port assistant occupying it.

②Rosmaster enters the burning mode operation, first press and hold the BOOT0 key on the expansion board, then press the RESET key, and finally release the BOOT0 key.

2.9. Program phenomenon

The LEDs on the expansion board flash every 200ms.

About Expansion Board
Button Control

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文