Welcome to ROSMASTER M1 PRO repository
5.Robotic arm gripping+Multimodal visual understand+SLAM navigation
Robotic Arm Gripping + Multimodal Visual Understanding + SLAM Navigation
Robotic Arm Gripping + Multimodal Visual Understanding + SLAM Navigation1. Course Content2. Starting the Agent3. Running the Cases
1. Course Content
After running the example program, perform complex task functions by combining Nav2 navigation, robotic arm gripping, and AI large model visual understanding.
Note: This lesson requires configuring the map mapping file first.
Note
All operation steps are the same as those in AI Model - Voice Version. The differences are that the command input method is different and there is no voice reply. For detailed operation steps and source code analysis, refer to the AI Model - Voice Version course content.
2. Starting the Agent
For the operation steps of recording semantic locations to the map mapping file, refer to the previous lesson "Multimodal Visual Understanding + SLAM Navigation".
ros2 launch yahboomcar_bringup dify_llm_agents.launch.py use_nav:=true use_camera:=true
Text interaction terminal
xxxxxxxxxxdify_tui
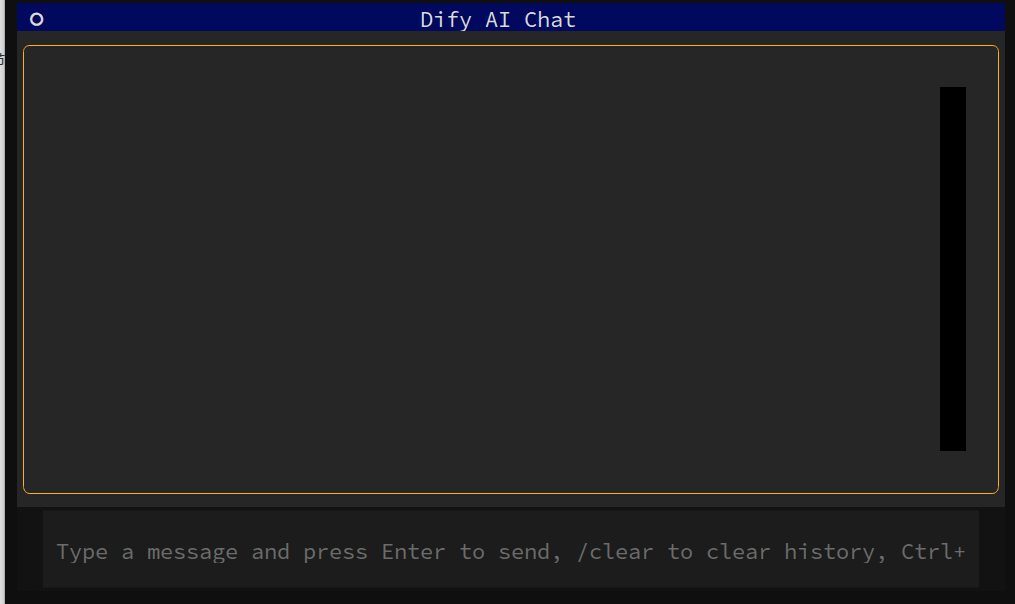
Use the
/clearcommand to clear the terminal conversation history; press Ctrl+Q to exit the interaction terminal.
3. Running the Cases
Help me take the red block in front of you to the master bedroom, and then take the green block in the master bedroom to the kitchen. The wooden block used is 30x30x30mm.