Welcome to ROSMASTER M1 PRO repository
6.GMapping-SLAM Mapping
Gmapping Mapping Algorithm
Gmapping Mapping Algorithm1. Course Content2. Gmapping Algorithm Introduction3. Case Demonstration3.1 Mapping Process3.2 Saving the Map3.3 Configuration File4. Source Code Analysis
1. Course Content
Basic: Run the example program, perform SLAM mapping with the gmapping mapping algorithm, and save the grid map.
Advanced: Understand the gmapping algorithm's configuration parameters.
2. Gmapping Algorithm Introduction
Gmapping is a commonly used open-source SLAM algorithm based on the filtering SLAM framework.
Gmapping is based on the RBPF particle filter algorithm, separating the simultaneous localization and mapping process: it performs localization first, then mapping.
Gmapping makes two main improvements on the RBPF algorithm: an improved proposal distribution and selective resampling.
Advantages: Gmapping can build indoor maps in real time, requires relatively little computation for building small-scene maps, and achieves high accuracy.
Disadvantages: As the scene grows larger, the number of particles required increases; because each particle carries a map, the memory and
computation required to build a large map both increase. Therefore, it is not suitable for building large-scene maps. It also lacks loop closure detection, so the map may become misaligned during loop closure. Although increasing the number of particles can make the map close, this comes at the cost of increased computation and memory.
3. Case Demonstration
Launch method 1: GUI launch
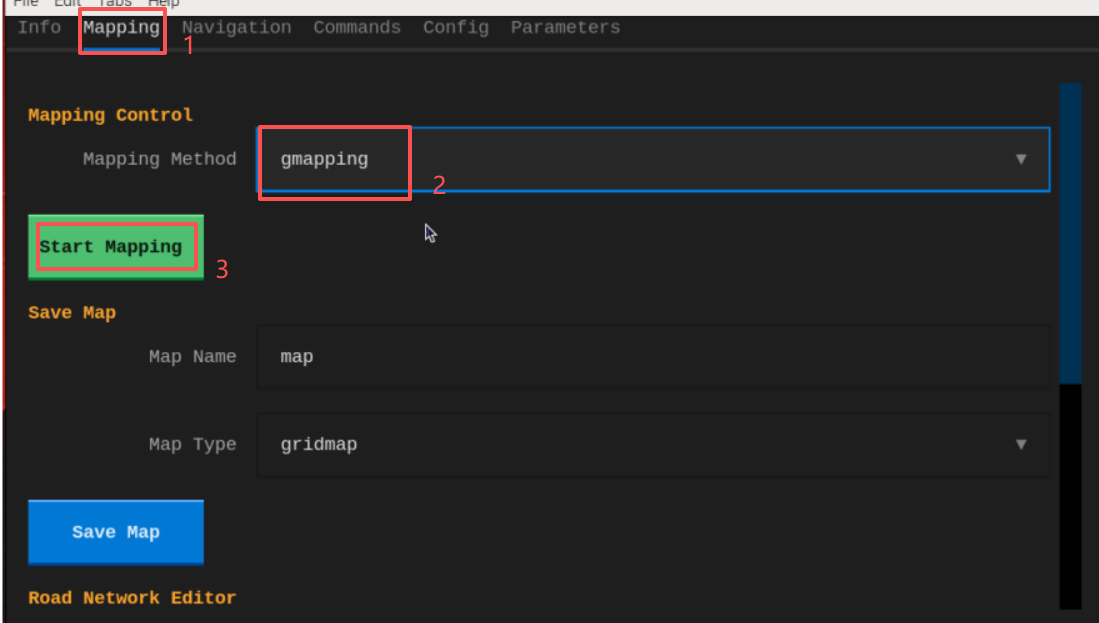
Launch method 2: CLI command launch in VNC
xxxxxxxxxxros2 launch yahboomcar_bringup gmapping.launch.py
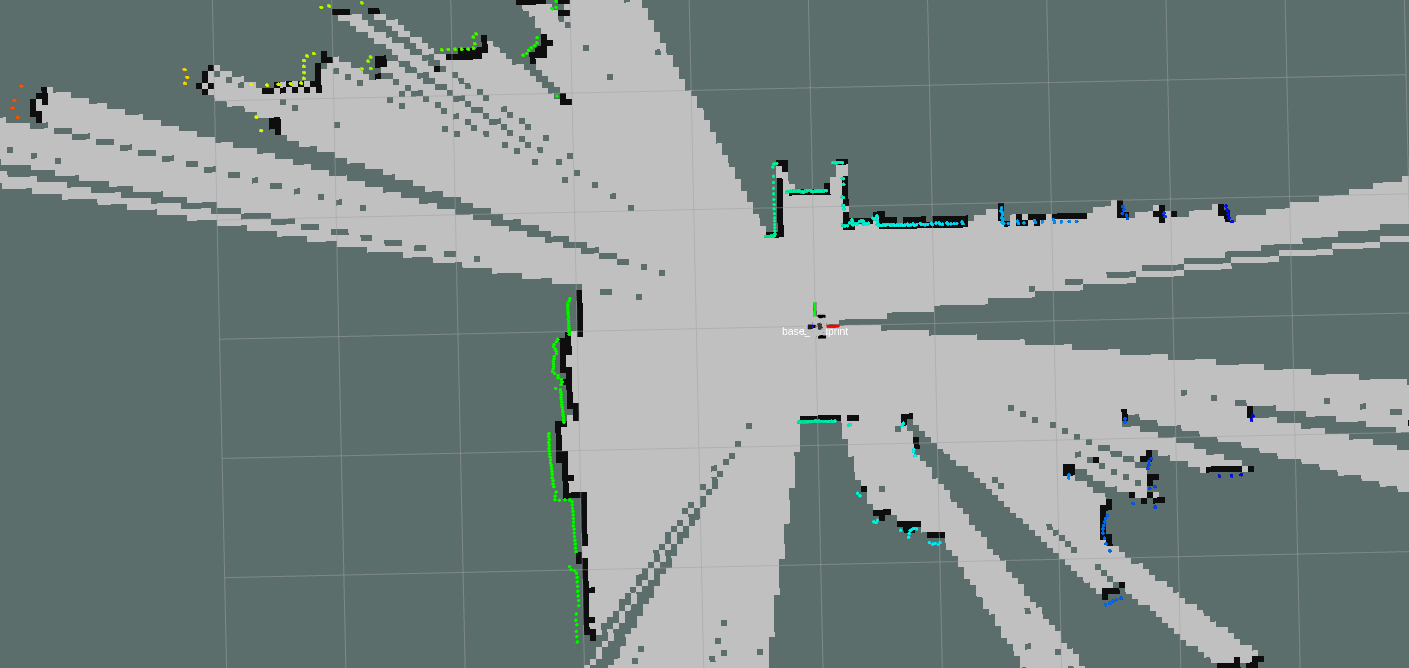
3.1 Mapping Process
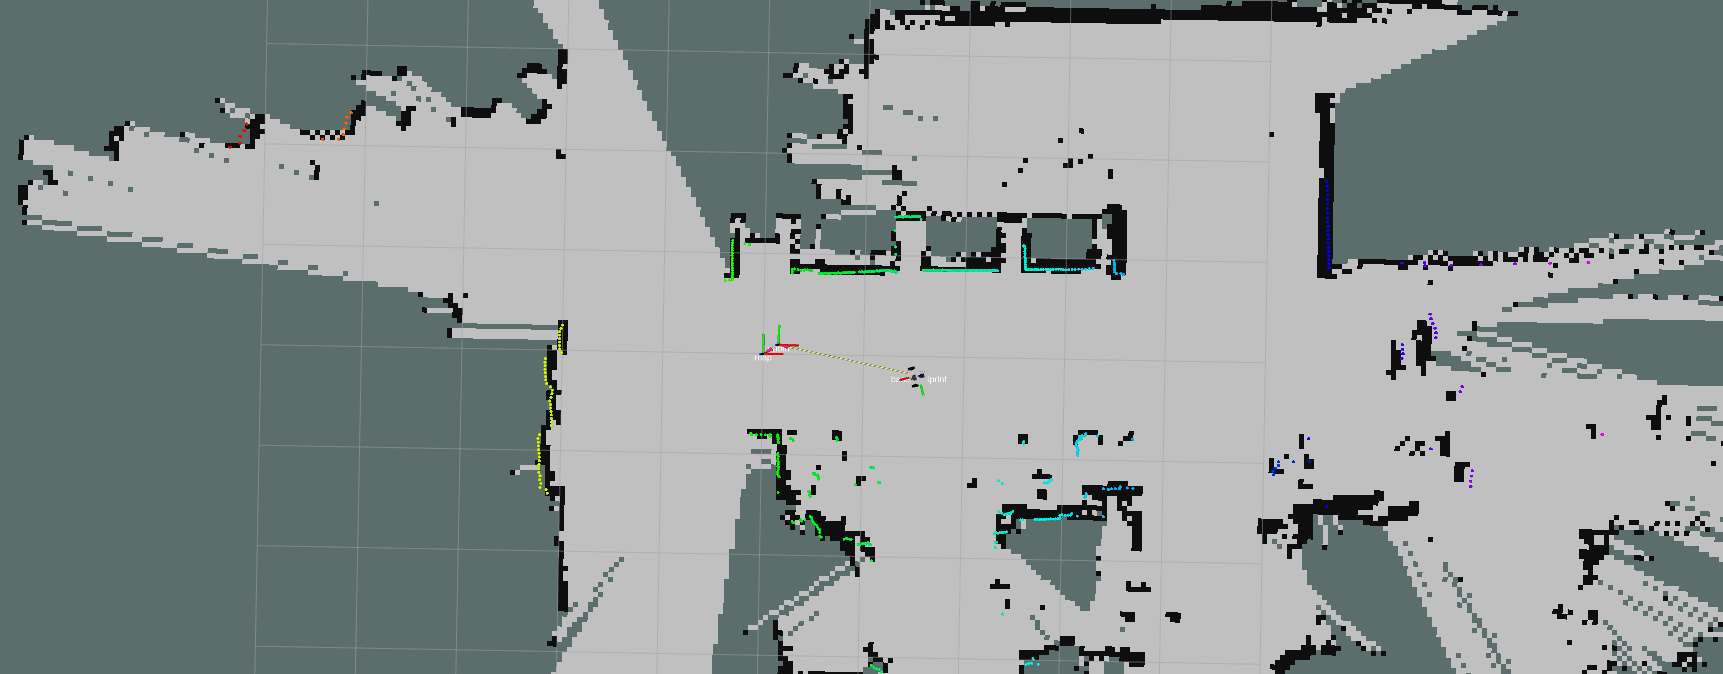
Note: when mapping, the slower the speed, the better the result (mainly the rotation speed should be slower).
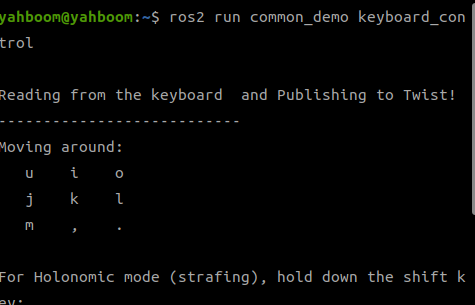
Control the car's movement to complete mapping of the environment. You can use keyboard control or joystick control; here, keyboard control is used as an example
xxxxxxxxxxros2 run common_demo keyboard_control
3.2 Saving the Map
Method 1: operate through the UI; start RobotManager
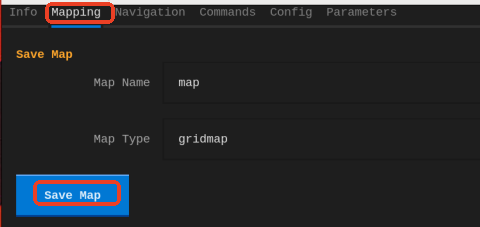
Click Save Map. You can also customize the map name and map type. If the terminal indicates that saving failed, simply save again
Method 2: run the following command in the terminal to save the grid map:
xxxxxxxxxxros2 launch yahboomcar_bringup save_map_launch.pyTip
Optional parameter:
map_name: specifies the name for saving the map; the default value is map
For example, to save a map named test.yaml, you need to add the parameter: ros2 launch yahboomcar_bringup save_map_launch.py map_name:=test.yaml
When the terminal displays Map saved successfully, the map has been saved successfully. If saving fails, try saving again.
The default map save path is as follows:
xxxxxxxxxx~/map/map.yaml
A pgm image and a yaml file yahboom_map.yaml
xxxxxxxxxximage: yahboom_map.pgmmode: trinaryresolution: 0.05origin: [-10, -10, 0]negate: 0occupied_thresh: 0.65free_thresh: 0.25
Parameter analysis:
image: the path of the map file; it can be an absolute path or a relative path
mode: this attribute can be one of trinary, scale, or raw, depending on the mode selected; trinary mode is the default mode
resolution: the map's resolution, in meters/pixel
origin: the 2D pose (x, y, yaw) of the map's lower-left corner; here yaw is rotated counter-clockwise (yaw=0 means no rotation). At present, many parts of the system ignore the yaw value.
negate: whether to invert the meaning of white/black and free/occupied (the interpretation of thresholds is unaffected)
occupied_thresh: pixels with an occupancy probability greater than this threshold are considered fully occupied.
free_thresh: pixels with an occupancy probability less than this threshold are considered fully free.
3.3 Configuration File
Configuration file path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/param/slam_gmapping.yaml
Meaning of the default configuration parameters:
xxxxxxxxxxslam_gmapping ros__parameters # Angular update threshold (radians): update the map when the robot rotates beyond this angle angularUpdate0.25 # Angular sampling step (radians): the angular search step used for scan matching astep0.05 # Name of the robot base coordinate frame base_framebase_footprint # Name of the map coordinate frame map_framemap # Name of the odometry coordinate frame odom_frameodom # Iteration termination condition of the scan matching algorithm: stop iterating when the parameter change is less than this value delta0.05 # Maximum number of iterations for scan matching iterations5 # Kernel size used for scan matching; affects the smoothness of the match kernelSize1 # Distance sampling range for large-scale scan matching (meters) lasamplerange0.005 # Distance sampling step for large-scale scan matching (meters) lasamplestep0.005 # Linear update threshold (meters): update the map when the robot moves beyond this distance linearUpdate0.5 # Distance sampling range for small-scale scan matching (meters) llsamplerange0.01 # Distance sampling step for small-scale scan matching (meters) llsamplestep0.01 # Measurement noise covariance of the laser scan lsigma0.075 # Number of laser beams to skip: 0 means using all laser points lskip0 # Linear sampling step (meters): the linear search step used for scan matching lstep0.05 # Map update interval (seconds) map_update_interval3.0 # Maximum laser range (meters): points beyond this distance are ignored maxRange6.0 # Effective maximum laser range (meters): the maximum distance used for mapping maxUrange4.0 # Minimum score threshold for scan matching: matches below this value are discarded minimum_score0.0 # Occupancy probability threshold: cells greater than this value are considered occupied occ_thresh0.25 # Gain factor: affects the speed of map updates ogain3.0 # Number of particles in the particle filter particles30 # QoS (Quality of Service) parameter settings qos_overrides /parameter_events publisher depth1000 # Message queue depth durabilityvolatile # Durability policy historykeep_all # History policy reliabilityreliable # Reliability policy /tf publisher depth1000 durabilityvolatile historykeep_last # Keep only the latest message reliabilityreliable # Resampling threshold: trigger resampling when the number of effective particles falls below this ratio resampleThreshold0.5 # Angular noise covariance of scan matching sigma0.05 # Odometry model parameter: proportion of linear error caused by linear motion srr0.1 # Odometry model parameter: proportion of angular error caused by linear motion srt0.2 # Odometry model parameter: proportion of linear error caused by angular motion str0.1 # Odometry model parameter: proportion of angular error caused by angular motion stt0.2 # Time update interval (seconds): update the map even if the robot has not moved temporalUpdate1.0 # Coordinate transform publishing period (seconds) transform_publish_period0.05 # Whether to use simulation time use_sim_timefalse # Maximum x-axis range of the map (meters) xmax100.0 # Minimum x-axis range of the map (meters) xmin-100.0 # Maximum y-axis range of the map (meters) ymax100.0 # Minimum y-axis range of the map (meters) ymin-100.0
4. Source Code Analysis
gmapping mapping launch file
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/launch/gmapping.launch.py
slam_gmapping_config_file: the full path for loading the gmapping parameter configuration fileslam_gmapping.yamlrviz_cmd: declares thervizlaunch parameter, default valueTrue, used to control whether to automatically start Rviz2bringup_car_base: includescar_base.launch.py, enabling the LiDAR (use_lidar: True) and IMU (use_imu: True), disabling the camera and magnetometer, and using the EKF odometry as the TF source (odom_tf_source: ekf)gmapping_node: starts theslam_gmappingnode and loads the above configuration file to perform mappingrviz_node: starts Rviz2 and loads the preset configurationgmapping_rviz.rviz, controlled by thervizparameterLaunchDescription: aggregates and returns all declared parameters and nodes
xxxxxxxxxxdef generate_launch_description():
    slam_gmapping_config_file = os.path.join(get_package_share_directory("yahboomcar_bringup"), "param", "slam_gmapping.yaml")
    rviz_cmd=DeclareLaunchArgument(        "rviz",        default_value="True",        description="Start Rviz2 automatically ?",    )
    bringup_car_base=IncludeLaunchDescription(            PythonLaunchDescriptionSource(os.path.join(get_package_share_directory('yahboomcar_bringup'),'launch','car_base.launch.py')),            launch_arguments={'log_level': 'info',                              'use_imu': 'True',                              'use_lidar': 'True',                              'use_mag': 'False',                              'use_camera': 'False',                              'odom_tf_source': 'ekf'                              }.items())
    gmapping_node=Node(    package='slam_gmapping',     executable='slam_gmapping',     output='screen',     parameters=[slam_gmapping_config_file]    )    rviz_node=Node(        package='rviz2',        executable='rviz2',        name='rviz2',        arguments=['-d', os.path.join(get_package_share_directory('yahboomcar_bringup'), 'rviz', 'gmapping_rviz.rviz')],        condition=IfCondition(LaunchConfiguration('rviz'))    )
    return LaunchDescription([            rviz_cmd,                                   rviz_node,                                   bringup_car_base,                             gmapping_node,                     ])
Save map command launch file path
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/launch/save_map_launch.py
Important
In subsequent chapter courses, the save map command and the command source code in RobotManager's save map feature are all save_map_launch.py, which switches between different functions through launch parameters. save_map_launch.py will not be explained again in subsequent courses
map_folder_dir: defines the map save directory~/mapdeclared_arguments: declares two launch parameters,map_name(map name, defaultmap, without file extension) andmap_type(map type, defaultgridmap, optionsgridmap / pbstream / posegraph)map_path / pbstream_path: concatenates the save directory and map name into the full pathsave_map: usesnav2_map_server'smap_saver_clito save the grid map, specifying a free space threshold of0.196and an occupied threshold of0.65; executes only whenmap_type == 'gridmap'save_pbstream: calls Cartographer's/write_stateservice viaros2 service callto save a map in.pbstreamformat; executes only whenmap_type == 'pbstream'save_posegraph: calls slam_toolbox's/slam_toolbox/serialize_mapservice viaros2 service callto save the pose graph; executes only whenmap_type == 'posegraph'LaunchDescription: aggregates and returns all parameter declarations and the three save nodes (executed conditionally)
xdef generate_launch_description(): map_folder_dir = os.path.join(os.path.expanduser('~'), 'map')
declared_arguments = [ DeclareLaunchArgument( 'map_name', default_value='map', description='Map name to save, without file extension', ), DeclareLaunchArgument( 'map_type', default_value='gridmap', description='Type of map to be saved (optional):gridmap、pbstream、posegraph', ), ]
map_name = LaunchConfiguration('map_name') map_type = LaunchConfiguration('map_type') map_path = PathJoinSubstitution([map_folder_dir, map_name]) pbstream_path = PathJoinSubstitution([map_folder_dir, map_name])
save_map = Node( package='nav2_map_server', executable='map_saver_cli', arguments=[ '-f', PathJoinSubstitution([map_folder_dir, map_name]), '--free', '0.196', '--occ', '0.65'], condition=IfCondition(PythonExpression(["'", map_type, "' == 'gridmap'"])) )
save_pbstream = ExecuteProcess( condition=IfCondition(PythonExpression(["'", map_type, "' == 'pbstream'"])), cmd=[ 'ros2', 'service', 'call', '/write_state', 'cartographer_ros_msgs/srv/WriteState', ['{filename: "', pbstream_path, '.pbstream"}'], ], shell=False, emulate_tty=True, output='screen', ) save_posegraph = ExecuteProcess( condition=IfCondition(PythonExpression(["'", map_type, "' == 'posegraph'"])), cmd=[ 'ros2', 'service', 'call', '/slam_toolbox/serialize_map', 'slam_toolbox/srv/SerializePoseGraph', ['{filename: "', map_path, '"}'], ], shell=False, emulate_tty=True, output='screen', )
return LaunchDescription([ *declared_arguments, save_map, save_pbstream, save_posegraph, ])