Welcome to ROSMASTER M1 PRO repository
17.Line Following Obstacle Clearing
Line Following and Obstacle Clearing
Line Following and Obstacle Clearing1. Course Content2. Preparation3. Case Demonstration4. Color Calibration5. Core Source Code Analysis
1. Course Content
This feature implements the program acquiring images through the camera and recognizing the color of the line. The program controls the car to move along the line. During this period, the LiDAR scans for obstacles on the path, and if an obstacle is encountered, the car stops; if an AprilTag appears on the route, it adjusts its pose, lowers its gripper to grasp the AprilTag, places it aside, and then continues line following.
2. Preparation
The wooden block used in this section is: 30x30x30mm AprilTag wooden block
ros2 launch yahboomcar_bringup arm_demo.launch.py demo:=follow_line_clear
3. Case Demonstration
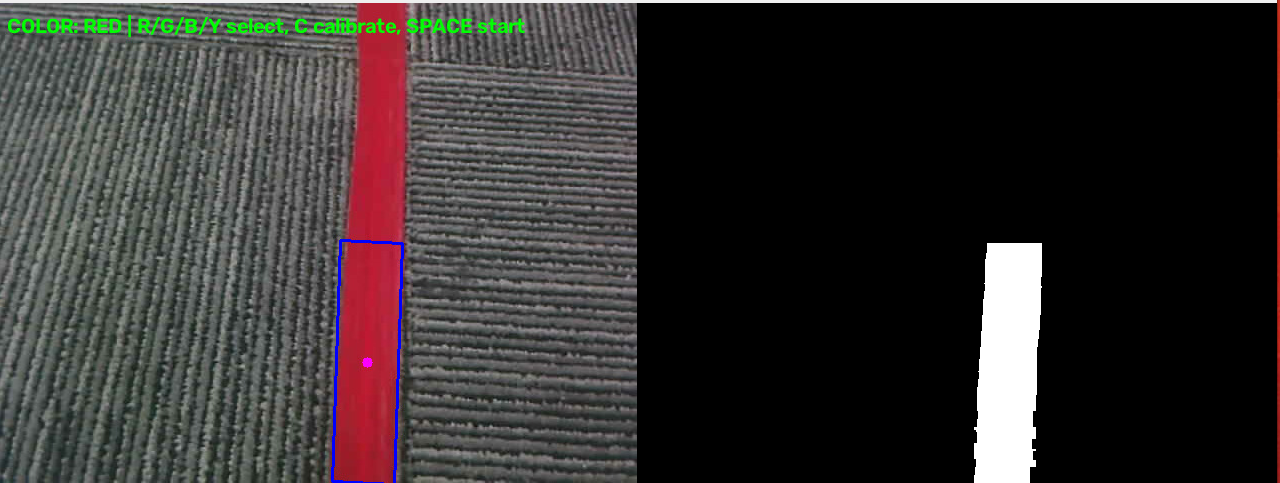
Press R, G, B, or Y to select the color to follow, and press the spacebar to start following the path
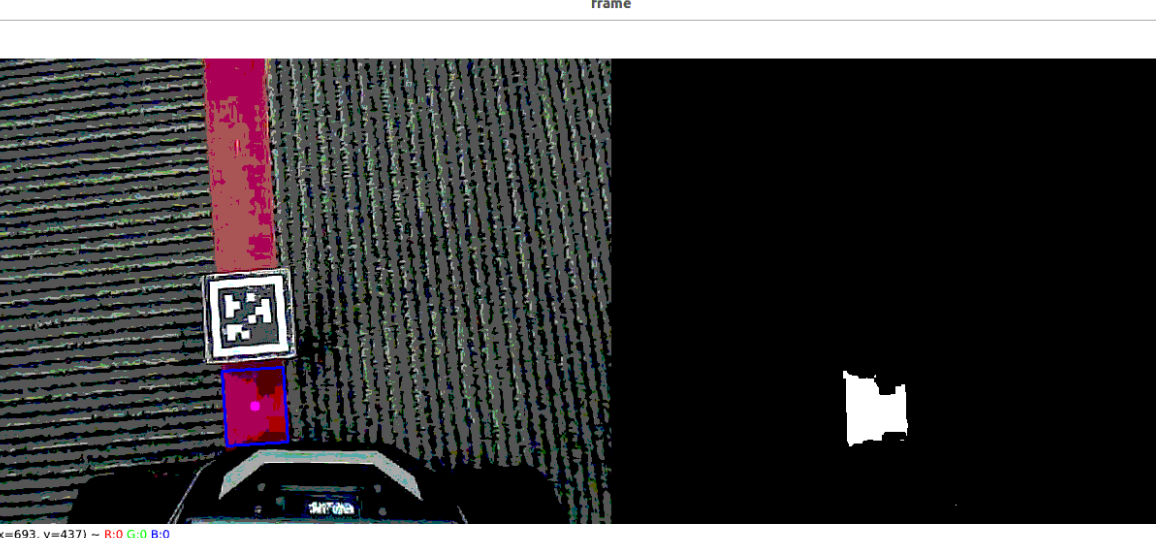
If an AprilTag block appears on the ground ahead, the car pauses following, first removes the AprilTag block, and then continues line following
4. Color Calibration
If the current color recognition is not good, press C to enter color calibration mode, use the mouse to draw a box on the color, and then check the color recognition effect in the binarized image
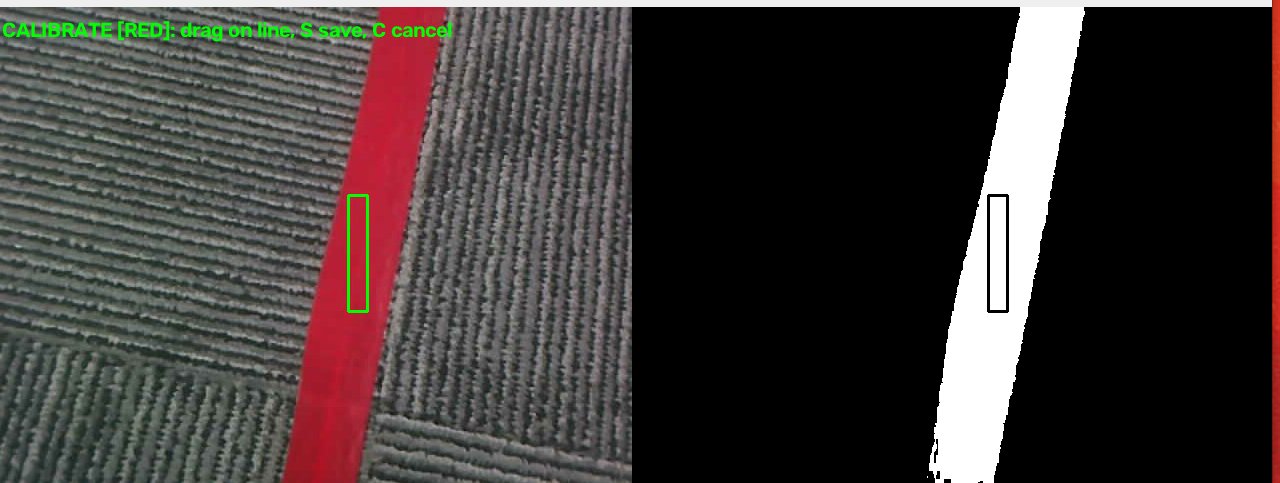
After calibration is complete, press the S key to save the calibration result to the parameter file

5. Core Source Code Analysis
Program path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/arm_demo/follow_line_clear.py
_iterative_align function (iterative alignment):
This function adjusts the chassis position through multiple iterations to make the robot aim at the target AprilTag, ensuring that the relative position between the robotic arm end-effector and the target meets the preset conditions during grasping.
tolerance = 0.017: alignment tolerance (meters); when the position error is less than this value, alignment is considered completerequired_stable = 2: alignment must be detected as stable for 2 consecutive times before returning, preventing a single accidental satisfaction of the conditionmax_iterations = 12: maximum number of iterations; after exceeding this, alignment is abandoned and the current pose is returnedmax_step = 0.04: maximum distance of a single move (meters), limiting the adjustment amplitude each time to avoid overshoot_get_fresh_tag_data(tag_id): obtains the latest AprilTag detection result and pose datadelta_x = pose[0] - grasp_distance_x: calculates the deviation between the current x direction and the expected grasping distancey_needs = abs(pose[1]) > grasp_distance_y + tolerance: determines whether the y-direction deviation exceeds the tolerancestable_count: stability counter; increments when the alignment condition is satisfied consecutively, otherwise resetsmove_by_odom(distance=..., direction=...): calls the chassis odometry Action to move the specified distance; the direction is determined by the sign of the deviation (forward/left/right)After each move, wait 2 seconds for the chassis to stabilize, then re-detect the pose
_execute_grasp function (grasping thread wrapper):
Calls
_do_graspto execute the actual grasping logic, catches exceptions, and logs themfinally: self._reset_grasp_state(): regardless of success or failure, resets the grasping state at the end
_do_grasp function (execute grasping):
This function is the main control function of the grasping flow, sequentially completing alignment, angle calculation, inverse kinematics solution, robotic arm motion, gripper closing, placement, and other steps.
self.arm_kinematics: checks whether the kinematics solver is available; if not, skips grasping_iterative_align(tag_id): calls the iterative alignment function to obtain the aligned AprilTag pose_get_fresh_tag_data(tag_id): re-obtains the latest detection result after alignment is complete, and extracts the AprilTag's yaw angle (yaw)normalize_angle_to_0_45(rvec_yaw_deg): normalizes the yaw angle to the range 0°~45°, used to determine the gripper rotation directiongrasp_offset: grasping offset[gx, gy, gz, pitch], compensating for the difference between the camera-detected position and the actual grasping positionarm_kinematics.inverse_kinematics(...): calls the inverse kinematics solver, taking the target position (camera pose + grasping offset) and pitch angle as input, and outputting 5 joint anglesresult.approximate/result.adjusted_pitch: handles the cases of approximate solutions and automatic pitch angle adjustment, outputting warning logsjoints[0:3] = round(ik_joints[0:3]): rounds the J1~J4 joint angles obtained from the inverse solution to integers (the low-level firmware only accepts integers)joints[4] = int(90 + angle_normalized): the J5 joint angle is calculated from the normalized yaw angle, so that the gripper rotation aligns with the AprilTag directionjoints[5] = 35: the J6 gripper angle is set to 35° (open state)pubSix_Arm(joints): publishes the 6-joint control command, and the robotic arm moves to the grasping poseSingleJoint_pub.publish(ArmJoint(id=6, joint=gripping_angle, time=1500)): controls the gripper to close individuallyDROP_JOINTS.get(latest_tag.tag_id, DEFAULT_DROP_JOINTS): obtains the placement joint angles from the preset dictionary according to the AprilTag ID; if there is no corresponding ID, uses the default valuedown_joint.append(self.gripping_angle): appends the gripper angle to the placement joint listpubSix_Arm(down_joint): the robotic arm moves to the placement positionSingleJoint_pub.publish(ArmJoint(id=6, joint=30, time=1500)): opens the gripper to release the objectpubSix_Arm(observation_pose): returns the robotic arm to the observation pose, ready to continue line following
x def _iterative_align(self, tag_id): tolerance = 0.017 required_stable = 2 max_iterations = 12 max_step = 0.04 stable_count = 0 for iteration in range(max_iterations): if not rclpy.ok(): return None time.sleep(0.5) tag, pose, _ = self._get_fresh_tag_data(tag_id) if tag is None or pose is None: self.get_logger().warn(f"[Iter {iteration+1}] tag {tag_id} not visible") stable_count = 0 continue delta_x = pose[0] - self.grasp_distance_x x_needs = delta_x > tolerance y_needs = abs(pose[1]) > self.grasp_distance_y + tolerance if not x_needs and not y_needs: stable_count += 1 if stable_count >= required_stable: self.get_logger().info("Chassis alignment stable, returning latest pose for IK") return pose time.sleep(0.3) continue stable_count = 0 if x_needs: move_x = min(delta_x, max_step) self.move_by_odom(distance=move_x, direction='forward') if y_needs: move_y = min(abs(pose[1]) - self.grasp_distance_y, max_step) direction = 'left' if pose[1] > 0 else 'right' self.move_by_odom(distance=move_y, direction=direction) time.sleep(2.0) self.get_logger().warn(f"Alignment did not converge after {max_iterations} iterations") _, pose, _ = self._get_fresh_tag_data(tag_id) return pose
def _execute_grasp(self, tag_id): self.get_logger().info(f"Grasp thread started for tag ID {tag_id}") try: self._do_grasp(tag_id) except Exception as e: self.get_logger().error(f"Grasp thread exception: {e}") finally: self._reset_grasp_state()
def _do_grasp(self, tag_id): if self.arm_kinematics is None: self.get_logger().error("ArmKinematics not available, skip sorting") return final_pose = self._iterative_align(tag_id) if final_pose is None: self.get_logger().error("Iterative alignment failed") return time.sleep(0.5) latest_tag, _, rvec_yaw_deg = self._get_fresh_tag_data(tag_id) if latest_tag is None: self.get_logger().error("Tag lost after alignment") return
angle_normalized = normalize_angle_to_0_45(rvec_yaw_deg) self.get_logger().info(f"Tag rvec yaw: {rvec_yaw_deg:.1f}° -> normalized: {angle_normalized:.1f}°") mx, my, mz = final_pose gx, gy, gz = self.grasp_offset[0], self.grasp_offset[1], self.grasp_offset[2] self.get_logger().info(f"camera measure pose : x={mx:.3f}, y={my:.3f}, z={mz:.3f};IK target with grasp_offset: x={mx+gx:.3f}, y={my+gy:.3f}, z={mz+gz:.3f}, pitch={self.grasp_offset[3]:.1f}°")
result: KinResult = self.arm_kinematics.inverse_kinematics( target_x=mx + gx, target_y=my + gy, target_z=mz + gz, target_pitch=self.grasp_offset[3], seed_angles_deg=None, ) if not result.success: self.get_logger().error(f"Grasp IK failed: {result.message}") return if result.approximate: self.get_logger().warn(Fore.YELLOW+f"IK using approximate solution, position error = {result.position_error:.4f} m"+Fore.RESET) if result.adjusted_pitch is not None: self.get_logger().warn(Fore.YELLOW+f"IK using pitch sweep, adjusted pitch = {result.adjusted_pitch:.1f}°"+Fore.RESET)
ik_joints = result.data joints = [0, 0, 0, 0, 0, 0] joints[0] = round(ik_joints[0]) joints[1] = round(ik_joints[1]) joints[2] = round(ik_joints[2]) joints[3] = round(ik_joints[3]) joints[4] = int(90+angle_normalized) joints[5] = 35
self.get_logger().info(f"Grasp joints: {joints}") self.pubSix_Arm(joints) time.sleep(3.5) self.SingleJoint_pub.publish(ArmJoint(id=6, joint=self.gripping_angle, time=1500)) time.sleep(2.0)
down_joint = list(DROP_JOINTS.get(latest_tag.tag_id, DEFAULT_DROP_JOINTS)) if latest_tag.tag_id not in DROP_JOINTS: self.get_logger().warn(f"No dedicated drop pose for tag {latest_tag.tag_id}, using default") down_joint.append(self.gripping_angle) self.pubSix_Arm(down_joint) time.sleep(2.5) self.SingleJoint_pub.publish(ArmJoint(id=6, joint=30, time=1500)) time.sleep(2.0) self.pubSix_Arm(self.observation_pose) time.sleep(2.5)
Parameter file
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/param/common.yaml
Parameter Description:
apriltag_grasp_distance: [0.1, 0.0]: the expected grasping distance during chassis alignment[x, y](meters); x is the front-back direction distance, and y is the left-right direction offsettag_size: 0.02: the physical side length of the AprilTag (meters), used for pose estimationgrasp_offset: [0.00, 0.0, 0.015, 85.0]: grasping offset[x, y, z, pitch], compensating for the error reaching the target point caused by servo backlash and link rigidity degradation; pitch=85° means the gripper grasps almost vertically downwardgripping_angle: 140: the angle (degrees) when the gripper is closed; the larger the value, the tighter the gripperobservation_pose: [90, 115, 3, 0, 90, 30]: the 6 joint angles (degrees) of the observation pose; the robotic arm maintains this pose during line followingtag_confirm_frames: 1: the number of frames a tag must be stably detected consecutively before pausing line following, preventing false triggeringtag_trigger_distance: 0.3: the maximum distance (meters) to trigger sorting; when the AprilTag distance exceeds this value, continue line following to approach, and when it is less than this value, pause line following and start graspinggrasp_cooldown: 0.5: the cooldown time (seconds) before re-detecting tags after a sorting round is complete, preventing repeated triggering
xxxxxxxxxxfollow_line ros__parameters apriltag_grasp_distance0.1 0.0 # x,y axis alignment distance (meters) tag_size0.02 # AprilTag side length (meters) grasp_offset0.000.00.01585.0 # x,y,z axis offset distance and included angle, compensating for the error reaching the target point caused by servo backlash and link rigidity degradation gripping_angle140 # gripper grasping angle, in degrees, integer observation_pose90115309030 tag_confirm_frames1 # number of frames a tag must be stably detected consecutively before pausing line following tag_trigger_distance0.3 # maximum distance to trigger sorting (meters); if exceeded, continue line following to approach grasp_cooldown0.5 # cooldown time (seconds) before re-detecting tags after a sorting round is complete