Welcome to ROSMASTER M1 PRO repository
2.Multimodal Visual Understanding
Multimodal Visual Understanding
Multimodal Visual Understanding1. Course Content2. Preparation3. Running the Cases4. Source Code Analysis
1. Course Content
Run the example program to let the robot observe the environment through terminal text interaction, and perform tasks combined with commands.
Note
The only difference between the text version and the voice version is the command input method; the text version does not include the speech recognition and speech synthesis playback steps.
2. Preparation
ros2 launch yahboomcar_bringup dify_llm_agents.launch.py use_camera:=true
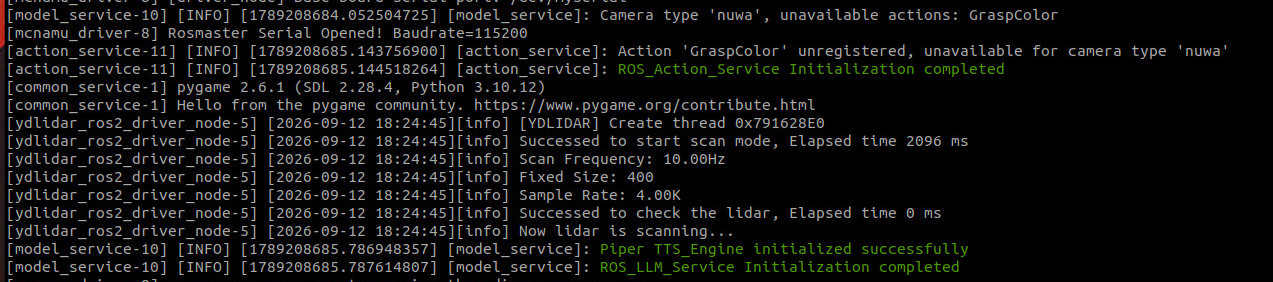
Text interaction terminal
xxxxxxxxxxdify_tui
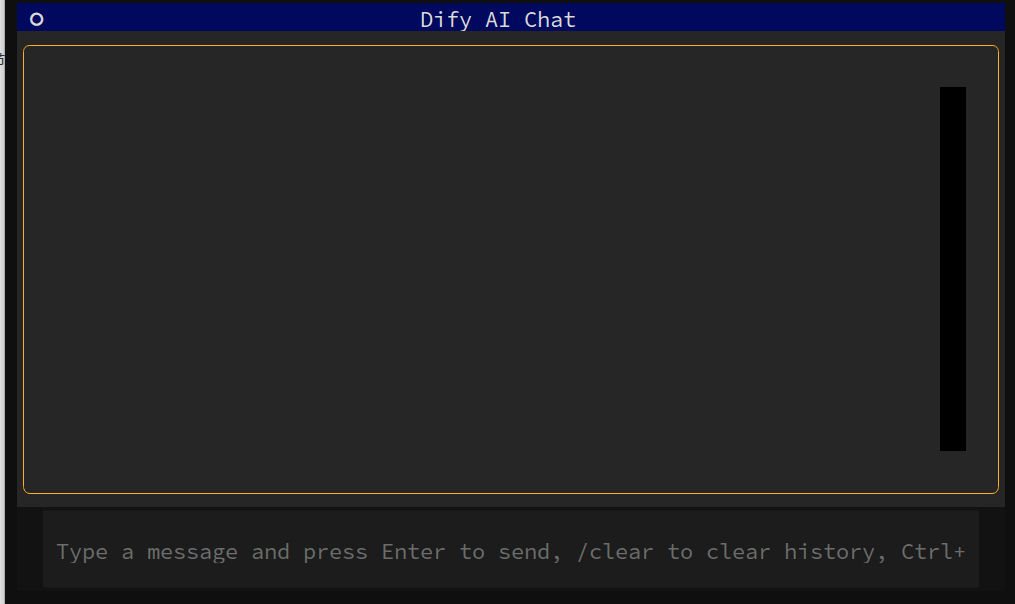
Use the
/clearcommand to clear the terminal conversation history, and ctrl+q to exit the interaction terminal
3. Running the Cases
Here are two reference test cases; you can write your own test commands as you like.
Help me see what objects are in front of you, and tell me what these objects are used for.
Please look in front of you and check whether there is a blue block and a pack of tissues. If so, nod your head; if not, shake your head.
4. Source Code Analysis
Refer to the analysis of the corresponding chapter of AI Model - Voice Version; the source code is the same, only the interaction method differs.