Welcome to ROSMASTER M1 PRO repository
14.Finger control robotic arm
Finger Control Robotic Arm
1. Content Description
This function implements acquiring color images and using the mediapipe framework to detect fingers, calculating the angle between the thumb and the index finger to control the opening and closing of the robotic arm gripper (servo No. 6).
2. Program Startup
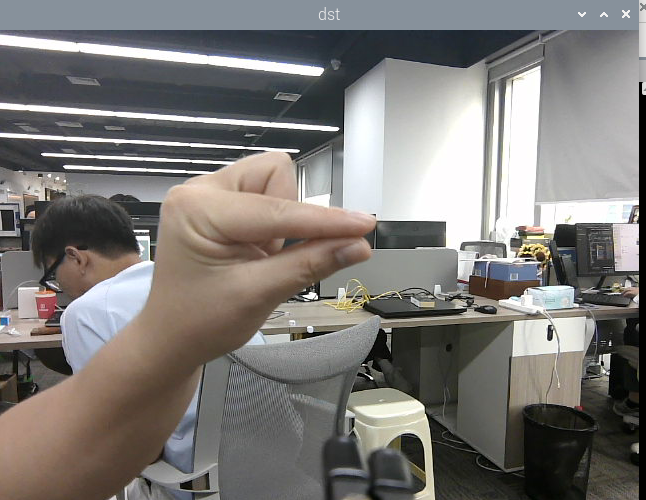
xxxxxxxxxxros2 launch yahboomcar_bringup mediapipe_demo.launch.py demo:=FingerCtrlGripperAfter the program runs, as shown in the figure below, once the program detects a palm, it will calculate the angle between the thumb and the index finger, slowly open and close the two fingers, and the robotic arm gripper will follow accordingly.
3. Core Source Code Analysis
Program code path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/mediapipe/17_FingerCtrlGripper.py
Import the required library files,
xxxxxxxxxximport mathimport timeimport cv2 as cvimport numpy as np#Import the mediapipe libraryimport mediapipe as mpimport rclpyfrom rclpy.node import Nodefrom cv_bridge import CvBridgefrom sensor_msgs.msg import Imagefrom arm_msgs.msg import ArmJoints,ArmJointimport cv2Initialize the data and define the publisher and subscriber,
xdef __init__(self, name): super().__init__(name) self.lmList = [] #Use the class in the mediapipe library to define a hand object self.mpHand = mp.solutions.hands self.mpDraw = mp.solutions.drawing_utils self.hands = self.mpHand.Hands( static_image_mode=False, max_num_hands=2, min_detection_confidence=0.5, min_tracking_confidence=0.5 )
self.rgb_bridge = CvBridge() #Define the topic publisher for controlling the 6 servos, and publish the detected pose self.TargetAngle_pub = self.create_publisher(ArmJoints, "arm6_joints", 10) #Define the topic publisher for controlling a single servo, to later control servo No. 6 (the gripper) individually self.pub_SingleTargetAngle = self.create_publisher(ArmJoint, "arm_joint", 10) self.init_joints = [90, 150, 10, 20, 90, 180] self.pubSix_Arm(self.init_joints) #Define the Subscriber for the color image topic self.sub_rgb = self.create_subscription(Image,"/camera/color/image_raw",self.get_RGBImageCallBack,100)Color image callback function,
xxxxxxxxxxdef get_RGBImageCallBack(self,msg): #Use CvBridge to convert the color image message data into image data frame = self.rgb_bridge.imgmsg_to_cv2(msg, "bgr8") #Pass the obtained image into the custom findHands function to check the palm img = self.findHands(frame) #Run the custom findPosition function to obtain the xy coordinates of the finger joints lmList = self.findPosition(frame, draw=False) if len(lmList) != 0: #Calculate the angle formed by the thumb tip, wrist joint, and index finger tip angle = self.calc_angle(4, 0, 8) print("angle: ",angle) #If the angle is less than 2, assign the value 2 to angle, because the maximum servo value is 180 if angle<2: angle = 2 #Calculate the value of servo No. 6 grasp = 360/angle #Execute the topic function that publishes the single servo angle self.pubSingleArm(6,int(grasp)) cv.imshow('dst', frame) action = cv2.waitKey(1)findPosition function, to obtain the xy coordinates of the finger joints
xxxxxxxxxxdef findPosition(self, frame, draw=True): #Define a list to store the id of each joint and the xy coordinates corresponding to the id self.lmList = [] if self.results.multi_hand_landmarks: #Iterate through the palm detection results to obtain the joint id and the xy coordinates corresponding to the joint id for id, lm in enumerate(self.results.multi_hand_landmarks[0].landmark): # print(id,lm) h, w, c = frame.shape cx, cy = int(lm.x * w), int(lm.y * h) # print(id, lm.x, lm.y, lm.z) self.lmList.append([id, cx, cy]) return self.lmLiscalc_angle function, to calculate the angle formed by 3 points,
def calc_angle(self, pt1, pt2, pt3): #Extract the xy coordinates from the list according to the joint id point1 = self.lmList[pt1][1], self.lmList[pt1][2] point2 = self.lmList[pt2][1], self.lmList[pt2][2] point3 = self.lmList[pt3][1], self.lmList[pt3][2] #Calculate the distance between the joints a = self.get_dist(point1, point2) b = self.get_dist(point2, point3) c = self.get_dist(point1, point3) try: radian = math.acos((math.pow(a, 2) + math.pow(b, 2) - math.pow(c, 2)) / (2 * a * b)) angle = radian / math.pi * 180 except: angle = 0 return abs(angle)