Welcome to ROSMASTER M1 PRO repository
3.Random movement
Random Movement
1. Course Content
This section explains how to use the MoveIt2 library to make the robot arm in RViz randomly move to a certain pose.
2. Preparation
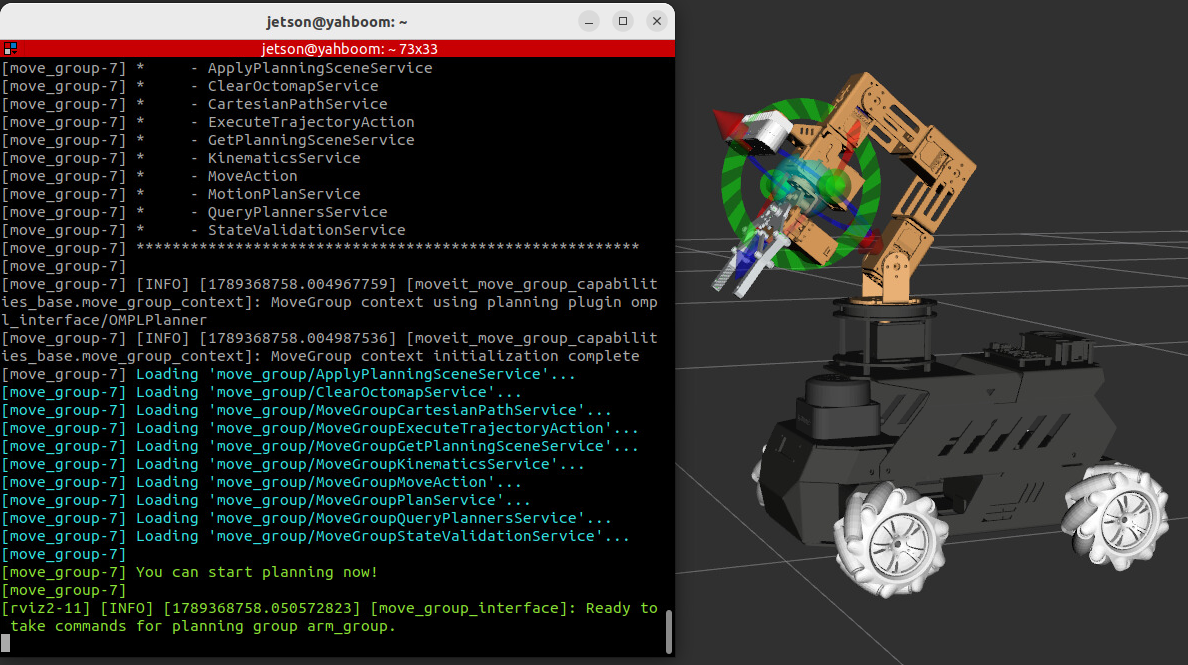
ros2 launch yahboomcar_bringup moveit_simulation.launch.py sim2real:=trueOnce the program starts, when You can start planning now! appears in the terminal, it means the startup was successful, as shown in the figure below:
3. Case Demonstration
Then enter the following command in the terminal to launch the random movement program:
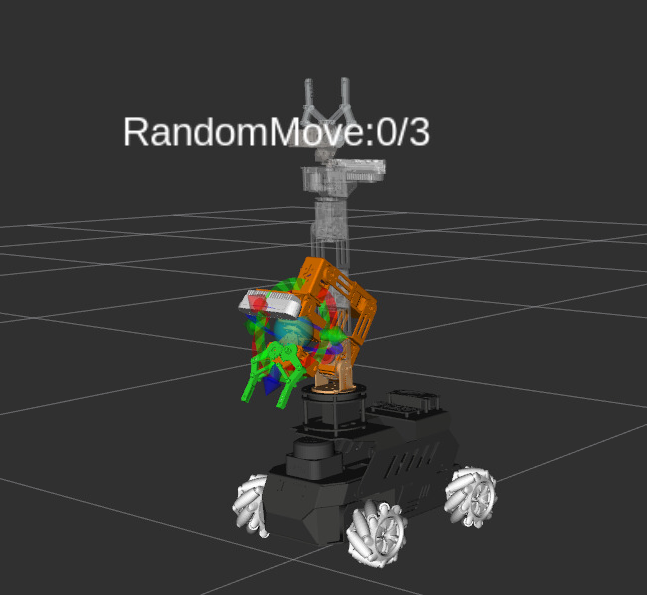
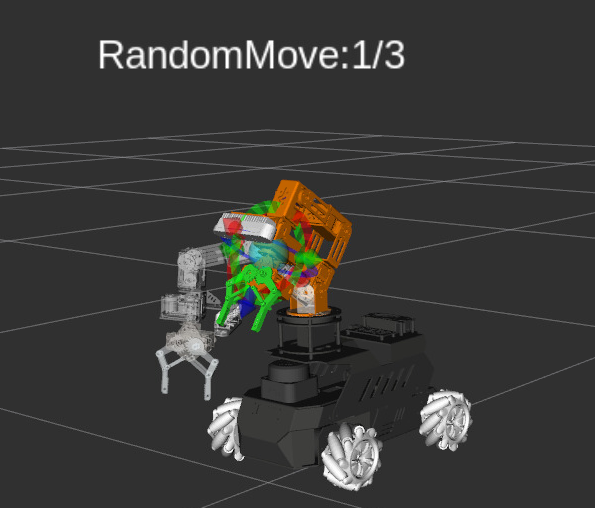
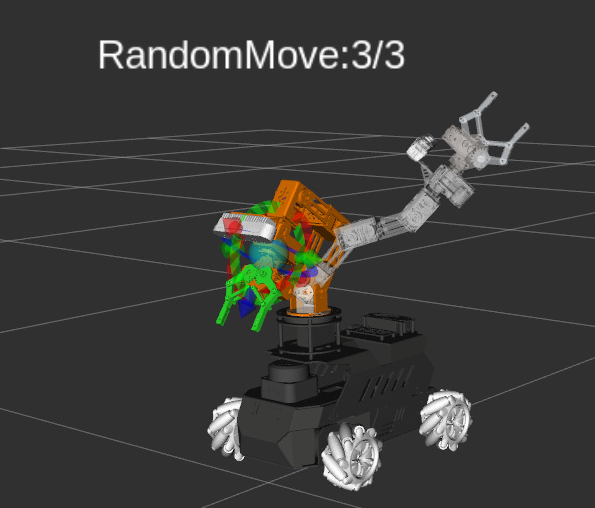
xxxxxxxxxxros2 run moveit_demo random_moveAfter the program runs, the robot arm in RViz will perform 3 random position movements, as shown in the figure below:
4. Core Source Code Analysis
Program code path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/moveit_demo/src/random_move.cpp
initialize function description:
MoveGroupInterface(shared_from_this(), "arm_group"): Creates a MoveGroup control interface, bound to thearm_groupplanning group, used to control the robot arm motion planning.PlanningSceneInterface: Creates a planning scene interface, used to manage the collision objects in the scene.setNumPlanningAttempts(10): Sets the number of planning attempts per call to 10, improving the planning success rate.setPlanningTime(10.0): Sets the maximum time for a single planning attempt to 10 seconds.setMaxVelocityScalingFactor(1.0): Sets the maximum velocity scaling factor to 1.0, i.e., using the full speed of the planned motion.setMaxAccelerationScalingFactor(1.0): Sets the maximum acceleration scaling factor to 1.0, i.e., using the full acceleration of the planned motion.MoveItVisualTools: Creates an RViz visualization tool for displaying text and markers in RViz.deleteAllMarkers(): Clears all existing markers in RViz.loadRemoteControl(): Loads the RViz remote control buttons to facilitate debugging interaction.setNamedTarget("up"): Sets the target to the preset "up" pose.plan(init_plan): Plans a trajectory to the "up" pose and returns whether it succeeded.execute(init_plan): Executes the planned trajectory, moving the robot arm to the "up" pose.create_wall_timer(std::chrono::seconds(10), ...): Creates a timer with a 10-second interval, triggering a random movement every 10 seconds.
move_to_random_target function description:
move_count_ >= 3: After 3 random movements are completed, cancels the timer and shuts down the node to end the program.setRandomTarget(): Randomly generates a set of joint angles within the joint space as the target pose.plan(my_plan): Plans a trajectory to the random target, checking whether a collision-free path exists.execute(my_plan): If planning succeeds, executes the trajectory and drives the robot arm to the random pose.for (int attempt = 0; attempt < 20; attempt++): Tries the random target up to 20 times until a successfully plannable path is found.timer_->cancel()andrclcpp::shutdown(): After all 3 movements are complete, stops the timer and shuts down the node.
publish_status_text function description:
deleteAllMarkers(): Clears old markers before publishing new text each time.Eigen::Isometry3d::Identity(): Creates an identity transformation matrix as the text display pose.text_pose.translation().z() = 0.5: Displays the text at a height of z=0.5 m.publishText(text_pose, text, rvt::WHITE, rvt::XLARGE): Publishes the status text in RViz in white extra-large font.trigger(): Triggers a render update so that the text is visible in RViz.
xclass RandomMove : public rclcpp::Node{public: RandomMove() : Node("random_target_move"), move_count_(0) { RCLCPP_INFO(this->get_logger(), "Initializing RandomMoveIt2Control."); }
void initialize() { // Initialize MoveGroupInterface after shared_ptr is fully constructed move_group_interface_ = std::make_shared<moveit::planning_interface::MoveGroupInterface>( shared_from_this(), "arm_group"); planning_scene_interface_ = std::make_shared<moveit::planning_interface::PlanningSceneInterface>();
move_group_interface_->setNumPlanningAttempts(10); move_group_interface_->setPlanningTime(10.0); move_group_interface_->setMaxVelocityScalingFactor(1.0); move_group_interface_->setMaxAccelerationScalingFactor(1.0);
// Initialize RViz visual tools for text display visual_tools_ = std::make_shared<moveit_visual_tools::MoveItVisualTools>( shared_from_this(), move_group_interface_->getPlanningFrame(), "random_move_markers"); visual_tools_->deleteAllMarkers(); visual_tools_->loadRemoteControl(); publish_status_text("RandomMove:0/3");
// Move arm to "up" position for initialization moveit::planning_interface::MoveGroupInterface::Plan init_plan; move_group_interface_->setNamedTarget("up"); bool init_success = (move_group_interface_->plan(init_plan) == moveit::core::MoveItErrorCode::SUCCESS); if (init_success) { RCLCPP_INFO(this->get_logger(), "Init arm succeeded."); move_group_interface_->execute(init_plan); } else { RCLCPP_ERROR(this->get_logger(), "Init arm failed!"); }
timer_ = this->create_wall_timer( std::chrono::seconds(10), std::bind(&RandomMove::move_to_random_target, this)); }
private: void move_to_random_target() { if (move_count_ >= 3) { RCLCPP_INFO(this->get_logger(), "Random movement ended."); publish_status_text("RandomMove:Ended"); timer_->cancel(); rclcpp::shutdown(); return; }
move_count_++; RCLCPP_INFO(this->get_logger(), "Attempting random movement %d/3.", move_count_); publish_status_text("RandomMove:"+std::to_string(move_count_)+"/3");
bool found_valid_target = false; moveit::planning_interface::MoveGroupInterface::Plan my_plan;
// Retry up to 20 times to find a collision-free random target for (int attempt = 0; attempt < 20; attempt++) { move_group_interface_->setRandomTarget();
bool plan_success = (move_group_interface_->plan(my_plan) == moveit::core::MoveItErrorCode::SUCCESS);
if (plan_success) { found_valid_target = true; RCLCPP_INFO(this->get_logger(), "Random movement %d: Planning succeeded, moving the arm.", move_count_); move_group_interface_->execute(my_plan); break; } else { RCLCPP_WARN(this->get_logger(), "Random movement %d: Planning attempt %d failed, retrying...", move_count_, attempt + 1); } }
if (!found_valid_target) { RCLCPP_ERROR(this->get_logger(), "Random movement %d: Failed to find a collision-free target after 20 attempts.", move_count_); }
// Check if all 3 movements are done after this attempt if (move_count_ >= 3) { publish_status_text("RandomMove:Ended"); timer_->cancel(); rclcpp::shutdown(); } }
void publish_status_text(const std::string& text) { if (visual_tools_) { visual_tools_->deleteAllMarkers(); Eigen::Isometry3d text_pose = Eigen::Isometry3d::Identity(); text_pose.translation().z() = 0.5; visual_tools_->publishText(text_pose, text, rvt::WHITE, rvt::XLARGE); visual_tools_->trigger(); } }
std::shared_ptr<moveit::planning_interface::MoveGroupInterface> move_group_interface_; std::shared_ptr<moveit::planning_interface::PlanningSceneInterface> planning_scene_interface_; std::shared_ptr<moveit_visual_tools::MoveItVisualTools> visual_tools_; rclcpp::TimerBase::SharedPtr timer_; int move_count_;};