Welcome to ROSMASTER M1 PRO repository
3.Robotic Arm Chassis Coordination Control
Robotic Arm and Chassis Coordinated Control
Robotic Arm and Chassis Coordinated Control1. Content Description2. Preparation3. Case Demonstration4. Core Source Code Analysis
1. Content Description
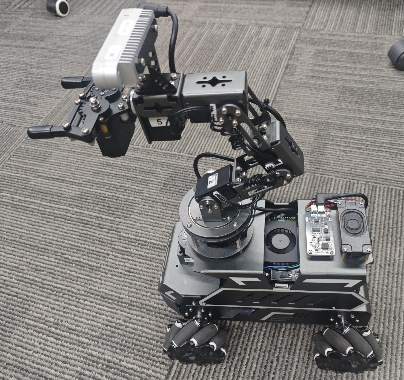
This course implements synchronized motion using the robotic arm's pose and the chassis, with the robotic arm and chassis making relative motions one after the other.
2. Preparation
ros2 launch yahboomcar_bringup arm_demo.launch.py demo:=combined_control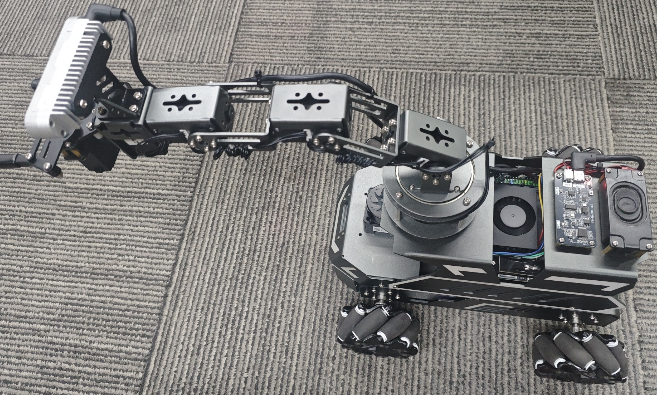
3. Case Demonstration
Trigger the action
xxxxxxxxxxros2 service call /combined_move_trigger std_srvs/srv/Trigger {}
Each time the action is triggered, both the robotic arm and the chassis move alternately in opposite directions to achieve coordinated control
4. Core Source Code Analysis
Code path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/arm_demo/combined_control.py
_trigger_callback function (service trigger callback):
self._running: running status flag; if already running, reject new trigger requestsself._current_joint_states: current robotic arm joint state; if not received, return an errormove_by_odom_client.wait_for_server(timeout_sec=3.0): waits for the chassis odometry Action server to be ready; if it times out at 3 seconds, returns failureself._trigger_count: trigger counter, used to alternately switch the motion directionarm_direction = -1.0 if (trigger_count % 2 == 1) else 1.0: on odd-numbered triggers the robotic arm moves backward (-x), and on even-numbered triggers the robotic arm moves forward (+x)base_direction: chassis motion direction, opposite to the robotic arm direction (when the robotic arm moves backward the chassis moves forward, and vice versa)threading.Thread(target=self._combined_worker, daemon=True): starts a background daemon thread to execute the coordinated motion, avoiding blocking the service callback
_combined_worker function (worker thread wrapper):
Calls
_combined_move_implto execute the actual coordinated motion, catches exceptions, and logs themfinally: self._running = False: regardless of success or failure, resets the running status flag at the end
_combined_move_impl function (coordinated motion implementation):
base_j2, base_j3, base_j4: extracts the J2/J3/J4 joint angles from the initial pose as reference valuesfixed_j1, fixed_j5, fixed_j6: the fixed and unchanging J1/J5/J6 joint anglesstart_disp = self._arm_disp: the starting extension amount is the current value, achieving continuous motion across triggers (not returning to the initial position)end_disp: target extension amount; when moving backward it is-arm_distance, and when moving forward it is0.0(the frontmost)MoveByOdom.Goal(): constructs the chassis odometry motion goal, wheredistanceis the movement distance (meters) anddirectionis the direction (forward/backward)send_goal_async(goal, feedback_callback=...): asynchronously sends the chassis motion goal and registers a feedback callback to update the moved distance in real timegoal_handle.accepted: checks whether the goal is accepted by the serverprogress = self._moved_distance / self.base_distance: calculates the chassis motion progress (0~1), used to interpolate the robotic arm extension targetself._update_arm_reach(start_disp + (end_disp - start_disp) * progress, ...): linearly interpolates the robotic arm extension amount according to the chassis progress, achieving synchronized coordinated control of the chassis and the robotic armConvergence phase after the chassis is in position: continuously issues the final extension command until the smoother output converges (difference less than 0.005), waiting at most 5 seconds
self._arm_disp = end_disp: updates the current extension amount to prepare for the next trigger
_odom_feedback_callback function (odometry feedback callback):
self._moved_distance = feedback_msg.feedback.moved_distance: updates the chassis moved distance in real time, used to calculate the coordinated progress
_update_arm_reach function (robotic arm extension update):
reach_pid.compute(displacement, 0.0): the PID controller calculates the raw output value according to the target extension amountSmoothing (Slew Rate Limiter): limits the change per step to no more than
max_step_change_zto prevent robotic arm jittertarget_j2/j3/j4 = base_j2/j3/j4 + angular_z * gain_reach_j2/j3/j4: distributes the PID output proportionally to the three joints J2/J3/J4 to achieve end-effector extension motionmax(0, min(180, target_j)): limits the joint angle to the range of 0~180 degreespubSix_Arm(joints, runtime=runtime): publishes the 6-joint control command to the robotic arm driverself._current_joints_cmd: records the currently issued joint angle command
x def _trigger_callback(self, request, response): if self._running: response.success = False response.message = "Combined motion already running, please wait" return response if self._current_joint_states is None: response.success = False response.message = "No arm joint state received yet, please try again later" return response if not self.move_by_odom_client.wait_for_server(timeout_sec=3.0): response.success = False response.message = "move_by_odom action server not available" return response
self._trigger_count += 1 # Odd trigger: chassis forward + end-effector backward (-x); even trigger: chassis backward + end-effector forward (+x) arm_direction = -1.0 if (self._trigger_count % 2 == 1) else 1.0 base_direction = 'forward' if arm_direction < 0.0 else 'backward' phase = 1 if arm_direction < 0.0 else 2
self._running = True threading.Thread( target=self._combined_worker, args=(phase, arm_direction, base_direction), daemon=True ).start()
arm_desc = "backward" if arm_direction < 0.0 else "forward" response.success = True response.message = ( f"Phase {phase} started: chassis {base_direction} {self.base_distance:.2f}m, " f"arm end-effector moves {arm_desc} {self.arm_distance:.2f}m simultaneously" ) self.get_logger().info(response.message) return response
# ========== Coordinated motion worker thread ========== def _combined_worker(self, phase, arm_direction, base_direction): try: self._combined_move_impl(phase, arm_direction, base_direction) except Exception as e: self.get_logger().error(f"Combined move thread exception: {e}") finally: self._running = False
def _combined_move_impl(self, phase, arm_direction, base_direction): base_j2, base_j3, base_j4 = float(self.init_pose[1]), float(self.init_pose[2]), float(self.init_pose[3]) fixed_j1, fixed_j5, fixed_j6 = int(self.init_pose[0]), int(self.init_pose[4]), int(self.init_pose[5]) # Target extension amount: backward to -arm_distance, forward back to 0 (frontmost), transitioning continuously from the current extension amount without returning to the initial position start_disp = self._arm_disp end_disp = -self.arm_distance if arm_direction < 0.0 else 0.0 self.get_logger().info( f"Phase {phase}: base joints J2={base_j2:.1f}, J3={base_j3:.1f}, J4={base_j4:.1f}, " f"arm displacement {start_disp:+.3f}m -> {end_disp:+.3f}m" )
# PID and smoother state is kept across triggers, so the robotic arm moves continuously from the current pose self._moved_distance = 0.0 goal = MoveByOdom.Goal() goal.distance = float(abs(self.base_distance)) goal.angle = 0.0 goal.direction = base_direction try: send_goal_future = self.move_by_odom_client.send_goal_async( goal, feedback_callback=self._odom_feedback_callback ) while rclpy.ok() and not send_goal_future.done(): time.sleep(0.05) goal_handle = send_goal_future.result() if not goal_handle.accepted: self.get_logger().warn("MoveByOdom goal rejected by action server") return result_future = goal_handle.get_result_async() except Exception as e: self.get_logger().error(f"Send MoveByOdom goal exception: {e}") return self.get_logger().info(f"Chassis start moving {base_direction} {self.base_distance:.2f}m, arm moving simultaneously")
# While the chassis is moving, the extension target transitions linearly from the current value to the target value (interpolated by chassis progress) while rclpy.ok() and not result_future.done(): progress = self._moved_distance / self.base_distance progress = max(0.0, min(progress, 1.0)) self._update_arm_reach(start_disp + (end_disp - start_disp) * progress, base_j2, base_j3, base_j4, fixed_j1, fixed_j5, fixed_j6) time.sleep(self.arm_control_period)
# Chassis in position, confirm the action result and ensure the end-effector reaches the final target try: result = result_future.result().result if result.success: self.get_logger().info(f"Chassis movement complete: {result.message}") else: self.get_logger().warn(f"Chassis movement failed: {result.message}") except Exception as e: self.get_logger().error(f"MoveByOdom result exception: {e}")
# After the chassis is in position, keep issuing until the smoother converges to the final extension amount (the smoother has a limited step, so it needs to catch up) final_displacement = end_disp converge_deadline = time.time() + 5.0 while rclpy.ok() and time.time() < converge_deadline: raw_z = self.reach_pid.compute(final_displacement, 0.0) self._update_arm_reach(final_displacement, base_j2, base_j3, base_j4, fixed_j1, fixed_j5, fixed_j6, runtime=500) if abs(raw_z - self.last_angular_z) < 0.005: break time.sleep(self.arm_control_period) self._arm_disp = end_disp time.sleep(1.5) self.get_logger().info(f"Phase {phase} combined motion complete")
def _odom_feedback_callback(self, feedback_msg): self._moved_distance = feedback_msg.feedback.moved_distance
def _update_arm_reach(self, displacement, base_j2, base_j3, base_j4, fixed_j1, fixed_j5, fixed_j6, runtime=None): """Update J2/J3/J4 according to the target extension amount: same mapping as apriltag_follow.py, only the input differs""" if runtime is None: runtime = self.arm_step_runtime raw_z = self.reach_pid.compute(displacement, 0.0)
# Smoothing (Slew Rate Limiter) diff_z = raw_z - self.last_angular_z if diff_z > self.max_step_change_z: angular_z = self.last_angular_z + self.max_step_change_z elif diff_z < -self.max_step_change_z: angular_z = self.last_angular_z - self.max_step_change_z else: angular_z = raw_z self.last_angular_z = angular_z
target_j2 = base_j2 + angular_z * self.gain_reach_j2 target_j3 = base_j3 + angular_z * self.gain_reach_j3 target_j4 = base_j4 + angular_z * self.gain_reach_j4
joints = [ fixed_j1, int(max(0, min(180, target_j2))), int(max(0, min(180, target_j3))), int(max(0, min(180, target_j4))), fixed_j5, fixed_j6 ] self.pubSix_Arm(joints, runtime=runtime) self._current_joints_cmd = joints