Welcome to ROSMASTER M1 PRO repository
7.3D object recognition
3D Object Recognition
1. Content Description
This lesson implements the functions of acquiring the color image and using the mediapipe framework to recognize 3D objects (the case only shows four types: mug, shoe, chair, and camera).
2. Program Startup
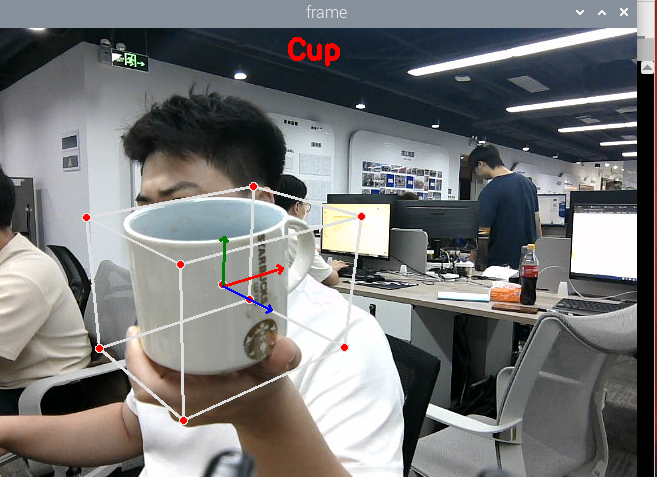
xxxxxxxxxxros2 launch yahboomcar_bringup mediapipe_demo.launch.py demo:=ObjectionAfter the program runs, the default recognition target is the shoe (Shoe). You can press the F key to switch the recognized object. As shown in the figure below, a mug is recognized.
3. Core Source Code Analysis
Program code path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/mediapipe/07_Objection.py
Import the required library files,
xxxxxxxxxximport mediapipe as mpimport cv2 as cvimport timeimport rclpyfrom rclpy.node import Nodefrom sensor_msgs.msg import Imagefrom cv_bridge import CvBridgeimport osimport numpy as npInitialize the data and define the Publisher and Subscriber,
xxxxxxxxxxdef __init__(self, staticMode=False, maxObjects=5, minDetectionCon=0.5, minTrackingCon=0.99): super().__init__('Objection') self.staticMode = staticMode self.maxObjects = maxObjects self.minDetectionCon = minDetectionCon self.minTrackingCon = minTrackingCon self.index = 0 self.modelNames = ['Shoe', 'Chair', 'Cup', 'Camera'] #Use the class in the mediapipe library to define a 3D detection object self.mpObjection = mp.solutions.Objection self.mpDraw = mp.solutions.drawing_utils self.mpObjection = self.mpObjection.Objection( self.staticMode, self.maxObjects, self.minDetectionCon, self.minTrackingCon, self.modelNames[self.index]) self.bridge = CvBridge() #Define the Subscriber for the color image topic camera_type = os.getenv('CAMERA_TYPE', 'usb') topic_name = '/ascamera_hp60c/camera_publisher/rgb0/image' if camera_type == 'nuwa' else '/usb_cam/image_raw' self.subscription = self.create_subscription( Image, topic_name, self.image_callback, 10)Color image callback function,
xxxxxxxxxxdef image_callback(self, msg): frame = self.bridge.imgmsg_to_cv2(msg, desired_encoding='bgr8') action = cv2.waitKey(1) #Press the F key to switch the recognized object if action == ord('f') or action == ord('F') : self.configUP() frame = self.findObjection(frame) cv.imshow('Objection', frame)configUP function for switching the recognized object, selects self.modelNames by modifying the value of self.index. The options of self.modelNames are ['Shoe', 'Chair', 'Cup', 'Camera']
xxxxxxxxxxdef configUP(self): self.index += 1 if self.index>=4:self.index=0 self.mpObjection = self.mpObjection.Objection( self.staticMode, self.maxObjects, self.minDetectionCon, self.minTrackingCon, self.modelNames[self.index])findObjection object recognition function,
def findObjection(self, frame): cv.putText(frame, self.modelNames[self.index], (int(frame.shape[1] / 2) - 30, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 3) #Convert the color space of the input image from BGR to RGB for subsequent image processing img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) #Call the process function in the mediapipe library for image processing; during init, the self.pose object was created and initialized results = self.mpObjection.process(img_RGB) #Determine whether the target object is recognized if results.detected_objects: for id, detection in enumerate(results.detected_objects): #Draw a coordinate system on the recognized target object in the image self.mpDraw.draw_landmarks(frame, detection.landmarks_2d, self.mpObjection.BOX_CONNECTIONS) self.mpDraw.draw_axis(frame, detection.rotation, detection.translation) return frame