Welcome to ROSMASTER M1 PRO repository
15.3D Spatial Tracking AprilTag
3D Spatial Tracking AprilTags
3D Spatial Tracking AprilTags1. Course Content2. Preparation3. Case Demonstration4. Core Source Code Analysis
1. Course Content
The feature implements the program acquiring images through the camera and recognizing the AprilTag. When the AprilTag is moved up/down, left/right, and forward/backward, the robotic arm follows the AprilTag's movement.
2. Preparation
The wooden block used in this section is: 40x40x40mm AprilTag wooden block
xxxxxxxxxxros2 launch yahboomcar_bringup arm_demo.launch.py demo:=apriltag_follow
3. Case Demonstration
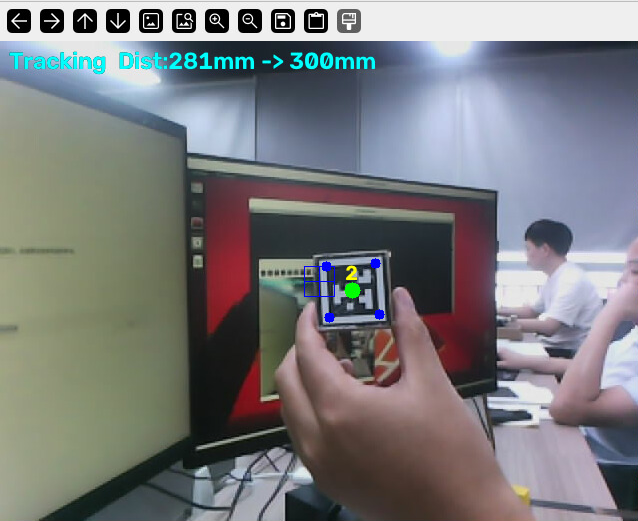
Hold the AprilTag wooden block and move it slowly and smoothly in the 3D space in front of the robotic arm:
Left/right panning: base servo No. 1 rotates smoothly left and right to follow;
Up/down raising and lowering: pitch joints No. 2/3/4 cooperate to raise or press down;
Forward/backward pushing and pulling: the robotic arm automatically adjusts the linkage extension amount, keeping the distance between the camera and the wooden block constant;
4. Core Source Code Analysis
Program path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/arm_demo/apriltag_follow.py
xxxxxxxxxx
    def track(self, center_x, center_y):        """Three-channel PID: pixel X -> J1, pixel Y -> J2/J3/J4 pitch, depth Z -> J2/J3/J4 reach + J6 gripper"""
        # --- Channel 1: left/right (pixel X -> J1) ---        raw_x = self.angular_x_PID.compute(center_x, TARGET_X)
        # --- Channel 2: up/down (pixel Y -> J2/J3/J4 pitch) ---        raw_y = self.angular_y_PID.compute(center_y, TARGET_Y)
        # --- Channel 3: forward/backward (depth -> J2/J3/J4 reach + J6) ---        raw_z = self.depth_pid.compute(self.cur_depth, self.target_depth)
        # ==== Smoothing (Slew Rate Limiter) ====        # X axis        diff_x = raw_x - self.last_angular_x        if diff_x > self.max_step_change_xy:            angular_x = self.last_angular_x + self.max_step_change_xy        elif diff_x < -self.max_step_change_xy:            angular_x = self.last_angular_x - self.max_step_change_xy        else:            angular_x = raw_x        self.last_angular_x = angular_x
        # Y axis        diff_y = raw_y - self.last_angular_y        if diff_y > self.max_step_change_xy:            angular_y = self.last_angular_y + self.max_step_change_xy        elif diff_y < -self.max_step_change_xy:            angular_y = self.last_angular_y - self.max_step_change_xy        else:            angular_y = raw_y        self.last_angular_y = angular_y
        # Z axis        diff_z = raw_z - self.last_angular_z        if diff_z > self.max_step_change_z:            angular_z = self.last_angular_z + self.max_step_change_z        elif diff_z < -self.max_step_change_z:            angular_z = self.last_angular_z - self.max_step_change_z        else:            angular_z = raw_z        self.last_angular_z = angular_z
        base_j1, base_j2, base_j3, base_j4 = 90, 150.0, 12.0, 20.0
        # Pitch gains (Y channel -> J2/J3/J4)        gain_pitch_j2 = -150.0        gain_pitch_j3 = -60.0        gain_pitch_j4 = -100.0
        # J1: pure yaw        gain_j1 = -90.0        target_j1 = base_j1 + (10 * angular_x * gain_j1)
        # J2/J3/J4: pitch (Y) + reach (Z) combined        target_j2 = base_j2 + (angular_y * gain_pitch_j2) + (angular_z * self.gain_reach_j2)        target_j3 = base_j3 + (angular_y * gain_pitch_j3) + (angular_z * self.gain_reach_j3)        target_j4 = base_j4 + (angular_y * gain_pitch_j4) + (angular_z * self.gain_reach_j4)
        base_j6 = 30        target_j6 = base_j6 + (angular_z * self.gain_j6)
        joints_0 = [            int(max(0, min(180, target_j1))),            int(max(0, min(180, target_j2))),            int(max(0, min(180, target_j3))),            int(max(0, min(180, target_j4))),            90,            int(max(10, min(180, target_j6)))        ]        self.pubSixArm(joints_0)        self.cur_joints = joints_0
Parameter file
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/param/common.yaml
Parameter Description:
xapriltag_follow ros__parameters tag_size0.025 # 4*4*4 cm wooden block observation_pose90 150 12 20 90 30 # robotic arm observation pose (degrees) camera_measure0.0 0.0 0.0 # measure coordinate frame measurement compensation (meters) pixel_tolerance15 # pixel alignment tolerance target_depth0.3 # target hold (meters)