Welcome to ROSMASTER M1 PRO repository
9.Scene Design
Scene Design
1. Course Content
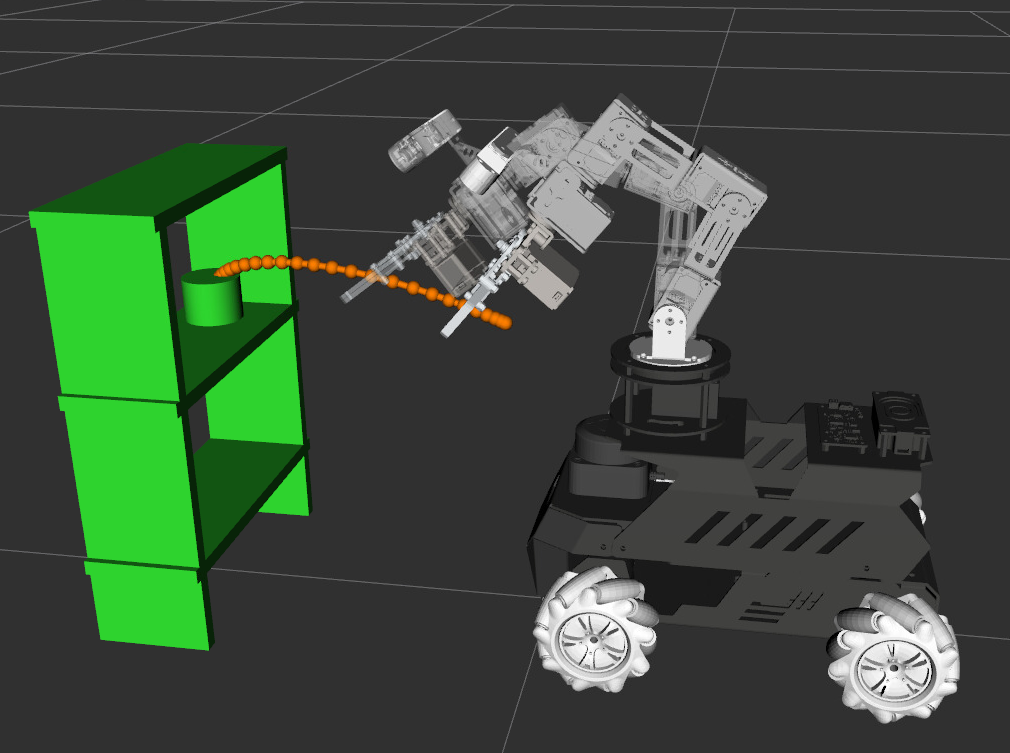
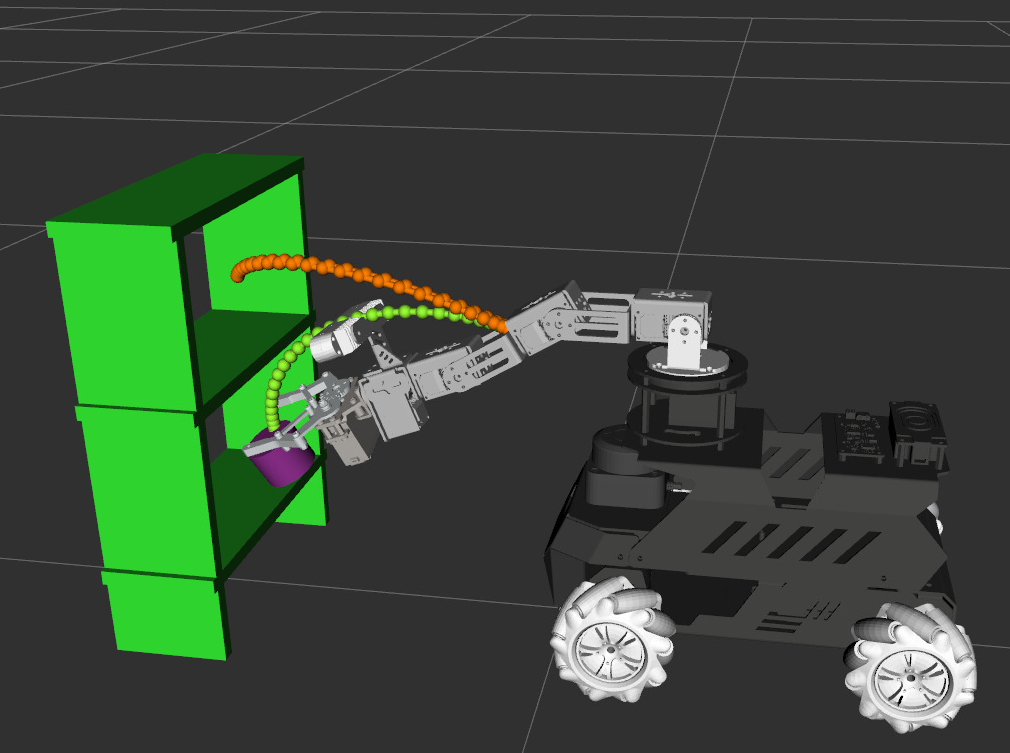
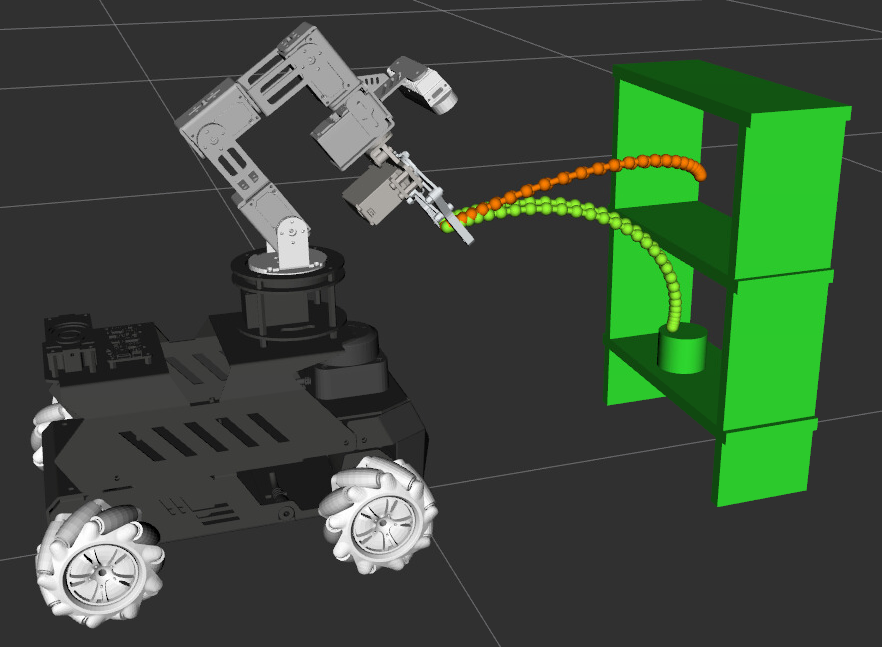
This course implements a virtual scene: a three-layer shelf is built, and after the robot arm grasps a cylindrical object, it plans to the middle upper and lower layers to simulate the action of placing the object, while avoiding the shelf obstacles.
2. Preparation
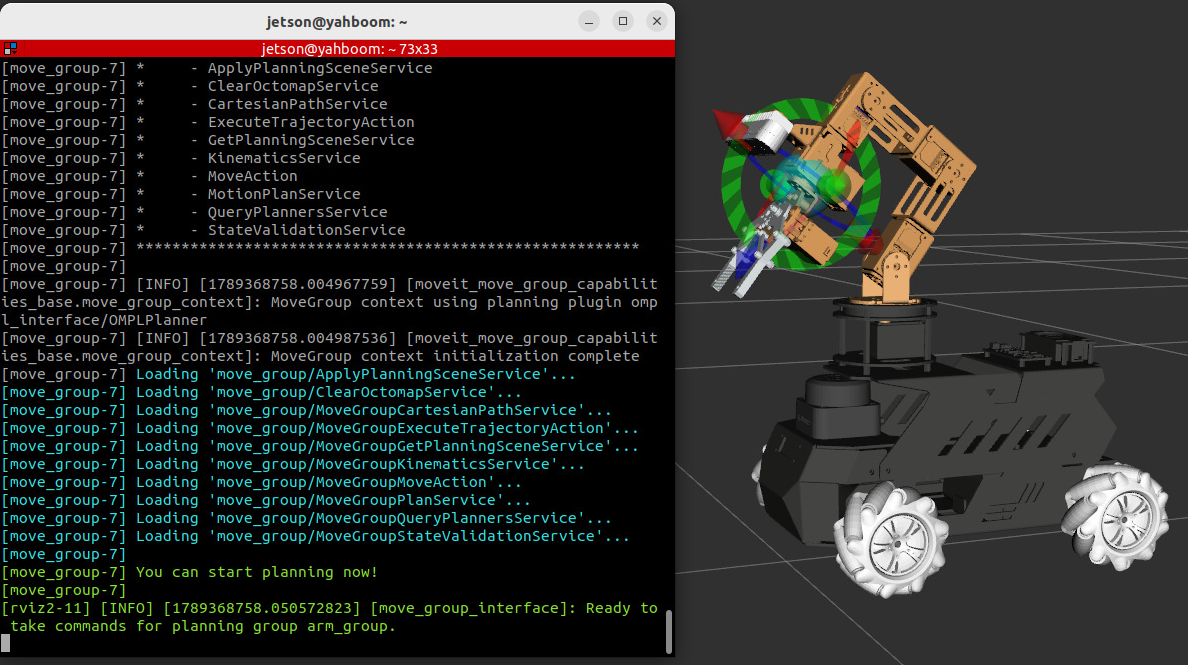
ros2 launch yahboomcar_bringup moveit_simulation.launch.py sim2real:=true rviz_config:=demoOnce the program starts, when You can start planning now! appears in the terminal, it means the startup was successful, as shown in the figure below:
3. Case Demonstration
xxxxxxxxxxros2 run moveit_demo set_scene
After the program runs, the robot arm will plan to the set init pose, then a purple cylindrical object will be added to the gripper. Next, it starts planning and executing the simulated action of placing the object between the middle two layers: first grasp the cylinder from the upper shelf, then the robot arm returns to the initial position -> plans a trajectory to move to the lower shelf to place the object -> finally the robot arm returns to the initial pose.
4. Core Source Code Analysis
Source code path
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/moveit_demo/src/set_scene.cpp
Loading the scene file and adding the cylinder:
ament_index_cpp::get_package_share_directory("moveit_demo"): Gets the installation path of the moveit_demo package.loadSceneFile(scene_path): Loads the shape.scene scene file and parses out the collision object list.Position adaptation: Maps the x coordinate in the scene model to
pose.position.x = 0.26,pose.position.y = -old_x, adjusting the scene model to the front of the robot.Orientation adaptation: Rotates the orientation of the scene model by 90° (about the Z axis) through quaternion multiplication, aligning it with the robot coordinate frame.
addCollisionObjects(scene_objects): Adds all collision objects in the scene to the planning scene.Cylinder pre-placement: Adds a cylinder with a height of 0.03 m and a radius of 0.02 m at the middle shelf position (0.24, 0.0, 0.22).
applyCollisionObject(cylinder_pre): Applies the cylinder collision object to the scene.
Allowed Collision Matrix (ACM) configuration:
create_publisher<PlanningScene>("/planning_scene", 10): Creates a planning scene publisher, used to send ACM updates.getLinkModelNames(): Gets the names of all links of the robot.gripper_links = {"llink2", "rlink2", "arm5_Link"}: The gripper link list, used to re-enable collision detection with base_link.shelf_exempt = {"llink2", "rlink2"}: The links exempted from collision detection with the shelf, allowing the gripper to touch the shelf edges.shelf_ids = {"Box_0"..."Box_4"}: The list of shelf collision object IDs.entry_names: Builds the ACM entry name list, including robot links + cylinder + shelf collision objects.allowed_collision_matrix.entry_values[i].enabled[j] = false: Sets that collision between the two objects is allowed (collision detection is ignored).Between robot links: disables self-collision, but re-enables collision detection between the gripper and base_link.
Between the shelf and the gripper: collision between llink2/rlink2 and the shelf is allowed (exempted), and collision detection between other links and the shelf is disabled.
Execution flow:
Step 1: Move to the init initial pose.
Step 2: Move to the middle shelf position through a joint-space target, specifying each joint angle (radians).
Step 4:
attachObject("cylinder", "gripper_tcp", touch_links): Attaches the cylinder to the gripper; touch_links specifies the links allowed to make contact.Step 4.5: Retreat to the init pose to prepare for the lower shelf motion.
Step 5: Move to the lower shelf position through a joint-space target.
Step 6: Place the cylinder — first remove it from the scene, then re-add it at the lower shelf position (0.24, 0.0, 0.09).
removeCollisionObjects(to_remove): Removes the cylinder from the scene.detachObject("cylinder"): Releases the attachment relationship between the cylinder and the gripper.applyCollisionObject(cyl_placed): Re-adds the cylinder at the lower shelf position.Step 7: Move to the init pose; the task is complete.
x void initialize() { move_group_interface_ = std::make_shared<moveit::planning_interface::MoveGroupInterface>( shared_from_this(), "arm_group"); planning_scene_interface_ = std::make_shared<moveit::planning_interface::PlanningSceneInterface>();
move_group_interface_->setNumPlanningAttempts(30); move_group_interface_->setPlanningTime(20.0); move_group_interface_->setGoalPositionTolerance(0.02); move_group_interface_->setGoalJointTolerance(0.05); // wider goal region for joint-space plans move_group_interface_->setWorkspace(-0.1, -0.4, -0.05, 0.5, 0.4, 0.7); move_group_interface_->setMaxVelocityScalingFactor(1.0); move_group_interface_->setMaxAccelerationScalingFactor(1.0); move_group_interface_->setEndEffectorLink("gripper_tcp"); move_group_interface_->setPoseReferenceFrame("measure");
const moveit::core::JointModelGroup* joint_model_group = move_group_interface_->getRobotModel()->getJointModelGroup("arm_group"); visual_tools_ = std::make_shared<moveit_visual_tools::MoveItVisualTools>( shared_from_this(), "measure", "set_scene", move_group_interface_->getRobotModel()); visual_tools_->deleteAllMarkers(); visual_tools_->loadRemoteControl();
// Load shape.scene and cylinder try { std::string scene_path = ament_index_cpp::get_package_share_directory("moveit_demo") + "/scene/shape.scene"; RCLCPP_INFO(this->get_logger(), "Loading scene file: %s", scene_path.c_str()); std::vector<moveit_msgs::msg::CollisionObject> scene_objects = loadSceneFile(scene_path); for (auto& obj : scene_objects) { for (auto& pose : obj.primitive_poses) { //Special operations, adapted to scene models double old_x = pose.position.x; pose.position.x = 0.26; pose.position.y = -old_x;
double qr_x = 0.0, qr_y = 0.0, qr_z = -0.70710678, qr_w = 0.70710678; double qo_x = pose.orientation.x; double qo_y = pose.orientation.y; double qo_z = pose.orientation.z; double qo_w = pose.orientation.w; pose.orientation.x = qr_w * qo_x + qr_x * qo_w + qr_y * qo_z - qr_z * qo_y; pose.orientation.y = qr_w * qo_y - qr_x * qo_z + qr_y * qo_w + qr_z * qo_x; pose.orientation.z = qr_w * qo_z + qr_x * qo_y - qr_y * qo_x + qr_z * qo_w; pose.orientation.w = qr_w * qo_w - qr_x * qo_x - qr_y * qo_y - qr_z * qo_z; } }
planning_scene_interface_->addCollisionObjects(scene_objects);
// Pre-place cylinder at middle shelf { moveit_msgs::msg::CollisionObject cylinder_pre; cylinder_pre.id = "cylinder"; cylinder_pre.header.frame_id = "measure"; cylinder_pre.operation = cylinder_pre.ADD; shape_msgs::msg::SolidPrimitive cyl_prim; cyl_prim.type = cyl_prim.CYLINDER; cyl_prim.dimensions.resize(2); cyl_prim.dimensions[cyl_prim.CYLINDER_HEIGHT] = 0.03; cyl_prim.dimensions[cyl_prim.CYLINDER_RADIUS] = 0.02;
geometry_msgs::msg::Pose cyl_pose; cyl_pose.orientation.w = 1.0; cyl_pose.position.x = 0.24; cyl_pose.position.y = 0.0; cyl_pose.position.z = 0.22; cylinder_pre.primitives.push_back(cyl_prim); cylinder_pre.primitive_poses.push_back(cyl_pose); planning_scene_interface_->applyCollisionObject(cylinder_pre); } } catch (const std::exception& e) { RCLCPP_ERROR(this->get_logger(), "Failed to load scene file: %s", e.what()); } // Disable robot self-collision. Only re-enable gripper ↔ base_link // Also exempt llink2/rlink2 ↔ shelf so gripper fingers can touch shelf edges. { auto acm_pub = this->create_publisher<moveit_msgs::msg::PlanningScene>( "/planning_scene", 10); rclcpp::sleep_for(std::chrono::milliseconds(300));
const auto& links = move_group_interface_->getRobotModel()->getLinkModelNames(); const size_t robot_n = links.size();
// Gripper links checked against base_link const std::vector<std::string> gripper_links = { "llink2", "rlink2", "arm5_Link"};
// Gripper links exempted from shelf collision const std::vector<std::string> shelf_exempt = {"llink2", "rlink2"};
const std::vector<std::string> shelf_ids = { "Box_0", "Box_1", "Box_2", "Box_3", "Box_4"};
// Build entry list: robot links + cylinder + shelf boxes std::vector<std::string> entry_names = links; entry_names.push_back("cylinder"); const size_t cyl_idx = entry_names.size() - 1; for (const auto& sid : shelf_ids) entry_names.push_back(sid); const size_t total = entry_names.size();
// Build name → index map std::map<std::string, size_t> name_to_idx; for (size_t i = 0; i < total; i++) name_to_idx[entry_names[i]] = i;
auto it_base = name_to_idx.find("base_link"); const size_t base_idx = (it_base != name_to_idx.end()) ? it_base->second : 0;
moveit_msgs::msg::PlanningScene ps_msg; ps_msg.is_diff = true; ps_msg.allowed_collision_matrix.entry_names = entry_names; ps_msg.allowed_collision_matrix.entry_values.resize(total);
// --- Row 0..robot_n-1 (robot links) --- for (size_t i = 0; i < robot_n; i++) { auto& row = ps_msg.allowed_collision_matrix.entry_values[i]; row.enabled.resize(total, true); // Check robot ↔ shelf (except exempt links) bool is_exempt = false; for (const auto& ename : shelf_exempt) if (entry_names[i] == ename) { is_exempt = true; break; } if (!is_exempt) { for (const auto& sid : shelf_ids) { auto it = name_to_idx.find(sid); if (it != name_to_idx.end()) row.enabled[it->second] = false; } } }
// --- Cylinder row --- { auto& row = ps_msg.allowed_collision_matrix.entry_values[cyl_idx]; row.enabled.resize(total, true); }
// --- Shelf rows --- for (const auto& sid : shelf_ids) { auto it_s = name_to_idx.find(sid); if (it_s == name_to_idx.end()) continue; auto& row = ps_msg.allowed_collision_matrix.entry_values[it_s->second]; row.enabled.resize(total, false); for (const auto& ename : shelf_exempt) { auto it_e = name_to_idx.find(ename); if (it_e != name_to_idx.end()) row.enabled[it_e->second] = true; } }
// Re-enable gripper ↔ base_link (both directions) for (const auto& gname : gripper_links) { auto it = name_to_idx.find(gname); if (it == name_to_idx.end()) continue; size_t gi = it->second; ps_msg.allowed_collision_matrix.entry_values[gi].enabled[base_idx] = false; ps_msg.allowed_collision_matrix.entry_values[base_idx].enabled[gi] = false; }
acm_pub->publish(ps_msg); rclcpp::sleep_for(std::chrono::milliseconds(500)); RCLCPP_INFO(this->get_logger(), "ACM: self-collision OFF, gripper↔base ON, llink2/rlink2↔shelf OFF. " "(%zu links + %zu shelf)", robot_n, shelf_ids.size()); }
// shelf pick-and-place const int max_attempts = 5; const double SHELF_X = 0.24; const double MIDDLE_Z = 0.23; const double LOWER_Z = 0.09; auto exec_named = [&](const std::string& desc, const std::string& target, bool show_trajectory = true, rviz_visual_tools::Colors color = rviz_visual_tools::LIME_GREEN) { RCLCPP_INFO(this->get_logger(), "=== %s: named target '%s' ===", desc.c_str(), target.c_str()); for (int a = 1; a <= max_attempts; a++) { move_group_interface_->setNamedTarget(target); moveit::planning_interface::MoveGroupInterface::Plan plan; if (move_group_interface_->plan(plan) == moveit::core::MoveItErrorCode::SUCCESS) { if (show_trajectory) { visual_tools_->publishTrajectoryLine(plan.trajectory_, move_group_interface_->getRobotModel()->getLinkModel("gripper_tcp"), joint_model_group, color); visual_tools_->trigger(); } move_group_interface_->execute(plan); return true; } RCLCPP_WARN(this->get_logger(), "%s attempt %d/%d failed", desc.c_str(), a, max_attempts); } RCLCPP_ERROR(this->get_logger(), "%s failed!", desc.c_str()); return false; };
auto exec_position = [&](const std::string& desc, double x, double y, double z, rviz_visual_tools::Colors color = rviz_visual_tools::BLUE) { RCLCPP_INFO(this->get_logger(), "=== %s: position (%.3f, %.3f, %.3f) ===", desc.c_str(), x, y, z); for (int a = 1; a <= max_attempts; a++) { move_group_interface_->setStartStateToCurrentState(); move_group_interface_->setPositionTarget(x, y, z); moveit::planning_interface::MoveGroupInterface::Plan plan; if (move_group_interface_->plan(plan) == moveit::core::MoveItErrorCode::SUCCESS) { visual_tools_->publishTrajectoryLine(plan.trajectory_, move_group_interface_->getRobotModel()->getLinkModel("gripper_tcp"), joint_model_group, color); visual_tools_->trigger(); move_group_interface_->execute(plan); return true; } RCLCPP_WARN(this->get_logger(), "%s attempt %d/%d failed", desc.c_str(), a, max_attempts); rclcpp::sleep_for(std::chrono::milliseconds(200)); } RCLCPP_ERROR(this->get_logger(), "%s failed!", desc.c_str()); return false; };
// Move to init pose if (!exec_named("Step 1: init pose", "init", false)) { RCLCPP_ERROR(this->get_logger(), "Aborting: init pose failed."); rclcpp::shutdown(); return; }
// --- 4b. Move to middle shelf via joint-space target (orange) --- { RCLCPP_INFO(this->get_logger(), "=== Step 2: approach middle shelf via joint target ===");
std::map<std::string, double> middle_joints; middle_joints["arm1"] = 1.5825; middle_joints["arm2"] = 0.2489; middle_joints["arm3"] = 0.9974; middle_joints["arm4"] = 1.9240; middle_joints["arm5"] = 1.57;
bool ok = false; for (int a = 1; a <= max_attempts; a++) { move_group_interface_->setStartStateToCurrentState(); move_group_interface_->setJointValueTarget(middle_joints); moveit::planning_interface::MoveGroupInterface::Plan plan; if (move_group_interface_->plan(plan) == moveit::core::MoveItErrorCode::SUCCESS) { visual_tools_->publishTrajectoryLine(plan.trajectory_, move_group_interface_->getRobotModel()->getLinkModel("gripper_tcp"), joint_model_group, rviz_visual_tools::ORANGE); visual_tools_->trigger(); move_group_interface_->execute(plan); ok = true; break; } RCLCPP_WARN(this->get_logger(), "Step 2 attempt %d/%d failed", a, max_attempts); rclcpp::sleep_for(std::chrono::milliseconds(500)); }
if (!ok) { RCLCPP_ERROR(this->get_logger(), "Aborting: middle shelf approach failed."); rclcpp::shutdown(); return; } }
// Attach cylinder at middle shelf { RCLCPP_INFO(this->get_logger(), "=== Step 4: attach cylinder from middle shelf ===");
std::vector<std::string> touch_links; touch_links.push_back("llink2"); touch_links.push_back("rlink2"); move_group_interface_->attachObject("cylinder", "gripper_tcp", touch_links);
}
{ RCLCPP_INFO(this->get_logger(), "=== Step 4.5: retreat to init before lower shelf ==="); bool retreated = false; for (int a = 1; a <= max_attempts; a++) { move_group_interface_->setNamedTarget("init"); moveit::planning_interface::MoveGroupInterface::Plan plan; if (move_group_interface_->plan(plan) == moveit::core::MoveItErrorCode::SUCCESS) { visual_tools_->publishTrajectoryLine(plan.trajectory_, move_group_interface_->getRobotModel()->getLinkModel("gripper_tcp"), joint_model_group, rviz_visual_tools::ORANGE); visual_tools_->trigger(); move_group_interface_->execute(plan); retreated = true; break; } RCLCPP_WARN(this->get_logger(), "Retreat to init attempt %d/%d failed", a, max_attempts); rclcpp::sleep_for(std::chrono::milliseconds(200)); } if (!retreated) { RCLCPP_ERROR(this->get_logger(), "Cannot retreat to init, lower shelf plan will likely fail."); } }
// --- 4e. Move to lower shelf via joint-space target --- { RCLCPP_INFO(this->get_logger(), "=== Step 5: approach lower shelf via joint target ===");
std::map<std::string, double> lower_joints; lower_joints["arm1"] = 1.5837; lower_joints["arm2"] = -0.1831; lower_joints["arm3"] = 1.1294; lower_joints["arm4"] = 1.8359; lower_joints["arm5"] = 1.3307;
bool ok = false; for (int a = 1; a <= max_attempts; a++) { move_group_interface_->setStartStateToCurrentState(); move_group_interface_->setJointValueTarget(lower_joints); moveit::planning_interface::MoveGroupInterface::Plan plan; if (move_group_interface_->plan(plan) == moveit::core::MoveItErrorCode::SUCCESS) { visual_tools_->publishTrajectoryLine(plan.trajectory_, move_group_interface_->getRobotModel()->getLinkModel("gripper_tcp"), joint_model_group, rviz_visual_tools::LIME_GREEN); visual_tools_->trigger(); move_group_interface_->execute(plan); ok = true; break; } RCLCPP_WARN(this->get_logger(), "Step 5 attempt %d/%d failed", a, max_attempts); rclcpp::sleep_for(std::chrono::milliseconds(500)); }
if (!ok) { RCLCPP_WARN(this->get_logger(), "Lower shelf joint target failed, will still try to place cylinder."); } }
// --- 4f. Place cylinder at lower shelf (detach, reset to upright) --- { RCLCPP_INFO(this->get_logger(), "=== Step 6: place cylinder at lower shelf ===");
std::vector<std::string> to_remove = {"cylinder"}; planning_scene_interface_->removeCollisionObjects(to_remove); rclcpp::sleep_for(std::chrono::milliseconds(200));
move_group_interface_->detachObject("cylinder");
// Now add a fresh vertical cylinder at lower shelf moveit_msgs::msg::CollisionObject cyl_placed; cyl_placed.id = "cylinder"; cyl_placed.header.frame_id = "measure"; cyl_placed.operation = cyl_placed.ADD;
shape_msgs::msg::SolidPrimitive cyl_prim; cyl_prim.type = cyl_prim.CYLINDER; cyl_prim.dimensions.resize(2); cyl_prim.dimensions[cyl_prim.CYLINDER_HEIGHT] = 0.03; cyl_prim.dimensions[cyl_prim.CYLINDER_RADIUS] = 0.02;
geometry_msgs::msg::Pose cyl_pose; cyl_pose.orientation.w = 1.0; cyl_pose.position.x = SHELF_X; cyl_pose.position.y = 0.0; cyl_pose.position.z = 0.09; // bottom shelf (z=0.06) + half height
cyl_placed.primitives.push_back(cyl_prim); cyl_placed.primitive_poses.push_back(cyl_pose); planning_scene_interface_->applyCollisionObject(cyl_placed);
}
// Return to init pose exec_named("Step 7: return to init", "init");
rclcpp::shutdown(); }