Welcome to ROSMASTER M1 PRO repository
5.Path Re-planning
Path Replanning
Path Replanning1. Course Content2. Preparation3. Path Replanning Case Demonstration4. Source Code Analysis5. Parameter Debugging
1. Course Content
Basic
Start the road network navigation feature, and master using the roadnet_nav visualization panel to send a goal waypoint ID. Place an obstacle on the navigation path to block the current edge, and the robot will roll back to the last safe waypoint it passed and replan a traversable path to reach the goal waypoint.
Advanced
Understand the implementation logic of the program source code
Master the parameter file configuration, being able to turn the path replanning feature off and on and to adjust the collision detection distance
2. Preparation
ros2 launch yahboomcar_bringup roadnet_nav.launch.py
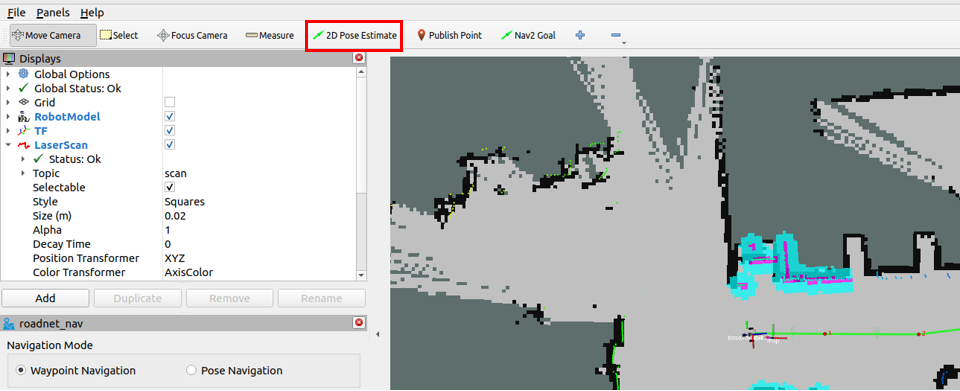
Click 2D Pose Estimate to initialize the robot's pose on the map
3. Path Replanning Case Demonstration
Here we take waypoint-to-waypoint navigation as an example: navigate from waypoint 3 to waypoint 5 through the road network, and place an obstacle in advance on the road in between.
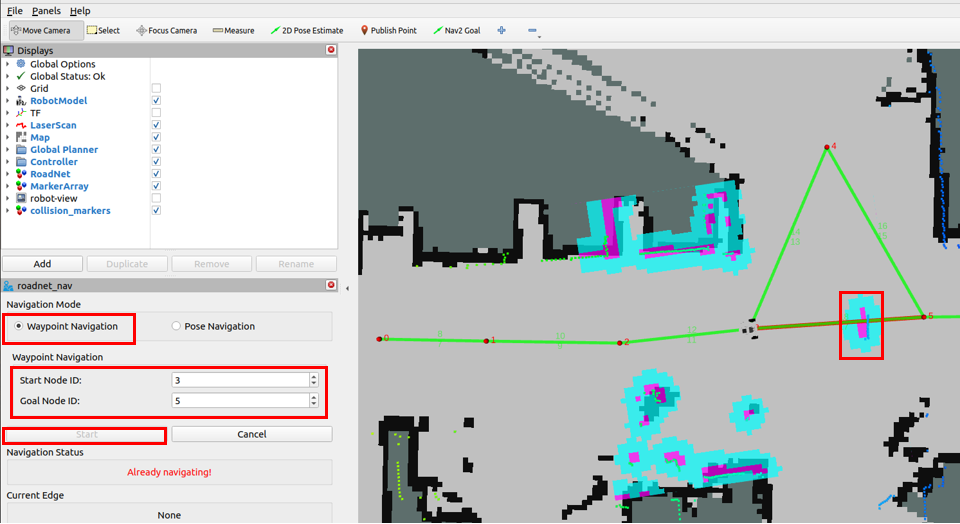
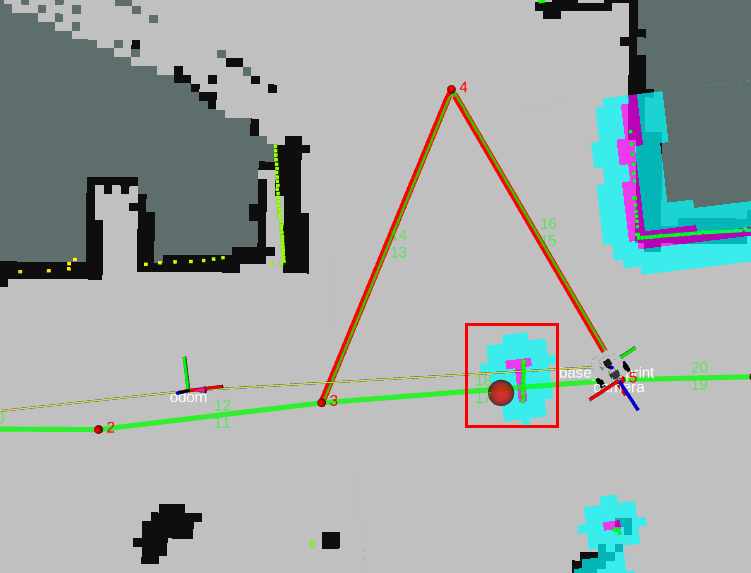
When an obstacle is detected within 0.5 meters in front of base_link, path replanning is triggered, and another route 3→4→5 is chosen to reach the goal waypoint.
The obstacle is displayed and marked on the map as a red sphere.
4. Source Code Analysis
Source code path of the implementation program:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/roadnet/src/route_server.cpp
Obtain the Action goal request
goal, and initialize the result, feedback, and replanning state objectsOuter loop (replanning loop):
Validate the legitimacy of the request, check whether a new goal has preempted it, and clear residual costs in the global costmap
Call
findRouteto compute a feasible path in the road network, and calldensifyto densify the pathWait for the
FollowPathAction server to be ready, send the dense path, and begin tracking
Inner loop (20 Hz path tracking):
Check for cancel/preempt requests, and check whether
FollowPathhas completedObtain the robot's current pose via TF, and compute the distance to the next waypoint
When the distance <
radius_threshold, determine that the waypoint has been reached and switch to the next edgeCall
OperationsManagerto perform obstacle detection and replanning judgmentWhen a collision is detected, cancel the current
FollowPath, setneed_rerouteto break out of the inner loop, and the outer loop replans the path
x void RouteServer::computeRouteAndFollow() { RCLCPP_INFO(get_logger(), "Computing route and following path to goal.");
auto goal = compute_route_and_follow_server_->get_current_goal(); auto result = std::make_shared<RoadNetToGoalResult>(); auto feedback = std::make_shared<RoadNetToGoalFeedback>(); ReroutingState rerouting_info; auto start_time = this->now();
try { Route route; nav_msgs::msg::Path path; // Reroute trigger conditions: (obstacle detection) or a request to the rerouting service (ReroutingService) while (rclcpp::ok()) { if (!isRequestValid(compute_route_and_follow_server_)) { return; } // Check whether a new goal has preempted the current one if (compute_route_and_follow_server_->is_preempt_requested()) { RCLCPP_INFO(get_logger(), "A new request is received, and the target of the original request is preempted"); goal = compute_route_and_follow_server_->accept_pending_goal(); rerouting_info.reset(); } // Clear residual costs in global_costmap before planning to avoid affecting planning clearGlobalCostmap();
// Compute a feasible route in the road network route = findRoute(goal, rerouting_info); RCLCPP_INFO(get_logger(), "Route found with %zu nodes and %zu edges", route.edges.size() + 1u, route.edges.size()); path = path_converter_->densify(route, rerouting_info, route_frame_, this->now());
// Print the path std::string route_str; if (route.start_node) { route_str = std::to_string(route.start_node->nodeid); } for (const auto &edge : route.edges) { route_str += " --------->> " + std::to_string(edge->end->nodeid); } RCLCPP_INFO(get_logger(), "Find route plan: %s", route_str.c_str());
// Wait for FollowPath action server if (!follow_path_client_->wait_for_action_server(std::chrono::seconds(5))) { RCLCPP_ERROR(get_logger(), "FollowPath action server not available!"); result->error_code = RoadNetToGoalResult::UNKNOWN; result->error_msg = "FollowPath action server not available"; compute_route_and_follow_server_->terminate_current(result); return; } // Send the path to FollowPath auto follow_goal = FollowPath::Goal(); follow_goal.path = path;
auto send_goal_options = rclcpp_action::Client<FollowPath>::SendGoalOptions(); auto goal_handle_future = follow_path_client_->async_send_goal(follow_goal, send_goal_options);
// Wait for goal acceptance if (goal_handle_future.wait_for(std::chrono::seconds(5)) != std::future_status::ready) { RCLCPP_ERROR(get_logger(), "FollowPath goal send timed out!"); result->error_code = RoadNetToGoalResult::UNKNOWN; result->error_msg = "FollowPath goal send timed out"; compute_route_and_follow_server_->terminate_current(result); return; }
auto follow_goal_handle = goal_handle_future.get(); if (!follow_goal_handle) { RCLCPP_ERROR(get_logger(), "FollowPath goal was rejected!"); result->error_code = RoadNetToGoalResult::UNKNOWN; result->error_msg = "FollowPath goal rejected by controller"; compute_route_and_follow_server_->terminate_current(result); return; } RCLCPP_DEBUG(get_logger(), "FollowPath goal accepted, robot is moving!");
// Get result future for polling auto follow_result_future = follow_path_client_->async_get_result(follow_goal_handle);
// Track path progress and detect obstacles double radius_threshold = 2.0; nav2_util::declare_parameter_if_not_declared( shared_from_this(), "radius_to_achieve_node", rclcpp::ParameterValue(radius_threshold)); radius_threshold = get_parameter("radius_to_achieve_node").as_double();
EdgePtr current_edge = nullptr; NodePtr next_node = nullptr; int edge_idx = -1; RouteTrackingState tracking_state; tracking_state.last_node = route.start_node; tracking_state.next_node = route.start_node;
// Advance to first edge if (!route.edges.empty()) { edge_idx = 0; current_edge = route.edges[0]; next_node = current_edge->end; tracking_state.current_edge = current_edge; RCLCPP_INFO(get_logger(), "Entering edge:%u id:%u ---------------------> id:%u", current_edge->edgeid, current_edge->start->nodeid, current_edge->end->nodeid); } rclcpp::Rate rate(20.0); bool follow_completed = false; bool route_tracking_done = route.edges.empty(); bool need_reroute = false;
while (rclcpp::ok() && !follow_completed && !need_reroute) { // Check if our action was cancelled if (compute_route_and_follow_server_->is_cancel_requested()) { RCLCPP_INFO(get_logger(), "Goal cancelled, cancelling FollowPath..."); follow_path_client_->async_cancel_goal(follow_goal_handle); compute_route_and_follow_server_->terminate_all(); return; } // Check if preempted by a new goal if (compute_route_and_follow_server_->is_preempt_requested()) { RCLCPP_INFO(get_logger(), "Goal preempted, cancelling FollowPath..."); follow_path_client_->async_cancel_goal(follow_goal_handle); break; }........
5. Parameter Debugging
Road network navigation parameter file path:
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_bringup/param/roadnet_nav.yaml
Enable/disable the replanning feature: modify the
operationslistoperations: ["ReroutingService", "CollisionMonitor"]: enable both the external rerouting service and collision-detection replanning (default)operations: ["ReroutingService"]: enable only the external rerouting service, disable collision detection; during navigation there is no automatic obstacle avoidance or replanningoperations: []: disable everything; no replanning is triggered
Adjust the collision detection distance: modify
max_collision_distunderCollisionMonitor. The unit is meters, representing the maximum distance in front of base_link for detecting obstacles; the smaller the value, the closer the detection rangeAdjust the node achievement radius:
radius_to_achieve_node: the achievement judgment radius for intermediate path nodes; when the robot's distance to the waypoint is smaller than this value, it is judged to be reachedboundary_radius_to_achieve_node: the achievement judgment radius for the start/goal points
Other CollisionMonitor parameters:
rate: collision detection frequency (Hz); the higher the value, the more timely the detection but the greater the CPU usagereroute_on_collision: whether to trigger replanning when a collision is detectedmax_cost: maximum allowed cost value; areas exceeding this value are treated as obstaclescheck_resolution: check resolution; 1 means checking cell by cell
xxxxxxxxxxroute_server ros__parameters # Path generation route_frame"map" path_density0.05
tracker_update_rate3.0 aggregate_blocked_idsfalse boundary_radius_to_achieve_node0.3 # Achievement radius threshold for the path (start / goal) radius_to_achieve_node0.35 # Achievement radius threshold for intermediate path nodes (non-start / non-goal) # Nearest neighbor search enable_nn_searchfalse # Whether to enable a breadth-first search based on the costmap to find the nearest node (when off, only the waypoint with the smallest Euclidean distance is used; when on, collisions along the path are taken into account) max_nn_search_iterations10000 num_nearest_nodes5 # Number of nearest neighbor nodes found using the KD tree
smooth_cornersfalse # Whether to enable corner smoothing #smoothing_radius: 0.2 #smoothing_angle_threshold: 2.96 # Angle smoothing threshold
# Path pruning max_prune_dist_from_edge8.0 min_prune_dist_from_goal0.15 min_prune_dist_from_start0.10 prune_goaltrue
# Rerouting service operations"ReroutingService" "CollisionMonitor" # operations: ["ReroutingService"] ReroutingService plugin"roadnet::ReroutingService" CollisionMonitor plugin"roadnet::CollisionMonitor" costmap_topic"global_costmap/costmap_raw" # Do not modify rate1.0 # Check frequency (Hz) reroute_on_collisiontrue # Trigger replanning when a collision is detected max_cost253.0 # Maximum allowed cost check_resolution2 # Check resolution (1 = every cell) max_collision_dist0.5 # Maximum check distance (meters)
# Edge cost functions # edge_cost_functions: ["CostmapScorer","DynamicEdgesScorer"] edge_cost_functions"DynamicEdgesScorer" CostmapScorer plugin"roadnet::CostmapScorer" # Costmap scorer use_maximumfalse # Use average cost instead of maximum cost invalid_on_collisiontrue # Allow colliding edges, but compute a high cost invalid_off_mapfalse # Do not mark as invalid when outside the costmap max_cost253.0 # Maximum valid cost check_resolution4 # Check resolution costmap_topic"global_costmap/costmap_raw" # Costmap topic, do not modify weight1.0 # Weight DynamicEdgesScorer plugin"roadnet::DynamicEdgesScorer"