Welcome to ROSMASTER M1 PRO repository
5.Image Classification
Image Classification
1. Course Content
Use the yolo classification model to classify objects in the camera image and display the confidence.
2. Case Demonstration
ros2 launch yahboomcar_bringup camera_demo.launch.py demo:=yolo_cls
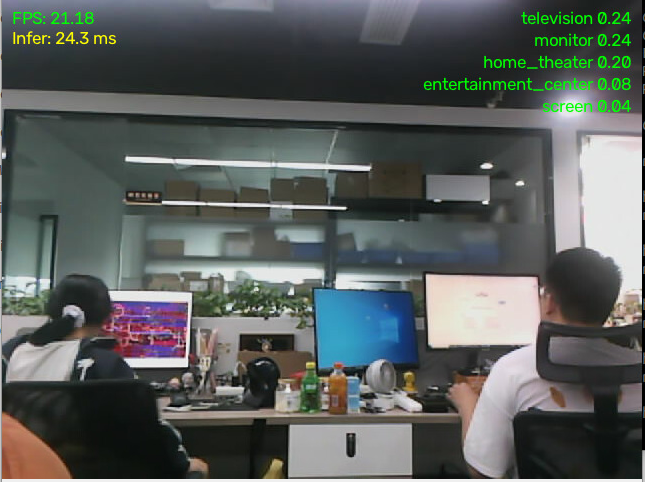
The detection image consists of the following elements:
Original camera image: The image classification mode does not draw bounding boxes; the image is the original camera video stream.
Top-5 classification results in the upper right corner: Displays the 5 class names with the highest predicted confidence and their corresponding confidence (0~1), one per line, shown in green text on the right side of the image.
Upper-left status bar: Green text displays the real-time frame rate FPS, and yellow text displays the single-frame inference time (milliseconds).
3. Source Code Analysis
Source code path
xxxxxxxxxx~/yahboomcar_ros2_ws/yahboomcar_ws/src/common_demo/common_demo/yolo/yolo_cls.py
_init_arm_pose function description:
wait_for_service(timeout_sec=10.0): Waits for the robot arm joint control service to come online; if it times out after 10 seconds, the initial pose setup is skipped.ArmPosition.Request(): Constructs a joint control request, whererequest_jointsis the initial pose angle list.call_async(req): Sends the joint control request asynchronously.add_done_callback(self._init_arm_done_callback): Registers a callback function to check the execution result after the request completes.
get_RGBImageCallBack function description:
imgmsg_to_cv2(rgb_msg, desired_encoding='bgr8'): Converts the ROS Image message into an OpenCV BGR format image.self.yolo_model.predict(rgb_image, stream=True, max_det=self.max_det, verbose=False): Performs YOLO image classification inference on the current frame;stream=Trueenables streaming output to save memory.res.probs: The result object of the classification task, containingtop5(the 5 class IDs with the highest confidence) andtop5conf(the corresponding confidence values).res.plot(probs=False).copy(): Draws the original image (without overlaying YOLO's default probability text);.copy()creates a copy for subsequently overlaying the classification results in a custom way.res.names[int(cls_id)]: Gets the class name string according to the class ID.cv2.getTextSize(text, ...): Calculates the pixel width and height that the text occupies on the image, used to precisely position where the text is drawn.cv2.putText(annotated_frame, text, (img_w - text_w - 10, 25 + i * 22), ...): Draws the Top-5 classification results on the right side of the image, with 22 pixels between lines and right-aligned text.FPS calculation: Counts the number of frames within 1 second to calculate the real-time frame rate.
cv2.imshow(...)/cv2.waitKey(1): Displays the classification image;waitKey(1)refreshes the window.
xclass YOLO_CLS(Node): def __init__(self,name): super().__init__(name) self.declare_parameter('init_pose', [90, 180, 0, 0, 90, 30]) self.init_pose = self.get_parameter('init_pose').get_parameter_value().integer_array_value self.declare_parameter('model_path','') self.model_path = self.get_parameter('model_path').get_parameter_value().string_value self.declare_parameter('max_det', 5) self.max_det = self.get_parameter('max_det').get_parameter_value().integer_value self.set_arm_client = self.create_client(ArmPosition, 'set_arm_joints') self.rgb_bridge = CvBridge() self.msg2img_bridge = CvBridge() self.count=0 self.sub_rgb = self.create_subscription(Image,'camera_rgb_topic',self.get_RGBImageCallBack,1) self.frame_count=0 self.prev_time = time.time() self.frame_count = 0 self.fps = 0.0
self.yolo_model = YOLO(self.model_path, task='classify') self.get_logger().info(Fore.GREEN + 'YOLOV26-Cls Model Loaded.' + Fore.RESET) self._init_arm_pose()
def _init_arm_pose(self): if not self.set_arm_client.wait_for_service(timeout_sec=10.0): self.get_logger().warn("Failed to connect to set_arm_joints server, skipping init arm pose") return req = ArmPosition.Request() req.request_joints = list(self.init_pose) future = self.set_arm_client.call_async(req) future.add_done_callback(self._init_arm_done_callback)
def _init_arm_done_callback(self, future): result = future.result() if not result.success: self.get_logger().warn(f"Init arm pose failed: {list(result.result_joints)}, msg: {result.message}")
def get_RGBImageCallBack(self,rgb_msg): rgb_image = self.rgb_bridge.imgmsg_to_cv2(rgb_msg, desired_encoding='bgr8') infer_start = time.time() results = self.yolo_model.predict(rgb_image, stream=True, max_det=self.max_det, verbose=False) for res in results: if res.probs is not None: annotated_frame = res.plot(probs=False).copy() infer_end = time.time() self.frame_count += 1 curr_time = time.time() time_diff = curr_time - self.prev_time if time_diff >= 1.0: self.fps = self.frame_count / time_diff self.frame_count = 0 self.prev_time = curr_time cv2.putText(annotated_frame,f"FPS: {self.fps:.2f}",(10, 25),cv2.FONT_HERSHEY_SIMPLEX,0.6,(0, 255, 0),1,) infer_time = (infer_end - infer_start) * 1000 cv2.putText(annotated_frame, f"Infer: {infer_time:.1f} ms", (10, 45),cv2.FONT_HERSHEY_SIMPLEX, 0.6, (0, 255, 255), 1)
if res.probs is not None: img_w = annotated_frame.shape[1] for i, (cls_id, conf) in enumerate(zip(res.probs.top5, res.probs.top5conf)): text = f"{res.names[int(cls_id)]} {float(conf):.2f}" (text_w, _), _ = cv2.getTextSize(text, cv2.FONT_HERSHEY_SIMPLEX, 0.6, 1) cv2.putText(annotated_frame, text, (img_w - text_w - 10, 25 + i * 22), cv2.FONT_HERSHEY_SIMPLEX, 0.6, (0, 255, 0), 1)
cv2.imshow("YOLO26-Cls Panel", annotated_frame) cv2.waitKey(1)