Welcome to ROSMASTER A1 PRO repository
16.AprilTag Transport
📦 AprilTag Vision Recognition and Composite Transport (AprilTag Transport)
1. Course Content
Master the high-level composite transport full process integrating Nav2 autonomous navigation, AprilTag machine code visual pose solving, Ackermann chassis dual PID approach fine-tuning, and six-degree-of-freedom robotic arm 3D space inverse kinematics grasping.
Master the robotic arm base servo (0°~180°) step scanning and visual search mechanism tailored for Ackermann vehicle limited field of view.
Master the closed-loop control of autonomous cruising, target recognition, alignment, gripper grasping transport, and return classification unloading.
This case uses 4 * 4 * 4 AprilTag wooden blocks
2. System Architecture and Workflow
This system consists of four major modules: chassis navigation, robotic arm kinematics control, visual solving, and task state scheduling:
Navigate to Operation Area: The robot drives to the target cargo area through Nav2 autonomous obstacle avoidance; after arrival, the buzzer beeps and automatically enters visual detection ready state.
Intelligent Visual Search: Aimed at the Ackermann chassis turning radius limitation, the robotic arm base servo 1 drives the camera to perform step-by-step scanning in the 0°~180° range.
Closed-Loop Approach and Fine-Tuning: After detecting the AprilTag tag code, immediately lock the servo; through dual PID controllers, drive the chassis to fine-tune to the robotic arm's optimal grasping workspace (target distance ~190mm).
Spatial Inverse Kinematics Grasping: Through robotic arm inverse kinematics (IK) solving for six-degree-of-freedom joint target angles, execute lower gripper grasping, smoothly retract, and reset driving posture.
Return to Origin and Classification Unloading: Press the
bkey, the robot automatically plans a route back to the starting origin; after arrival, the robotic arm rotates to the corresponding shelf based on the recognized Tag ID to complete unloading.
3. Preparation and Running
This case requires opening 6~8 terminals in sequence to start each functional node:
3.1 Start Chassis and Lidar
Run in Terminal 1 (start A1 Pro chassis driver and lidar driver):
ros2 launch yahboomcar_nav laser_bringup_launch.py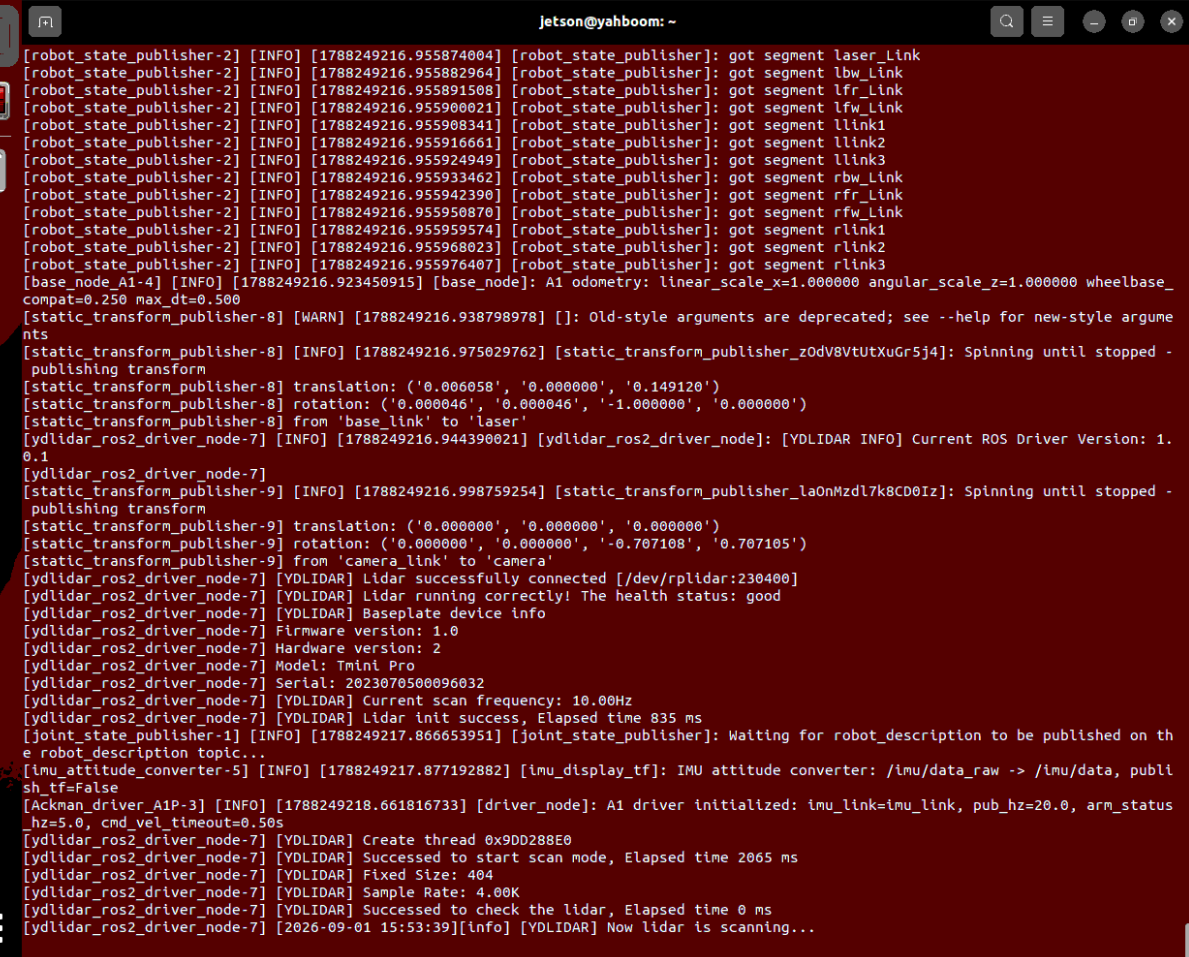
3.2 Start Robotic Arm and Camera Driver
Run in Terminal 2 (start DOFBOT Pro six-degree-of-freedom robotic arm underlying driver, forward/inverse kinematics solving service, and camera):
xxxxxxxxxxros2 launch dofbot_pro_driver camera_arm.launch.py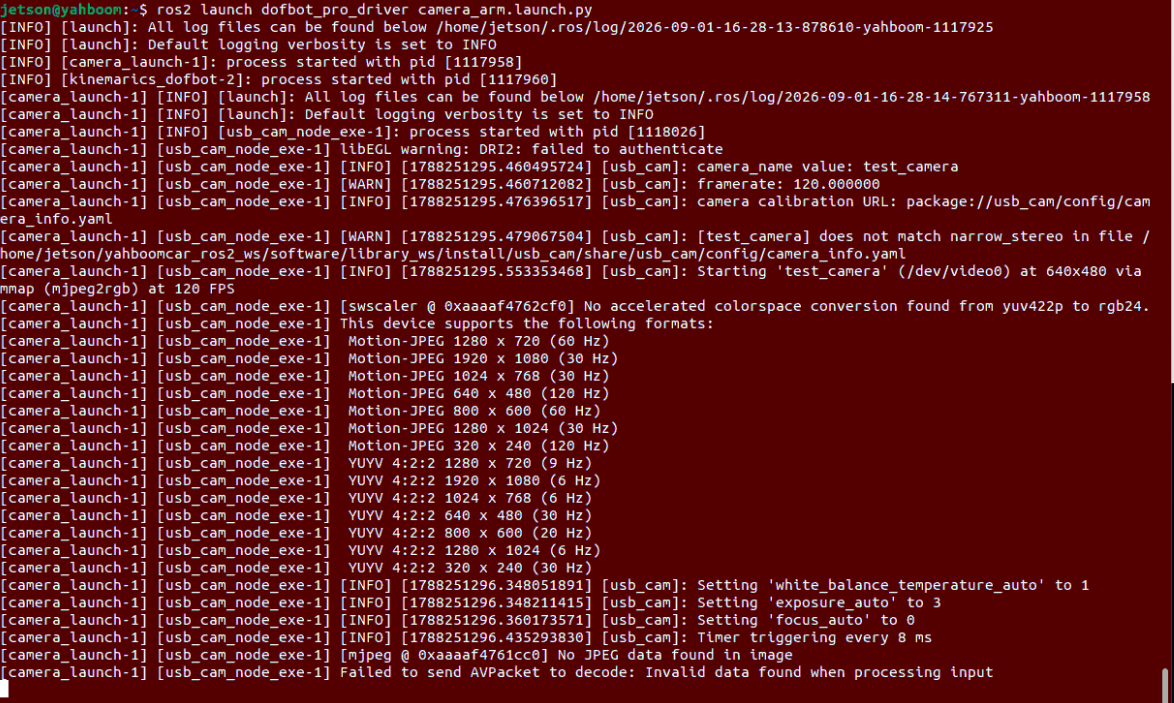
3.3 Start RViz Navigation Visualization
Run in Terminal 3 (it is recommended to open RViz on the virtual machine if the VM and robot are on the same LAN):
xxxxxxxxxxros2 launch yahboomcar_nav display_nav_launch.py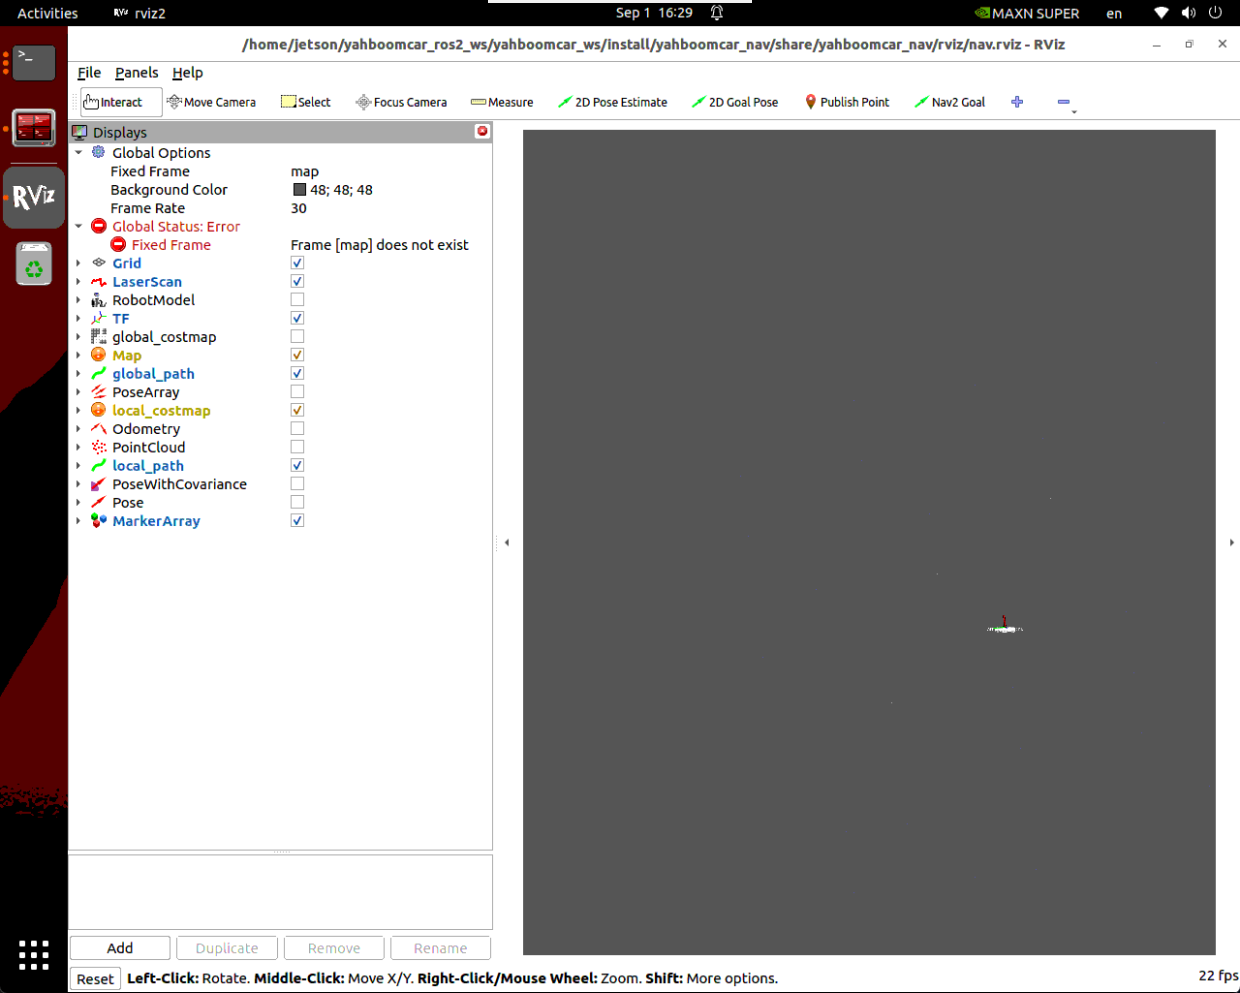
3.4 Start Nav2 Autonomous Navigation Stack
Run in Terminal 4 (start TEB local planner and global path planner):
xxxxxxxxxx# Default start with map.yaml map under yahboomcar_navros2 launch yahboomcar_nav navigation_teb_launch.py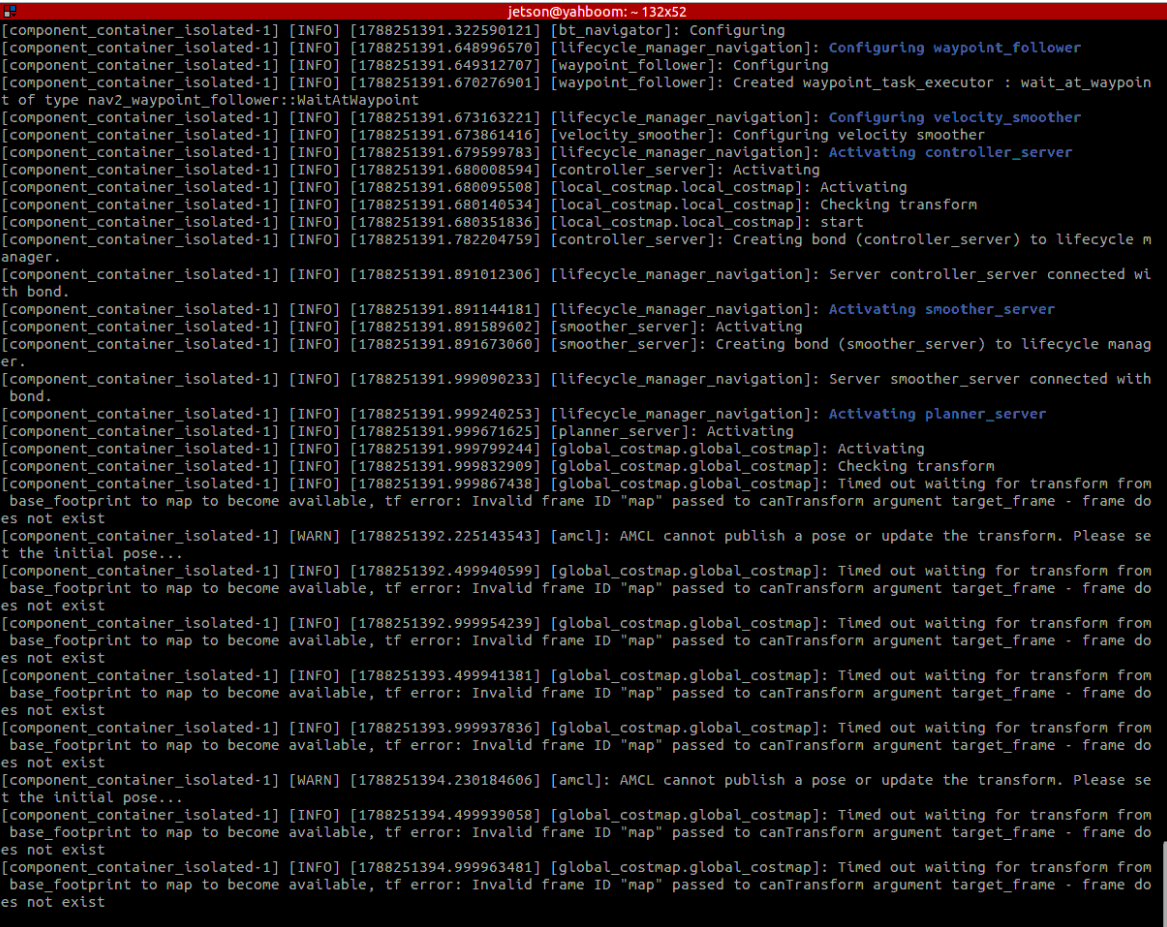
Important
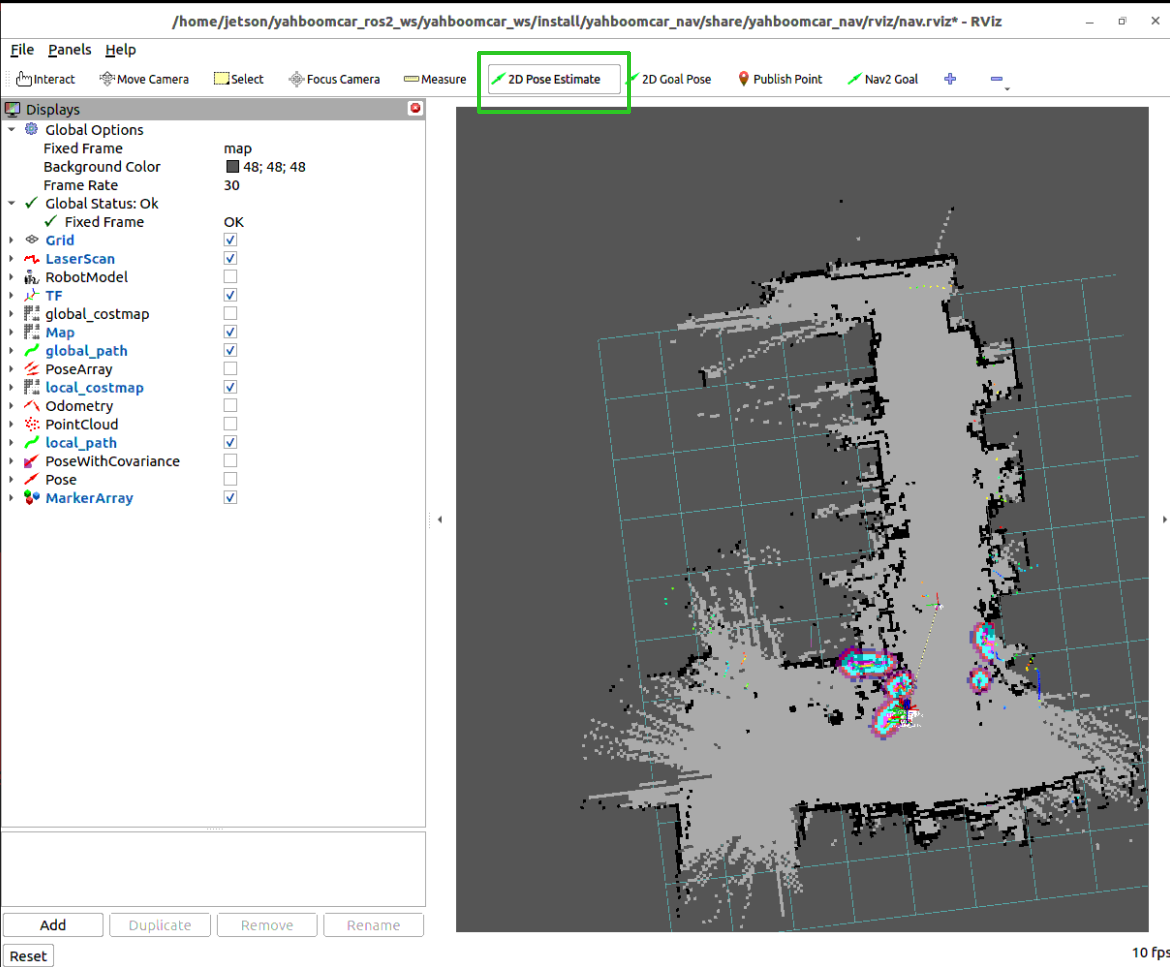
Initial Pose Alignment:
Click the
2D Pose Estimatetool in the top toolbar of RViz2.Click at the actual robot position on the map, hold the mouse, drag the green arrow along the actual chassis heading direction and release.
Observe that the laser point cloud in RViz coincides with the black obstacle boundaries on the map, representing successful initial pose alignment (this position will be automatically recorded by the system as the return origin).
3.5 Start Robotic Arm Grasping Execution Node
Run in Terminal 5 (load spatial inverse kinematics and grasping/unloading action sequence):
x# Depth camera version (Nuwa)ros2 run dofbot_pro_driver grasp_transport
# Or USB camera versionros2 run dofbot_pro_usb grasp_transport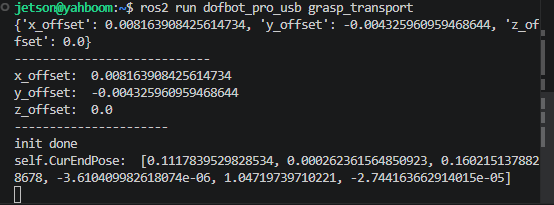
3.6 Start Servo Scanning Search Node (Ackermann Vehicle Dedicated)
Run in Terminal 6 (provide robotic arm base servo 0°~180° step-by-step scanning search):
xxxxxxxxxxros2 run yahboomcar_nav rotation_detect_V2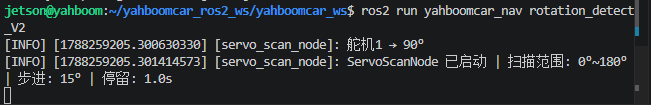
3.7 Start Navigation Status Listener and Scheduling Node
Run in Terminal 7 (monitor arrival status, origin recording, and one-key return control):
xxxxxxxxxxros2 run yahboomcar_nav get_nav2_status_V2
3.8 Start AprilTag Transport Master Control Decision Node
Run in Terminal 8 (visual detection, PID approach fine-tuning, and terminal key interaction):
xxxxxxxxxx# Depth camera version (Nuwa)ros2 run dofbot_pro_driver apriltag_transport_V2
# Or USB camera versionros2 run dofbot_pro_usb apriltag_transport_V2
4. Operation Flow and Key Interaction Description
Initial Origin Calibration: Complete initial pose alignment in RViz using
2D Pose Estimate, andget_nav2_status_V2will automatically save this coordinate as the return baseline origin.Send Target Operation Point: Use the
2D Goal Posetool in RViz to specify the target area where AprilTag machine code wooden blocks are placed on the map. The robot autonomously plans a route and obstacle-avoids to the target point; after arrival, the buzzer beeps once and the terminal prompts ready.Transport Mode Keyboard Control: In the terminal running
apriltag_transport_V2, press the corresponding control key:Key
r(Search, Align, and Grasp):If a tag code already exists in the current camera field of view, the system buzzer beeps, and the chassis immediately starts forward/backward and yaw PID fine-tuning.
If the tag code is not in the current field of view, automatically wake up
rotation_detect_V2to drive robotic arm base servo 1 to step-scan between 0°~180°; once the target is detected, immediately lock the servo.The chassis automatically adjusts posture and distance, approaching to the optimal grasping distance (~190mm).
The robotic arm automatically lowers the gripper according to spatial inverse kinematics, closes the gripper to firmly hold the wooden block, retracts and lifts to safe driving height.
Key
b(One-Key Return and Classification Unloading):The robot automatically calls Nav2 Action to return to the initial origin.
After arriving at the origin, the robotic arm automatically rotates to the corresponding cargo slot angle based on the wooden block's Tag ID (1~4) and lowers the gripper to release and complete unloading.
Key
n(Continue Cruising):If the target is not found at the current point or continuous cruising needs to be executed, send the next goal point in RViz.
Note
When you need to end the program, press Ctrl+C in each terminal window to stop the program.
5. Core Source Code and Key Implementation Mechanism Analysis
5.1 Transport Master Control and Chassis PID Approach (apriltag_transport_V2.py)
Source Code Path:
xxxxxxxxxx$HOME/yahboomcar_ros2_ws/dofbot_pro_ws/src/dofbot_pro_usb/dofbot_pro_usb/apriltag_transport_V2.py
1. Spatial Pose Estimation and Chassis Dual PID Fine-Tuning
The node uses camera intrinsic parameters and AprilTag corners to calculate the target object's distance and yaw error in space, and through linear and angular velocity dual PID control, smoothly approaches the chassis:
xxxxxxxxxxdef _process_tag_tracking(self, tags, result_image, fx, fy, cx0, cy0):    for tag_current in tags:        center_x, center_y = tag_current.center
        # 1. Solve 3D coordinates of tag code in camera coordinate system        cam_coords = self.estimate_tag_camera_coords(tag_current, fx, fy, cx0, cy0)        pose = self.compute_world_pose(cam_coords)        dist_detect = math.sqrt(pose[1] ** 2 + pose[0] ** 2) * 1000.0  # millimeters
        # 2. Arm center reset (when approaching 250~265mm)        if not self.arm_centered and 250.0 < dist_detect < 265.0:            self.pubVel(0, 0, 0)            self.pubSix_Arm(self.init_joints)            self.arm_centered = True
        # 3. Y-axis lateral alignment (correct angular velocity through PID)        if self.y_track:            err_pixel_x = center_x - TARGET_PIXEL_X            if abs(err_pixel_x) > 10:                self.angle_pid.SetPoint = TARGET_PIXEL_X                self.angle_pid.update(center_x)                angular_z = float(self.angle_pid.output)                self.pubVel(0, 0, angular_z)            else:                self.pubVel(0, 0, 0)                self.y_track = False                self.adjust_dist = True
        # 4. X-axis distance approach (target distance TARGET_DIST_MM = 190mm)        if self.adjust_dist:            dist_err = dist_detect - TARGET_DIST_MM            if abs(dist_err) > DIST_THRESHOLD_MM:                self.linearx_pid.SetPoint = TARGET_DIST_MM                self.linearx_pid.update(dist_detect)                linear_x = -float(self.linearx_pid.output)                self.pubVel(linear_x, 0, 0)            else:                # Approach complete, stop chassis and trigger robotic arm inverse kinematics grasping                self.pubVel(0, 0, 0)                self.adjust_dist = False                self.grasp(tag_current.tag_id, pose)
2. Non-Blocking Terminal Keyboard Listening Mechanism
Uses cross-platform independent thread (Linux environment uses termios and select non-canonical mode) to capture terminal keyboard key inputs (r/n/b), and puts key events into a queue processed by ROS 2 timer polling, ensuring immediate response of human-machine interaction and efficient decoupling from the main control loop.
5.2 Servo Step-by-Step Scanning Search Mechanism (rotation_detect_V2.py)
Source Code Path:
xxxxxxxxxx$HOME/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_nav/yahboomcar_nav/rotation_detect_V2.py
Due to Ackermann chassis steering structure limitations, it cannot perform in-place 360° rotation like differential/omni-wheel chassis. This system designs ServoScanNode, which controls the robotic arm base servo 1 to drive the camera for multi-step scanning:
xxxxxxxxxxclass ServoScanNode(Node):    def start_rotate_callback(self, msg):        """Receive scan command, servo gradually rotates from scan_start (0°) to scan_end (180°)"""        self.scanning = True        self.detected = False        self.current_angle = self.scan_start        self.move_servo(self.scan_start)
        # Timed step scanning (each step step_pause = 1.0s)        wait_sec = self.servo_speed / 1000.0 + self.step_pause        self.scan_timer = self.create_timer(wait_sec, self.scan_step_callback)
    def detect_result_callback(self, msg):        """Visual node recognized target, immediately lock scanning ahead of schedule"""        if msg.data and self.scanning:            self.detected = True            self.stop_scan(found=True)
5.3 Robotic Arm Spatial Inverse Kinematics Grasping and Classification Unloading (grasp_transport.py)
Source Code Path:
xxxxxxxxxx$HOME/yahboomcar_ros2_ws/dofbot_pro_ws/src/dofbot_pro_usb/dofbot_pro_usb/grasp_transport.py
3D Inverse Kinematics Solving: Receives material spatial coordinates
(x, y, z)from the visual node, combined with the robotic arm and camera extrinsic calibration transformation matrixEndToCamMatand bias configuration file, calls the underlyingget_kinemaricsinverse solving service to calculate the 6 servo target pulse width angles.Step-by-Step Safe Grasping Trajectory:
Gripper fully opens, robotic arm moves to the material upper transition point.
Smoothly vertically descends to grasping height, closes gripper to clamp the wooden block.
Vertically lifts and retracts to safe driving posture, publishes
/grasp_donesignal.
Multi-Tag Classification Unloading: Based on different
tag_id, preset corresponding unloading joint angle dictionaryTAG_UNLOAD_POSITIONS; after returning to origin, accurately delivers the wooden block to the specified cargo slot.
6. Core Parameter Description
| Parameter Module | Parameter Name | Current Config Value | Core Function and Physical Meaning |
|---|---|---|---|
| Visual Detection | families | tag36h11 | AprilTag dictionary family (extremely strong anti-false-detection ability) |
| Visual Detection | tag_size | 0.025 | AprilTag wooden block tag physical side length (meters) |
| Chassis Approach | TARGET_DIST_MM | 190.0 | Robotic arm optimal grasping longitudinal target distance (millimeters) |
| Chassis Approach | DIST_THRESHOLD_MM | 5.0 | Allowable dead zone tolerance for grasping distance arrival (millimeters) |
| Chassis Approach | TARGET_PIXEL_X | 341 | Image center X pixel coordinate for target alignment |
| Chassis PID | LINEAR_X_PID | (0.5, 0.0, 0.2) | Forward/backward distance approach PID parameters (output linear velocity $v_x$) |
| Chassis PID | ANGLE_PID | (0.5, 0.0, 0.2) | Lateral angle alignment PID parameters (output angular velocity $\omega_z$) |
| Servo Scanning | scan_start / scan_end | 0° / 180° | Robotic arm servo 1 search scanning angle range |
| Servo Scanning | scan_step / step_pause | 15° / 1.0s | Each scanning step length and dwell time for visual detection |
| Offset Calibration | x/y/z_offset | Dynamically loaded | Spatial micro-adjustment compensation of gripper and material grasping geometric center (YAML configuration) |