Welcome to ROSMASTER A1 PRO repository
6.Face Special Effects
Face Special Effects
1. Content Description
This program implements acquiring the color image and using the dlib library to perform face detection, as well as face special effects. This section requires entering commands in the terminal, where the terminal is opened according to the mainboard type. This lesson uses the Raspberry Pi 5 as an example.
For the Raspberry Pi 5 mainboard, you need to open a terminal on the host machine, then enter the command to access the Docker container, and enter the commands mentioned in this lesson inside the terminal after entering the Docker container. For the tutorial on entering the Docker container from the host, please refer to 【Robot Configuration and Operation Guide】, section 【3.Enter Docker (For Raspberry Pi)】 in this product tutorial.
For the Orin and RDK mainboards, simply open a terminal and enter the commands mentioned in this lesson.
2. Program Startup
The Raspberry Pi PI5 controller needs to enter the Docker container first; RDK X5 and Orin controllers do not need to.
To enter the Docker container (for steps, refer to 【Docker Course】 --- 【4. Docker Startup Script】),
All the docker terminals for the commands below need to enter the same Docker container before executing (for steps, refer to 【Docker Course】 --- 【3.Docker Submission and Multi-Terminal Access】)
First, enter the following command in the terminal to start the robot camera and low-level driver environment:
xxxxxxxxxxros2 launch dofbot_pro_driver A1pro_camera_arm.launch.pyNote
This command is the official all-in-one startup script for the A1Pro, which automatically launches the image stream node according to the camera hardware configuration (USB monocular camera or Nuwa 3D depth camera) and loads the low-level drivers. If you only need to start the camera stream separately, you can also run ros2 launch usb_cam camera.launch.py (USB camera) or ros2 launch ascamera hp60c.launch.py (Nuwa camera).
After the camera is started successfully, open another terminal and enter the following command in the terminal to start the face special effects program:
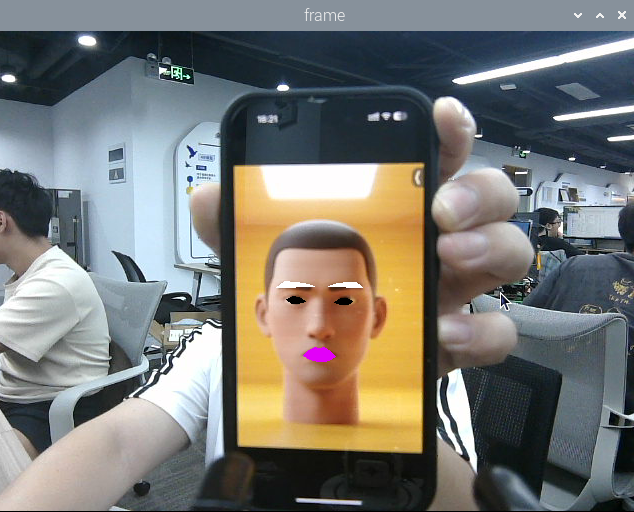
xxxxxxxxxxros2 run yahboomcar_mediapipe 06_FaceLandmarks# Control the robotic arm to look forwardros2 topic pub /arm6_joints dofbot_pro_interface/msg/ArmJoints "{joint1: 90, joint2: 180, joint3: 0, joint4: 0, joint5: 90, joint6: 0, time: 1000}" --onceAfter the program runs, as shown in the figure below, it first detects the face, and then applies special effects to the eyebrow, eye, and mouth regions:
3. Core Code Analysis
Program code path:
Raspberry Pi 5 mainboard
The program code is located in the running Docker. The path in the Docker is
/root/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/06_FaceLandmarks.pyOrin mainboard
The program code path is
/home/jetson/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/06_FaceLandmarks.pyRDK mainboard
The program code path is
/home/sunrise/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/06_FaceLandmarks.py
Import the required library files:
xxxxxxxxxximport timeimport dlibimport osimport cv2 as cvimport numpy as npimport rclpyfrom rclpy.node import Nodefrom sensor_msgs.msg import Imagefrom cv_bridge import CvBridgeimport osIntroduction to the dlib library:
DLIB is a modern C++ toolkit containing machine learning algorithms and tools that can be used to create complex software in C++ to solve real-world problems. It is widely used in industry and academia in fields such as robotics, embedded devices, mobile phones, and large high-performance computing environments. The dlib library uses 68 landmark points to mark important parts of the face; for example, points 18–22 mark the right eyebrow, and points 51–68 mark the mouth. The get_frontal_face_detector module of the dlib library is used to detect faces, and the shape_predictor_68_face_landmarks.dat feature data is used to predict facial feature values.
The 68 face landmarks of dlib are arranged in the following order:
0-16: Jaw contour
17-21: Right eyebrow
22-26: Left eyebrow
27-35: Nose bridge and nose tip
36-41: Right eye
42-47: Left eye
48-67: Lip contour
Initialize the data and define the Publisher and Subscriber:
xdef __init__(self, dat_file): super().__init__('face_landmarks') # Import the database self.dlib_facelandmark = dlib.shape_predictor(dat_file) # Define the face detection object self.hog_face_detector = dlib.get_frontal_face_detector() self.dlib_facelandmark = dlib.shape_predictor(self.dat_file)
self.bridge = CvBridge()
# Define the Subscriber for the color image topic camera_type = os.getenv('CAMERA_TYPE', 'usb') topic_name = '/ascamera_hp60c/camera_publisher/rgb0/image' if camera_type == 'nuwa' else '/usb_cam/image_raw'
self.subscription = self.create_subscription( Image, topic_name, self.image_callback, 10)Color image topic callback function:
xxxxxxxxxxdef image_callback(self, msg): frame = self.bridge.imgmsg_to_cv2(msg, desired_encoding='bgr8') # Pass the obtained image into the defined get_face function and return the detected image frame = self.get_face(rgb_image, draw=False) # Call the prettify_face function to apply special effects to the image frame = self.prettify_face(frame, eye=True, lips=True, eyebrow=True, draw=True) cv.imshow('Face Landmarks', frame)The get_face function for face detection:
xxxxxxxxxxdef get_face(self, frame, draw=True): # Convert the image space from BGR to grayscale for subsequent image processing gray = cv.cvtColor(frame, cv.COLOR_BGR2GRAY) # Pass the grayscale image to detect the face self.faces = self.hog_face_detector(gray) for face in self.faces: self.face_landmarks = self.dlib_facelandmark(gray, face) if draw: for n in range(68): x = self.face_landmarks.part(n).x y = self.face_landmarks.part(n).y cv.circle(frame, (x, y), 2, (0, 255, 255), 2) cv.putText(frame, str(n), (x, y), cv.FONT_HERSHEY_SIMPLEX, 0.6, (0, 255, 255), 2) return frameThe prettify_face function, which applies special effects to the face:
xxxxxxxxxxdef prettify_face(self, frame, eye=True, lips=True, eyebrow=True, draw=True): # Eyes if eye: leftEye = self.get_lmList(frame, 36, 42) rightEye = self.get_lmList(frame, 42, 48) if draw: if len(leftEye) != 0: frame = cv.fillConvexPoly(frame, np.mat(leftEye), (0, 0, 0)) if len(rightEye) != 0: frame = cv.fillConvexPoly(frame, np.mat(rightEye), (0, 0, 0)) # Lips if lips: lipIndexlistA = [51, 52, 53, 54, 64, 63, 62] lipIndexlistB = [48, 49, 50, 51, 62, 61, 60] lipsUpA = self.get_lipList(frame, lipIndexlistA, draw=True) lipsUpB = self.get_lipList(frame, lipIndexlistB, draw=True) lipIndexlistA = [57, 58, 59, 48, 67, 66] lipIndexlistB = [54, 55, 56, 57, 66, 65, 64] lipsDownA = self.get_lipList(frame, lipIndexlistA, draw=True) lipsDownB = self.get_lipList(frame, lipIndexlistB, draw=True) if draw: if len(lipsUpA) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsUpA), (249, 0, 226)) if len(lipsUpB) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsUpB), (249, 0, 226)) if len(lipsDownA) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsDownA), (249, 0, 226)) if len(lipsDownB) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsDownB), (249, 0, 226)) # Eyebrows if eyebrow: lefteyebrow = self.get_lmList(frame, 17, 22) righteyebrow = self.get_lmList(frame, 22, 27) if draw: if len(lefteyebrow) != 0: frame = cv.fillConvexPoly(frame, np.mat(lefteyebrow), (255, 255, 255)) if len(righteyebrow) != 0: frame = cv.fillConvexPoly(frame, np.mat(righteyebrow), (255, 255, 255)) return frameThe get_lmList function for obtaining face coordinates:
def get_lmList(self, frame, p1, p2, draw=True): # Define an empty list lmList = [] # Determine whether a face has been detected if len(self.faces) != 0: # Iterate through the face list to obtain the xy coordinates of the points in each range for n in range(p1, p2): x = self.face_landmarks.part(n).x y = self.face_landmarks.part(n).y # Add the point coordinates of the face to the list lmList.append([x, y]) if draw: next_point = n + 1 if n == p2 - 1: next_point = p1 x2 = self.face_landmarks.part(next_point).x y2 = self.face_landmarks.part(next_point).y cv.line(frame, (x, y), (x2, y2), (0, 255, 0), 1) return lmList