Welcome to ROSMASTER A1 PRO repository
1.Map Description and Prop Placement
Map Description and Prop Placement
Map Description and Prop Placement1. Map Overview2. Detailed Functional Area DivisionArea Function Comparison Table3. Experimental Props Function and Technical Description3.1 AprilTag / ArUco Machine Code Tags3.2 Storage Shelves and Material Trays3.3 Blue Cargo Anti-Static Mat3.4 Four-Color Classified Garbage Bins3.5 Various Colored Cargo Cubes and Garbage Model Cubes
1. Map Overview
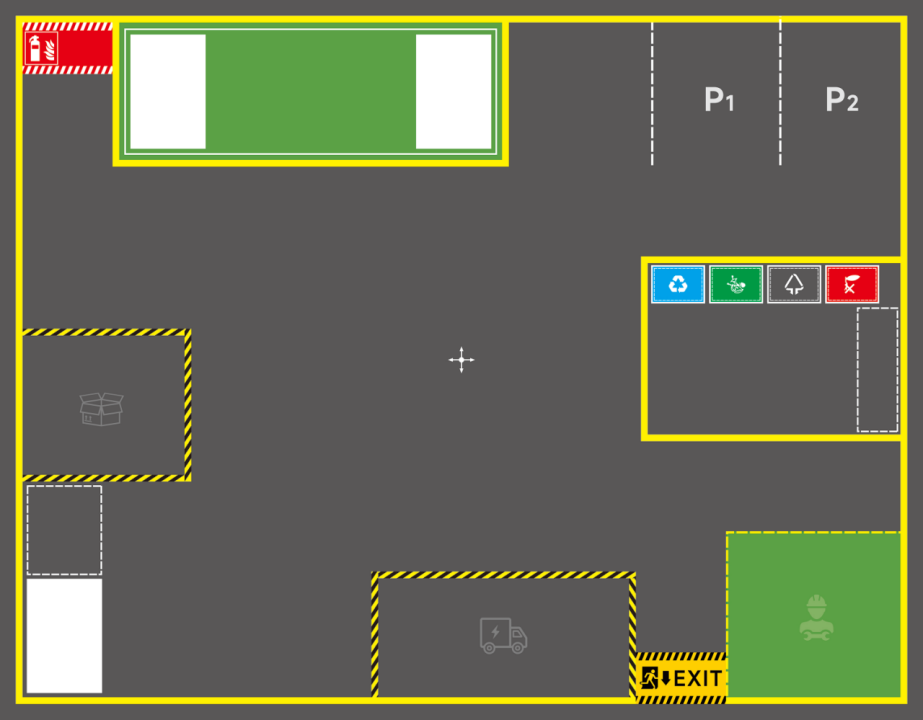
This sandbox map is specifically designed for embodied intelligent mobile manipulation robots - a "Smart Unmanned Factory and Flexible Logistics Warehouse Miniature Training Scenario".
In actual industrial scenarios, composite mobile robots need to shuttle between different workstations such as shelves, material warehouses, assembly production lines, and garbage collection points, performing fully autonomous navigation, delivery, and sorting-grasping operations. This sandbox highly reproduces the real production workflow of modern smart factories through high-definition ground lane lines, functional area markings, and column targets.
2. Detailed Functional Area Division
The naming and functional division of each area in the sandbox supports free definition and expansion. You can customize place names according to your teaching or R&D needs in subsequent courses. The following is the factory-recommended typical smart factory functional layout reference:
Area Function Comparison Table
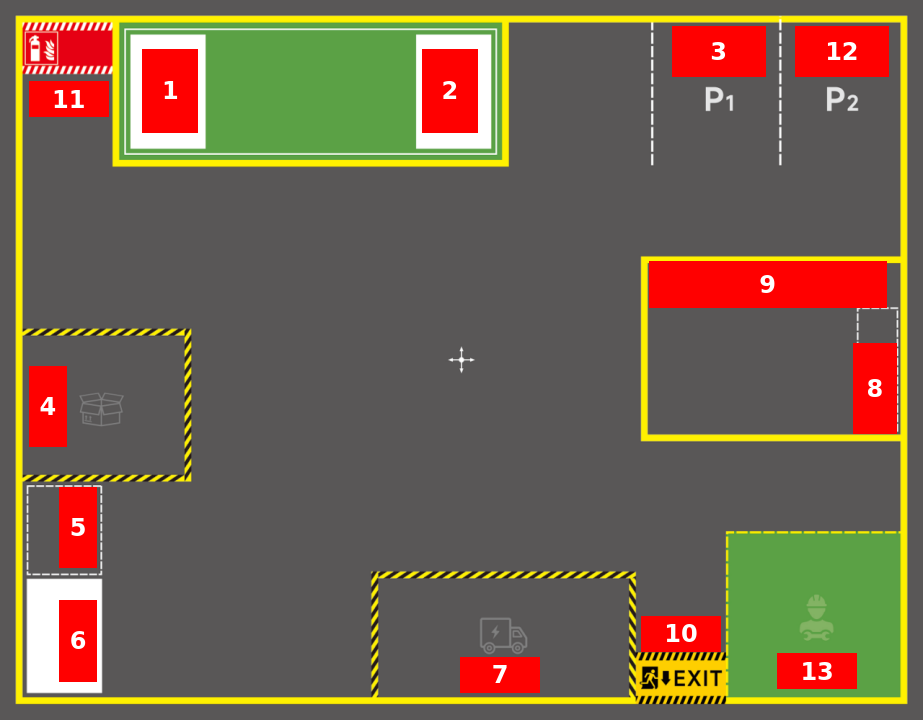
| Area No. | Area Name | Corresponding Props and Facilities | Typical Applications and Task Scenarios |
|---|---|---|---|
| 1 | Shelf Area 1 | Double-layer storage shelf, material tray, cargo cubes | Raw material outbound, semi-finished product storage, high-precision fixed-point placement |
| 2 | Shelf Area 2 | Double-layer storage shelf, material tray | Finished product inbound, cross-station material transfer destination |
| 3 | Parking Lot 1 (Start/Charging Pile) | Ground marking parking spaces | Robot initial departure point, inspection end auto-return charging parking |
| 4 | Goods Warehouse (Raw Material Reserve) | Blue anti-static mat, various colored cargo cubes | Basic raw material storage area, on-demand replenishment extraction station |
| 5 | Goods Sorting Area (Flexible Processing Table) | Blue mat, mixed color cubes | Visual color recognition, multi-category brick autonomous grasping and classification |
| 6 | Shelf Area 3 | Storage shelf, classification tray | Pre-processing buffer area, cross-area production line transfer hub |
| 7 | Shipping Area (Shipping Dock) | Packing shipping table, goods cubes waiting for shipping | Material factory inspection, active inspection and replenishment of missing goods |
| 8 | Garbage Sorting Area | Scattered irregular domestic garbage cubes | YOLO-OBB rotating object detection, tilt-adaptive classification grasping |
| 9 | Garbage Bin Placement Area | Four-color classified garbage bins (food waste/recyclable/other/hazardous) | Stable action group delivery, environmental intelligence classification practice |
| 10 | Factory Entrance/Exit | Channel gate markings | Cross-workshop main line entrance/exit navigation testing |
| 11 | Fire and Safety Equipment Area | Emergency supplies marking positions | Factory safety inspection check-in, abnormal obstacle detour testing |
| 12 | Parking Lot 2 (Backup Parking Position) | Backup parking markings | Multi-vehicle scheduling collaboration, second standby parking point |
| 13 | Equipment Maintenance and Quality Inspection Area | Maintenance station markings | Equipment health self-check, fault simulation check-in point |
3. Experimental Props Function and Technical Description
3.1 AprilTag / ArUco Machine Code Tags
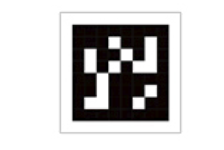
Technical Principle: Black and white high-contrast matrix code with unique digital ID and 4 physical feature corner points.
Function Description: Attached to sandbox shelf columns, key intersections, or operation table edges. When the cart navigates long distances to near a workstation, if slight drift occurs due to wheel slipping, the camera only needs to glance at the tag code, and the algorithm can instantly solve the global 3D coordinates, achieving centimeter-level visual global repositioning correction.
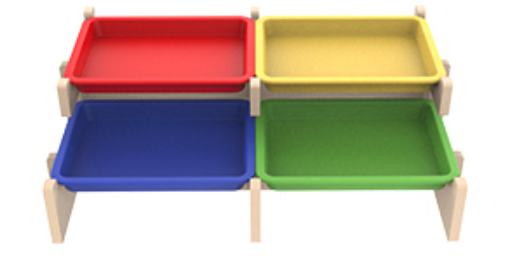
3.2 Storage Shelves and Material Trays
Physical Parameters: Adapted to DOFBOT Pro robotic arm vertical lift and horizontal outreach workspace.
Function Description: Simulates industrial stereo shelves. Upper and lower trays are used to place various colored cargo cubes, training the robot's spatial height perception and inverse kinematics (IK) placement capability.
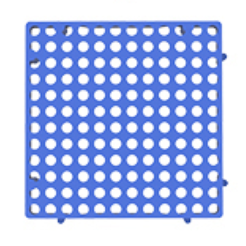
3.3 Blue Cargo Anti-Static Mat
Function Description: Simulates anti-static operation tables and receiving tables in industrial dust-free workshops. The mat surface is flat with soft diffuse reflection characteristics, facilitating the robot's RGB-D depth camera to obtain high-quality surface point cloud data, preventing point cloud missing due to strong light reflection.
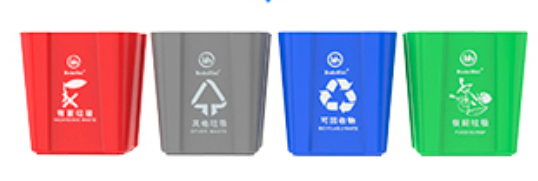
3.4 Four-Color Classified Garbage Bins
Function Description: Corresponding to the national standard four-classification garbage bins (green food waste, blue recyclable, gray other waste, red hazardous waste). In garbage sorting tasks, the robotic arm, based on YOLO-OBB detected category labels, calls preset action groups to precisely deliver to the corresponding colored bin opening.
3.5 Various Colored Cargo Cubes and Garbage Model Cubes
Color Cubes (Standard 4x4x4 cm wooden cubes): Covering red, green, blue, yellow four colors, simulating various industrial standard parts, used for basic tracking grasping, semantic fixed-point placement, and cross-station transfer.
Garbage Cubes: Surface printed with domestic garbage patterns such as peach pits, banana peels, cans, batteries, etc., used for tilt-adaptive rotating object detection and sorting grasping.