Welcome to ROSMASTER A1 PRO repository
8.Brush
Brush
1. Content Description
This lesson implements acquiring the color image and using the MediaPipe framework to detect fingers, then select a color and draw the movement trajectory on the image according to the detected finger movement. This section requires entering commands in the terminal, where the terminal is opened according to the mainboard type. This lesson uses the Raspberry Pi 5 as an example.
For the Raspberry Pi 5 mainboard, you need to open a terminal on the host machine, then enter the command to access the Docker container, and enter the commands mentioned in this lesson inside the terminal after entering the Docker container. For the tutorial on entering the Docker container from the host, please refer to 【Robot Configuration and Operation Guide】, section 【3.Enter Docker (For Raspberry Pi)】 in this product tutorial.
For the Orin and RDK mainboards, simply open a terminal and enter the commands mentioned in this lesson.
2. Program Startup
The Raspberry Pi PI5 controller needs to enter the Docker container first; RDK X5 and Orin controllers do not need to.
To enter the Docker container (for steps, refer to 【Docker Course】 --- 【4. Docker Startup Script】),
All the docker terminals for the commands below need to enter the same Docker container before executing (for steps, refer to 【Docker Course】 --- 【3.Docker Submission and Multi-Terminal Access】)
First, enter the following command in the terminal to start the robot camera and low-level driver environment:
xxxxxxxxxxros2 launch dofbot_pro_driver A1pro_camera_arm.launch.pyNote
This command is the official all-in-one startup script for the A1Pro, which automatically launches the image stream node according to the camera hardware configuration (USB monocular camera or Nuwa 3D depth camera) and loads the low-level drivers. If you only need to start the camera stream separately, you can also run ros2 launch usb_cam camera.launch.py (USB camera) or ros2 launch ascamera hp60c.launch.py (Nuwa camera).
After the camera is started successfully, open another terminal and enter the following command in the terminal to start the brush program:
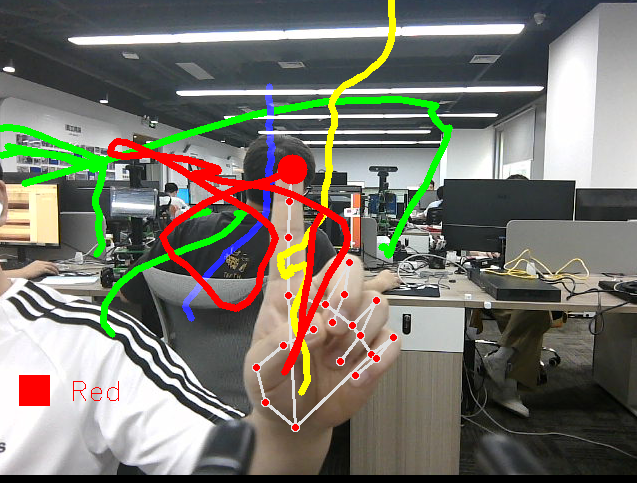
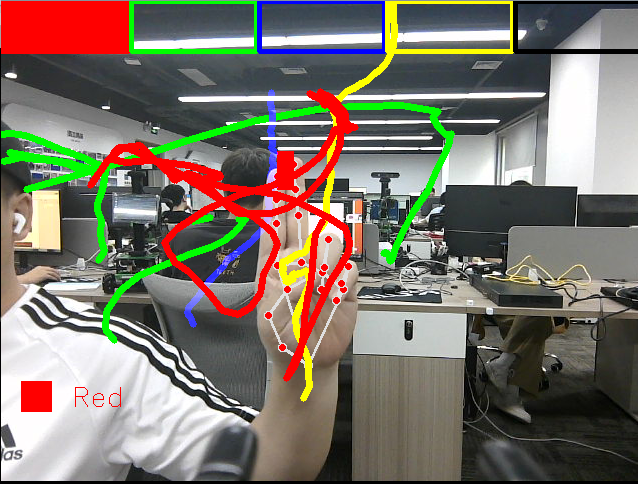
xxxxxxxxxxros2 run yahboomcar_mediapipe 08_VirtualPaint# Control the robotic arm to look forwardros2 topic pub /arm6_joints dofbot_pro_interface/msg/ArmJoints "{joint1: 90, joint2: 180, joint3: 0, joint4: 0, joint5: 90, joint6: 0, time: 1000}" --onceAfter the program runs, as shown in the figure below, the default fingertip color is red. When the index finger and middle finger of the right hand are together, it is in the selection state and a color selection box pops up in the meantime. When the two fingertips move to the corresponding color position, that color is selected (black is the eraser); when the index finger and middle finger are separated, it is in the drawing state, and you can draw freely on the canvas.
When the index finger and middle finger are separated, it is in the drawing state:
When the index finger and middle finger are together, it enters the color selection mode:
3. Core Code Analysis
Program code path:
Raspberry Pi 5 mainboard
The program code is located in the running Docker. The path in the Docker is
/root/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/08_VirtualPaint.pyOrin mainboard
The program code path is
/home/jetson/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/08_VirtualPaint.pyRDK mainboard
The program code path is
/home/sunrise/yahboomcar_ros2_ws/yahboomcar_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/08_VirtualPaint.py
Import the required library files:
xxxxxxxxxximport mathimport timeimport cv2 as cvimport numpy as npimport mediapipe as mpimport rclpyfrom rclpy.node import Nodefrom sensor_msgs.msg import Imagefrom cv_bridge import CvBridgeimport osInitialize the data and define the Publisher and Subscriber:
xdef __init__(self): super().__init__('hand_painting_node') # Create a blank canvas with a resolution of 480*640 self.imgCanvas = np.zeros((480, 640, 3), np.uint8) # Define the thickness of the brush (red, green, blue, yellow) self.brushThickness = 5 # Define the thickness of the eraser (black) self.eraserThickness = 100 # The y coordinate threshold of the bottom of the color selection box; a value less than this means entering the color selection mode self.top_height = 50 self.Color = "Red" # Define the brush color list; the values after each color name represent the rgb value of that color self.ColorList = { 'Red': (0, 0, 255), 'Green': (0, 255, 0), 'Blue': (255, 0, 0), 'Yellow': (0, 255, 255), 'Black': (0, 0, 0), } # Define the ID of each fingertip, which will be used later to determine which fingers are straightened self.tipIds = [4, 8, 12, 16, 20] # Use the class in the mediapipe library to define a hand object self.mpHand = mp.solutions.hands self.mpDraw = mp.solutions.drawing_utils self.hands = self.mpHand.Hands( static_image_mode=False, max_num_hands=2, min_detection_confidence=0.85, min_tracking_confidence=0.5 ) # Define the attributes of the joint connection lines, which will be used in the subsequent joint connection function self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=15) self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=10, circle_radius=10)
self.bridge = CvBridge()
# Define the Subscriber for the color image topic camera_type = os.getenv('CAMERA_TYPE', 'usb') topic_name = '/ascamera_hp60c/camera_publisher/rgb0/image' if camera_type == 'nuwa' else '/usb_cam/image_raw'
self.subscription = self.create_subscription( Image, topic_name, self.image_callback, 10)Color image callback function:
xxxxxxxxxxdef image_callback(self, msg): # Convert the color image message data into image data using CvBridge frame = self.bridge.imgmsg_to_cv2(msg, desired_encoding='bgr8') # Obtain the size of the color image for later color selection based on the fingertip coordinates h, w, c = frame.shape frame, lmList = self.hand_detector.findHands(frame, draw=False) if len(lmList) != 0: # print(lmList) # tip of index and middle fingers # Obtain the fingertip coordinates of the index finger and middle finger x1, y1 = lmList[8][1:] x2, y2 = lmList[12][1:] # Call the fingersUp function to return the list of straightened fingers fingers = self.fingersUp() # If both the index finger and middle finger are straightened if fingers[1] and fingers[2]: # print("Seclection mode") if y1 < self.top_height: # Determine the selected color based on the index finger coordinate and the size of the image if 0 < x1 < int(w / 5) - 1: self.boxx = 0 self.Color = "Red" if int(w / 5) < x1 < int(w * 2 / 5) - 1: self.boxx = int(w / 5) self.Color = "Green" elif int(w * 2 / 5) < x1 < int(w * 3 / 5) - 1: self.boxx = int(w * 2 / 5) self.Color = "Blue" elif int(w * 3 / 5) < x1 < int(w * 4 / 5) - 1: self.boxx = int(w * 3 / 5) self.Color = "Yellow" elif int(w * 4 / 5) < x1 < w - 1: self.boxx = int(w * 4 / 5) self.Color = "Black" cv.rectangle(frame, (x1, y1 - 25), (x2, y2 + 25), self.ColorList[self.Color], cv.FILLED) cv.rectangle(frame, (self.boxx, 0), (self.boxx + int(w / 5), self.top_height), self.ColorList[self.Color], cv.FILLED) # Draw the color selection box for each color cv.rectangle(frame, (0, 0), (int(w / 5) - 1, self.top_height), self.ColorList['Red'], 3) cv.rectangle(frame, (int(w / 5) + 2, 0), (int(w * 2 / 5) - 1, self.top_height), self.ColorList['Green'], 3) cv.rectangle(frame, (int(w * 2 / 5) + 2, 0), (int(w * 3 / 5) - 1, self.top_height), self.ColorList['Blue'], 3) cv.rectangle(frame, (int(w * 3 / 5) + 2, 0), (int(w * 4 / 5) - 1, self.top_height), self.ColorList['Yellow'], 3) cv.rectangle(frame, (int(w * 4 / 5) + 2, 0), (w - 1, self.top_height), self.ColorList['Black'], 3) # If the index finger and middle finger are not straightened simultaneously and the pixel distance between the two fingertips is greater than 50, it means the fingers are spread apart, and the program enters the drawing mode at this time if fingers[1] and fingers[2] == False and math.hypot(x2 - x1, y2 - y1) > 50: # print("Drawing mode") if self.xp == self.yp == 0: self.xp, self.yp = x1, y1 # If the color is black, it is the eraser mode, which erases the drawn trajectory; otherwise, draw the trajectory on the image according to the selected color if self.Color == 'Black': cv.line(frame, (self.xp, self.yp), (x1, y1), self.ColorList[self.Color], self.eraserThickness) cv.line(self.imgCanvas, (self.xp, self.yp), (x1, y1), self.ColorList[self.Color], self.eraserThickness) else: cv.line(frame, (self.xp, self.yp), (x1, y1), self.ColorList[self.Color], self.brushThickness) # Draw the line in the selected color on the created canvas cv.line(self.imgCanvas, (self.xp, self.yp), (x1, y1), self.ColorList[self.Color], self.brushThickness) cv.circle(frame, (x1, y1), 15, self.ColorList[self.Color], cv.FILLED) self.xp, self.yp = x1, y1 else: self.xp = self.yp = 0 # Convert the color space of the canvas to a grayscale image for subsequent image processing imgGray = cv.cvtColor(self.imgCanvas, cv.COLOR_BGR2GRAY) # Perform thresholding on the grayscale image, that is, divide the pixel values of the image into two classes (such as foreground and background) according to the set threshold. It is one of the core methods of image binarization. _, imgInv = cv.threshold(imgGray, 50, 255, cv.THRESH_BINARY_INV) # Convert the color space and transform the grayscale image into the color BGR image space imgInv = cv.cvtColor(imgInv, cv.COLOR_GRAY2BGR) # Perform bitwise AND and OR operations on the images to combine them frame = cv.bitwise_and(frame, imgInv) frame = cv.bitwise_or(frame, self.imgCanvas) # Draw the currently selected color box and color cv.rectangle(frame, (20, h - 100), (50, h - 70), self.ColorList[self.Color], cv.FILLED) cv.putText(frame, self.Color, (70, h - 75), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) cv.imshow('frame', frame)The fingersUp function for detecting straightened fingers:
xxxxxxxxxxdef fingersUp(self): fingers=[] # Thumb, judge whether the angle of each joint of the thumb is greater than 150 degrees; if so, the thumb can be considered straightened if (self.calc_angle(self.tipIds[0], self.tipIds[0] - 1, self.tipIds[0] - 2) > 150.0) and ( self.calc_angle( self.tipIds[0] - 1, self.tipIds[0] - 2, self.tipIds[0] - 3) > 150.0): fingers.append(1) else: fingers.append(0) # 4 finger, the remaining four fingers for id in range(1, 5): # Here it judges whether the y value of the fingertip joint is smaller than that of the middle joint; if so, the finger is considered straightened (the origin of the image is at the upper left, y increases downward, and x increases to the right) if self.lmList[self.tipIds[id]][2] < self.lmList[self.tipIds[id] - 2][2]: fingers.append(1) else: fingers.append(0) return fingersAs shown in the figure below, the ID of each finger joint:
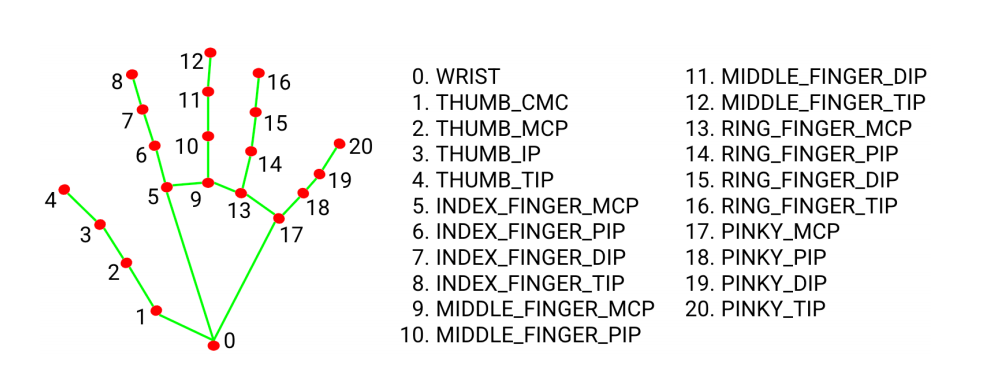
The findHands function for palm detection:
def findHands(self, frame, draw=True): # Create a detection list to store the detection results self.lmList = [] img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) # Call the process function in the mediapipe library for image processing; during init, the self.hands object was created and initialized self.results = self.hands.process(img_RGB) if self.results.multi_hand_landmarks: for handLms in self.results.multi_hand_landmarks: if draw: self.mpDraw.draw_landmarks(frame, handLms, self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) else: self.mpDraw.draw_landmarks(frame, handLms, self.mpHand.HAND_CONNECTIONS) # Iterate through the detection results and add the detection results to the self.lmList list, which represents the id of each detected hand joint and the xy coordinates of the joint for id, lm in enumerate(self.results.multi_hand_landmarks[0].landmark): h, w, c = frame.shape cx, cy = int(lm.x * w), int(lm.y * h) # print(id, cx, cy) self.lmList.append([id, cx, cy]) return frame, self.lmList