Welcome to ROSMASTER A1 PRO repository
5.Inverse Kinematics Design
Inverse Kinematics Design
1. Content Description
This course explains how to call the functions in the MoveIt library to implement inverse kinematics design of the robot arm. Inverse kinematics design refers to computing the required joint angles based on the desired pose of the end effector. Here, in RViz, we specify a pose for the end effector, and then let MoveIt2 plan and move to this pose.
2. Launch
Enter the following command in the terminal to launch the MoveIt2 simulation environment:
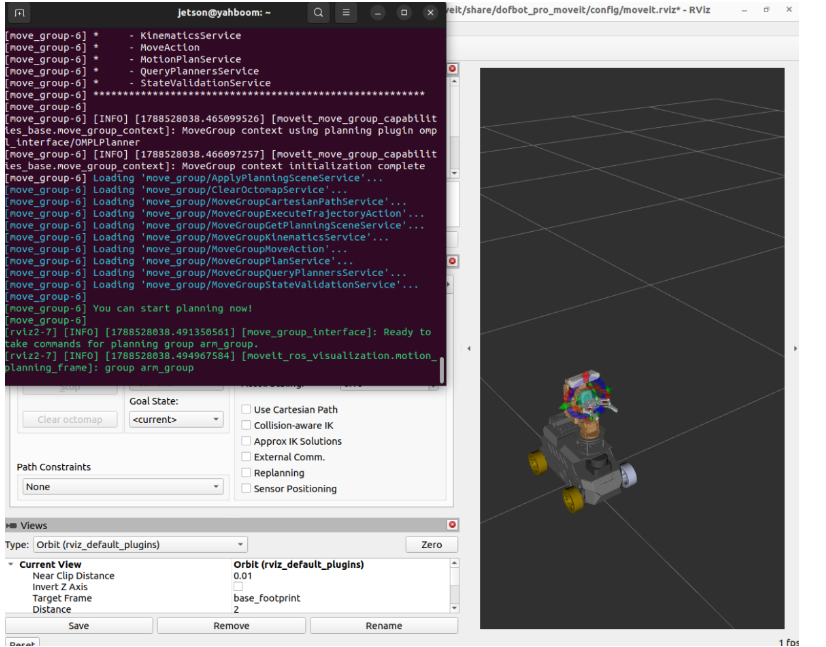
xxxxxxxxxxros2 launch dofbot_pro_moveit demo_3d.launch.pyOnce the program starts, when You can start planning now! appears in the terminal, it means the startup was successful, as shown in the figure below:
If you want the simulated robot arm to be linked with the real physical robot arm (optional), open another terminal to run the real-machine driver node:
xxxxxxxxxxros2 run movelt_demo SimulationToMachine(It is recommended not to start this node during the initial test. First verify that the obstacle-avoidance trajectory is correct in the pure RViz simulation environment before connecting to the real machine).
Then enter the following command in another terminal to launch the inverse kinematics spatial pose planning program:
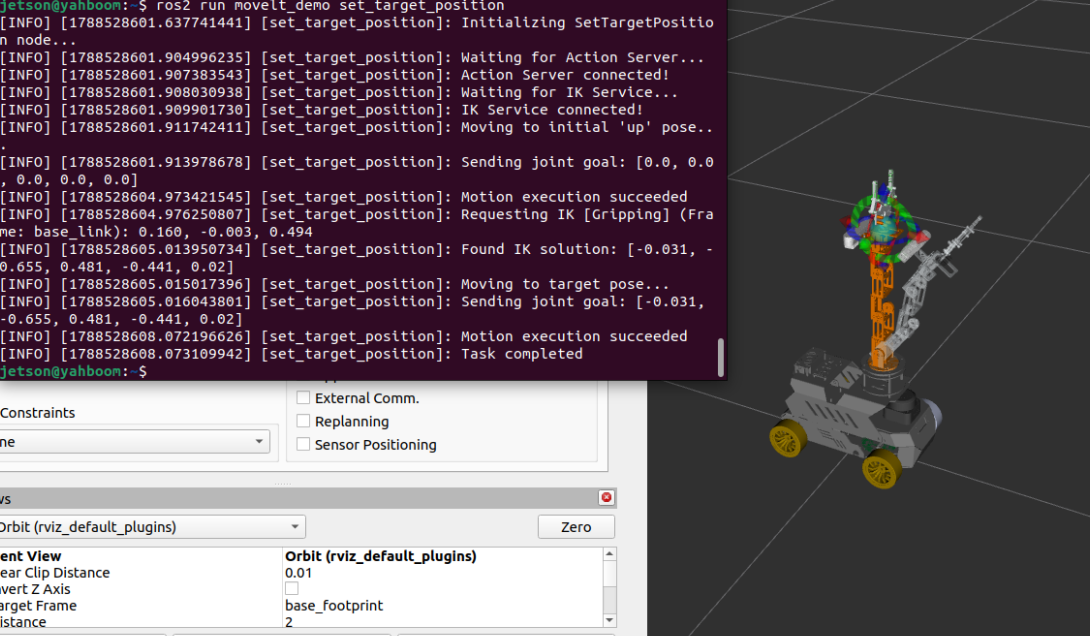
xxxxxxxxxxros2 run movelt_demo set_target_positionAfter the program runs, the robot arm in RViz (as well as the physical robot arm) will automatically invoke the MoveIt kinematics inverse-solution solver, smoothly plan and move to the specified end-effector spatial pose, as shown in the figure below:
3. Core Code Analysis
Program source code path:
~/yahboomcar_ros2_ws/dofbot_pro_ws/src/movelt_demo/movelt_demo/set_target_position.py
3.1 Inverse Kinematics Principles and Service Client Initialization
Inverse Kinematics (IK) refers to reversely deriving and computing each joint rotation angle that satisfies the given target coordinates $(x, y, z)$ and the orientation quaternion $(q_x, q_y, q_z, q_w)$ of the robot arm's end effector (e.g., the gripper Gripping) in Cartesian 3D space.
The program creates two core interfaces:
/compute_ikservice client: Calls MoveIt's internal KDL/IKFast solver to compute the feasible joint angles corresponding to the spatial pose;FollowJointTrajectoryAction client: Sends the solved joint angles to the controller to execute the physical/simulated trajectory.
xxxxxxxxxximport rclpyfrom rclpy.node import Nodefrom rclpy.action import ActionClientfrom control_msgs.action import FollowJointTrajectoryfrom trajectory_msgs.msg import JointTrajectory, JointTrajectoryPointfrom builtin_interfaces.msg import Durationfrom geometry_msgs.msg import PoseStampedfrom moveit_msgs.srv import GetPositionIKfrom moveit_msgs.msg import PositionIKRequest
class SetTargetPosition(Node):    def __init__(self):        super().__init__('set_target_position')        self.get_logger().info("Initializing SetTargetPosition node...")                # 1. Trajectory execution Action client        self._action_client = ActionClient(            self,             FollowJointTrajectory,             '/arm_group_controller/follow_joint_trajectory'        )                # 2. Kinematics inverse-solution solver service client        self._ik_client = self.create_client(GetPositionIK, '/compute_ik')                self.joint_names = [            "arm1_Joint", "arm2_Joint", "arm3_Joint",             "arm4_Joint", "arm5_Joint"        ]                self._action_client.wait_for_server()        while not self._ik_client.wait_for_service(timeout_sec=1.0):            self.get_logger().info("Waiting for the /compute_ik service to come online...")
3.2 Inverse-Solution Computing and Target Trajectory Execution
Construct a PositionIKRequest request, specifying the end link as Gripping and the target reference frame as base_link:
x def get_ik_solution(self, target_pose, frame_id="base_link", ik_link_name="Gripping"): """Call the /compute_ik service to compute the inverse kinematics joint angles""" request = GetPositionIK.Request() request.ik_request.group_name = "arm_group" request.ik_request.ik_link_name = ik_link_name request.ik_request.pose_stamped = target_pose request.ik_request.pose_stamped.header.frame_id = frame_id request.ik_request.timeout = Duration(sec=0, nanosec=500000000) # 500ms timeout request.ik_request.avoid_collisions = False request.ik_request.robot_state.joint_state.name = self.joint_names request.ik_request.robot_state.joint_state.position = [0.0] * 5
future = self._ik_client.call_async(request) rclpy.spin_until_future_complete(self, future) response = future.result() if response.error_code.val == response.error_code.SUCCESS: solution = response.solution.joint_state # Extract the joint angles of axes 1-5 joint_positions = [ solution.position[solution.name.index(name)] for name in self.joint_names ] return joint_positions else: self.get_logger().error(f"IK computation failed, error code: {response.error_code.val}") return None
def execute_ik_motion(self): # Set the target 3D coordinates and the quaternion orientation target_pose = PoseStamped() target_pose.pose.position.x = 0.10755 target_pose.pose.position.y = 0.0 target_pose.pose.position.z = 0.400775 target_pose.pose.orientation.w = 1.0 joint_goals = self.get_ik_solution(target_pose) if joint_goals: self.move_to_joints(joint_goals, move_time=3.0)