yahboom
HomeTutorialsProduct
Solution
Blog
Online Store
About Us
EN/中文
Store
ROSMASTER A1 PRO📖
00.Configuration and Operation Guide
  • 0. Unboxing and Review
  • 1.Assembly Videos
  • 2.User Manual
  • 3.Enter Docker (For Raspberry Pi)
  • 4.A1Pro Front Wheel Servo Calibration
  • 5.USB Camera Calibration
  • 6.Depth Camera Calibration
  • 7.FAQ
  • 8.Desktop Configuration Center and Remote Control Guide
01.Chassis Control Course
  • 1.Robot Information Publishing
  • 2.Robot Handle Control
  • 3.Robot Keyboard Control
  • 4.Linear Velocity Calibration
  • 5.Angular Velocity Calibration
  • 6.Robot URDF Model
  • 7.Robot EKF State Estimation
02.Lidar Course
  • 1.Lidar Introduction and Use
  • 2.Lidar Obstacle Avoidance
  • 3.Lidar Following
  • 4.Lidar Patrol
  • 5.GMapping-SLAM Mapping
  • 6.Cartographer-SLAM Mapping
  • 7.Slam-Toolbox Mapping
  • 8.Lifelong Mode Mapping
  • 9.Navigation2 Single Point Navigation
  • 10.Navigation2 Multi Point Navigation
  • 11.Cartographer Relocalization Navigation
  • 12.Slam-Toolbox Localization Navigation
  • 13.Synchronous Mapping And Navigation
  • 14.Aruco Visual Relocalization Navigation
  • 15.Mobile App Mapping And Navigation
  • 16.AprilTag Transport
  • 17.Color Block Transport
03.USB Camera-Depth Camera Course
  • 1.USB Camera Introduction
  • 2.USB Camera Intrinsic Calibration
  • 3.Nuwa-HP60C Camera Introduction (Depth Camera Only)
  • 4.Depth Camera Distance Measurement (Depth Camera Only)
  • 5.Depth Pseudo Color Image (Depth Camera Only)
  • 6.Block Volume Calculation (Depth Camera Only)
  • 7.Edge Detection (Depth Camera Only)
  • 8.RTAB-Map SLAM Mapping (Depth Camera Only)
  • 9.RTAB-Map Navigation (Depth Camera Only)
04.Robotic Arm and 3D Space Gripping Course
  • 0.Robotic Arm Basic Usage
  • 1.Robotic Arm Kinematics
  • 2.Robotic Arm Chassis Coordination Control
  • 3.AprilTag ID Sorting
  • 4.AprilTag Height Anomaly Sorting
  • 5.AprilTag Tracking and Grasping
  • 6.Color Block Sorting
  • 7.Color Block Height Anomaly Sorting
  • 8.Color Block Tracking and Grasping
  • 9.Wood Block Shape Sorting
  • 10.KCF Tracking and Grasping Objects
  • 11.Mediapipe Gesture ID Sorting AprilTag
  • 12.Mediapipe Gesture Height Sorting AprilTag
  • 13.Desktop Tracking and Grasping AprilTag
  • 14.3D Spatial Tracking AprilTag
  • 15.Line Following Obstacle Clearing
  • 16.Transformer Model Tracking Algorithm
05.Road Network Planning and Navigation
  • 1.Introduction To Road Network Planning
  • 2.Road Network Annotation
  • 3.Planning And Navigation Between Waypoints
  • 4.Road Network Navigation In Any Pose
  • 5.Path Re-planning
06.OpenClaw Basic Course
  • 1.Introduction to OpenClaw
  • 2.OpenClaw Core Concepts
  • 3.OpenClaw API-KEY Configuration
  • 4.OpenClaw Switch Models
  • 5.OpenClaw System Prompt Words
  • 6.OpenClaw Common CLI Commands
07.OpenClaw Interaction Method
  • 1.OpenClaw Webchat Interaction
  • 2.OpenClaw Tui Interaction
  • 3.OpenClaw Voice Dialogue Interaction
  • 4.OpenClaw WhatsApp Interaction
08.OpenClaw Development
  • 1.OpenClaw Connecting to Robot MCP Service
  • 2.Robot CLI Command Tool
  • 3.robot-control plugin tool
  • 4.reply-bridge plugin tool
  • 5.OpenClaw Multimodal Vision
  • 6.OpenClaw Chassis Control
  • 7.OpenClaw Robotic Arm Control
  • 8.OpenClaw Skills Development
  • 9.OpenClaw Scheduled Tasks
  • 10.OpenClaw Multi-Agent Intelligent Agent
  • 11.OpenClaw Active Interaction
  • 12.OpenClaw Vector Memory
09.OpenClaw Embodied Intelligent Application
  • 1.OpenClaw Target Tracking
  • 2.OpenClaw Arm Tracking And Grasping
  • 3.OpenClaw Arm Fixed-point Placement
  • 4.OpenClaw Waste Sorting
  • 5.OpenClaw SLAM Mapping And Navigation
  • 6.OpenClaw Navigation Transport
  • 7.OpenClaw AprilTag Grasping
  • 8.OpenClaw Color Line Patrol
  • 9.OpenClaw Visual Distance Measurement
10.OpenClaw Scenario Sandbox
  • 1.Map Description and Prop Placement
  • 2.Build Sand Table Map
  • 3.Visual Relocation Markers
  • 4.Map Mapping Markers
  • 5.OpenClaw Scenario Sandbox Comprehensive Case
11.AI Model Basics
  • 1.AI Large Model Types and Principles
  • 2.RAG Retrieval Enhancement and Model Training Samples
  • 3.Embodied Intelligent Robot System Architecture
  • 4.Embodied Intelligent Functions Core Source Code
12.AI Model Development
  • 1.Register a Model Service Provider Aaccount
  • 2.Configuring API-KEY
  • 3.Introduction to Dify
  • 4.Basic Dify Features
  • 5.AI Large Model Development - chatbot
  • 6.Deploy the RAG Knowledge Base
  • 7.RAG Knowledge Base + chatbot
  • 8.AI Agent Workflow
  • 9.Custom Wake-up Response
13.AI Model - Text Version
  • 1.Semantic Understand and Command Follow
  • 2.Multimodal Visual Understand
  • 3.Multimodal Visual Understand + Robotic Arm Gripping
  • 4.Multimodal Visual Understand+SLAM Navigation
  • 5.Robotic Arm Gripping+Multimodal Visual Understand+SLAM Navigation
  • 6.Intention Estimation
14.AI Model - Voice Version
  • 1.Semantic Understand and Command Follow
  • 2.Multimodal Visual Understand
  • 3. Multimodal Large Model+Robotic Arm Gripping
  • 4.Multimodal Visual Understand+SLAM Navigation
  • 5.Robotic Arm Gripping+Multimodal Visual Understand+SLAM Navigation
  • 6.Intention Estimation
15.Mediapipe Visual Course
  • 1.Hand Detection
  • 2.Posture Detection
  • 3.Overall Detection
  • 4.Facial Landmark Detection
  • 5.Face Detection
  • 6.Face Special Effects
  • 7.3D Object Recognition
  • 8.Brush
  • 9.Finger Control
  • 10.Palm Target Positioning
  • 11.Fingertip Trajectory Recognition
  • 12.Fingertip Gesture Control Cobotic Arm
  • 13.Gesture Grabbing and Releasing Objects
  • 14.Finger Control Robotic Arm
  • 15.Medipipe Gesture Control Robotic arm Cction Group
16.MoveIt2 Simulation Course
  • 1.MovelT2 Configuration
  • 2.MovelT2 Simulation-Reality Linkage
  • 3.Random Movement
  • 4.Forward Kinematics Design
  • 5.Inverse Kinematics Design
  • 6.Cartesian Path
  • 7.Scene Design
  • 8.Trajectory Planning
  • 9.Collision Detection
  • 10.3D Perception Obstacle‑Avoidance
17.Multi-vehicle Course
  • 1.Multi-vehicle Control
  • 2.Multi-vehicle Navigation
  • 3.Multi-vehicle Formation
18.YOLO26 Development
  • 1.CLI Use
  • 2.Object Detection
  • 3.Instance Segmentation
  • 4.Pose Estimation
  • 5.Image Classification
  • 6.Oriented Object Detection
  • 7.YOLOv26 + DeepSORT Tracking
  • 8.Monocular Depth Estimation
19.Control Board STM32 Driver Course
  • 0.Notes (Must Read)
  • 1.About Expansion Board
  • 2.STM32 Development Environment
  • 3.Button Control
  • 4.FreeRTOS Application
  • 5.Serial Communication
  • 6.SBUS Model Aircraft Remote Control
  • 7.CAN Bus Communication
  • 8.RGB Colorful Light Bar
  • 9.Timer Interrupt to Control PWM Servo
  • 10.Control Serial Port Servos
  • 11.Nine-axis Attitude Sensor to Obtain Data
  • 12.Control Motor
  • 13.Timer Captures the Encoder Data
  • 14.1 Kinematic Analysis of Mecanum Wheel
  • 14.2 Kinematic Analysis of Ackerman
  • 14.3 Kinematic Analysis of 4WD
  • 15.PID Control Robot Movement
20.Docker Course
  • 1.Docker Introduction and Installation
  • 2.Docker Basic Commands
  • 3.Docker Submission and Multi-Terminal Access
  • 4. Docker Startup Script
  • 5.Docker-Vscode Environment Construction
21.Image Processing Basics Course
  • 1. Introduction to Open Source CV
  • 2. Image reading and display
  • 3. Image writing
  • 4. Image quality
  • 5. Pixel Operation
  • 6. Image zoom
  • 7. Image cutting
  • 8. Image translation
  • 9. Image Mirroring
  • 10. Affine Transformation
  • 11. Image Rotation
  • 12. Perspective Transformation
  • 13. Grayscale processing
  • 14. Image Binarization
  • 15. Edge Detection
  • 16. Line drawing
  • 17. Rectangle and circle drawing
  • 18. Drawing text and pictures
22.Linux System Course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
23.ROS2 Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
24.Main Control Course
Jetson Orin Nano_NX
  • 1.Jetson Orin board introduction
  • 2.Restore the factory image system
  • 3.Backup SSD system
  • 4.SSD expansion
  • 5.Network configuration
  • 6.SSH remote login
  • 7.VNC remote control
  • 8.Remote file transfer
  • 9.Jtop tool
  • 10.Exchange space expansion
Raspberry Pi
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Update and upgrade operating system
  • 6. Introduction to raspi-config tool
  • 7. config.txt file description
  • 8. Network Configuration
  • 9. remote access
  • 10. Transfer files remotely
  • 11. Set display resolution and rotation
  • 12. Set screen to sleep
  • 13. Play audio and video
  • 14. Using USB camera
  • 15. Using MIPI camera
  • 16. Get real-time temperature of Raspberry Pi
RDKX5
  • 1.Introduction to RDK X5 board
  • 2.Write system file
  • 3.Hardware interface description
  • 4.Install case and other accessories
  • 5.Network configuration
  • 6.Remote login
  • 7.Update system
  • 8.srpi-config user guide
  • 9.config. txt configuration file
  • 10.Self-startup setting
  • 11.RDK exclusive command usage
  • 12.Linux command usage
  • 13.GPIO readwrite operation
  • 14.Image classification algorithm
  • 15.Use USB camera
  • 16.Use MIPI camera
  • 17.Binocular camera depth algorithm
  • 18. Controlling RGB Cooling Fans
Download
  • SystemFile
  • Code
  • 3D_Model_File
  • Software_Tools
  • Hardware_Info
  • Introduction_Manual
  • Script_File
  • Dify AI Agent
Download ZIP

Welcome to ROSMASTER A1 PRO repository

6.Deploy the RAG Knowledge Base

Deploy the RAG Knowledge Base

Deploy the RAG Knowledge Base1. Course Content2. Starting the Dify Service3. Viewing the Preset Knowledge Base4. Extending the RAG Knowledge Base4.1 Economy-Mode Knowledge Base4.2 High-Quality-Mode Knowledge Base4.3 Retrieval Testing

1. Course Content

  • Master the process and methods for locally deploying, debugging, and testing the RAG knowledge base.

  • Master the methods for extending the RAG knowledge base according to your own task scenarios.

Tip

  • The RAG knowledge base helps general-purpose AI large models provide reference knowledge in vertical domains, avoiding hallucinated responses and improving the model's ability to answer within a vertical domain.

  • The RAG knowledge base helps robots quickly extend their generalization ability across different task scenarios.


2. Starting the Dify Service

  • Connect to the onboard computer via VNC or SSH, and enter the following command in the terminal:

sh ~/bringup_dify.sh
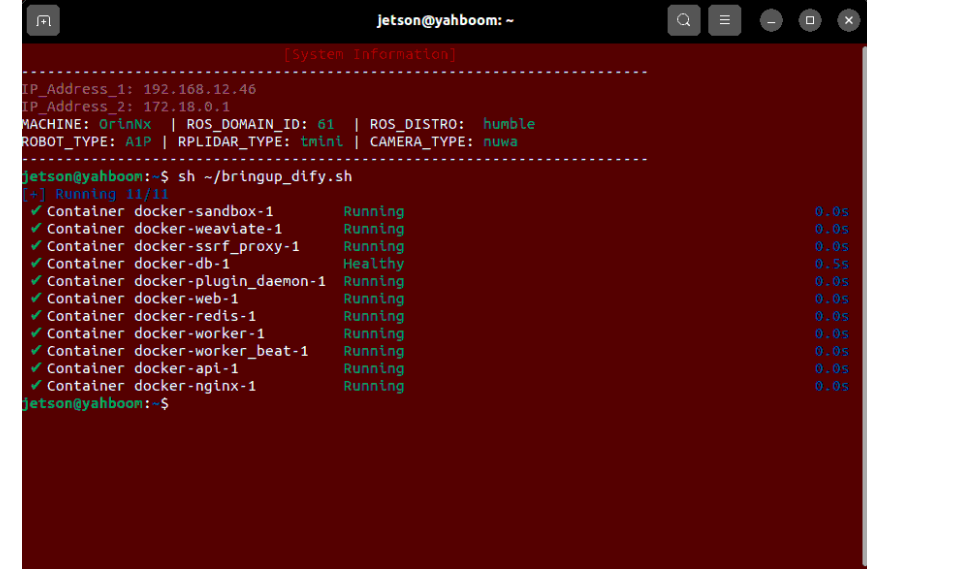
image-20260904191455740


  • Open a terminal to view the current IP address.
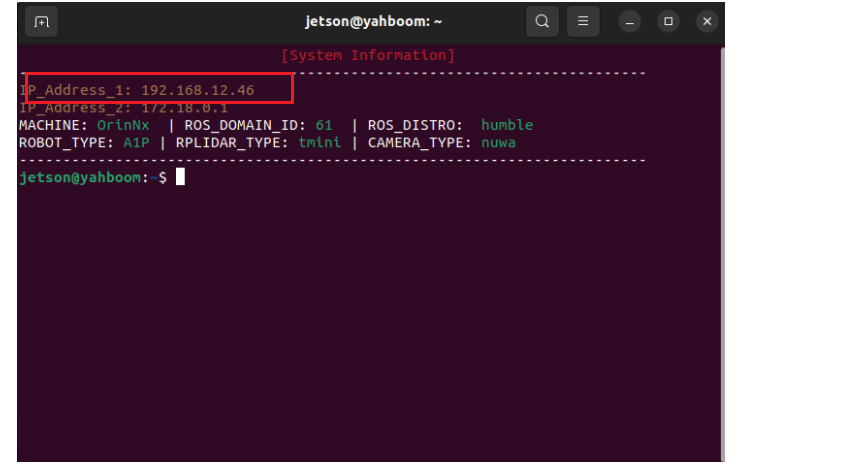
image-20260904191514130


3. Viewing the Preset Knowledge Base

  • Click the Knowledge Base page on the home page. Dify comes with two preset RAG knowledge bases by default, which contain the same content and differ only in language.

Tip

  • The preset knowledge bases here provide training samples for some task scenarios, helping the AI model quickly master the relevant skills.
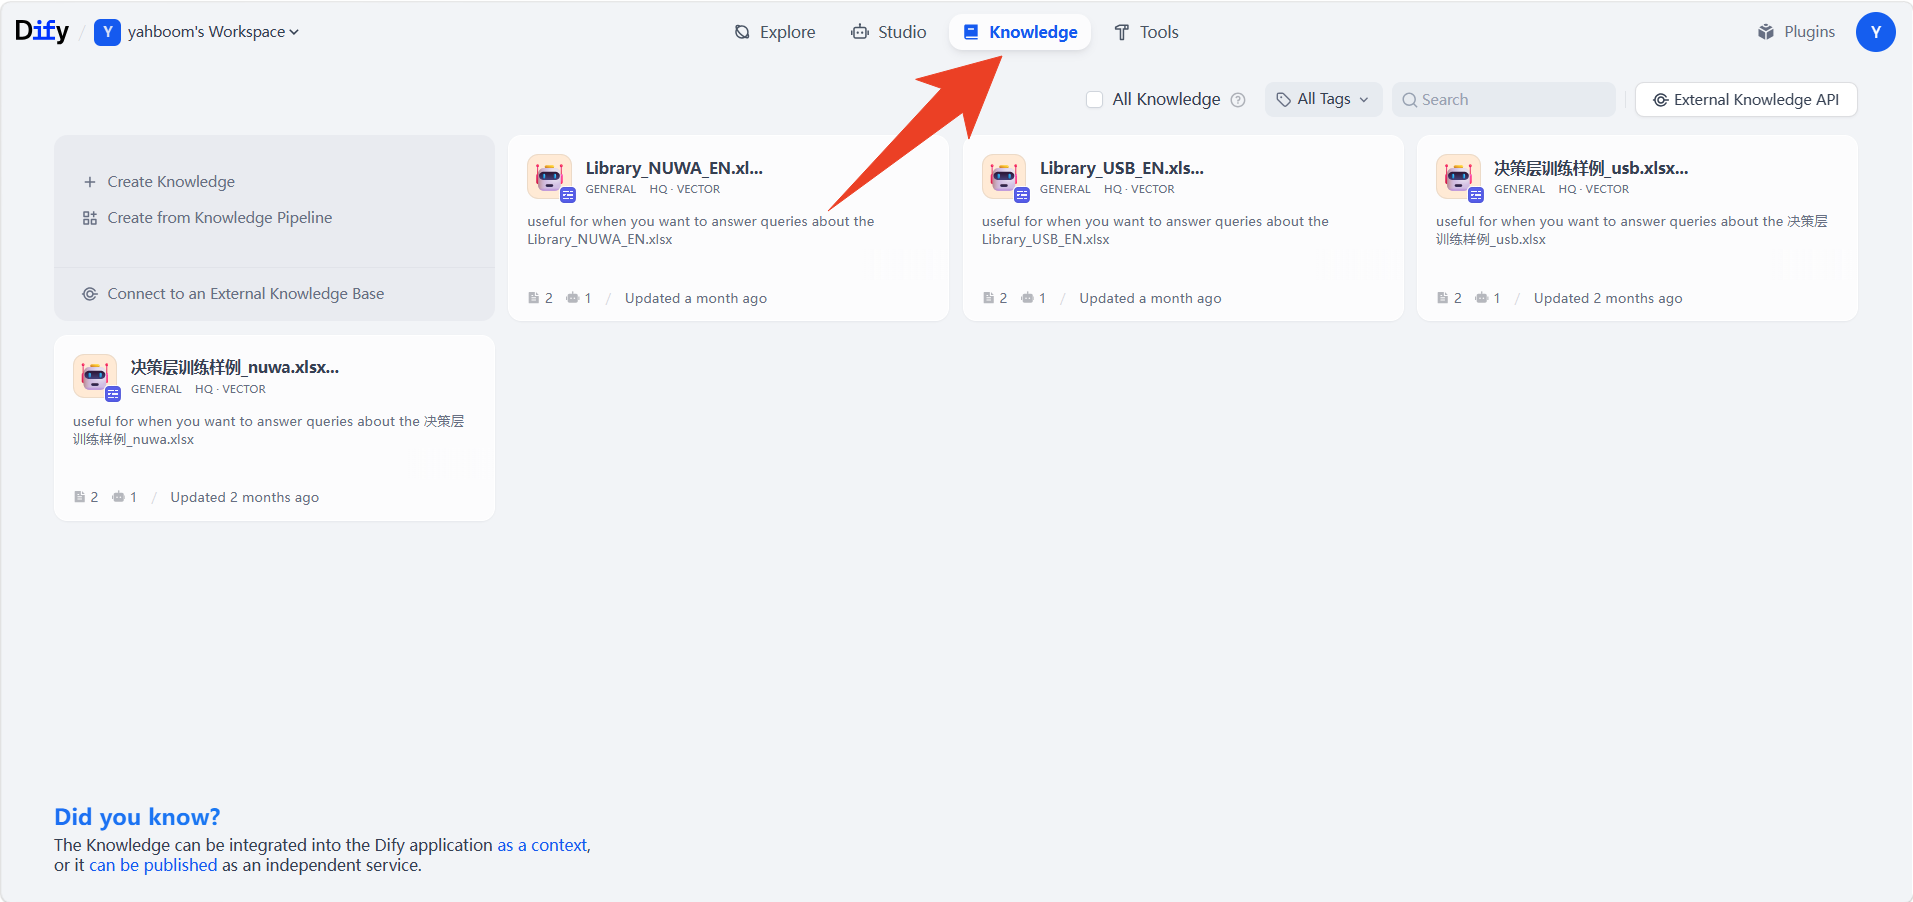
image-20260904191535942


  • Open a knowledge base. There are two preset files in it: Intent_en and Libray_NUWA_EN, where:

    • Intent_en: used to store user intents and the corresponding tasks that the robot needs to perform.

    • Libray_NUWA_EN: stores some preset reference samples for task scenarios.
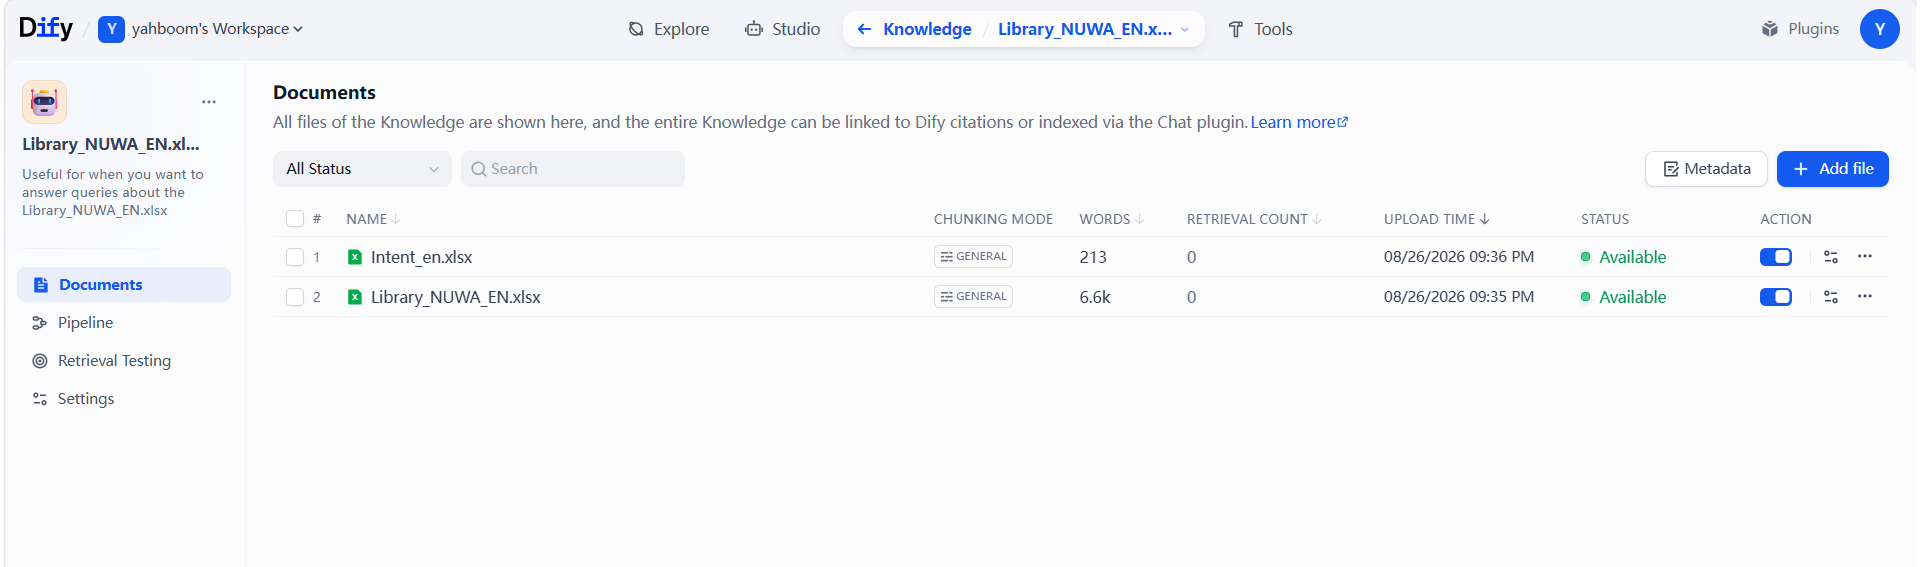
image-20260904191549847


4. Extending the RAG Knowledge Base

  • If you need to extend the knowledge base, click Create Knowledge.
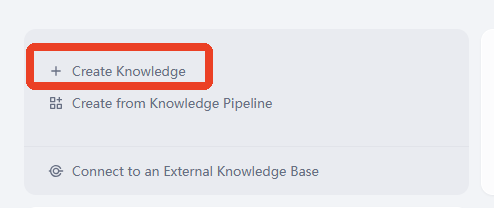
 

image-20251219183845482


  • Here, importing local data is used as the example data source.

  • Click Import from Text → Select File → Next.
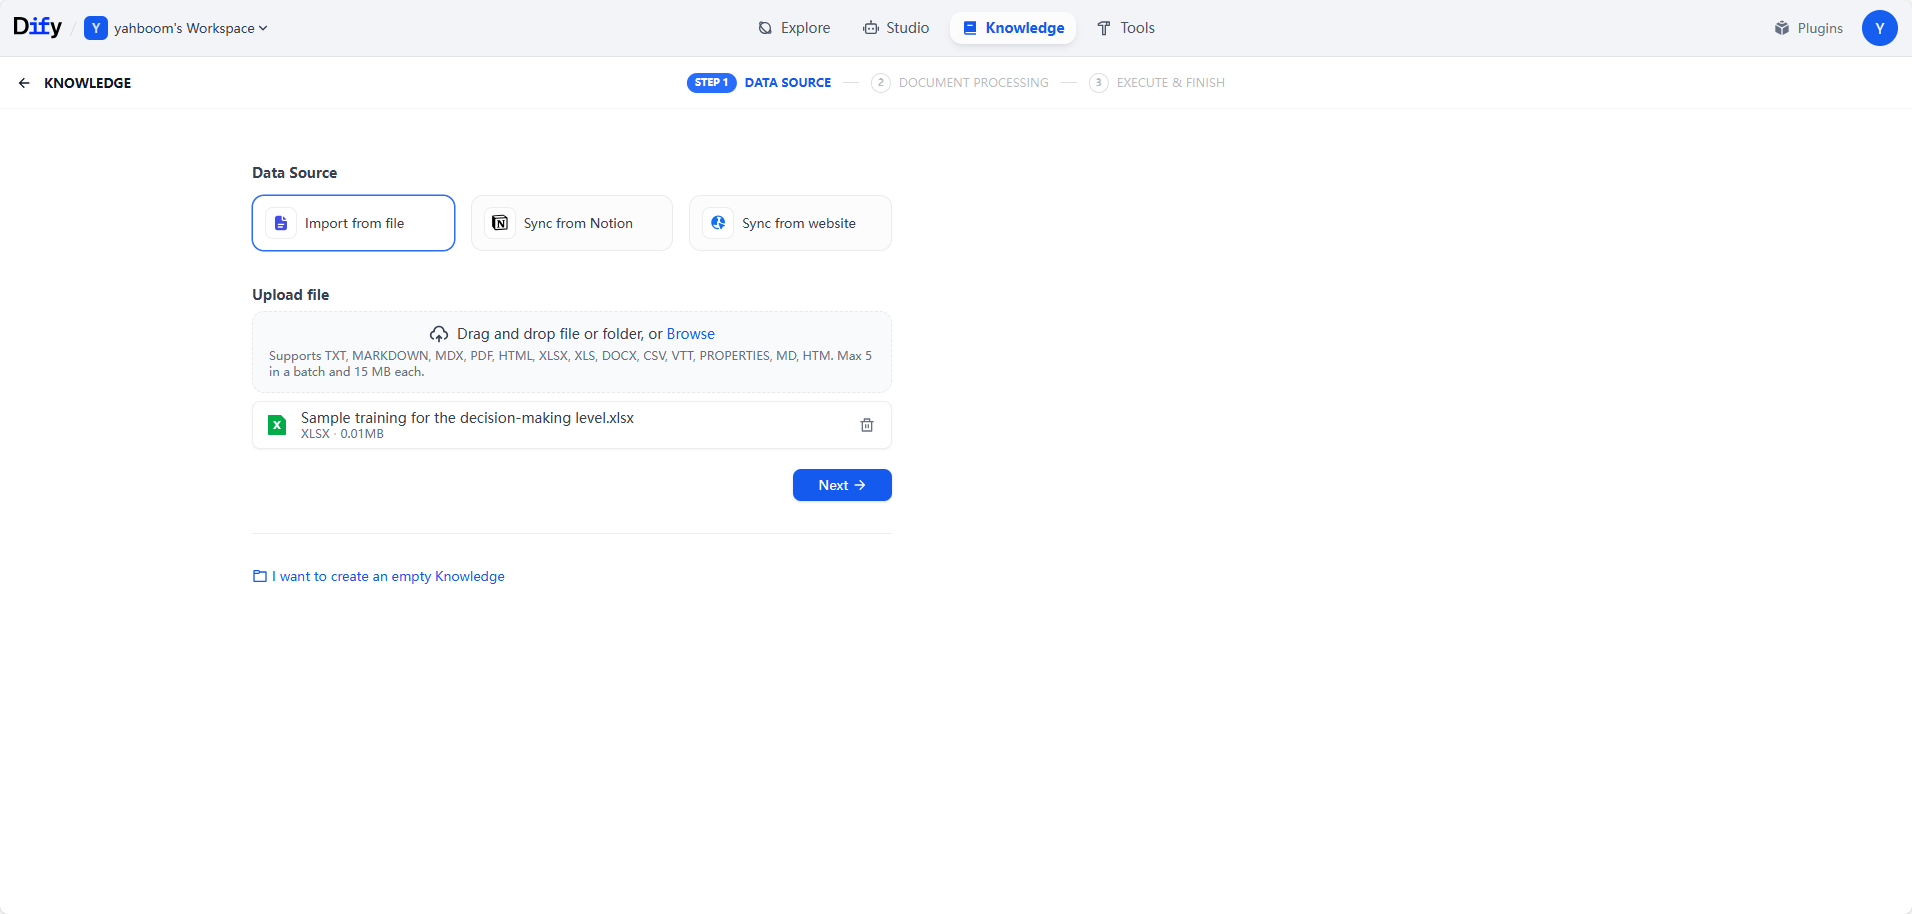
image-20251219184147798

  • Then you enter the knowledge base configuration page. Click the Preview block to view the chunking effect on the file. Here, the indexing mode is set to Economy.

Tip

  • For beginners, we recommend using the Economy mode first for learning and testing. The difference between the two indexing modes:

    • Economy: retrieves content in the knowledge base through keywords; it cannot perform extended retrieval based on similar semantics, so the way of retrieving knowledge segments is relatively rigid.

    • High Quality mode: requires an embedding model that consumes extra tokens and also requires a rerank model, achieving more accurate retrieval of semantically similar segments.


4.1 Economy-Mode Knowledge Base

  • Select the following configuration, then click Save and Process.
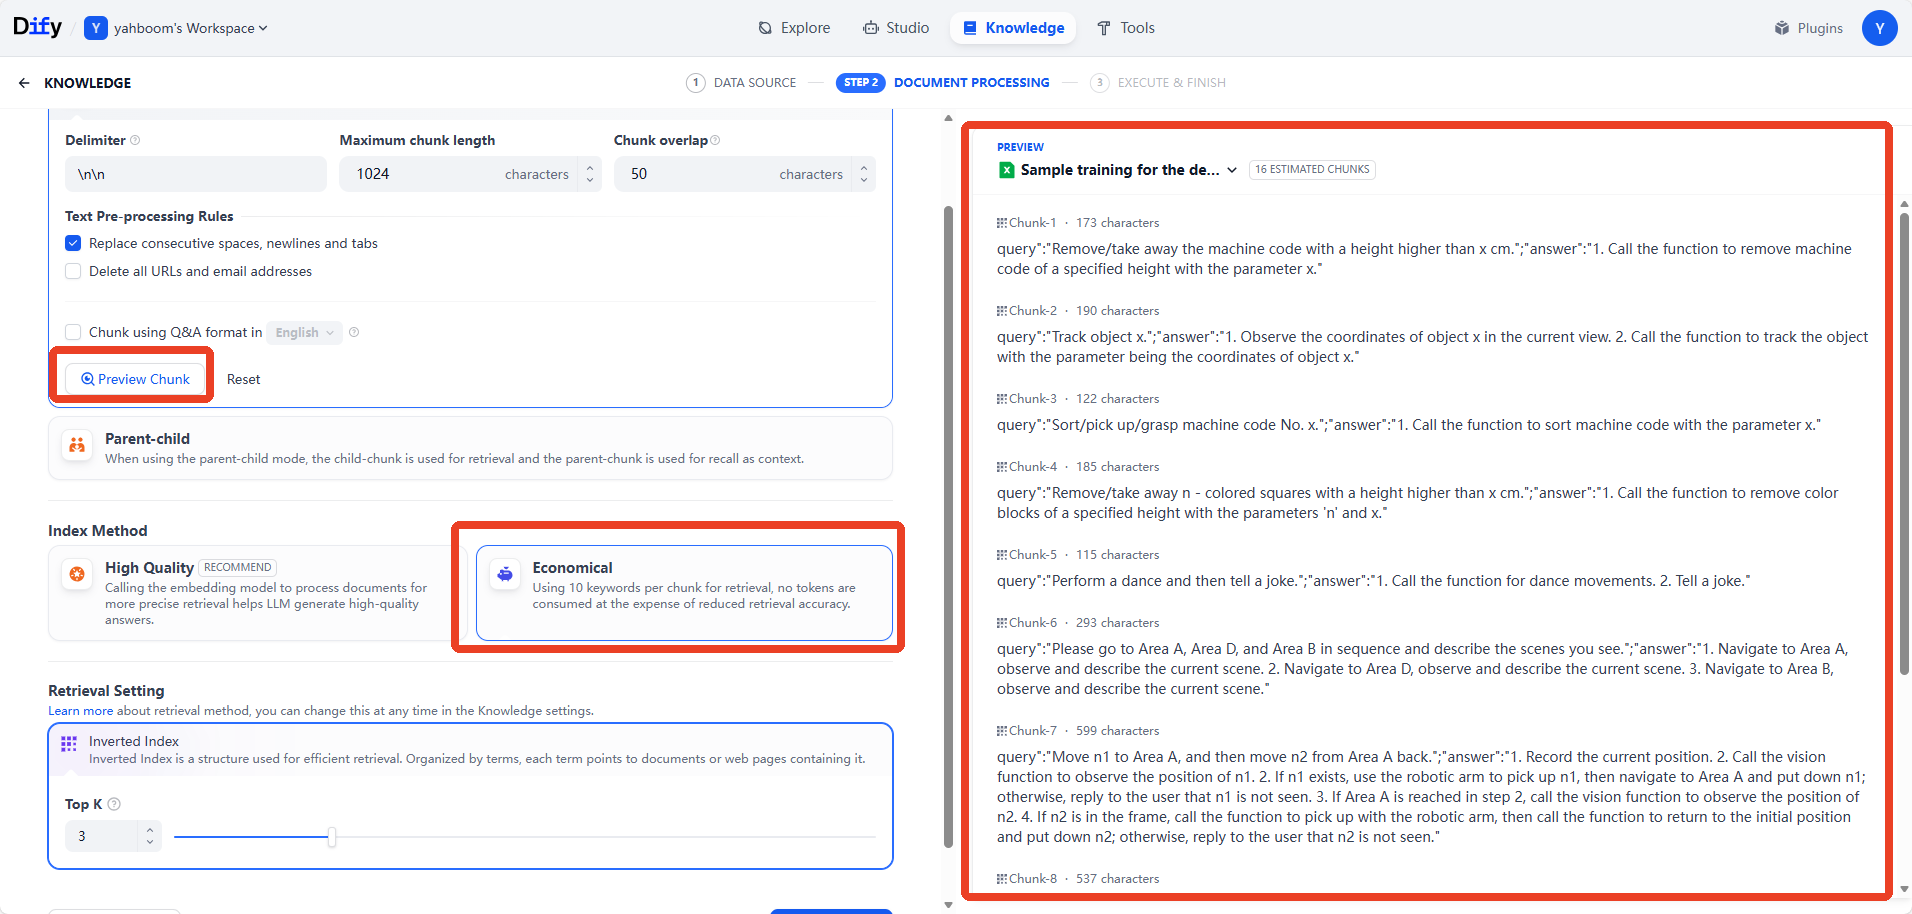
image-20251219184705522

  • Then wait for the embedding to complete and click Go to document.
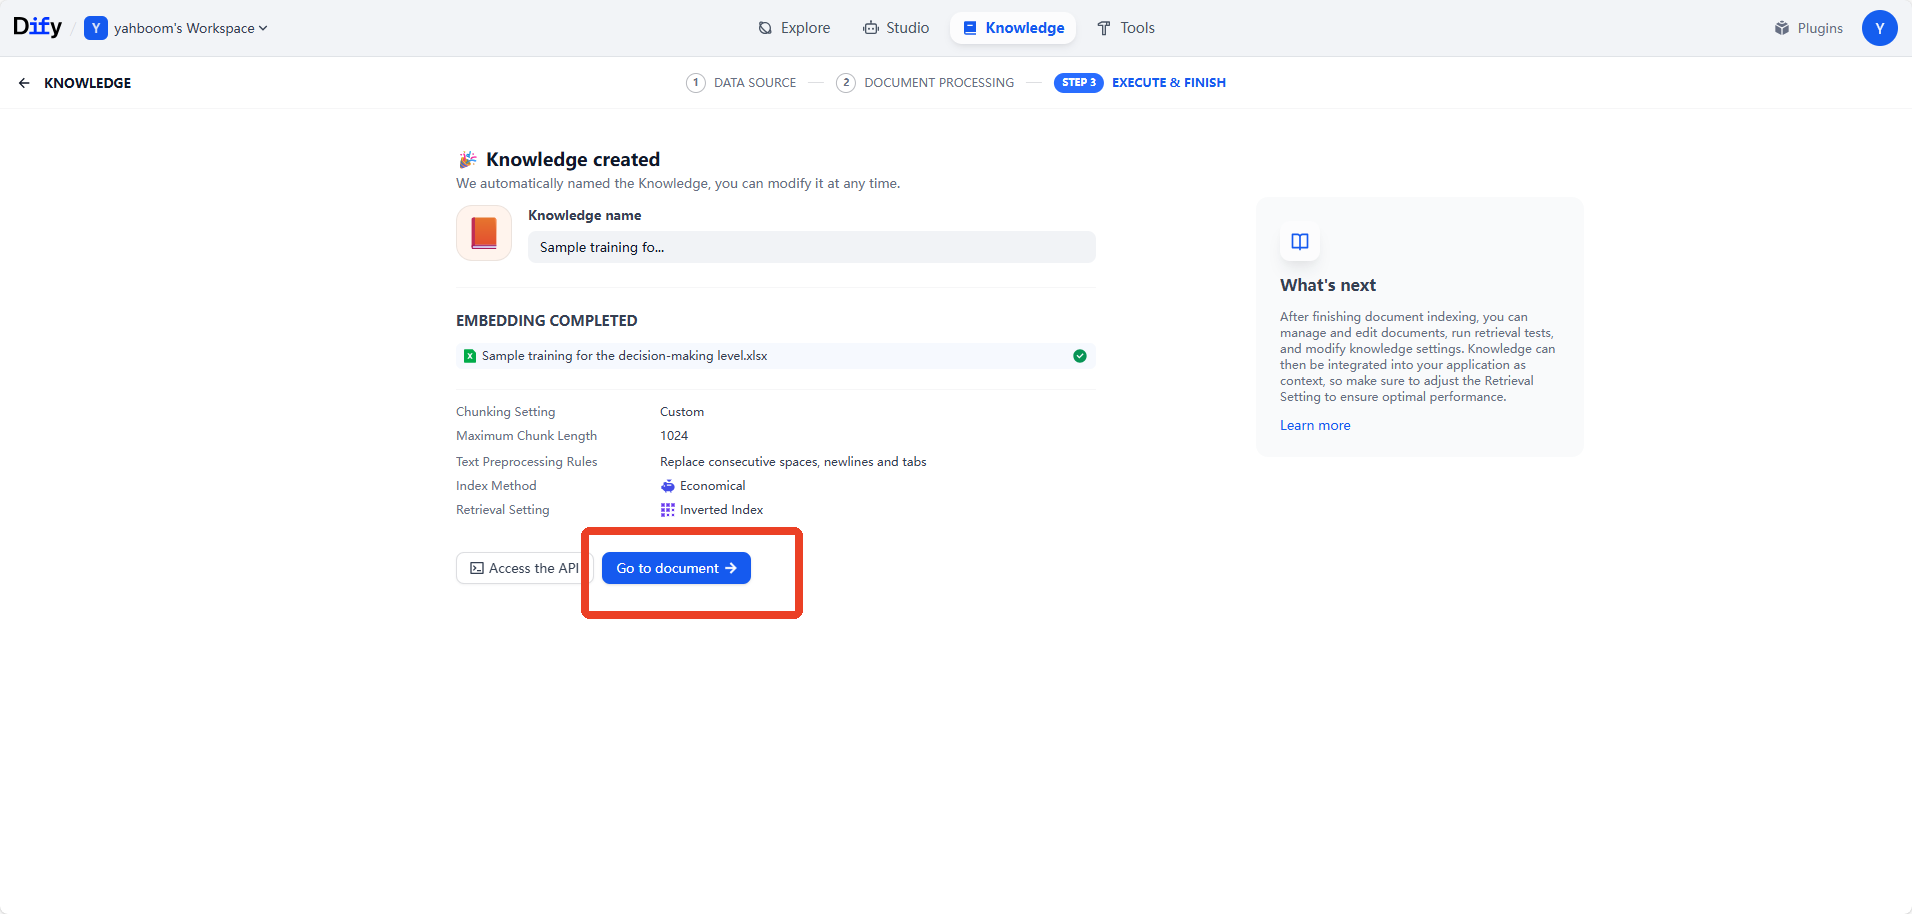
image-20251219190308224

  • When the knowledge base is normal, its status will be displayed as Available. Then click the Documents of the knowledge base.
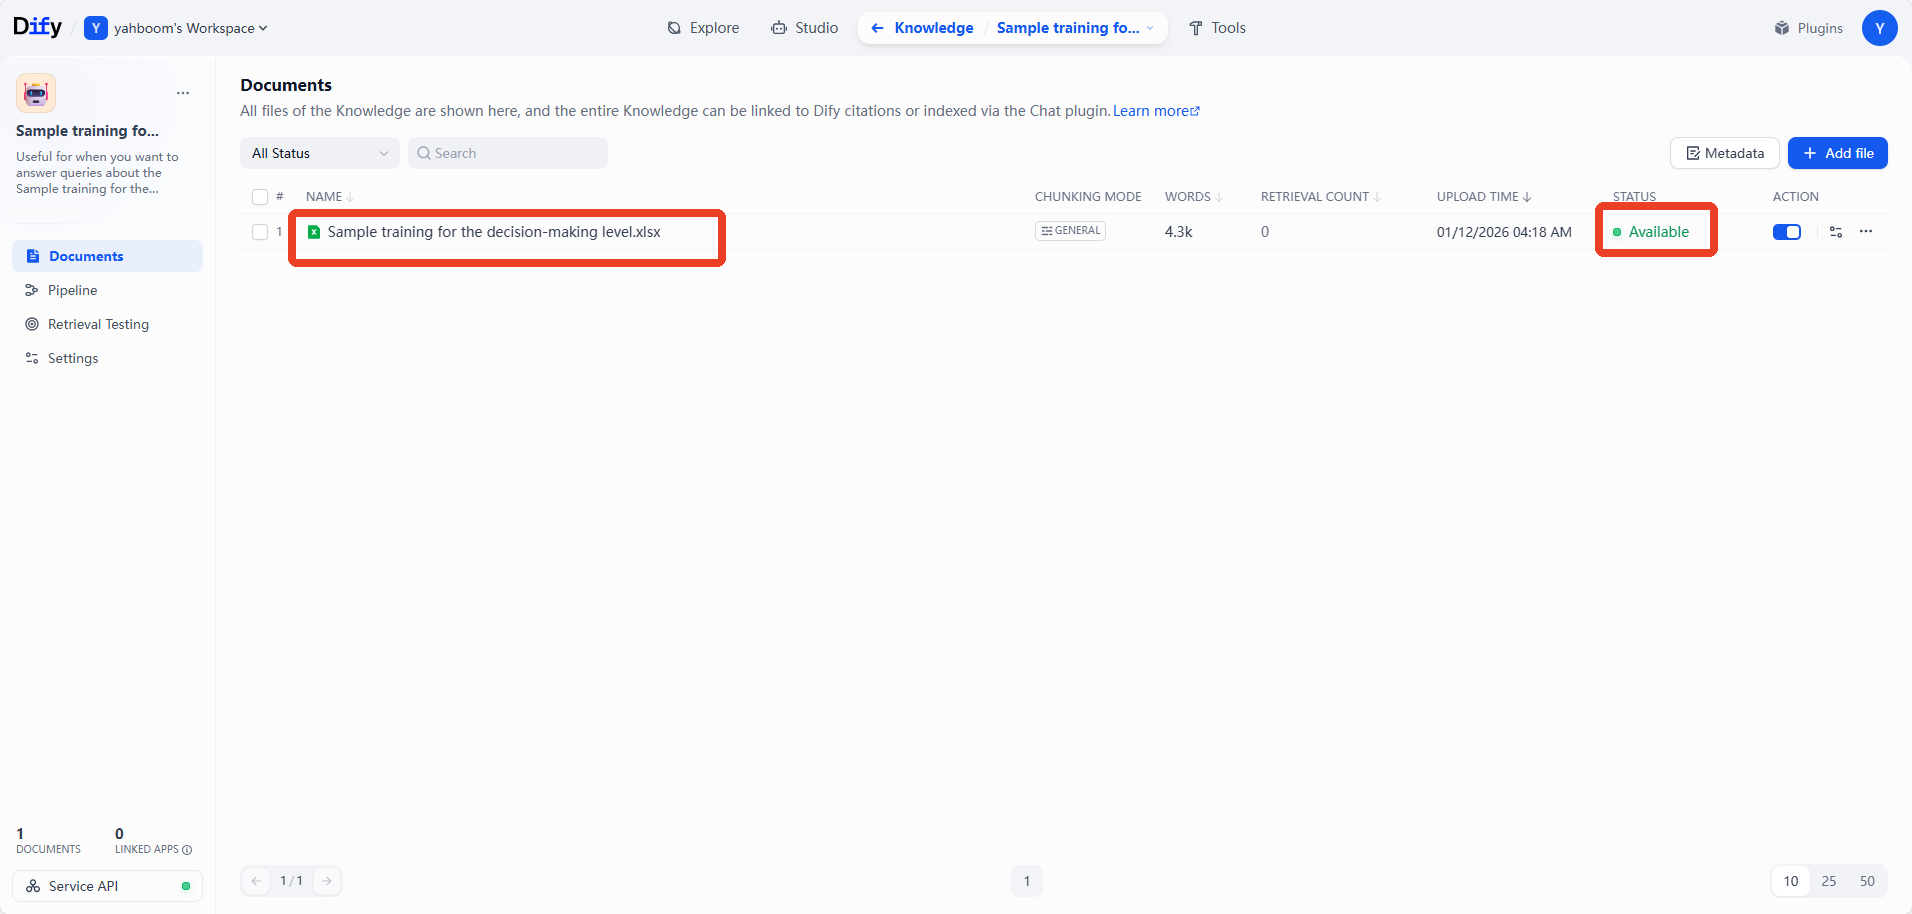
image-20251219190716325


  • Then we can see the knowledge base chunks that have been segmented. The small text below each chunk is the automatically segmented keyword of that chunk (available only in the Economy mode).
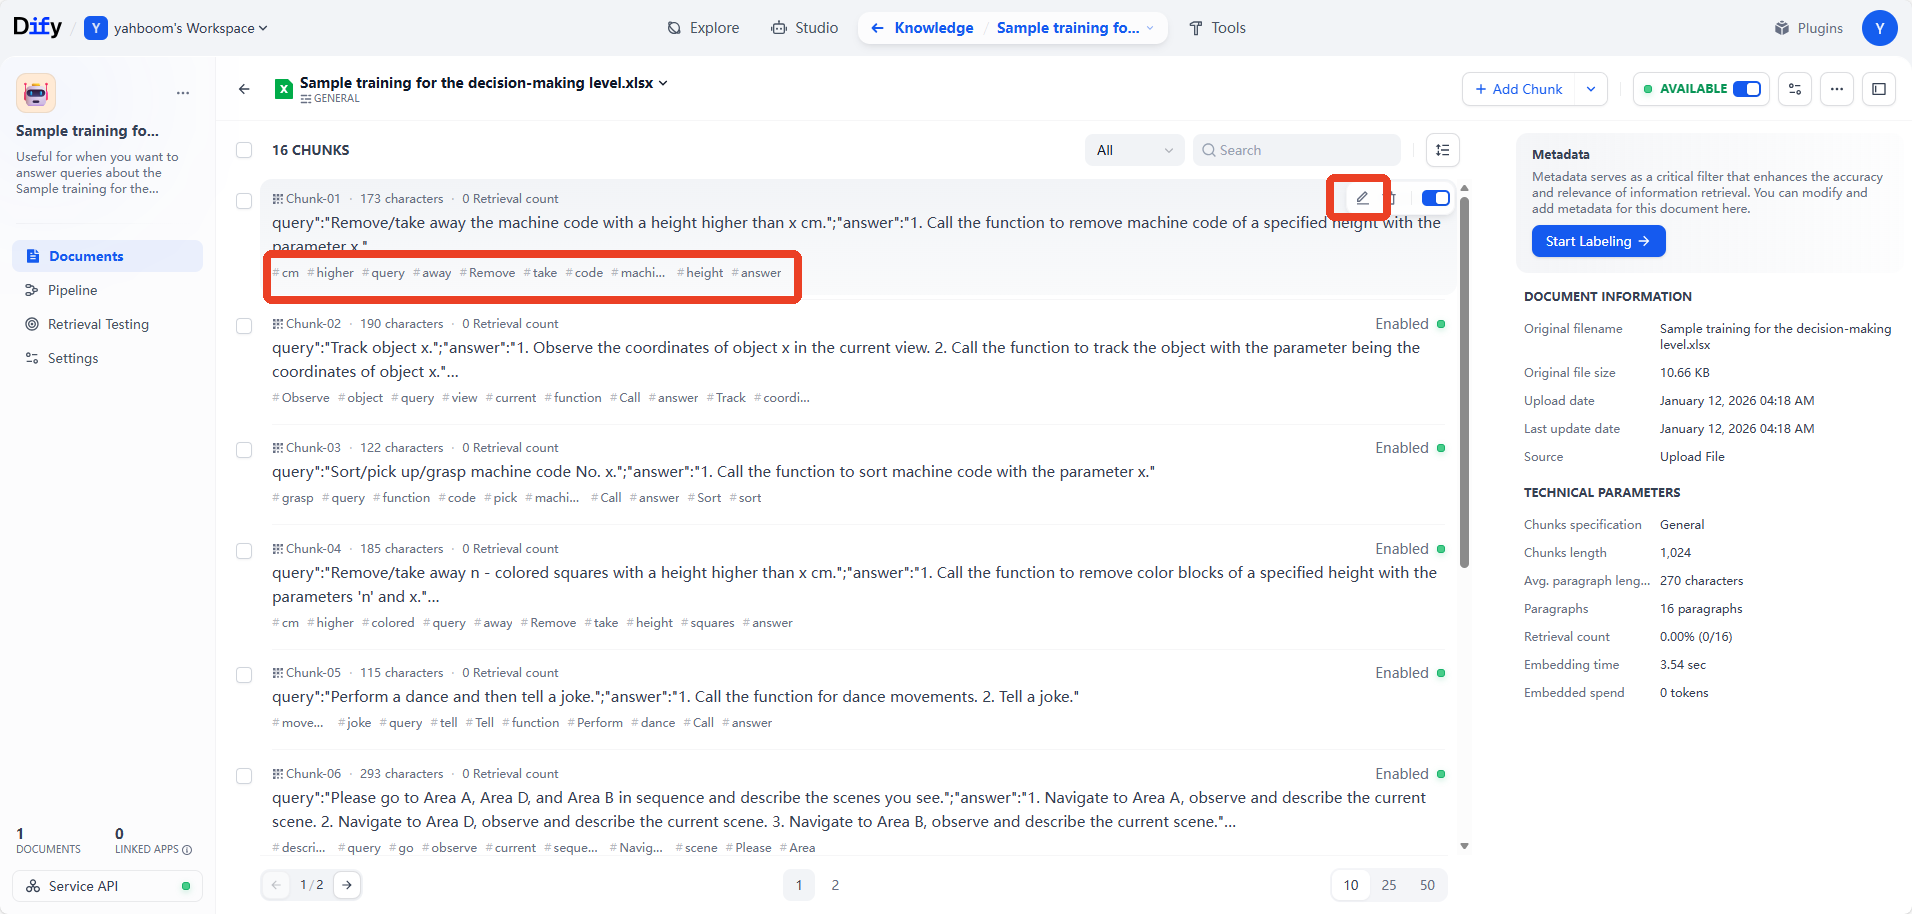
image-20251219191257204


  • If the keyword does not accurately describe the knowledge segment, click Edit on the right side of the segment to edit the content or keyword of that segment individually. In the figure below, the keyword was modified, and then Save was clicked.
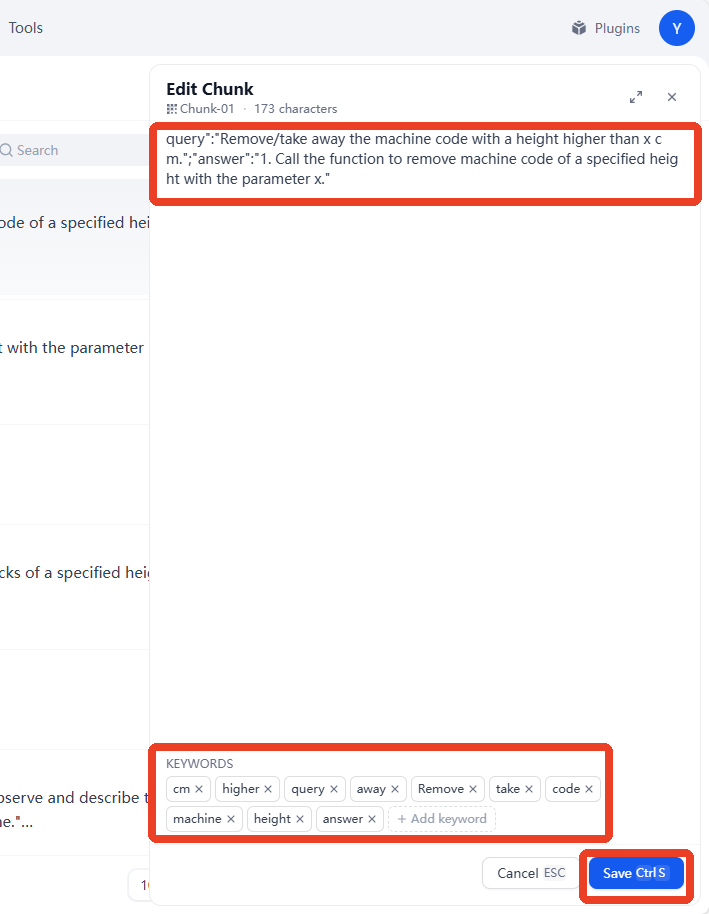
image-20251219192446703


4.2 High-Quality-Mode Knowledge Base

  • If you need to use a high-quality knowledge base later, refer to the tutorial in this section.

  • Creating the knowledge base and importing the file are the same as before.

  • Here, select High Quality as the indexing mode, and choose any retrieval method (hybrid retrieval is used as an example here). Finally, click Save and Process.
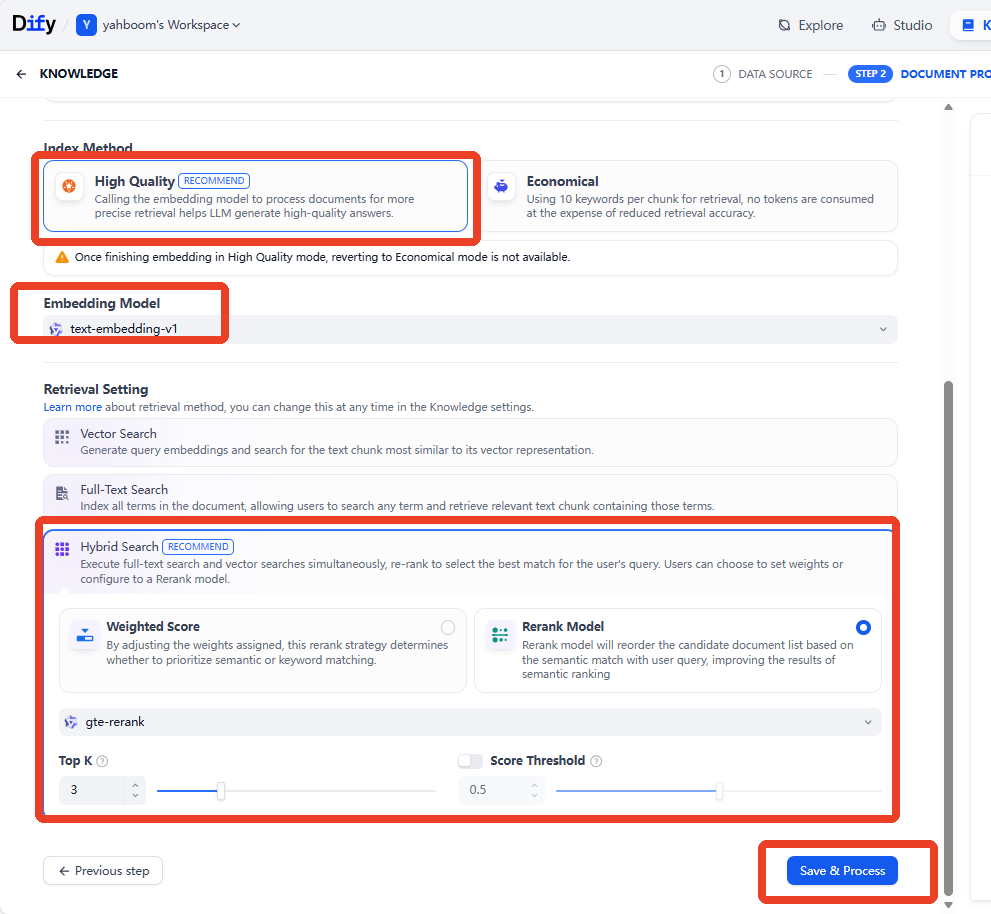
image-20251219193448878


4.3 Retrieval Testing

  • Retrieval Testing tests the actual effect of recalling relevant knowledge segments from the knowledge base based on input, helping to tune better AI model reply effects.

  • Open a knowledge base and click Retrieval Testing on the left side.
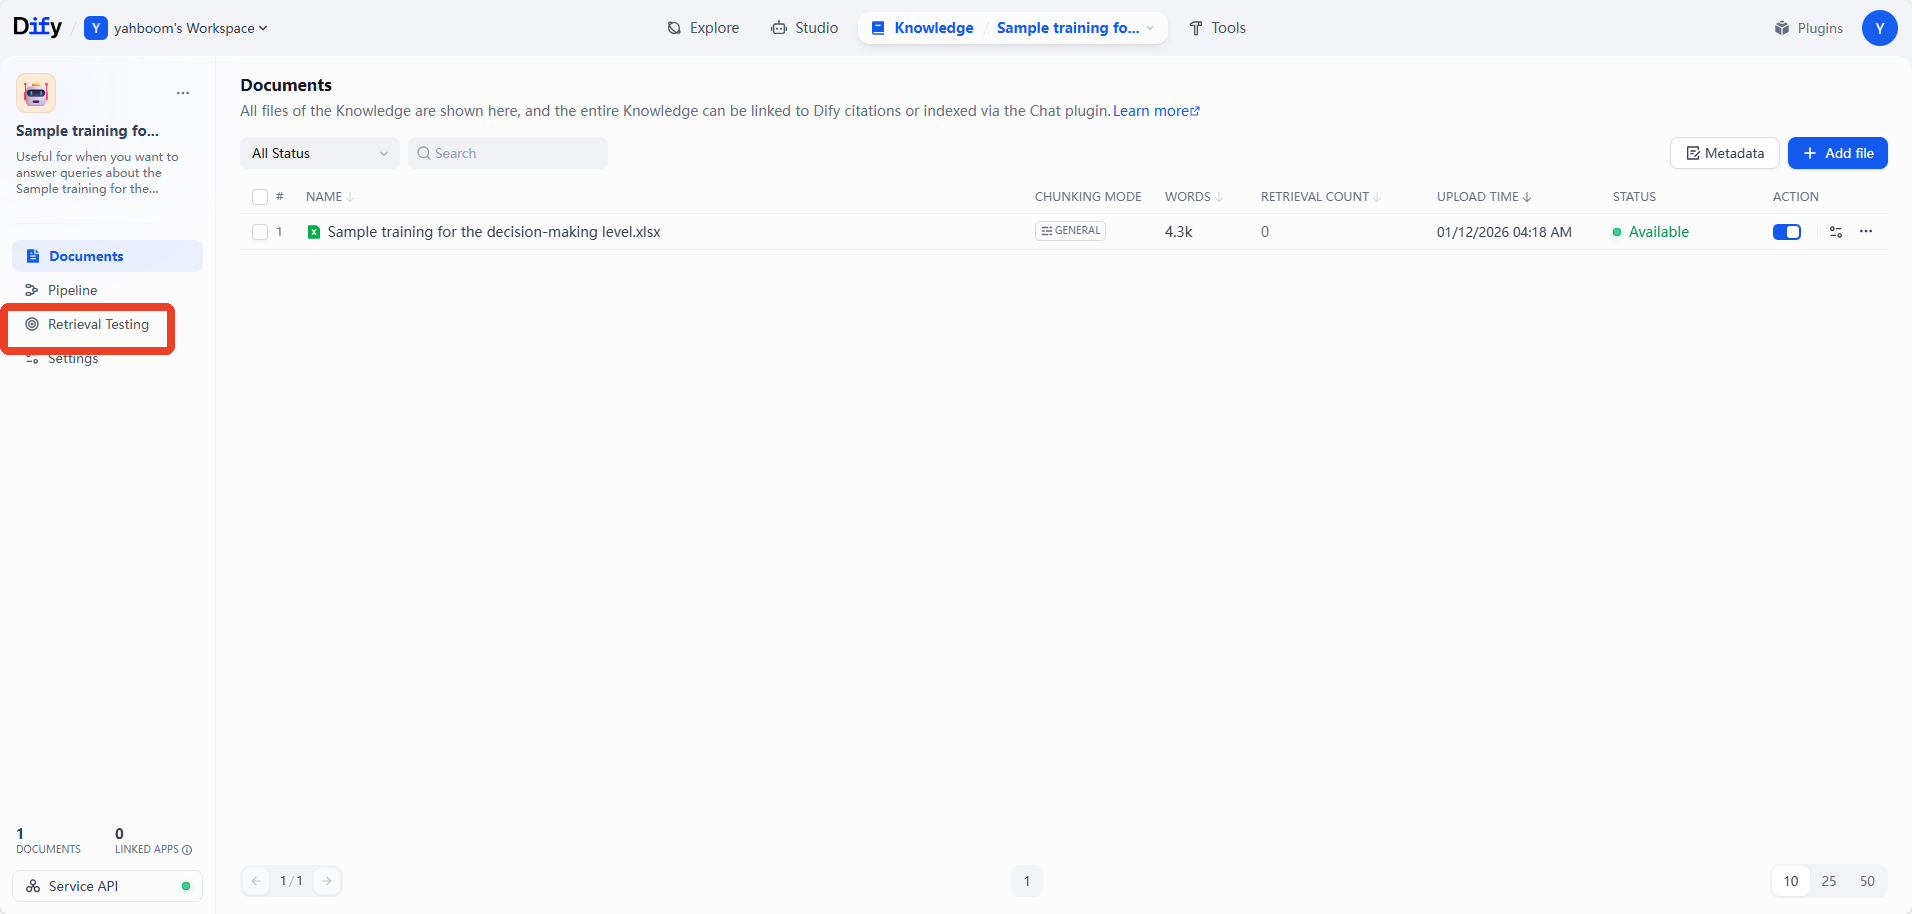
image-20251222094359492


  • Enter test content in the Source Text field (simulating the content that a user inputs in actual use), and then click Test.

  • On the right side, the recalled paragraphs related to the input content will appear. The knowledge base tested here is an Economy-mode knowledge base, which retrieves the knowledge base based on keywords.

Tip

The default reference knowledge base shipped from the factory uses the High Quality mode.

  • For a High Quality mode knowledge base, the recalled segments will have a SCORE rating. The higher the score, the higher the match between the segment and the input content. High Quality mode knowledge bases can perform associative retrieval of similar semantics, but they also consume tokens.
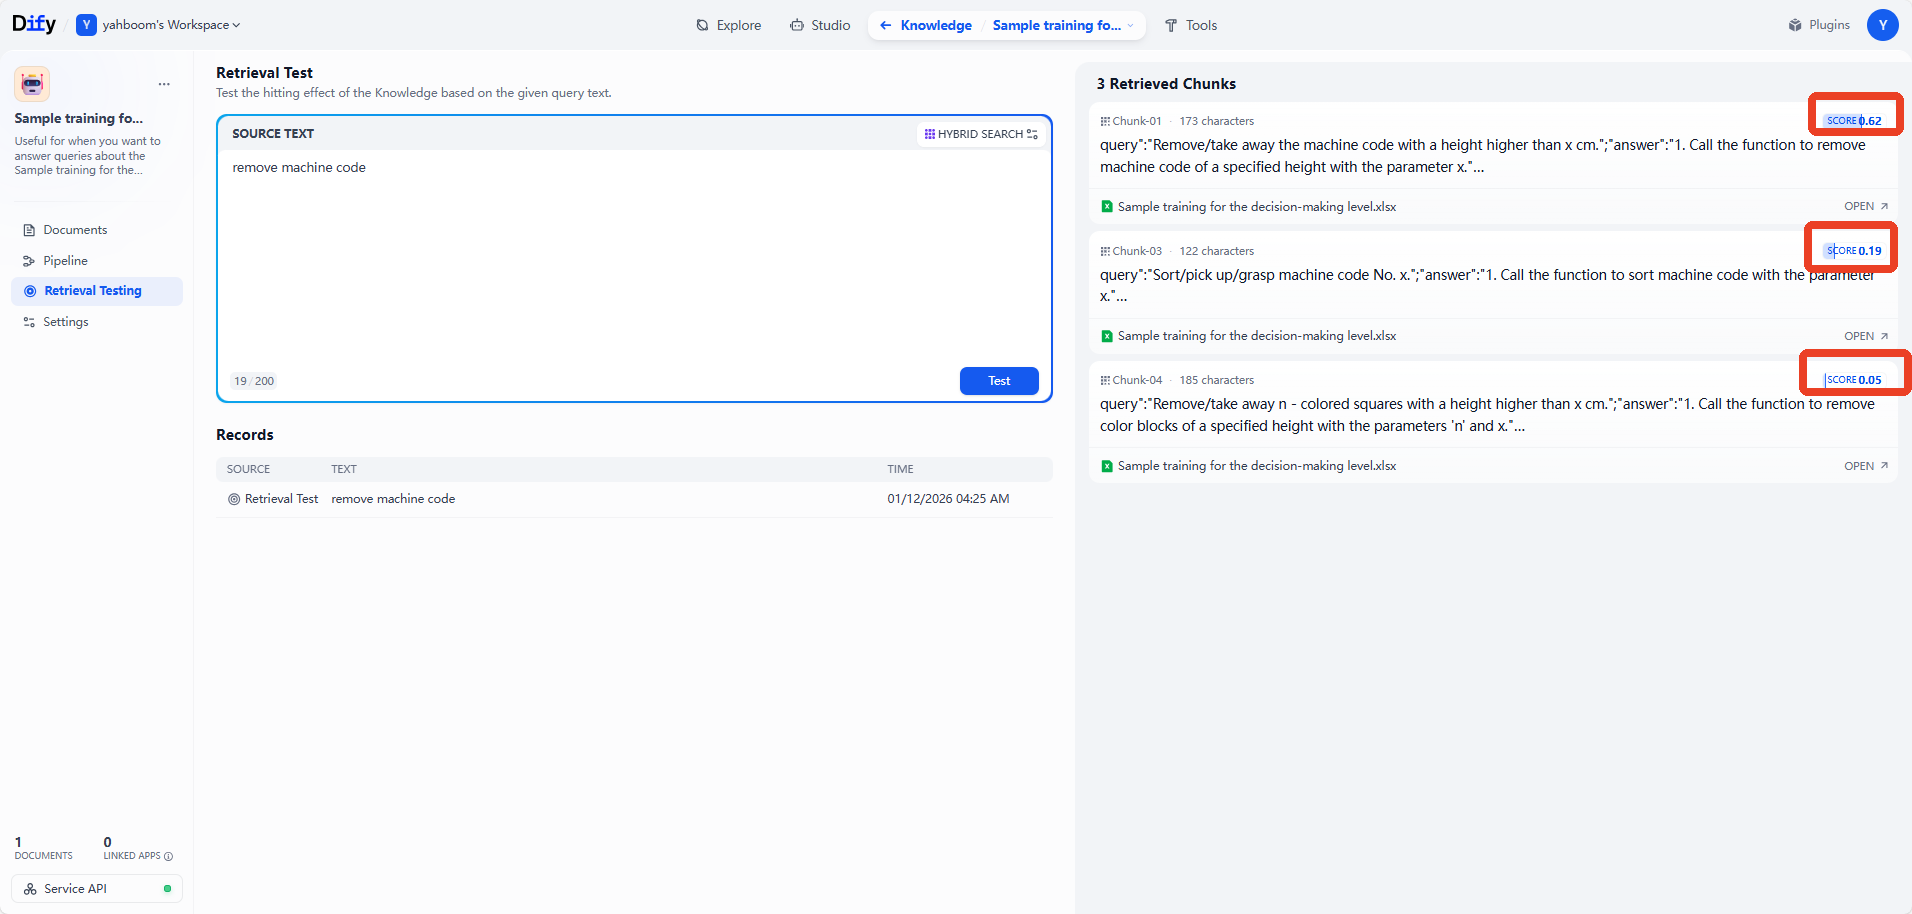
image-20251222095402665

AI Large Model Development - chatbot
RAG Knowledge Base + chatbot

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文